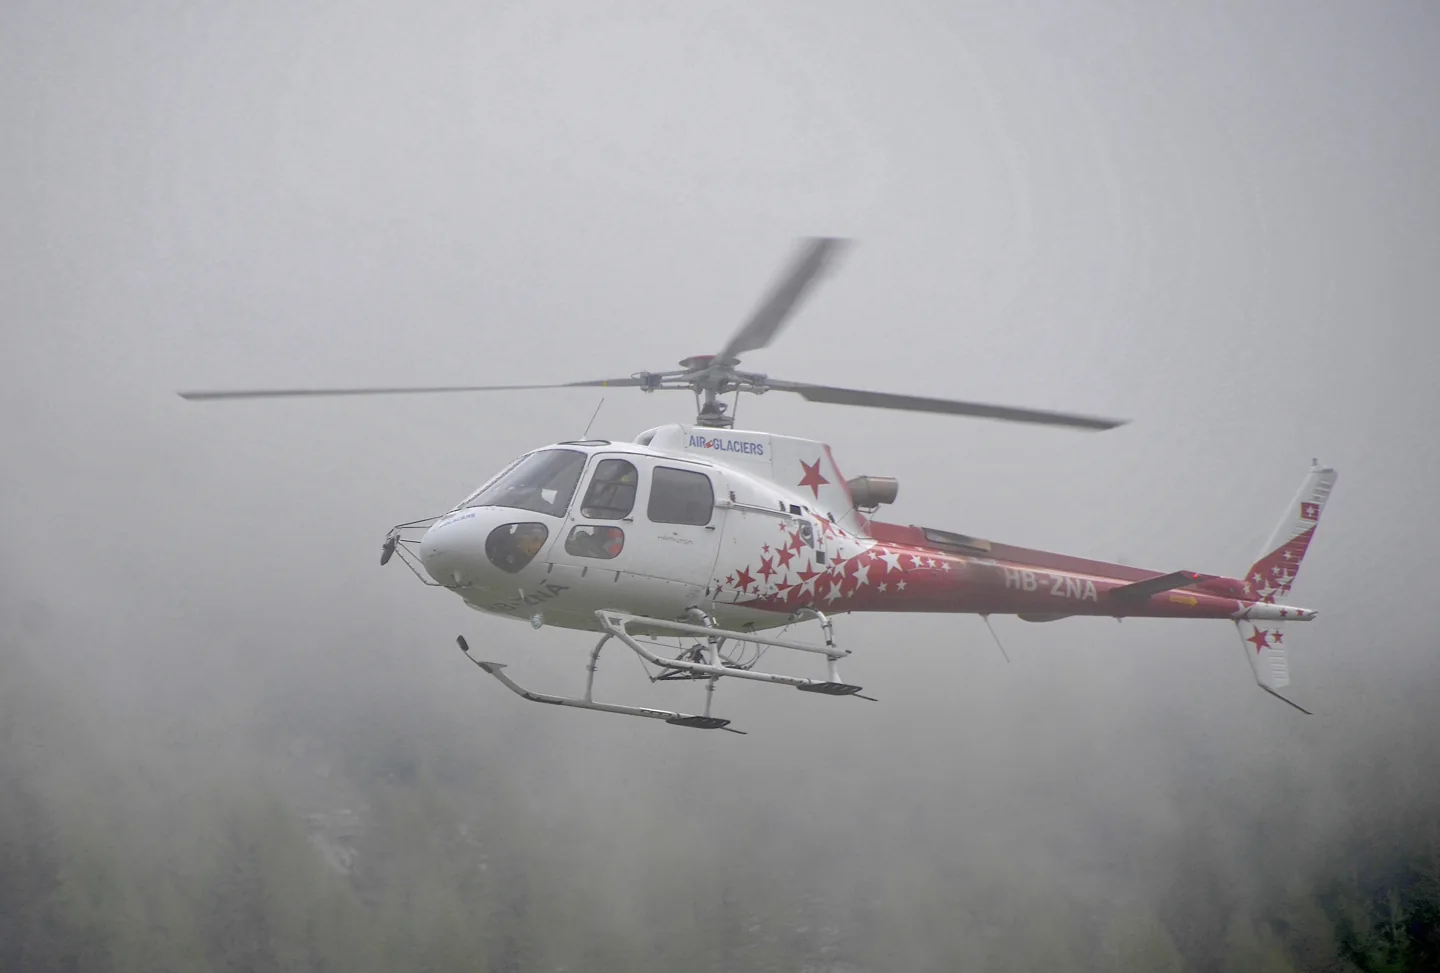
Aircraft libraryAirbus H125
Airbus H125Olga Ernst · CC BY-SA 4.0 · Airbus H125

Airbus H125

Hydraulically assisted cyclic controls and mechanical mixing, with three-blade Starflex rotor cues.
HelicopterH1257 profile choices

Know the plane

The H125 belongs to the AS350 lineage developed by Aérospatiale and continued through Eurocopter into Airbus Helicopters. Its broad cabin and single turbine support work ranging from passenger transport to observation and external-load operations.

The names reflect both the aircraft's history and its markets: Écureuil means squirrel, while AStar is familiar in North America. Equipment changed through the AS350 and H125 generations. Bundled simulator aircraft and independent add-ons have separate systems descriptions.

Airbus H125

Powerplant
Safran Arriel 2D, 847 shp takeoff↗
Seats
1 + 5↗
Max takeoff weight
4,961 lb (2,250 kg) internal↗
Main rotor diameter
35 ft 1 in (10.69 m)↗
Length overall
42 ft 6 in (12.94 m)↗
Never exceed (Vne)
155 KIAS↗
Fast cruise
≈132 kt↗
Service ceiling
≈23,000 ft↗
Range
≈340 nm↗
Usable fuel
≈143 US gal↗
Rotor system
Three-blade Starflex, hydraulically boosted↗
Notable
Landed on the summit of Everest, 2005↗

More about this aircraft on AirframeDB

An injured climber and weather closing over the glacier

Dulal recalled a rescue that remained particularly vivid among his mountain flying. A climber at Lobuche had a broken leg and altitude sickness, while poor weather complicated reaching the glacier. Bringing the patient aboard took time, and the clouds continued to close around the landing area as the crew worked.

The departure required a difficult judgement between worsening conditions and the patient’s need for help. Dulal described the flight back through Lukla to Kathmandu as one of his most challenging missions. Dulal also expressed confidence in the H125.

Looking back at Everest and the people behind the flight

Twenty years after Everest, Delsalle’s strongest memories included much more than handling the helicopter. Obtaining permission, arranging supplies and preparing a distant mission on a tight budget had been major obstacles. Engineers and technicians contributed extra time to the project, forming friendships that lasted long after the record flight.

In Nepal, the power of the mountain environment made an equally lasting impression. Delsalle described air movements unlike anything he had expected, reinforcing the respect for terrain he had learned during military training in the Alps. He gave substantial credit for the achievement to the people who designed and prepared the aircraft.

Testing a modification against the work he already knew

As a working mountain and rescue pilot, Bourke wanted to understand what the FastFin modification would change in familiar conditions. At Gunnison, the team loaded the test aircraft to resemble his usual missions. The cockpit carried additional instruments and recording equipment, giving the demonstration a different atmosphere from an ordinary working flight.

Bourke noticed smoother heading control during hovering and liked the response as they tried approaches. Dan Smith later demonstrated measured control margins while the displays showed pedal movement. Bourke had not witnessed the unmodified comparison flights, so his own assessment combined this demonstration with experience in other H125s. He came away enthusiastic about the modified aircraft, with his interest rooted in the precision and comfort required when carrying out difficult jobs in the mountains.

Public sources 19
  1. Eurocopter AS350 ÉcureuilResearch background · Wikipedia revision 1373884153 · retrieved 2026-09-12
  2. Microsoft Flight Simulator aircraft manuals
  3. MSFS 2024 FAQ and edition aircraft inventory
  4. CowanSim H125 user manual · MSFS
  5. CowanSim manuals
  6. SAS Autopilot Manual
  7. SAS Manual
  8. User Manual
  9. X-Plane aircraft and avionics manuals
  10. H125 (AS350B3e) for MSFSOfficial developer / designated store catalogue · checked 2026-09-12
  11. H125 (AS350B3e) for X-PlaneOfficial developer / designated store catalogue · checked 2026-09-12
  12. The H125 at the top of the worldShashwot Dulal interviewed by Heather Couthaud · 8 November 2018
  13. Didier Delsalle’s twentieth-anniversary Everest interviewDidier Delsalle · 14 May 2025
  14. Taming the SquirrelJon Bourke · 2 March 2017; BLR FastFin evaluation
  15. ICAO Doc 8643 — aircraft type designatorsPublic search data retrieved 2026-09-14; authority update 2026-09-03
  16. MSFS 2024 Sim Update 3 release notesPublisher announcement or release notes
  17. Airbus H125 flight manualPrint or archived reference; no public link
  18. EASA TCDS R.008Print or archived reference; no public link
  19. Airbus published dataPrint or archived reference; no public link

How the profile models it

CowanSim H125 / AS350B3e

Free + Pro
X-Plane 12CowanSim

The H125 belongs to the AS350 lineage developed by Aérospatiale and continued through Eurocopter into Airbus Helicopters. Its broad cabin and single turbine support work ranging from passenger transport to observation and external-load operations.

This profile selects CowanSim H125 / AS350B3e for X-Plane 12.

The spring stays independent of airspeed. Directed aerodynamic loading is omitted.

Local force trim is off. Autopilot following is off.

Cyclic damping is on. Its configured gain is 0.35; it resists hardware motion separately from the spring and aircraft stabilization.

Controls and trim

The H125/AS350 has hydraulically assisted cyclic controls. The cited AS350 retrofit account describes very little aerodynamic feedback and quick linkage response; servo transparency under high loads is a separate documented phenomenon that this profile does not reproduce. CowanSim's optional HeliSAS distinguishes force-trim procedures for spring-centred and noncentering controls. Its trim-release and reset commands are not continuously readable hardware-neutral positions.

User ManualCowanSim HeloSAS autopilot manualUser ManualSAS ManualAS350 Garmin GFC 600H Flight Control SystemJack Be Nimble

The selected implementation

CowanSim's per-aircraft and simulator-edition trim/reset behavior remains separate from a local hardware-centre latch. An unsupported hydraulic binding does not create a force command.

User ManualSAS Manual

About the values

The gains are normalized profile settings. They describe the chosen effect balance; hand force depends on the device and its output limits. IAS references are tuning values rather than operating limits. Physical acceptance of this revision remains pending.

Master gain & control system

Master gain65%

The final overall output scale applied to everything the model produces, before the device cap.

More: everything (spring, loads, effects) gets stronger together.

Less: everything softens together.

Why here: Scales overall profile strength while preserving effect balance, subject to device and output limits.

Forces

Spring strength14%

The base centring force that pulls the stick back to centre. Every other force stacks on it. Too low and the stick feels limp in normal flight; too high and it fights your hand and masks the smaller cues layered above it.

More: firmer centring that resists your hand at all times.

Less: a limper stick that leans on aerodynamic load alone.

Why here: Nominal cyclic centering represents the boosted control arrangement without adding an unmodeled servo-transparency force. The baseline spring is 0.14. Low-speed spring blending is off.

User ManualCowanSim HeloSAS autopilot manualUser ManualSAS ManualAS350 Garmin GFC 600H Flight Control SystemJack Be Nimble
Spring deadband2%

A small neutral zone around centre where the spring stays quiet, so tiny movements at rest don't chatter. Wider is calmer but looser; narrower is more precise but can twitch around centre.

More: a calmer but looser centre with more free play.

Less: a tighter centre that may chatter at rest.

Why here: Sets travel around the centre before the baseline spring resists. Smaller values engage it sooner.

Overall aerodynamic load0%

A master scale over both sustained axis loads, applied before their independent balance. Profiles normally leave this alone and tune the two axis loads instead.

More: both axes load up harder.

Less: both axes lighten together.

Why here: The 0 gain omits sustained directed airspeed loading. Spring resistance remains independent.

Airspeed blendingFalse

Enables the low-speed spring engagement window (start/full knots above). Off, the spring is constant at all speeds.

Why here: Allows baseline spring strength to rise with indicated airspeed where the control law permits it.

Low-speed spring floor100%

How much of the spring survives at a standstill, before airspeed can build any aerodynamic force. A high floor keeps the parked stick firm; a low floor gives the loose, cable-slack feel of a parked light aircraft.

More: a firmer stick while parked and taxiing.

Less: a floppier parked stick that only wakes up with airspeed.

Why here: Sets low-speed spring strength as a fraction of baseline when blending is enabled. One keeps full strength.

Spring engagement start8 kt

The airspeed where the spring begins climbing from its low-speed floor toward full strength: the controls "coming alive" on the takeoff roll.

Why here: Sets the IAS where the low-speed spring blend starts rising. This is a feel threshold, not a flight limit.

Spring engagement full60.0 kt

The airspeed where the spring reaches full strength. Between the start and this point, centring firms up progressively as airflow builds over the controls.

Why here: Sets the IAS where the low-speed blend reaches baseline strength; high-speed stiffening also uses it.

Force tuning speed120

The indicated airspeed where aerodynamic load reaches its designed full level. It anchors the whole load curve to the aircraft's real speed range: a 172 loads up by 110 knots, a jet much later.

More: loads arrive later; the stick stays light up to a higher speed.

Less: loads arrive earlier and cruise feels heavier.

Why here: Sets the IAS reference for aerodynamic loading. It is an estimate, not published cruise TAS or a flight limit.

Centre firmness vs speed0%

How much the centring itself stiffens with speed, on top of the deflection loads. Zero keeps centre feel constant; more makes the stick centre harder at cruise and looser in the pattern.

More: a centre that hardens noticeably as you go faster.

Less: constant centre feel at every speed.

Why here: Adds permitted spring resistance above the full-blend speed. Zero removes this high-speed increase.

Centre stiffening cap5

The upper limit on speed-driven centre stiffening, so very fast flight can't wind the spring up without bound.

More: more total stiffening allowed at high speed.

Less: stiffening clamps off sooner.

Why here: Limits the squared airspeed ratio used for high-speed spring stiffening; it is not a device-force cap.

Aileron load72%

The sustained roll load from aileron deflection and airspeed, balanced independently of pitch. Together with the elevator load it sets the control-harmony ratio reviewers talk about.

More: heavier roll forces.

Less: lighter, quicker-feeling ailerons.

Why here: Roll and pitch aerodynamic scales are 0.72 and 1, respectively. These stored weights do not create directed aerodynamic loading while that term is inactive. No custom spring-travel curve is enabled.

Elevator load100%

The sustained pitch load from elevator deflection and airspeed, balanced independently of roll. This is the main lever behind a type's pitch weight. It does not touch aileron, spring, trim, or buffet forces.

More: heavier sustained pitch forces at speed.

Less: a lighter elevator that takes less muscle to hold.

Why here: Scales pitch aerodynamic loading; pitch spring travel and trim responses are separate settings.

Max output force55%

A cap on each steady pitch or roll force before it reaches the device, guarding against slamming or saturating the hardware in strong maneuvers.

More: stronger peak steady forces before clipping.

Less: a gentler ceiling; hard maneuvers flatten out sooner.

Why here: Caps directed-force output. Native spring effects and device limits remain separate.

Trim

Trim relief (elevator)0%

How strongly elevator trim relieves held pitch force and shifts where the stick settles. At 100%, a properly trimmed aircraft needs no held pressure, the trim-away-the-load workflow of real flying.

More: trim removes more of the held pitch force; at 100% full trim zeroes it.

Less: you keep holding force even when trimmed.

Why here: Scales supported pitch-trim relief and permitted centre movement. Zero removes pitch response.

Trim relief (aileron)0%

The same relief for roll trim. Most GA types have no real aileron trim, so this stays at zero; types with roll trim get a matching value.

More: roll trim removes more held roll force.

Less: roll trim does less.

Why here: Scales supported roll-trim relief and permitted centre movement. Zero removes roll response.

Effect gains · ground

Runway rumble0%

Rolling surface vibration from wheel speed and surface type: pavement, grass, or gravel under the gear.

More: louder surface texture through the stick.

Less: a smoother taxi.

Why here: Sets rolling texture strength, modified by speed, surface and undercarriage configuration.

Gear bumps0%

Short discrete bumps from expansion joints, ruts, and rough surface, punctuating the continuous rumble.

More: sharper hits from joints and ruts.

Less: softer ground detail.

Why here: Sets gear-bump texture during ground motion, separate from touchdown impact.

Effect gains · airframe

Stall buffet0%

Airframe shake approaching the stall and while the stall warning is active: how loudly this wing announces it is unhappy. Types with a crisp break get modest buffet and let the horn carry the warning.

More: a louder pre-stall shake.

Less: a quieter wing; the horn carries the warning.

Why here: Sets stall-buffet strength. Zero removes the cue without changing simulator stalls or warnings.

Mach buffet0%

Transonic buffet approaching the Mach limit. Meaningful for jets near MMO, zero for pistons and turboprops that never get there.

More: stronger transonic buffet near the Mach limit.

Less: a smoother high-Mach ride.

Why here: Sets high-Mach buffet strength; onset and full-strength thresholds are separate.

Flap buffet0%

Low-frequency airframe vibration with flaps extended into the airflow, in the speed window where they actually work the air.

More: a rougher ride with flaps working the air.

Less: smoother approach flap.

Why here: Sets flap buffet at the configured position and speed gates. Flap movement texture is separate.

Gear buffet0%

Airframe drumming from retractable gear hanging in the airstream. Zero for fixed-gear types, where the airframe never changes shape.

More: more drumming with the wheels hanging out.

Less: cleaner gear-down flight.

Why here: Sets gear aerodynamic buffet; movement and ground-contact cues are separate.

Stick shaker50%

The dedicated stall stick-shaker buzz, fired by the aircraft's own stall-warning system. Only types with a real shaker get a value; everything else relies on aerodynamic buffet and the horn.

More: a harder stick-shaker buzz.

Less: a subtler shaker.

Why here: Sets triggered shaker strength; inactive while the shaker feature is disabled.

Effect gains · engine, mechanical & drag

Touchdown thump50%

The one-shot kick when the wheels meet the runway, scaled by sink rate: a greaser whispers, a firm arrival thumps.

More: a harder kick at touchdown.

Less: softer arrivals.

Why here: Sets landing-impact strength; landing telemetry and response shape determine the pulse.

Reverse rumble0%

Rollout vibration while reverse thrust or beta-range props are working. Zero for types without reverse.

More: a rougher rollout under reverse.

Less: quieter reverse.

Why here: Sets reverse-thrust vibration with valid reverser and engine conditions. Zero removes the cue.

Engine rumble0%

Continuous powerplant vibration following RPM between idle and full power, the ever-present reminder that something is burning fuel up front.

More: more engine through the stick.

Less: a quieter powerplant.

Why here: Sets estimated engine vibration using configured telemetry and response, not measured cockpit vibration.

Flap motion0%

Continuous vibration only while the sim reports the flap surfaces actually travelling. It follows real actuator motion and failures, not an estimated timer.

More: more vibration while the flap surfaces travel.

Less: quieter flap runs.

Why here: Sets texture from observed flap movement; a command without movement does not establish the cue.

Autopilot follow

AP follow authority5%

How far autopilot commands may physically move the stick. Kept tiny in MSFS, where a moved axis can read back as pilot input; zero disables following entirely.

More: the autopilot visibly moves your stick further.

Less: a barely perceptible follow.

Why here: Sets admitted AP-follow gain, not a percentage of travel. Runtime ownership and input limits still apply.

Stick feel

StickFeel · Trim feel enabledFalse

Whether this feature is active in this profile.

Why here: Retained for compatibility and group membership. Trim relief, rather than this flag, controls centre movement.

StickFeel · Trim relief enabledFalse

Whether this feature is active in this profile.

Why here: Allows trim relief with supported control law and valid telemetry. Axis authorities set its amount.

StickFeel · G load enabledFalse

Whether this feature is active in this profile.

Why here: Allows load-factor changes to modify permitted spring laws. Passive fly-by-wire feel can suppress it.

StickFeel · Rate damping enabledFalse

Whether this feature is active in this profile.

Why here: Enables rate damping with the configured coefficients and control law.

Autopilot

Autopilot · Follow enabledFalse

Whether this feature is active in this profile.

Why here: Autopilot following is off; the configured spring and load retain the hardware feel.

Autopilot · Neutral hold enabledFalse

Whether this feature is active in this profile.

Why here: Permits centering hold during a supported AP state, separate from following a moving target.

Autopilot · Neutral hold strength0.6

Why here: Sets admitted AP neutral-hold strength; inactive while neutral hold is disabled.

Aero

Aero · EnabledTrue

Whether this feature is active in this profile.

Why here: Enables aerodynamic cues; each still needs nonzero strength and its simulator conditions.

Aero · Max flap index1

Where this effect reaches full strength (or has fully faded, for washouts).

More: a more gradual build to a later peak.

Less: a quicker build.

Why here: Sets the final flap index for detent normalization. UP plus three detents uses maximum index3.

Aero · Min flap index1

Where this effect begins fading in.

More: the effect begins later.

Less: it begins earlier.

Why here: Sets the first flap detent that admits buffet; this is a handle index, not degrees.

Aero · Shaker enabledFalse

Whether this feature is active in this profile.

Why here: Permits shaker at supported warning conditions; the switch does not establish aircraft equipment.

Ground

Ground · EnabledTrue

Whether this feature is active in this profile.

Why here: Enables ground effects; each still needs its own strength and contact or motion telemetry.

Engine

Engine · EnabledTrue

Whether this feature is active in this profile.

Why here: Enables engine cues with nonzero settings and valid running-engine telemetry.

Mechanical

Mechanical · EnabledTrue

Whether this feature is active in this profile.

Why here: Enables accessory cues with configured strengths and observed accessory movement.

Mechanical · Gain0

The strength of this effect.

More: a stronger effect.

Less: a weaker one.

Why here: Sets texture from observed gear movement, separate from aerodynamic and touchdown effects.

All profile settings
Estimated profile settings
ParameterValueWhat it controls and why
Spring strength0.14 Nominal cyclic centering represents the boosted control arrangement without adding an unmodeled servo-transparency force. The baseline spring is 0.14. Low-speed spring blending is off.
Spring deadband0.02 Sets travel around the centre before the baseline spring resists. Smaller values engage it sooner.
Force gain0 The 0 gain omits sustained directed airspeed loading. Spring resistance remains independent.
Master gain0.65 Scales overall profile strength while preserving effect balance, subject to device and output limits.
Dynamic-pressure blendFalse Allows baseline spring strength to rise with indicated airspeed where the control law permits it.
Minimum spring factor1 Sets low-speed spring strength as a fraction of baseline when blending is enabled. One keeps full strength.
Spring wake-up speed8 ktSets the IAS where the low-speed spring blend starts rising. This is a feel threshold, not a flight limit.
Spring full-strength speed60.0 ktSets the IAS where the low-speed blend reaches baseline strength; high-speed stiffening also uses it.
Force tuning speed120 ktSets the IAS reference for aerodynamic loading. It is an estimate, not published cruise TAS or a flight limit.
Airspeed spring stiffening0 Adds permitted spring resistance above the full-blend speed. Zero removes this high-speed increase.
Airspeed stiffening cap5 Limits the squared airspeed ratio used for high-speed spring stiffening; it is not a device-force cap.
Aileron force scale0.72 Roll and pitch aerodynamic scales are 0.72 and 1, respectively. These stored weights do not create directed aerodynamic loading while that term is inactive. No custom spring-travel curve is enabled.
Elevator force scale1 Scales pitch aerodynamic loading; pitch spring travel and trim responses are separate settings.
Maximum output force0.55 Caps directed-force output. Native spring effects and device limits remain separate.
StickFeel · Trim feel enabledFalse Retained for compatibility and group membership. Trim relief, rather than this flag, controls centre movement.
StickFeel · Trim relief enabledFalse Allows trim relief with supported control law and valid telemetry. Axis authorities set its amount.
StickFeel · Elevator authority0 Scales supported pitch-trim relief and permitted centre movement. Zero removes pitch response.
StickFeel · Aileron authority0 Scales supported roll-trim relief and permitted centre movement. Zero removes roll response.
StickFeel · Force trim enabledFalse Local force trim is distinct from CowanSim's rotor trim and optional HeliSAS procedures; a reset command does not itself provide a physical neutral target. Local force trim is off. The stored latch parameters are inactive; the profile does not supply a local hold-where-left neutral.
StickFeel · G load enabledFalse Allows load-factor changes to modify permitted spring laws. Passive fly-by-wire feel can suppress it.
StickFeel · Rate damping enabledFalse Enables rate damping with the configured coefficients and control law.
Autopilot · Follow enabledFalse Autopilot following is off; the configured spring and load retain the hardware feel.
Autopilot · Follow authority0.05 Sets admitted AP-follow gain, not a percentage of travel. Runtime ownership and input limits still apply.
Autopilot · Neutral hold enabledFalse Permits centering hold during a supported AP state, separate from following a moving target.
Autopilot · Neutral hold strength0.6 Sets admitted AP neutral-hold strength; inactive while neutral hold is disabled.
Aero · EnabledTrue Enables aerodynamic cues; each still needs nonzero strength and its simulator conditions.
Aero · Gain0 Sets stall-buffet strength. Zero removes the cue without changing simulator stalls or warnings.
Aero · Gain0 Sets high-Mach buffet strength; onset and full-strength thresholds are separate.
Aero · Gain0 Sets flap buffet at the configured position and speed gates. Flap movement texture is separate.
Aero · Max flap index1 Sets the final flap index for detent normalization. UP plus three detents uses maximum index3.
Aero · Min flap index1 Sets the first flap detent that admits buffet; this is a handle index, not degrees.
Aero · Gain0 Sets gear aerodynamic buffet; movement and ground-contact cues are separate.
Aero · Shaker enabledFalse Permits shaker at supported warning conditions; the switch does not establish aircraft equipment.
Aero · Amplitude0.5 Sets triggered shaker strength; inactive while the shaker feature is disabled.
Ground · EnabledTrue Enables ground effects; each still needs its own strength and contact or motion telemetry.
Ground · Gain0 Sets rolling texture strength, modified by speed, surface and undercarriage configuration.
Ground · Gain0 Sets gear-bump texture during ground motion, separate from touchdown impact.
Ground · Gain0.5 Sets landing-impact strength; landing telemetry and response shape determine the pulse.
Ground · Gain0 Sets reverse-thrust vibration with valid reverser and engine conditions. Zero removes the cue.
Engine · EnabledTrue Enables engine cues with nonzero settings and valid running-engine telemetry.
Engine · Gain0 Sets estimated engine vibration using configured telemetry and response, not measured cockpit vibration.
Mechanical · EnabledTrue Enables accessory cues with configured strengths and observed accessory movement.
Mechanical · Gain0 Sets texture from observed flap movement; a command without movement does not establish the cue.
Mechanical · Gain0 Sets texture from observed gear movement, separate from aerodynamic and touchdown effects.
Public sources 22
  1. Eurocopter AS350 ÉcureuilResearch background · Wikipedia revision 1373884153 · retrieved 2026-09-12
  2. User ManualExact MSFS aircraft hardware/control manual
  3. CowanSim HeloSAS autopilot manualCowan HeloSAS manual pp.2/5
  4. User ManualExact XP12 manual, title/configuration and trim sections
  5. SAS ManualCowan XP SAS manual pp.1-4
  6. AS350 Garmin GFC 600H Flight Control SystemAirbus H125
  7. Jack Be NimbleAirbus H125
  8. Microsoft Flight Simulator aircraft manuals
  9. MSFS 2024 FAQ and edition aircraft inventory
  10. CowanSim manuals
  11. SAS Manual
  12. X-Plane aircraft and avionics manuals
  13. H125 (AS350B3e) for MSFSOfficial developer / designated store catalogue · checked 2026-09-12
  14. H125 (AS350B3e) for X-PlaneOfficial developer / designated store catalogue · checked 2026-09-12
  15. The H125 at the top of the worldShashwot Dulal interviewed by Heather Couthaud · 8 November 2018
  16. Didier Delsalle’s twentieth-anniversary Everest interviewDidier Delsalle · 14 May 2025
  17. Taming the SquirrelJon Bourke · 2 March 2017; BLR FastFin evaluation
  18. ICAO Doc 8643 — aircraft type designatorsPublic search data retrieved 2026-09-14; authority update 2026-09-03
  19. MSFS 2024 Sim Update 3 release notesPublisher announcement or release notes
  20. Airbus H125 flight manualPrint or archived reference; no public link
  21. EASA TCDS R.008Print or archived reference; no public link
  22. Airbus published dataPrint or archived reference; no public link

Community & corrections

If your time in the type says this page got something wrong, correct it here.

Pilot corrections

Fly this aircraft? Correct this page.

This page is built from cited references, and real time in the type beats a citation. Quote the claim that reads wrong and tell us what the actual aircraft does. Corrections go to the maintainer for review and feed the next revision of this research.

Hangar talk

Open conversation about flying and tuning the Airbus H125, in the community forum. Corrections above go privately to the maintainer; hangar talk is public.

No hangar talk for the Airbus H125 yet. Be the first.

Community

Community profiles for this aircraft

No community profiles for this aircraft yet. Tuned it your way? Share a profile and it will appear here.