A light helicopter launched in 2013
Dynali’s October 2017 release dates the H3 launch to 2013. By that announcement the manufacturer reported more than fifty flying worldwide, with both complete aircraft and kits reaching overseas customers.
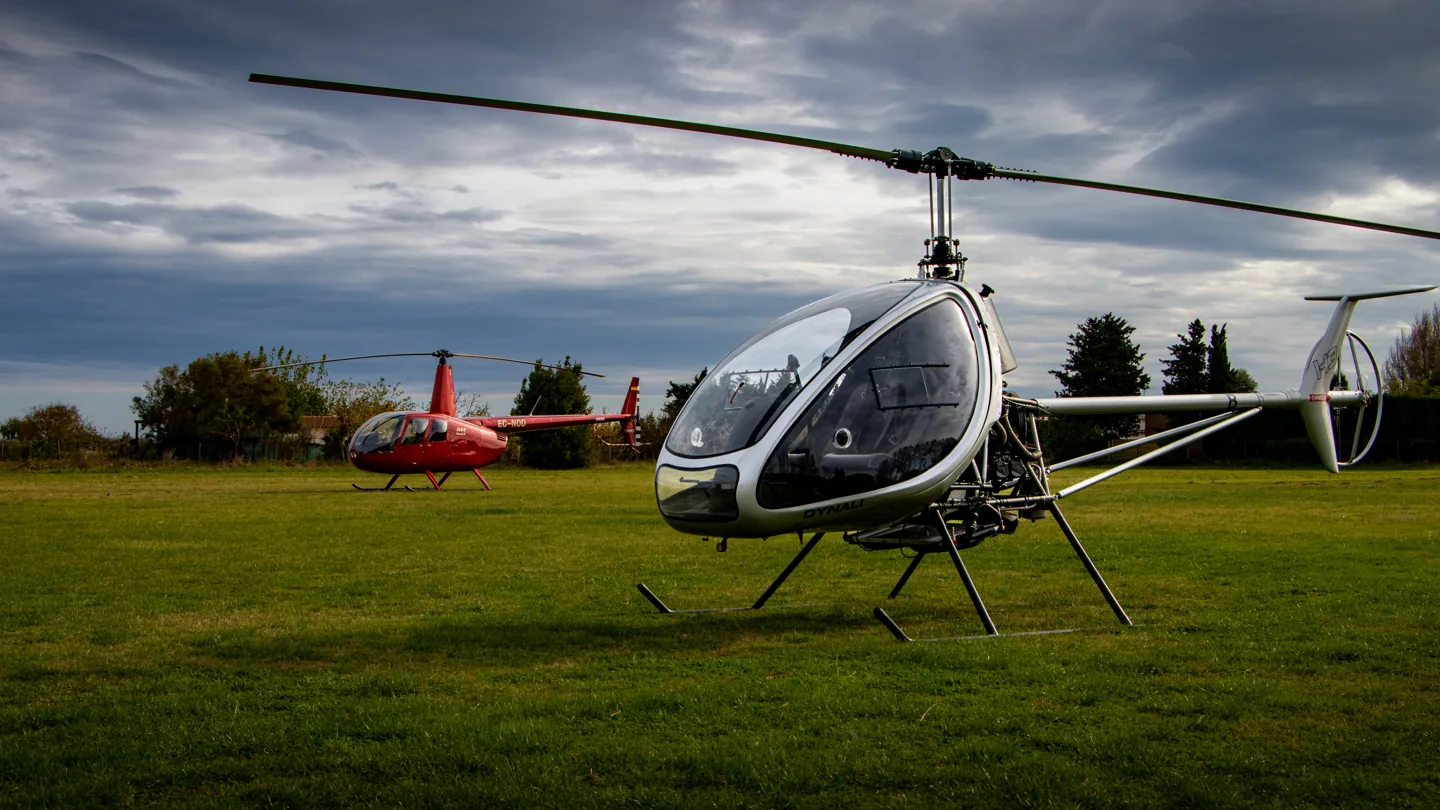 Aeroclubestartit · CC BY-SA 4.0 · Dynali H3.
The Dynali H3 is a compact helicopter offered in ready-to-fly and kit forms. Its side-by-side cabin and conventional tail rotor give it the familiar arrangement of a utility helicopter at a smaller scale.
VSKYLABS includes the classic EasyFlyer and newer Sport versions. Its X-Plane product uses native aircraft systems and supports interaction from a VR cockpit as well as a conventional screen.
Dynali H3 Sport 135 hp configuration
Meer over dit vliegtuig op AirframeDB
Dynali’s October 2017 release dates the H3 launch to 2013. By that announcement the manufacturer reported more than fifty flying worldwide, with both complete aircraft and kits reaching overseas customers.
The first United States-registered H3, N361EX, appeared in October 2017 as an importer’s demonstrator in Cincinnati. The same release described deliveries to South Korea, France and China and an order from New Zealand, illustrating the type’s expansion beyond Belgium.
The H3 Sport pairs its four-blade anti-torque rotor with an automatic clutch and a governor. Dynali describes light control inputs and a cabin 1.30 m wide. The engine is modified for helicopter service, so its 135 hp rating should not be confused with an unmodified Rotax 912 ULS.
The figures here describe the manufacturer’s 135 hp H3 Sport. The Open Air has a different cabin treatment, while simulator packages may also include the earlier EasyFlyer. Match the selected aircraft’s documentation before borrowing weights, equipment or operating details from another version.
The Dynali H3 is a compact helicopter offered in ready-to-fly and kit forms. Its side-by-side cabin and conventional tail rotor give it the familiar arrangement of a utility helicopter at a smaller scale.
This starting point selects Dynali H3. Its aircraft-level settings do not select a particular developer’s custom systems.
The cyclic spring and damping approximate mechanical push-pull controls. Spring resistance builds with the selected airspeed response. A separate aerodynamic term adds speed-dependent control load. Cyclic damping adds resistance to hardware motion.
Governor selection is separate from trim; the acquired controls description does not establish an in-flight trim linkage. Local force trim is off. Autopilot following is off.
Dynali documents push-pull cyclic and collective controls, adjustable friction and a rotor-sensed governor. The governor is an engine/rotor-regulation function. The preserved manufacturer and developer rotor-speed references differ, so they retain their named values and source context.
The gains are normalized profile settings. They describe the chosen effect balance; hand force depends on the device and its output limits. IAS references are tuning values rather than operating limits. Physical acceptance of this revision remains pending.
De uiteindelijke totaalschaal over alles wat het model produceert, vóór de apparaatbegrenzing.
Meer: alles (veer, belastingen, effecten) wordt samen sterker.
Minder: alles wordt samen zachter.
Waarom hier: Scales overall profile strength while preserving effect balance, subject to device and output limits.
De basiscentreerkracht die de stick terug naar het midden trekt. Elke andere kracht stapelt hierop. Te laag en de stick voelt slap in normale vlucht; te hoog en hij vecht tegen je hand en maskeert de kleinere signalen erbovenop.
Meer: een steviger centreren dat de hand meer weerstaat.
Minder: een slappere stick die alleen op aerodynamische belasting leunt.
Waarom hier: The cyclic spring and damping approximate mechanical push-pull controls. The baseline spring is 0. Its low-speed blend reaches baseline strength at 40 KIAS.
Developer POH systems/limitations; Cabri primary PDF110 printed7-4 or R66 section7 PDF9 printed7-7 where applicableDynali H3 EasyFlyer primary POH revision2.5VSKYLABS Aerospace Simulations Aircraft Center: VSKYLABS 'Test-Pilot': Dynali H3VSKYLABS Dynali H3. A High-Definition Ultralight Helicopter Simulation for X-Plane.Een kleine neutrale zone rond het midden waar de veer stil blijft, zodat minieme bewegingen in rust niet ratelen. Breder is rustiger maar losser; smaller is preciezer maar kan rond het midden trillen.
Meer: een rustiger maar losser midden, met meer speling.
Minder: een strakker midden dat in rust kan trillen.
Waarom hier: Sets travel around the centre before the baseline spring resists. Smaller values engage it sooner.
Een masterschaal over beide aangehouden asbelastingen, toegepast vóór hun onafhankelijke balans. Profielen laten dit normaal met rust en stemmen de twee asbelastingen af.
Meer: beide assen laden zwaarder.
Minder: beide assen worden samen lichter.
Waarom hier: The aerodynamic-load gain is 0.35 with an indicated-speed reference of 80 KIAS. This supplies speed-dependent loading alongside the spring.
Schakelt het lage-snelheidsvenster van de veeraangrijping in (start/vol-knopen hierboven). Uit betekent een constante veer op alle snelheden.
Waarom hier: Allows baseline spring strength to rise with indicated airspeed where the control law permits it.
Hoeveel van de veer overleeft bij stilstand, voordat luchtsnelheid aerodynamische kracht kan opbouwen. Een hoge vloer houdt de geparkeerde stick stevig; een lage geeft het losse, kabelslappe gevoel van een geparkeerd licht vliegtuig.
Meer: een stevigere stick geparkeerd en tijdens taxiën.
Minder: een slappe stick geparkeerd die pas met snelheid ontwaakt.
Waarom hier: Sets low-speed spring strength as a fraction of baseline when blending is enabled. One keeps full strength.
De snelheid waarbij de veer vanaf zijn lage-snelheidsvloer richting volle sterkte begint te klimmen: de besturing die 'tot leven komt' tijdens de startrol.
Waarom hier: Sets the IAS where the low-speed spring blend starts rising. This is a feel threshold, not a flight limit.
De snelheid waarbij de veer volle sterkte bereikt. Tussen het begin en dit punt wordt het centreren geleidelijk steviger naarmate de luchtstroom over de roeren groeit.
Waarom hier: Sets the IAS where the low-speed blend reaches baseline strength; high-speed stiffening also uses it.
De aangewezen snelheid waarbij de aerodynamische belasting haar ontworpen volle niveau bereikt. Hij verankert de hele belastingscurve aan het echte snelheidsbereik van het vliegtuig: een 172 laadt op tegen 110 knopen, een jet veel later.
Meer: belastingen komen later; de stick blijft langer licht.
Minder: belastingen komen eerder en de kruisvlucht weegt zwaarder.
Waarom hier: Sets the IAS reference for aerodynamic loading. It is an estimate, not published cruise TAS or a flight limit.
Hoeveel het centreren zelf met snelheid verstijft, bovenop de uitslagbelastingen. Nul houdt het middengevoel constant; meer laat de stick harder centreren op kruissnelheid en losser in het circuit.
Meer: een midden dat duidelijk verhardt met snelheid.
Minder: een constant middengevoel op elke snelheid.
Waarom hier: Adds permitted spring resistance above the full-blend speed. Zero removes this high-speed increase.
De bovengrens van snelheidsgedreven centreerverstijving, zodat zeer snelle vlucht de veer niet onbegrensd kan opwinden.
Meer: meer totale verstijving toegestaan op hoge snelheid.
Minder: de verstijving stopt eerder.
Waarom hier: Limits the squared airspeed ratio used for high-speed spring stiffening; it is not a device-force cap.
De aangehouden rolbelasting uit rolroeruitslag en snelheid, onafhankelijk van pitch gebalanceerd. Samen met de hoogteroerbelasting bepaalt dit de stuurharmonie waar recensenten het over hebben.
Meer: zwaardere rolkrachten.
Minder: lichtere, levendigere rolroeren.
Waarom hier: Roll and pitch aerodynamic scales are 1 and 1, respectively. They set the aerodynamic axis balance. No custom spring-travel curve is enabled.
De aangehouden pitchbelasting uit hoogteroeruitslag en snelheid, onafhankelijk van rol gebalanceerd. Dit is de hoofdhendel achter het pitchgewicht van een type. Hij raakt rolroer-, veer-, trim- of buffetkrachten niet.
Meer: zwaardere aangehouden pitchkrachten op snelheid.
Minder: een lichter hoogteroer, minder spierkracht om vast te houden.
Waarom hier: Scales pitch aerodynamic loading; pitch spring travel and trim responses are separate settings.
Een plafond op elke gestage pitch- of rolkracht voordat die het apparaat bereikt, ter bescherming tegen beuken of verzadigen van de hardware bij stevige manoeuvres.
Meer: hogere gestage krachtpieken vóór afkapping.
Minder: een zachter plafond; harde manoeuvres vlakken eerder af.
Waarom hier: Caps directed-force output. Native spring effects and device limits remain separate.
Hoe sterk hoogteroertrim de vastgehouden pitchkracht verlicht en verschuift waar de stick tot rust komt. Op 100 % heeft een goed getrimd vliegtuig geen vastgehouden druk nodig, de trim-de-last-weg-werkwijze van echt vliegen.
Meer: trim neemt meer vastgehouden kracht weg; op 100 % heft volle trim hem op.
Minder: je blijft kracht houden, zelfs getrimd.
Waarom hier: Scales supported pitch-trim relief and permitted centre movement. Zero removes pitch response.
Dezelfde verlichting voor roltrim. De meeste GA-types hebben geen echte rolroertrim, dus dit blijft op nul; types met roltrim krijgen een passende waarde.
Meer: roltrim neemt meer vastgehouden kracht weg.
Minder: roltrim doet minder.
Waarom hier: Scales supported roll-trim relief and permitted centre movement. Zero removes roll response.
Rollende oppervlaktetrilling uit wielsnelheid en ondergrondtype: asfalt, gras of grind onder het onderstel.
Meer: een sterkere oppervlaktetextuur in de stick.
Minder: gladder taxiën.
Waarom hier: Sets rolling texture strength, modified by speed, surface and undercarriage configuration.
Korte losse stoten van uitzetvoegen, sporen en ruw oppervlak, die het doorlopende gerommel accentueren.
Meer: scherpere stoten van voegen en sporen.
Minder: zachtere gronddetails.
Waarom hier: Sets gear-bump texture during ground motion, separate from touchdown impact.
Casco-schudden bij het naderen van de overtrek en terwijl de overtrekwaarschuwing actief is: hoe luid deze vleugel aankondigt dat hij ontevreden is. Types met een scherpe afbreek krijgen bescheiden buffet en laten de hoorn de waarschuwing dragen.
Meer: een sterker trillen vóór de overtrek.
Minder: een discretere vleugel; de hoorn draagt de waarschuwing.
Waarom hier: Sets stall-buffet strength. Zero removes the cue without changing simulator stalls or warnings.
Transsoon buffet bij het naderen van de Machlimiet. Betekenisvol voor jets nabij MMO, nul voor zuigers en turboprops die er nooit komen.
Meer: een sterker transsoon buffet nabij de Machlimiet.
Minder: gladder vliegen op hoge Mach.
Waarom hier: Sets high-Mach buffet strength; onset and full-strength thresholds are separate.
Laagfrequente casco-trilling met kleppen uitgeslagen in de luchtstroom, in het snelheidsvenster waar ze de lucht echt bewerken.
Meer: ruwer vliegen met werkende kleppen.
Minder: zachtere naderingskleppen.
Waarom hier: Sets flap buffet at the configured position and speed gates. Flap movement texture is separate.
Casco-getrommel van intrekbaar onderstel dat in de luchtstroom hangt. Nul voor types met vast onderstel, waar het casco nooit van vorm verandert.
Meer: meer getrommel met het onderstel uit.
Minder: schoner vliegen met onderstel uit.
Waarom hier: Sets gear aerodynamic buffet; movement and ground-contact cues are separate.
De speciale stall-stickshakerzoem, geactiveerd door het eigen overtrekwaarschuwingssysteem van het vliegtuig. Alleen types met een echte shaker krijgen een waarde; de rest steunt op aerodynamisch buffet en de hoorn.
Meer: een hardere shaker.
Minder: een discretere shaker.
Waarom hier: Sets triggered shaker strength; inactive while the shaker feature is disabled.
De eenmalige dreun als de wielen de baan raken, geschaald op daalsnelheid: een zachte landing fluistert, een stevige aankomst bonkt.
Meer: een hardere dreun bij de landing.
Minder: zachtere aankomsten.
Waarom hier: Sets landing-impact strength; landing telemetry and response shape determine the pulse.
Uitroltrilling terwijl reverse thrust of props in beta werken. Nul voor types zonder reverse.
Meer: ruwer uitrollen onder reverse.
Minder: een discretere reverse.
Waarom hier: Sets reverse-thrust vibration with valid reverser and engine conditions. Zero removes the cue.
Doorlopende motortrilling die het toerental volgt tussen stationair en vol vermogen, de altijd aanwezige herinnering dat er voorin iets brandstof verbrandt.
Meer: meer motor in de stick.
Minder: een discretere motor.
Waarom hier: Sets estimated engine vibration using configured telemetry and response, not measured cockpit vibration.
Doorlopende trilling alleen terwijl de sim meldt dat de klepvlakken daadwerkelijk bewegen. Volgt echte actuatorbeweging en storingen, geen geschatte timer.
Meer: meer trilling met bewegende kleppen.
Minder: discretere klepbewegingen.
Waarom hier: Sets texture from observed flap movement; a command without movement does not establish the cue.
Hoe ver autopilootcommando's de stick fysiek mogen bewegen. Piepklein gehouden in MSFS, waar een bewogen as kan worden teruggelezen als pilooteninvoer; nul schakelt volgen volledig uit.
Meer: de autopiloot beweegt je stick zichtbaar meer.
Minder: een nauwelijks merkbaar volgen.
Waarom hier: Sets admitted AP-follow gain, not a percentage of travel. Runtime ownership and input limits still apply.
Whether this feature is active in this profile.
Waarom hier: Retained for compatibility and group membership. Trim relief, rather than this flag, controls centre movement.
Whether this feature is active in this profile.
Waarom hier: Allows trim relief with supported control law and valid telemetry. Axis authorities set its amount.
Whether this feature is active in this profile.
Waarom hier: Governor selection is separate from trim; the acquired controls description does not establish an in-flight trim linkage. Local force trim is off. The stored latch parameters are inactive; the profile does not supply a local hold-where-left neutral.
Developer POH systems/limitations; Cabri primary PDF110 printed7-4 or R66 section7 PDF9 printed7-7 where applicableDynali H3 EasyFlyer primary POH revision2.5VSKYLABS Aerospace Simulations Aircraft Center: VSKYLABS 'Test-Pilot': Dynali H3VSKYLABS Dynali H3. A High-Definition Ultralight Helicopter Simulation for X-Plane.Whether this feature is active in this profile.
Waarom hier: Allows load-factor changes to modify permitted spring laws. Passive fly-by-wire feel can suppress it.
Whether this feature is active in this profile.
Waarom hier: Enables rate damping with the configured coefficients and control law.
Whether this feature is active in this profile.
Waarom hier: Autopilot following is off; the configured spring and load retain the hardware feel.
Whether this feature is active in this profile.
Waarom hier: Permits centering hold during a supported AP state, separate from following a moving target.
Waarom hier: Sets admitted AP neutral-hold strength; inactive while neutral hold is disabled.
Whether this feature is active in this profile.
Waarom hier: Enables aerodynamic cues; each still needs nonzero strength and its simulator conditions.
Where this effect reaches full strength (or has fully faded, for washouts).
Meer: a more gradual build to a later peak.
Minder: a quicker build.
Waarom hier: Sets the final flap index for detent normalization. UP plus three detents uses maximum index3.
Where this effect begins fading in.
Meer: the effect begins later.
Minder: it begins earlier.
Waarom hier: Sets the first flap detent that admits buffet; this is a handle index, not degrees.
Whether this feature is active in this profile.
Waarom hier: Permits shaker at supported warning conditions; the switch does not establish aircraft equipment.
Whether this feature is active in this profile.
Waarom hier: Enables ground effects; each still needs its own strength and contact or motion telemetry.
Whether this feature is active in this profile.
Waarom hier: Enables engine cues with nonzero settings and valid running-engine telemetry.
Whether this feature is active in this profile.
Waarom hier: Enables accessory cues with configured strengths and observed accessory movement.
The strength of this effect.
Meer: a stronger effect.
Minder: a weaker one.
Waarom hier: Sets texture from observed gear movement, separate from aerodynamic and touchdown effects.
| Parameter | Waarde | Wat het regelt en waarom |
|---|---|---|
| Spring strength | 0 | The cyclic spring and damping approximate mechanical push-pull controls. The baseline spring is 0. Its low-speed blend reaches baseline strength at 40 KIAS. |
| Spring deadband | 0.02 | Sets travel around the centre before the baseline spring resists. Smaller values engage it sooner. |
| Force gain | 0.35 | The aerodynamic-load gain is 0.35 with an indicated-speed reference of 80 KIAS. This supplies speed-dependent loading alongside the spring. |
| Master gain | 0.85 | Scales overall profile strength while preserving effect balance, subject to device and output limits. |
| Dynamic-pressure blend | True | Allows baseline spring strength to rise with indicated airspeed where the control law permits it. |
| Minimum spring factor | 1 | Sets low-speed spring strength as a fraction of baseline when blending is enabled. One keeps full strength. |
| Spring wake-up speed | 11.2 kt | Sets the IAS where the low-speed spring blend starts rising. This is a feel threshold, not a flight limit. |
| Spring full-strength speed | 40.0 kt | Sets the IAS where the low-speed blend reaches baseline strength; high-speed stiffening also uses it. |
| Snelheid voor krachtafstemming | 80.0 kt | Sets the IAS reference for aerodynamic loading. It is an estimate, not published cruise TAS or a flight limit. |
| Airspeed spring stiffening | 0 | Adds permitted spring resistance above the full-blend speed. Zero removes this high-speed increase. |
| Airspeed stiffening cap | 5 | Limits the squared airspeed ratio used for high-speed spring stiffening; it is not a device-force cap. |
| Aileron force scale | 1 | Roll and pitch aerodynamic scales are 1 and 1, respectively. They set the aerodynamic axis balance. No custom spring-travel curve is enabled. |
| Elevator force scale | 1 | Scales pitch aerodynamic loading; pitch spring travel and trim responses are separate settings. |
| Maximum output force | 0.55 | Caps directed-force output. Native spring effects and device limits remain separate. |
| StickFeel · Trim feel enabled | False | Retained for compatibility and group membership. Trim relief, rather than this flag, controls centre movement. |
| StickFeel · Trim relief enabled | False | Allows trim relief with supported control law and valid telemetry. Axis authorities set its amount. |
| StickFeel · Elevator authority | 0.3 | Scales supported pitch-trim relief and permitted centre movement. Zero removes pitch response. |
| StickFeel · Aileron authority | 0.3 | Scales supported roll-trim relief and permitted centre movement. Zero removes roll response. |
| StickFeel · Force trim enabled | False | Governor selection is separate from trim; the acquired controls description does not establish an in-flight trim linkage. Local force trim is off. The stored latch parameters are inactive; the profile does not supply a local hold-where-left neutral. |
| StickFeel · G load enabled | False | Allows load-factor changes to modify permitted spring laws. Passive fly-by-wire feel can suppress it. |
| StickFeel · Rate damping enabled | True | Enables rate damping with the configured coefficients and control law. |
| Autopilot · Follow enabled | False | Autopilot following is off; the configured spring and load retain the hardware feel. |
| Autopilot · Follow authority | 0.05 | Sets admitted AP-follow gain, not a percentage of travel. Runtime ownership and input limits still apply. |
| Autopilot · Neutral hold enabled | False | Permits centering hold during a supported AP state, separate from following a moving target. |
| Autopilot · Neutral hold strength | 0.6 | Sets admitted AP neutral-hold strength; inactive while neutral hold is disabled. |
| Aero · Enabled | True | Enables aerodynamic cues; each still needs nonzero strength and its simulator conditions. |
| Aero · Gain | 0 | Sets stall-buffet strength. Zero removes the cue without changing simulator stalls or warnings. |
| Aero · Gain | 0 | Sets high-Mach buffet strength; onset and full-strength thresholds are separate. |
| Aero · Gain | 0 | Sets flap buffet at the configured position and speed gates. Flap movement texture is separate. |
| Aero · Max flap index | 1 | Sets the final flap index for detent normalization. UP plus three detents uses maximum index3. |
| Aero · Min flap index | 1 | Sets the first flap detent that admits buffet; this is a handle index, not degrees. |
| Aero · Gain | 0 | Sets gear aerodynamic buffet; movement and ground-contact cues are separate. |
| Aero · Shaker enabled | False | Permits shaker at supported warning conditions; the switch does not establish aircraft equipment. |
| Aero · Amplitude | 0.5 | Sets triggered shaker strength; inactive while the shaker feature is disabled. |
| Ground · Enabled | True | Enables ground effects; each still needs its own strength and contact or motion telemetry. |
| Ground · Gain | 0 | Sets rolling texture strength, modified by speed, surface and undercarriage configuration. |
| Ground · Gain | 0 | Sets gear-bump texture during ground motion, separate from touchdown impact. |
| Ground · Gain | 0.5 | Sets landing-impact strength; landing telemetry and response shape determine the pulse. |
| Ground · Gain | 0 | Sets reverse-thrust vibration with valid reverser and engine conditions. Zero removes the cue. |
| Engine · Enabled | True | Enables engine cues with nonzero settings and valid running-engine telemetry. |
| Engine · Gain | 0.12 | Sets estimated engine vibration using configured telemetry and response, not measured cockpit vibration. |
| Mechanical · Enabled | True | Enables accessory cues with configured strengths and observed accessory movement. |
| Mechanical · Gain | 0 | Sets texture from observed flap movement; a command without movement does not establish the cue. |
| Mechanical · Gain | 0 | Sets texture from observed gear movement, separate from aerodynamic and touchdown effects. |
Zegt jouw ervaring op het type dat deze pagina iets fout heeft? Corrigeer het hier.
Deze pagina is gebouwd op geciteerde bronnen, en echte ervaring op het type verslaat elke bron. Citeer de foute bewering en vertel ons wat het echte toestel doet. Correcties gaan ter beoordeling naar de maintainer en voeden de volgende revisie van dit onderzoek.
Open gesprek over het vliegen en afstellen van de Dynali H3, op het communityforum. Correcties hierboven gaan privé naar de maintainer; hangarpraat is openbaar.