Libreria dei velivoliEurocopter EC135
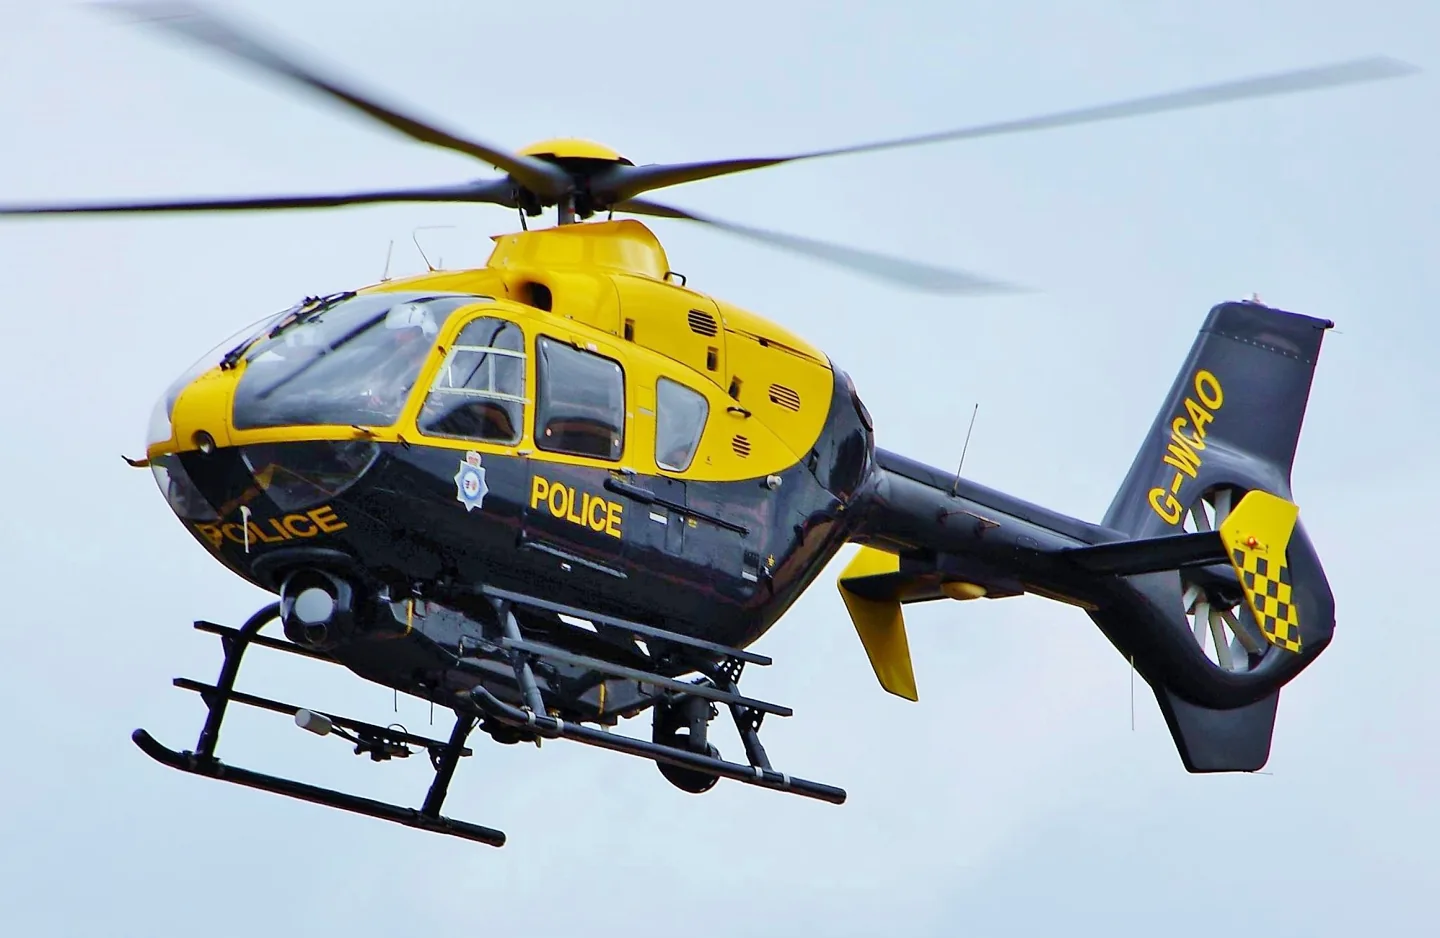
Eurocopter EC135Tim Felce (Airwolfhound) · CC BY-SA 2.0 · Eurocopter EC135 pictured

Eurocopter EC135

A compact twin-engine helicopter widely used for medical, police and training work.
Helicopter3 opzioni di profilo

Conosci l'aereo

The EC135, later renamed H135, developed from the MBB Bo 108 programme. Its enclosed tail rotor, twin turbines and practical cabin made it a useful platform for emergency services and other operators. The type first flew in 1994 and entered service in 1996.

The H135 name covers later development of the same lineage. Mission interiors, avionics and flight-control equipment differ between operators and versions. The photograph depicts a medical installation; simulator documentation identifies the included mission equipment.

Aircraft / family

Propulsion
Twin turboshaft↗
Configuration
Utility / medical / training↗

Eurocopter EC135 · Specifications (EC135 P2+/T2+) · real aircraft; source units retained

Length
10.2 m (33 ft 6 in)↗
Height
3.51 m (11 ft 6 in)↗
Empty weight
1,455 kg (3,208 lb)↗
Max takeoff weight
2,910 kg (6,415 lb)↗
Powerplant
2 × Turbomeca Arrius 2B2 turboshaft engines, 472 kW (633 hp) each or 2 × Pratt & Whitney Canada PW206B turboshaft engines rated at 463 kW (621 hp) (take-off power)↗
Main rotor diameter
10.2 m (33 ft 6 in)↗
Main rotor area
81.7 m² (879 sq ft)↗
Cruise speed
254 km/h (158 mph, 137 kn)↗
Range
635 km (395 mi, 343 nmi)↗
Service ceiling
6,096 m (20,000 ft)↗

Scopri di più su questo aeromobile su AirframeDB

The H135 changes its cockpit while retaining its identity

Duke’s 2017 report places Helionix after the earlier P3/T3 performance improvements. His evaluation deliberately concentrates on displays and automation, distinguishing a cockpit transition from a new engine or increased carrying capacity.

A simulator developer discovers what hovering feels like

Meyer’s visit began with measurements on the ground for an X-Plane project. Flying the real EC135 was the next step, and he was conscious that his own experience was in aeroplanes. The glass surrounding the cockpit made the view both spectacular and slightly unsettling as the chief pilot introduced him to the aircraft.

Once given the controls, he found forward flight manageable but hovering much more demanding. The instructor intervened when the aircraft’s motion exceeded Meyer’s ability to contain it, then gave him further opportunities to try. He came away with aching hands, excitement and observations he wanted to bring back to the simulator. His exuberant account is a personal learning experience; its explanations and claims about simulator transfer are not independent validation of a flight model.

Learning to trust a quieter instrument scan

Duke wanted to understand what the new displays and automation added to an established helicopter. During the brief start, Neuhaus explained a cockpit that brought abnormal trends to the pilot’s attention instead of requiring constant checks of scattered gauges. Duke had to adjust to the absence of familiar indications before appreciating the spare attention it created.

The flight included a confined-area approach and experiments with different levels of autopilot assistance. The display was easy to interpret, but Duke remained cautious about judging tail clearance through a camera image. An automated approach completed the return to Donauwörth. His evaluation focuses on how the pilot interacts with the equipment, preserving both the features he enjoyed and the particular task for which he preferred a more cautious judgment.

Trying the updated helicopter at its intended test weight

Gray arrived curious about how far the EC135 family had developed since the magazine’s earlier evaluation. The team planned the fuel load so that his first hover would take place at the intended maximum weight despite time spent briefing on the ground. Even accepting the aircraft involved a detail he appreciated: an electronic system linking the pilot’s acceptance to the technician’s sign-off.

In flight, Gray tried the handling and followed Neuhaus through more energetic manoeuvres. He found the power indications easy to interpret and the cockpit comfortable to work in. The return demonstrated an automated approach and hover before Gray took control for the landing. His overall impression was of considerable complexity made accessible to the pilot. The report did not include an autorotation or a passenger-cabin evaluation.

Fonti pubbliche 10
  1. Eurocopter EC135Research background · Wikipedia revision 1373321906 · retrieved 2026-09-12
  2. Microsoft Flight Simulator aircraft manuals
  3. EC135 free for MSFS 2024 owners
  4. H135 freewareOfficial developer / designated store catalogue · checked 2026-09-12
  5. The Magical FishbowlAustin Meyer · July 2002
  6. Glass of its Own: H135Jon Duke · 21 July 2017
  7. Continually improvingPeter Gray · 29 November–5 December 2016; archived magazine pages
  8. ICAO Doc 8643 — aircraft type designatorsPublic search data retrieved 2026-09-14; authority update 2026-09-03
  9. Airbus H135 v1.4 release notesSteve Daniels · 26 July 2021Product listing captured 2026-09-30; edition scope from the reviewed catalogue
  10. rotorsim – Das Portal für die HubschraubersimulationProduct listing captured 2026-09-23; edition scope from the reviewed catalogue

Come il profilo lo modella

HPG H135

Free + Pro
MSFS 2020HPG

The EC135, later renamed H135, developed from the MBB Bo 108 programme. Its enclosed tail rotor, twin turbines and practical cabin made it a useful platform for emergency services and other operators. The type first flew in 1994 and entered service in 1996.

This profile selects HPG H135 for MSFS 2020.

The cyclic response works around an aircraft-owned neutral where the integration provides it. The spring stays independent of airspeed. Directed aerodynamic loading is omitted. Cyclic damping adds resistance to hardware motion.

Plugin-written trim describes the control neutral, separately from AP engagement. Local force trim is off. Autopilot following is off.

Questa revisione esatta non è ancora abilitata per l’installazione pubblica.

The selected implementation

HPG’s build447 documentation says vertical-speed mode is unsupported despite its engagement display.

H135 build447 guide based on HPG guide

About the values

The gains are normalized profile settings. They describe the chosen effect balance; hand force depends on the device and its output limits. IAS references are tuning values rather than operating limits. Physical acceptance of this revision remains pending.

Master gain & control system

Master gain65%

La scala finale complessiva applicata a tutto ciò che il modello produce, prima del limite del dispositivo.

Più: tutto (molla, carichi, effetti) si rafforza insieme.

Meno: tutto si ammorbidisce insieme.

Perché qui: Scales overall profile strength while preserving effect balance, subject to device and output limits.

Forces

Spring strength10%

La forza di centraggio di base che riporta la barra al centro. Ogni altra forza si somma a questa. Troppo bassa e la barra sembra molle in volo normale; troppo alta e combatte la mano, mascherando i segnali più piccoli sovrapposti.

Più: un centraggio più fermo che resiste di più alla mano.

Meno: una barra più molle che conta solo sul carico aerodinamico.

Perché qui: The cyclic response works around an aircraft-owned neutral where the integration provides it. The baseline spring is 0.1. Low-speed spring blending is off.

H135 build447 guide based on HPG guidewww.rotorsim.deDeveloper controls, versions and configuration documentationDeveloper controls, versions and configuration documentationDeveloper controls, versions and configuration documentationDeveloper controls, versions and configuration documentationPublished EC135 MOZA preset, location from supplied updater configuration and installation guideOfficial dataref catalog JSONEC135 original updater skunkcrafts_updater.cfgEC1355.36 original plugins/ec135/lin.xplEC1355.36 original plugins/ec135/win.xplEC135 published original file CRCsAirbus H135 v1.4 release notesH135 freeware
Spring deadband2%

Una piccola zona neutra attorno al centro dove la molla resta silenziosa, così i micro-movimenti a riposo non vibrano. Più larga è più tranquilla ma più lasca; più stretta è più precisa ma può fremere attorno al centro.

Più: un centro più calmo ma più lasco, con più gioco.

Meno: un centro più serrato che può fremere a riposo.

Perché qui: Sets travel around the centre before the baseline spring resists. Smaller values engage it sooner.

Overall aerodynamic load0%

Una scala maestra su entrambi i carichi d'asse sostenuti, applicata prima del loro bilanciamento indipendente. Di norma i profili la lasciano stare e regolano i due carichi d'asse.

Più: entrambi gli assi caricano più forte.

Meno: entrambi gli assi si alleggeriscono insieme.

Perché qui: The 0 gain omits sustained directed airspeed loading. Spring resistance remains independent.

Airspeed blendingFalse

Attiva la finestra di innesto della molla a bassa velocità (nodi di inizio/pieno qui sopra). Spento, la molla è costante a ogni velocità.

Perché qui: Allows baseline spring strength to rise with indicated airspeed where the control law permits it.

Low-speed spring floor50%

Quanta molla sopravvive da fermo, prima che la velocità possa generare forza aerodinamica. Un pavimento alto tiene salda la barra parcheggiata; uno basso dà la sensazione lasca, da cavi allentati, di un aereo leggero in sosta.

Più: una barra più salda in sosta e al rullaggio.

Meno: una barra molle da fermo che si sveglia solo con la velocità.

Perché qui: Sets low-speed spring strength as a fraction of baseline when blending is enabled. One keeps full strength.

Spring engagement start8 kt

La velocità a cui la molla comincia a salire dal suo pavimento di bassa velocità verso la piena forza: i comandi che «prendono vita» in corsa di decollo.

Perché qui: Sets the IAS where the low-speed spring blend starts rising. This is a feel threshold, not a flight limit.

Spring engagement full55.0 kt

La velocità a cui la molla raggiunge la piena forza. Tra l'inizio e questo punto il centraggio si irrigidisce progressivamente man mano che il flusso cresce sui comandi.

Perché qui: Sets the IAS where the low-speed blend reaches baseline strength; high-speed stiffening also uses it.

Velocità di regolazione della forza110

La velocità indicata a cui il carico aerodinamico raggiunge il livello pieno di progetto. Ancora l'intera curva di carico al reale intervallo di velocità dell'aereo: un 172 carica verso 110 nodi, un jet molto più tardi.

Più: i carichi arrivano più tardi; la barra resta leggera fino a velocità più alte.

Meno: i carichi arrivano prima e la crociera pesa di più.

Perché qui: Sets the IAS reference for aerodynamic loading. It is an estimate, not published cruise TAS or a flight limit.

Centre firmness vs speed0%

Quanto il centraggio stesso si irrigidisce con la velocità, oltre ai carichi da deflessione. Zero mantiene costante la sensazione del centro; di più fa centrare la barra più dura in crociera e più lasca in circuito.

Più: un centro che si indurisce nettamente con la velocità.

Meno: una sensazione di centro costante a ogni velocità.

Perché qui: Adds permitted spring resistance above the full-blend speed. Zero removes this high-speed increase.

Centre stiffening cap5

Il limite superiore all'irrigidimento del centro dovuto alla velocità, così il volo molto veloce non può caricare la molla senza limite.

Più: più irrigidimento totale concesso ad alta velocità.

Meno: l'irrigidimento si ferma prima.

Perché qui: Limits the squared airspeed ratio used for high-speed spring stiffening; it is not a device-force cap.

Aileron load100%

Il carico sostenuto di rollio da deflessione degli alettoni e velocità, bilanciato indipendentemente dal beccheggio. Insieme al carico dell'equilibratore fissa il rapporto di armonia dei comandi di cui parlano le recensioni.

Più: sforzi di rollio più pesanti.

Meno: alettoni più leggeri e scattanti.

Perché qui: Roll and pitch aerodynamic scales are 1 and 1, respectively. These stored weights do not create directed aerodynamic loading while that term is inactive. No custom spring-travel curve is enabled.

Elevator load100%

Il carico sostenuto di beccheggio da deflessione dell'equilibratore e velocità, bilanciato indipendentemente dal rollio. È la leva principale dietro il peso di beccheggio di un tipo. Non tocca alettoni, molla, trim né forze di buffet.

Più: sforzi di beccheggio sostenuti più pesanti in velocità.

Meno: una profondità più leggera, meno muscolosa da tenere.

Perché qui: Scales pitch aerodynamic loading; pitch spring travel and trim responses are separate settings.

Max output force55%

Un tetto su ogni forza stabile di beccheggio o rollio prima che raggiunga il dispositivo, a protezione da colpi o saturazioni dell'hardware nelle manovre energiche.

Più: picchi di forza stabile più alti prima del taglio.

Meno: un tetto più morbido; le manovre dure si appiattiscono prima.

Perché qui: Caps directed-force output. Native spring effects and device limits remain separate.

Trim

Trim relief (elevator)0%

Quanto il trim di profondità allevia lo sforzo di beccheggio mantenuto e sposta dove la barra si assesta. Al 100 %, un aereo trimmato bene non richiede pressione mantenuta: il flusso di lavoro trimma-via-il-carico del volo reale.

Più: il trim toglie più sforzo mantenuto; al 100 %, trim pieno lo annulla.

Meno: continui a tenere sforzo anche trimmato.

Perché qui: Scales supported pitch-trim relief and permitted centre movement. Zero removes pitch response.

Trim relief (aileron)0%

Lo stesso sollievo per il trim di rollio. La maggior parte dei tipi di aviazione generale non ha un vero trim degli alettoni, quindi resta a zero; i tipi con trim di rollio ricevono un valore corrispondente.

Più: il trim di rollio toglie più sforzo mantenuto.

Meno: il trim di rollio fa meno.

Perché qui: Scales supported roll-trim relief and permitted centre movement. Zero removes roll response.

Effect gains · Ground

Runway rumble0%

Vibrazione di rotolamento da velocità delle ruote e tipo di superficie: asfalto, erba o ghiaia sotto il carrello.

Più: una texture di superficie più forte nella barra.

Meno: un rullaggio più liscio.

Perché qui: Sets rolling texture strength, modified by speed, surface and undercarriage configuration.

Gear bumps0%

Colpi brevi e discreti da giunti di dilatazione, solchi e superficie irregolare, che punteggiano il rombo continuo.

Più: colpi più netti da giunti e solchi.

Meno: dettagli del suolo più morbidi.

Perché qui: Sets gear-bump texture during ground motion, separate from touchdown impact.

Effect gains · Airframe

Stall buffet0%

Scuotimento della cellula in avvicinamento allo stallo e con l'avviso attivo: quanto forte quest'ala annuncia di essere scontenta. I tipi con distacco netto ricevono buffet modesto e lasciano l'avviso alla sirena.

Più: un tremito pre-stallo più forte.

Meno: un'ala più discreta; la sirena porta l'avviso.

Perché qui: Sets stall-buffet strength. Zero removes the cue without changing simulator stalls or warnings.

Mach buffet0%

Buffet transonico in avvicinamento al limite di Mach. Significativo per i jet vicino a MMO, zero per pistoni e turboelica che non ci arrivano mai.

Più: un buffet transonico più forte vicino al limite di Mach.

Meno: un volo più liscio ad alto Mach.

Perché qui: Sets high-Mach buffet strength; onset and full-strength thresholds are separate.

Flap buffet0%

Vibrazione a bassa frequenza della cellula con i flap estesi nel flusso, nella finestra di velocità in cui lavorano davvero l'aria.

Più: un volo più ruvido con i flap al lavoro.

Meno: flap d'avvicinamento più morbidi.

Perché qui: Sets flap buffet at the configured position and speed gates. Flap movement texture is separate.

Gear buffet0%

Il tambureggiare della cellula per il carrello retrattile appeso nel flusso. Zero per i tipi a carrello fisso, dove la cellula non cambia mai forma.

Più: più tambureggiare col carrello fuori.

Meno: un volo col carrello fuori più pulito.

Perché qui: Sets gear aerodynamic buffet; movement and ground-contact cues are separate.

Stick shaker50%

Il ronzio dedicato dello stick shaker di stallo, attivato dal sistema di avviso dell'aereo stesso. Solo i tipi con un vero shaker ricevono un valore; tutti gli altri si affidano al buffet aerodinamico e alla sirena.

Più: uno shaker più duro.

Meno: uno shaker più discreto.

Perché qui: Sets triggered shaker strength; inactive while the shaker feature is disabled.

Effect gains · Engine, mechanical & drag

Touchdown thump20%

Il colpo singolo quando le ruote toccano la pista, scalato dal rateo di discesa: un atterraggio di velluto sussurra, un arrivo deciso batte.

Più: un colpo più duro al contatto.

Meno: arrivi più morbidi.

Perché qui: Sets landing-impact strength; landing telemetry and response shape determine the pulse.

Reverse rumble0%

Vibrazione in corsa mentre lavorano l'inversione di spinta o le eliche in beta. Zero per i tipi senza reverse.

Più: una corsa più ruvida in reverse.

Meno: una reverse più discreta.

Perché qui: Sets reverse-thrust vibration with valid reverser and engine conditions. Zero removes the cue.

Engine rumble0%

Vibrazione continua del propulsore che segue i giri tra minimo e piena potenza, il promemoria sempre presente che qualcosa brucia carburante davanti.

Più: più motore nella barra.

Meno: un motore più discreto.

Perché qui: Sets estimated engine vibration using configured telemetry and response, not measured cockpit vibration.

Flap motion0%

Vibrazione continua solo mentre il simulatore riporta le superfici dei flap davvero in movimento. Segue il moto reale dell'attuatore e i guasti, non un timer stimato.

Più: più vibrazione coi flap in movimento.

Meno: corse dei flap più discrete.

Perché qui: Sets texture from observed flap movement; a command without movement does not establish the cue.

Autopilot follow

AP follow authority10%

Quanto i comandi dell'autopilota possono muovere fisicamente la barra. Tenuto minuscolo in MSFS, dove un asse mosso può essere riletto come ingresso del pilota; zero disattiva del tutto il seguito.

Più: l'autopilota muove visibilmente di più la tua barra.

Meno: un seguito appena percettibile.

Perché qui: Sets admitted AP-follow gain, not a percentage of travel. Runtime ownership and input limits still apply.

Stick feel

StickFeel · Trim feel enabledFalse

Whether this feature is active in this profile.

Perché qui: Retained for compatibility and group membership. Trim relief, rather than this flag, controls centre movement.

StickFeel · Trim relief enabledFalse

Whether this feature is active in this profile.

Perché qui: Allows trim relief with supported control law and valid telemetry. Axis authorities set its amount.

StickFeel · Force trim enabledFalse

Whether this feature is active in this profile.

Perché qui: Plugin-written trim describes the control neutral, separately from AP engagement. Local force trim is off. The stored latch parameters are inactive; the profile does not supply a local hold-where-left neutral.

H135 build447 guide based on HPG guidewww.rotorsim.deDeveloper controls, versions and configuration documentationDeveloper controls, versions and configuration documentationDeveloper controls, versions and configuration documentationDeveloper controls, versions and configuration documentationPublished EC135 MOZA preset, location from supplied updater configuration and installation guideOfficial dataref catalog JSONEC135 original updater skunkcrafts_updater.cfgEC1355.36 original plugins/ec135/lin.xplEC1355.36 original plugins/ec135/win.xplEC135 published original file CRCsAirbus H135 v1.4 release notesH135 freeware
StickFeel · G load enabledFalse

Whether this feature is active in this profile.

Perché qui: Allows load-factor changes to modify permitted spring laws. Passive fly-by-wire feel can suppress it.

StickFeel · Rate damping enabledFalse

Whether this feature is active in this profile.

Perché qui: Enables rate damping with the configured coefficients and control law.

Autopilot

Autopilot · Follow enabledFalse

Whether this feature is active in this profile.

Perché qui: Autopilot following is off; the configured spring and load retain the hardware feel.

Autopilot · Neutral hold enabledFalse

Whether this feature is active in this profile.

Perché qui: Permits centering hold during a supported AP state, separate from following a moving target.

Autopilot · Neutral hold strength0.6

Perché qui: Sets admitted AP neutral-hold strength; inactive while neutral hold is disabled.

Aero

Aero · EnabledTrue

Whether this feature is active in this profile.

Perché qui: Enables aerodynamic cues; each still needs nonzero strength and its simulator conditions.

Aero · Max flap index3

Where this effect reaches full strength (or has fully faded, for washouts).

Più: a more gradual build to a later peak.

Meno: a quicker build.

Perché qui: Sets the final flap index for detent normalization. UP plus three detents uses maximum index3.

Aero · Min flap index2

Where this effect begins fading in.

Più: the effect begins later.

Meno: it begins earlier.

Perché qui: Sets the first flap detent that admits buffet; this is a handle index, not degrees.

Aero · Shaker enabledFalse

Whether this feature is active in this profile.

Perché qui: Permits shaker at supported warning conditions; the switch does not establish aircraft equipment.

Ground

Ground · EnabledTrue

Whether this feature is active in this profile.

Perché qui: Enables ground effects; each still needs its own strength and contact or motion telemetry.

Engine

Engine · EnabledFalse

Whether this feature is active in this profile.

Perché qui: Enables engine cues with nonzero settings and valid running-engine telemetry.

Mechanical

Mechanical · EnabledTrue

Whether this feature is active in this profile.

Perché qui: Enables accessory cues with configured strengths and observed accessory movement.

Mechanical · Gain0

The strength of this effect.

Più: a stronger effect.

Meno: a weaker one.

Perché qui: Sets texture from observed gear movement, separate from aerodynamic and touchdown effects.

Tutte le impostazioni del profilo
Impostazioni stimate del profilo
ParametroValoreCosa controlla e perché
Spring strength0.1 The cyclic response works around an aircraft-owned neutral where the integration provides it. The baseline spring is 0.1. Low-speed spring blending is off.
Spring deadband0.02 Sets travel around the centre before the baseline spring resists. Smaller values engage it sooner.
Force gain0 The 0 gain omits sustained directed airspeed loading. Spring resistance remains independent.
Master gain0.65 Scales overall profile strength while preserving effect balance, subject to device and output limits.
Dynamic-pressure blendFalse Allows baseline spring strength to rise with indicated airspeed where the control law permits it.
Minimum spring factor0.5 Sets low-speed spring strength as a fraction of baseline when blending is enabled. One keeps full strength.
Spring wake-up speed8 ktSets the IAS where the low-speed spring blend starts rising. This is a feel threshold, not a flight limit.
Spring full-strength speed55.0 ktSets the IAS where the low-speed blend reaches baseline strength; high-speed stiffening also uses it.
Velocità di regolazione della forza110 ktSets the IAS reference for aerodynamic loading. It is an estimate, not published cruise TAS or a flight limit.
Airspeed spring stiffening0 Adds permitted spring resistance above the full-blend speed. Zero removes this high-speed increase.
Airspeed stiffening cap5 Limits the squared airspeed ratio used for high-speed spring stiffening; it is not a device-force cap.
Aileron force scale1 Roll and pitch aerodynamic scales are 1 and 1, respectively. These stored weights do not create directed aerodynamic loading while that term is inactive. No custom spring-travel curve is enabled.
Elevator force scale1 Scales pitch aerodynamic loading; pitch spring travel and trim responses are separate settings.
Maximum output force0.55 Caps directed-force output. Native spring effects and device limits remain separate.
StickFeel · Trim feel enabledFalse Retained for compatibility and group membership. Trim relief, rather than this flag, controls centre movement.
StickFeel · Trim relief enabledFalse Allows trim relief with supported control law and valid telemetry. Axis authorities set its amount.
StickFeel · Elevator authority0 Scales supported pitch-trim relief and permitted centre movement. Zero removes pitch response.
StickFeel · Aileron authority0 Scales supported roll-trim relief and permitted centre movement. Zero removes roll response.
StickFeel · Force trim enabledFalse Plugin-written trim describes the control neutral, separately from AP engagement. Local force trim is off. The stored latch parameters are inactive; the profile does not supply a local hold-where-left neutral.
StickFeel · G load enabledFalse Allows load-factor changes to modify permitted spring laws. Passive fly-by-wire feel can suppress it.
StickFeel · Rate damping enabledFalse Enables rate damping with the configured coefficients and control law.
Autopilot · Follow enabledFalse Autopilot following is off; the configured spring and load retain the hardware feel.
Autopilot · Follow authority0.1 Sets admitted AP-follow gain, not a percentage of travel. Runtime ownership and input limits still apply.
Autopilot · Neutral hold enabledFalse Permits centering hold during a supported AP state, separate from following a moving target.
Autopilot · Neutral hold strength0.6 Sets admitted AP neutral-hold strength; inactive while neutral hold is disabled.
Aero · EnabledTrue Enables aerodynamic cues; each still needs nonzero strength and its simulator conditions.
Aero · Gain0 Sets stall-buffet strength. Zero removes the cue without changing simulator stalls or warnings.
Aero · Gain0 Sets high-Mach buffet strength; onset and full-strength thresholds are separate.
Aero · Gain0 Sets flap buffet at the configured position and speed gates. Flap movement texture is separate.
Aero · Max flap index3 Sets the final flap index for detent normalization. UP plus three detents uses maximum index3.
Aero · Min flap index2 Sets the first flap detent that admits buffet; this is a handle index, not degrees.
Aero · Gain0 Sets gear aerodynamic buffet; movement and ground-contact cues are separate.
Aero · Shaker enabledFalse Permits shaker at supported warning conditions; the switch does not establish aircraft equipment.
Aero · Amplitude0.5 Sets triggered shaker strength; inactive while the shaker feature is disabled.
Ground · EnabledTrue Enables ground effects; each still needs its own strength and contact or motion telemetry.
Ground · Gain0 Sets rolling texture strength, modified by speed, surface and undercarriage configuration.
Ground · Gain0 Sets gear-bump texture during ground motion, separate from touchdown impact.
Ground · Gain0.2 Sets landing-impact strength; landing telemetry and response shape determine the pulse.
Ground · Gain0 Sets reverse-thrust vibration with valid reverser and engine conditions. Zero removes the cue.
Engine · EnabledFalse Enables engine cues with nonzero settings and valid running-engine telemetry.
Engine · Gain0 Sets estimated engine vibration using configured telemetry and response, not measured cockpit vibration.
Mechanical · EnabledTrue Enables accessory cues with configured strengths and observed accessory movement.
Mechanical · Gain0 Sets texture from observed flap movement; a command without movement does not establish the cue.
Mechanical · Gain0 Sets texture from observed gear movement, separate from aerodynamic and touchdown effects.
Fonti pubbliche 22
  1. Eurocopter EC135Research background · Wikipedia revision 1373321906 · retrieved 2026-09-12
  2. H135 build447 guide based on HPG guideDeveloper operating notes or exact systems listing; HPG-based guide build447, pages10-12
  3. www.rotorsim.deXP12 installation requirements
  4. Developer controls, versions and configuration documentationChangelog5.32 through5.36
  5. Developer controls, versions and configuration documentationControls, force trim and joystick modes
  6. Developer controls, versions and configuration documentationSETTINGS JoystickHasFtr; AFCS ResetTrimAtDisengage
  7. Developer controls, versions and configuration documentationDeveloper reply570
  8. Published EC135 MOZA preset, location from supplied updater configuration and installation guidePublished moza_ab9_ec135.preset from official updater repository
  9. Official dataref catalog JSONdrefs sim/cockpit2/controls/elevator_trim and aileron_trim
  10. EC135 original updater skunkcrafts_updater.cfgOriginal updater configuration
  11. EC1355.36 original plugins/ec135/lin.xplTrimSystem constructor, setFfbTrim, setTrimPitch and setTrimRoll; static symbol review
  12. EC1355.36 original plugins/ec135/win.xplOriginal Windows plugin strings and official updater CRC
  13. EC135 published original file CRCsplugins/ec135/lin.xpl and win.xpl; ec135.acf and config.ini
  14. Airbus H135 v1.4 release notesProduct listing captured 2026-09-30; edition scope from the reviewed catalogueSteve Daniels · 26 July 2021
  15. H135 freewareOfficial developer / designated store catalogue ·Official developer / designated store catalogue · checked 2026-09-12
  16. Microsoft Flight Simulator aircraft manuals
  17. EC135 free for MSFS 2024 owners
  18. The Magical FishbowlAustin Meyer · July 2002
  19. Glass of its Own: H135Jon Duke · 21 July 2017
  20. Continually improvingPeter Gray · 29 November–5 December 2016; archived magazine pages
  21. ICAO Doc 8643 — aircraft type designatorsPublic search data retrieved 2026-09-14; authority update 2026-09-03
  22. rotorsim – Das Portal für die HubschraubersimulationProduct listing captured 2026-09-23; edition scope from the reviewed catalogue

Comunità e correzioni

Se la tua esperienza sul tipo dice che questa pagina sbaglia, correggila qui.

Correzioni dei piloti

Voli questo velivolo? Correggi questa pagina.

Questa pagina nasce da riferimenti citati, e l'esperienza reale sul tipo vale più di una citazione. Cita l'affermazione errata e dicci cosa fa il velivolo reale. Le correzioni vanno al maintainer per revisione e alimentano la prossima revisione di questa ricerca.

Chiacchiere da hangar

Conversazione aperta su come si vola e si regola il Eurocopter EC135, nel forum della comunità. Le correzioni sopra vanno in privato al maintainer; le chiacchiere da hangar sono pubbliche.

Ancora nessuna chiacchiera da hangar sul Eurocopter EC135. Inizia tu.

Comunità

Profili della comunità per questo velivolo

Ancora nessun profilo della comunità per questo velivolo. Lo hai regolato a modo tuo? Condividi un profilo e apparirà qui.