机型库McDonnell Douglas F-4 Phantom II
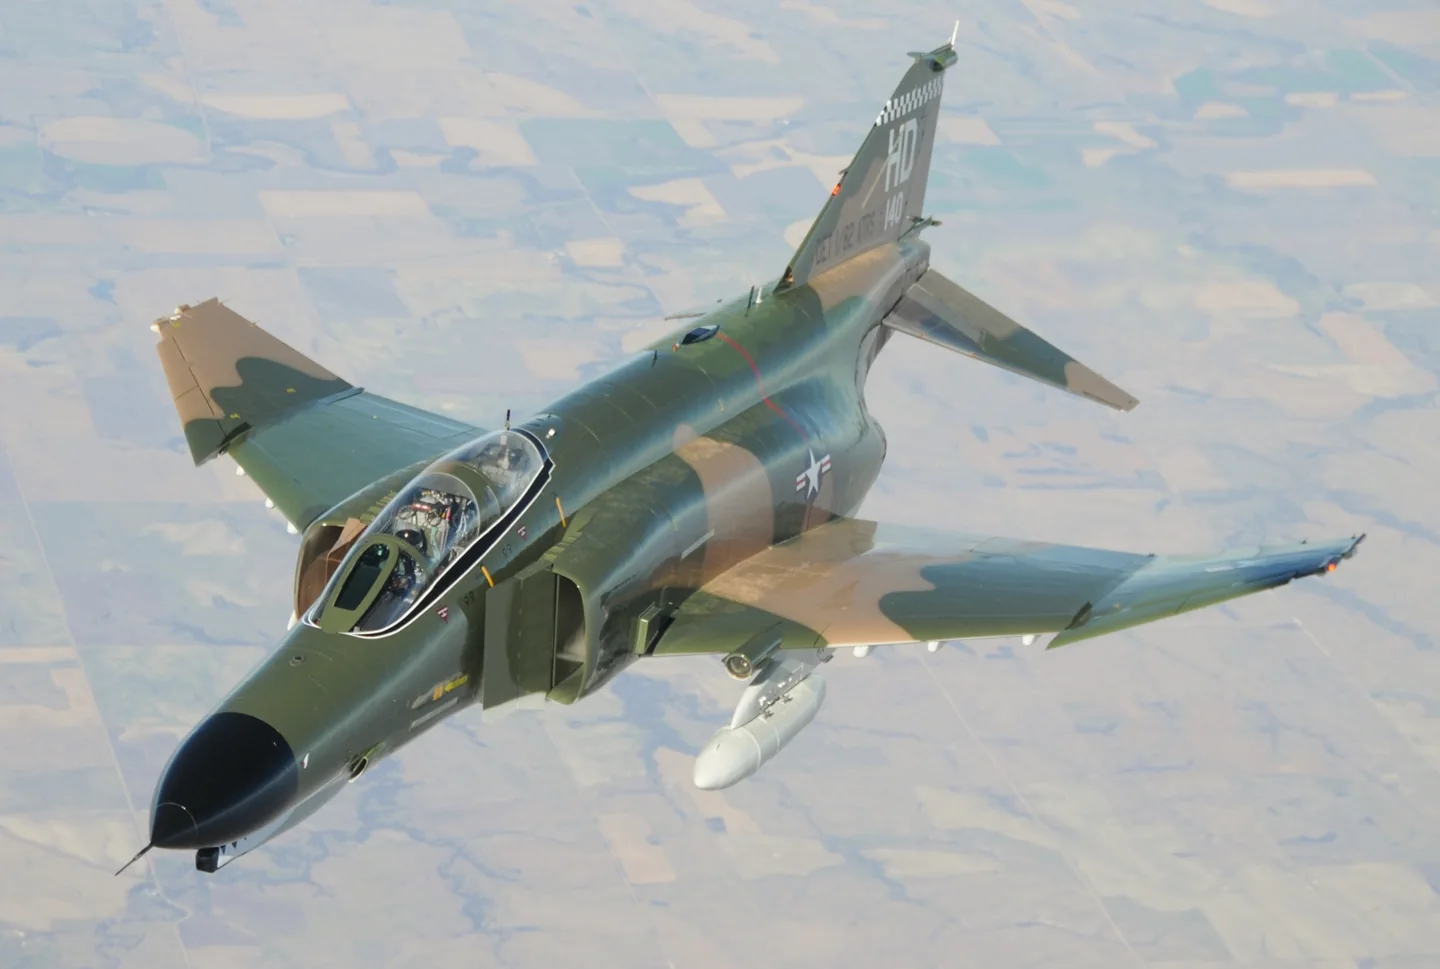
McDonnell Douglas F-4 Phantom IIUSAF · Public domain · McDonnell Douglas F-4 Phantom II pictured

McDonnell Douglas F-4 Phantom II

A two-seat, twin-engine fighter that served naval and land-based air forces in many roles.
Military jet配置文件选项:2 个

了解飞机

The Phantom began as a US Navy aircraft and was adopted by the US Air Force, Marine Corps and export customers. Large intakes, upward-angled outer wing panels and downward-angled tailplanes distinguish its airframe.

Interceptor, strike and reconnaissance versions carried different engines, radar and cockpit equipment. National upgrades added further differences during the type's long service.

Aircraft / family

Propulsion
Twin jet↗
Configuration
Two-seat multirole fighter↗

McDonnell Douglas F-4 Phantom II · Specifications (F-4E) · real aircraft; source units retained

Length
63 ft 0 in (19.2 m)↗
Wingspan
38 ft 5 in (11.7 m)↗
Height
16 ft 5 in (5 m)↗
Wing area
530 sq ft (49.2 m² )↗
Empty weight
30,328 lb (13,757 kg)↗
Gross weight
41,500 lb (18,824 kg)↗
Max takeoff weight
61,795 lb (28,030 kg)↗
Powerplant
2 × General Electric J79-GE-17A after-burning turbojet engines, 11,905 lbf (52.96 kN) thrust each dry, 17,845 lbf (79.38 kN) with afterburner↗
Maximum speed
1,280 kn (1,470 mph, 2,370 km/h) at 40,000 ft (12,000 m)↗
Cruise speed
510 kn (580 mph, 940 km/h)↗

在 AirframeDB 上了解这款航空器

The Phantom’s U.S. Air Force farewell includes its civilian instructors

Harkins’s interview places the final U.S. Air Force QF-4 flights at Holloman on 21 December 2016. His nine years as a civilian instructor illustrate the human contribution behind the aircraft’s late target-support career.

Moving from the Hunter into a two-person working cockpit

Bolton’s move from the Hunter to the Phantom meant learning an aircraft with a very different size and reputation. The initial impression of a large, powerful machine gradually gave way to understanding what it did well. The second crew member and the radar became central parts of that experience.

His work also changed when he moved from RAF ground-attack flying to the Royal Navy’s fleet-defence role. Shipboard preparation and practice brought their own audience and pressures, with other people watching how the crew performed. In his recollection, learning the Phantom was therefore more than mastering another set of controls. It involved a working partnership in the cockpit and adapting familiar flying skills to a different service environment.

Forty-five minutes of smiling at the end of a second career

Harkins had not expected to spend the later part of his career flying a fighter designed in the 1950s. Working as a civilian instructor gave him nine years and more than a thousand hours in the Phantom. By the farewell flights at Holloman, it had become a substantial second chapter in his flying life.

He remembered smiling so much during the final forty-five-minute flight that his cheeks hurt. The farewell appearances also brought conversations with veterans, families and old friends who wanted to see the aircraft again. Harkins compared his part in those events to driving the bus for the real star.

Choosing the front seat and learning from returning crews

Rubus had initially hoped for an F-105 assignment, but the available choices led him towards the Phantom. The opportunity to train for its front seat appealed to him, even when others warned that a new second lieutenant might find himself assigned to the rear cockpit instead. Looking back, he regarded the decision as a good one.

At George Air Force Base, instructors who had already served in Southeast Asia helped prepare him for the environment he would enter. Arriving at Ubon brought the classroom and conversion work into a different setting, with learning and staying alive closely connected in his recollection.

公开来源 10
  1. McDonnell Douglas F-4 Phantom IIResearch background · Wikipedia revision 1373929760 · retrieved 2026-09-12
  2. X-Plane 12 Desktop Manual
  3. X-Plane aircraft and avionics manuals
  4. X-Plane 11 Desktop Manual
  5. Flying the F-4 Phantom II, British styleChris Bolton · 31 July 2017
  6. Meet the last U.S. Air Force F-4 pilotInterview with Jim Harkins · 30 December 2016
  7. Interview with Gary RubusInterview by Sandor Farkas · 16 January 2016
  8. X-Plane 12 flight model update: supersonic transition, delta wings and mass propertiesAustin Meyer · February 2022
  9. ICAO Doc 8643 — aircraft type designatorsPublic search data retrieved 2026-09-14; authority update 2026-09-03
  10. DC Designs F-4E, F-4J and FGR2 PhantomProduct listing captured 28 September 2026; MSFS 2020 and 2024

配置文件如何建模

DC Designs F-4E / F-4J / FGR2 Phantom

Free + Pro
MSFS 2020MSFS 2024DC Designs

The Phantom began as a US Navy aircraft and was adopted by the US Air Force, Marine Corps and export customers. Large intakes, upward-angled outer wing panels and downward-angled tailplanes distinguish its airframe.

This profile selects DC Designs F-4E / F-4J / FGR2 Phantom for MSFS 2020, MSFS 2024.

Hydraulic control assistance motivates artificial stick centering. The spring stays independent of airspeed. Directed aerodynamic loading is omitted.

Pitch trim and pitch/bank hold serve separate cockpit functions. Pitch-trim relief is off. Autopilot following is off.

此确切修订版尚未开放公开安装。

Controls and trim

The F-4 package includes E, J and FGR2 aircraft, a hydraulic control system and a pitch/bank-hold automatic-flight installation. Those variant and automatic-flight functions define the documented rendition.

DC Designs F-4E, F-4J and FGR2 Phantom product and simulator compatibilityXPlane12 F4 flight model

The selected implementation

DC Designs includes E, J and FGR2 variants and pitch/bank hold in its documented cockpit.

DC Designs F-4E, F-4J and FGR2 Phantom product and simulator compatibility

About the values

The gains are normalized profile settings. They describe the chosen effect balance; hand force depends on the device and its output limits. IAS references are tuning values rather than operating limits. Physical acceptance of this revision remains pending.

Master gain & control system

Master gain85%

施加于模型产出的一切、在设备上限之前的最终整体输出缩放。

调高: 一切(弹簧、载荷、效果)一同增强。

调低: 一切一同变柔。

设定理由: Scales overall profile strength while preserving effect balance, subject to device and output limits.

Forces

Spring strength48%

把摇杆拉回中央的基础回中力。其他所有力都叠加在它之上。太低,正常飞行中摇杆会发软;太高,它会与你的手较劲,并掩盖叠加其上的细微提示。

调高: 更硬的回中,更抗手。

调低: 更软的杆,只靠气动载荷。

设定理由: Hydraulic control assistance motivates artificial stick centering. The baseline spring is 0.48. Low-speed spring blending is off.

DC Designs F-4E, F-4J and FGR2 Phantom product and simulator compatibilityXPlane12 F4 flight model
Spring deadband4%

中央附近弹簧保持安静的小中立区,让静止时的微小移动不会咔嗒作响。更宽更安稳但更松,更窄更精确但可能在中央附近抖动。

调高: 更安静但更松的中央,旷量更大。

调低: 更紧的中央,静止时可能抖动。

设定理由: Sets travel around the centre before the baseline spring resists. Smaller values engage it sooner.

Overall aerodynamic load25%

作用于两条持续轴载荷的主缩放,在它们各自的独立平衡之前施加。配置文件通常不动它,而是调校两条轴载荷。

调高: 两轴载荷一同加重。

调低: 两轴一同减轻。

设定理由: The stored 0.25 aerodynamic-load gain is inactive under the zero hydraulic-load factor.

Airspeed blendingFalse

启用低速弹簧介入窗口(上面的起始/全强度节数)。关闭时弹簧在所有速度下恒定。

设定理由: Allows baseline spring strength to rise with indicated airspeed where the control law permits it.

Low-speed spring floor55%

在静止、空速尚未产生气动力之前,弹簧还剩多少。下限高,停机时摇杆结实;下限低,则是停放轻型飞机那种钢索松弛的感觉。

调高: 停机和滑行时杆更结实。

调低: 停机时杆发软,只随速度苏醒。

设定理由: Sets low-speed spring strength as a fraction of baseline when blending is enabled. One keeps full strength.

Spring engagement start8 kt

弹簧从低速下限开始向全强度攀升的空速:起飞滑跑中操纵面"苏醒"的那一刻。

设定理由: Sets the IAS where the low-speed spring blend starts rising. This is a feel threshold, not a flight limit.

Spring engagement full65 kt

弹簧达到全强度的空速。从起点到这里,随着气流在操纵面上增强,回中逐渐变硬。

设定理由: Sets the IAS where the low-speed blend reaches baseline strength; high-speed stiffening also uses it.

力反馈调校速度250

气动载荷达到设计满值的指示空速。它把整条载荷曲线锚定在飞机真实的速度范围:172在110节就载满,喷气机要晚得多。

调高: 载荷来得更晚;杆轻到更高速度。

调低: 载荷来得更早,巡航更沉。

设定理由: Sets the IAS reference for aerodynamic loading. It is an estimate, not published cruise TAS or a flight limit.

Centre firmness vs speed0%

在偏转载荷之外,回中本身随速度变硬的程度。零则中央手感恒定;越大,巡航时回中越硬,起落航线上越松。

调高: 中央随速度明显变硬。

调低: 任何速度下中央手感恒定。

设定理由: The high-speed spring-stiffening gain is 0. No additional speed-driven stiffening is added; this does not disable independent aerodynamic loading.

Centre stiffening cap2

速度驱动的中央变硬上限,防止高速飞行把弹簧无限上紧。

调高: 高速允许更多总硬化。

调低: 硬化更早封顶。

设定理由: Limits the squared airspeed ratio used for high-speed spring stiffening; it is not a device-force cap.

Aileron load72%

由副翼偏转和空速产生的持续横滚载荷,独立于俯仰调校。与升降舵载荷一起,决定评测中常说的操纵协调比。

调高: 横滚力更重。

调低: 副翼更轻更灵。

设定理由: Roll and pitch aerodynamic scales are 0.72 and 1, respectively. These stored weights do not create directed aerodynamic loading while that term is inactive. No custom spring-travel curve is enabled.

Elevator load100%

由升降舵偏转和空速产生的持续俯仰载荷,独立于横滚调校。这是决定机型俯仰重量的主杠杆。它不影响副翼、弹簧、配平或抖振力。

调高: 速度下持续俯仰力更重。

调低: 升降舵更轻,握持更省力。

设定理由: Scales pitch aerodynamic loading; pitch spring travel and trim responses are separate settings.

Max output force55%

每个稳态俯仰或横滚力到达设备前的上限,防止猛烈机动中砸击或饱和硬件。

调高: 削波前更高的稳态力峰值。

调低: 更柔的上限;猛烈机动更早被抹平。

设定理由: Caps directed-force output. Native spring effects and device limits remain separate.

Trim

Trim relief (elevator)0%

升降舵配平缓解持续俯仰力、移动杆的安定位置的强度。在100 %时,配平得当的飞机不需要保持压力——正是真实飞行中"用配平消掉载荷"的流程。

调高: 配平消掉更多持续力;100 %时满配平可完全抵消。

调低: 即使配平也仍要持续用力。

设定理由: Pitch trim and pitch/bank hold serve separate cockpit functions. Pitch relief is off, with stored authority 0; roll authority is 0.

DC Designs F-4E, F-4J and FGR2 Phantom product and simulator compatibilityXPlane12 F4 flight model
Trim relief (aileron)0%

横滚配平的同类缓解。多数通航机型没有真正的副翼配平,所以保持为零;有横滚配平的机型获得相应的值。

调高: 横滚配平消掉更多持续力。

调低: 横滚配平作用更小。

设定理由: Scales supported roll-trim relief and permitted centre movement. Zero removes roll response.

Effect gains · Ground

Runway rumble40%

由轮速和地面类型(铺装、草地、砾石)产生的滚动振动。

调高: 杆上更强的地面质感。

调低: 更平滑的滑行。

设定理由: Sets rolling texture strength, modified by speed, surface and undercarriage configuration.

Gear bumps25%

来自伸缩缝、车辙和粗糙地面的短促离散颠簸,为持续隆隆声打上标点。

调高: 接缝与车辙的冲击更清晰。

调低: 更柔的地面细节。

设定理由: Sets gear-bump texture during ground motion, separate from touchdown impact.

Effect gains · Airframe

Stall buffet0%

接近失速及失速警告响起时的机体抖动:这副机翼宣告不满的音量。断失干脆的机型抖振收敛,让喇叭承担警告。

调高: 更强的失速前颤抖。

调低: 更含蓄的机翼;警告交给喇叭。

设定理由: Sets stall-buffet strength. Zero removes the cue without changing simulator stalls or warnings.

Mach buffet0%

接近马赫极限的跨音速抖振。对接近MMO的喷气机有意义,对到不了那里的活塞机和涡桨机为零。

调高: 接近马赫极限时更强的跨音速抖振。

调低: 高马赫下更平滑的飞行。

设定理由: Sets high-Mach buffet strength; onset and full-strength thresholds are separate.

Flap buffet0%

襟翼伸入气流后机体的低频振动,发生在它们真正做功的速度窗口内。

调高: 襟翼做功时更粗糙的飞行。

调低: 更柔的进近襟翼。

设定理由: Sets flap buffet at the configured position and speed gates. Flap movement texture is separate.

Gear buffet0%

可收放起落架悬在气流中引起的机体鼓振。固定起落架机型为零,它们的机体外形从不改变。

调高: 放起落架时更多鼓振。

调低: 放起落架飞行更干净。

设定理由: Sets gear aerodynamic buffet; movement and ground-contact cues are separate.

Stick shaker50%

由飞机自身失速警告系统触发的专用抖杆器振动。只有真有抖杆器的机型才有值;其余全靠气动抖振和喇叭。

调高: 更硬的抖杆器。

调低: 更含蓄的抖杆器。

设定理由: Sets triggered shaker strength; inactive while the shaker feature is disabled.

Effect gains · Engine, mechanical & drag

Touchdown thump65%

机轮触及跑道那一下的单次冲击,按下沉率缩放:轻柔着陆是耳语,结实到达是一记闷响。

调高: 触地时更硬的一击。

调低: 更柔的到达。

设定理由: Sets landing-impact strength; landing telemetry and response shape determine the pulse.

Reverse rumble0%

反推或桨叶beta区工作时的滑跑振动。无反推机型为零。

调高: 反推下更粗糙的滑跑。

调低: 更含蓄的反推。

设定理由: Sets reverse-thrust vibration with valid reverser and engine conditions. Zero removes the cue.

Engine rumble0%

从慢车到全功率跟随转速的持续动力装置振动——前方有东西在烧油的永恒提醒。

调高: 杆里更多发动机。

调低: 更含蓄的发动机。

设定理由: Sets estimated engine vibration using configured telemetry and response, not measured cockpit vibration.

Flap motion2%

仅在模拟器报告襟翼舵面确实移动时的持续振动。它跟随真实作动器的运动和故障,而非估算的计时器。

调高: 襟翼移动中更多振动。

调低: 更含蓄的襟翼行程。

设定理由: Sets texture from observed flap movement; a command without movement does not establish the cue.

Autopilot follow

AP follow authority10%

自动驾驶指令可以让杆实际移动多远。在MSFS中保持极小,因为移动的轴可能被读回为飞行员输入;零则完全禁用跟随。

调高: 自动驾驶让你的杆移动得明显更多。

调低: 几乎察觉不到的跟随。

设定理由: Sets admitted AP-follow gain, not a percentage of travel. Runtime ownership and input limits still apply.

Stick feel

StickFeel · Trim feel enabledFalse

Whether this feature is active in this profile.

设定理由: Retained for compatibility and group membership. Trim relief, rather than this flag, controls centre movement.

StickFeel · Trim relief enabledFalse

Whether this feature is active in this profile.

设定理由: Allows trim relief with supported control law and valid telemetry. Axis authorities set its amount.

StickFeel · Force trim enabledFalse

Whether this feature is active in this profile.

设定理由: Enables local force trim, separate from aircraft-owned trim and add-on integration qualification.

StickFeel · G load enabledFalse

Whether this feature is active in this profile.

设定理由: Allows load-factor changes to modify permitted spring laws. Passive fly-by-wire feel can suppress it.

StickFeel · Rate damping enabledFalse

Whether this feature is active in this profile.

设定理由: Enables rate damping with the configured coefficients and control law.

Autopilot

Autopilot · Follow enabledFalse

Whether this feature is active in this profile.

设定理由: Autopilot following is off; the configured spring and load retain the hardware feel.

Autopilot · Neutral hold enabledFalse

Whether this feature is active in this profile.

设定理由: Permits centering hold during a supported AP state, separate from following a moving target.

Autopilot · Neutral hold strength0.6

设定理由: Sets admitted AP neutral-hold strength; inactive while neutral hold is disabled.

Aero

Aero · EnabledTrue

Whether this feature is active in this profile.

设定理由: Enables aerodynamic cues; each still needs nonzero strength and its simulator conditions.

Aero · Max flap index3

Where this effect reaches full strength (or has fully faded, for washouts).

调高: a more gradual build to a later peak.

调低: a quicker build.

设定理由: Sets the final flap index for detent normalization. UP plus three detents uses maximum index3.

Aero · Min flap index2

Where this effect begins fading in.

调高: the effect begins later.

调低: it begins earlier.

设定理由: Sets the first flap detent that admits buffet; this is a handle index, not degrees.

Aero · Shaker enabledFalse

Whether this feature is active in this profile.

设定理由: Permits shaker at supported warning conditions; the switch does not establish aircraft equipment.

Ground

Ground · EnabledTrue

Whether this feature is active in this profile.

设定理由: Enables ground effects; each still needs its own strength and contact or motion telemetry.

Engine

Engine · EnabledFalse

Whether this feature is active in this profile.

设定理由: Enables engine cues with nonzero settings and valid running-engine telemetry.

Mechanical

Mechanical · EnabledTrue

Whether this feature is active in this profile.

设定理由: Enables accessory cues with configured strengths and observed accessory movement.

Mechanical · Gain0.025

The strength of this effect.

调高: a stronger effect.

调低: a weaker one.

设定理由: Sets texture from observed gear movement, separate from aerodynamic and touchdown effects.

全部配置文件设置
估算的配置文件设置
参数数值控制作用及原因
Spring strength0.48 Hydraulic control assistance motivates artificial stick centering. The baseline spring is 0.48. Low-speed spring blending is off.
Spring deadband0.04 Sets travel around the centre before the baseline spring resists. Smaller values engage it sooner.
Force gain0.25 The stored 0.25 aerodynamic-load gain is inactive under the zero hydraulic-load factor.
Master gain0.85 Scales overall profile strength while preserving effect balance, subject to device and output limits.
Dynamic-pressure blendFalse Allows baseline spring strength to rise with indicated airspeed where the control law permits it.
Minimum spring factor0.55 Sets low-speed spring strength as a fraction of baseline when blending is enabled. One keeps full strength.
Spring wake-up speed8 ktSets the IAS where the low-speed spring blend starts rising. This is a feel threshold, not a flight limit.
Spring full-strength speed65 ktSets the IAS where the low-speed blend reaches baseline strength; high-speed stiffening also uses it.
力反馈调校速度250 ktSets the IAS reference for aerodynamic loading. It is an estimate, not published cruise TAS or a flight limit.
Airspeed spring stiffening0 The high-speed spring-stiffening gain is 0. No additional speed-driven stiffening is added; this does not disable independent aerodynamic loading.
Airspeed stiffening cap2 Limits the squared airspeed ratio used for high-speed spring stiffening; it is not a device-force cap.
Aileron force scale0.72 Roll and pitch aerodynamic scales are 0.72 and 1, respectively. These stored weights do not create directed aerodynamic loading while that term is inactive. No custom spring-travel curve is enabled.
Elevator force scale1 Scales pitch aerodynamic loading; pitch spring travel and trim responses are separate settings.
Maximum output force0.55 Caps directed-force output. Native spring effects and device limits remain separate.
StickFeel · Trim feel enabledFalse Retained for compatibility and group membership. Trim relief, rather than this flag, controls centre movement.
StickFeel · Trim relief enabledFalse Allows trim relief with supported control law and valid telemetry. Axis authorities set its amount.
StickFeel · Elevator authority0 Pitch trim and pitch/bank hold serve separate cockpit functions. Pitch relief is off, with stored authority 0; roll authority is 0.
StickFeel · Aileron authority0 Scales supported roll-trim relief and permitted centre movement. Zero removes roll response.
StickFeel · Force trim enabledFalse Enables local force trim, separate from aircraft-owned trim and add-on integration qualification.
StickFeel · G load enabledFalse Allows load-factor changes to modify permitted spring laws. Passive fly-by-wire feel can suppress it.
StickFeel · Rate damping enabledFalse Enables rate damping with the configured coefficients and control law.
Autopilot · Follow enabledFalse Autopilot following is off; the configured spring and load retain the hardware feel.
Autopilot · Follow authority0.1 Sets admitted AP-follow gain, not a percentage of travel. Runtime ownership and input limits still apply.
Autopilot · Neutral hold enabledFalse Permits centering hold during a supported AP state, separate from following a moving target.
Autopilot · Neutral hold strength0.6 Sets admitted AP neutral-hold strength; inactive while neutral hold is disabled.
Aero · EnabledTrue Enables aerodynamic cues; each still needs nonzero strength and its simulator conditions.
Aero · Gain0 Sets stall-buffet strength. Zero removes the cue without changing simulator stalls or warnings.
Aero · Gain0 Sets high-Mach buffet strength; onset and full-strength thresholds are separate.
Aero · Gain0 Sets flap buffet at the configured position and speed gates. Flap movement texture is separate.
Aero · Max flap index3 Sets the final flap index for detent normalization. UP plus three detents uses maximum index3.
Aero · Min flap index2 Sets the first flap detent that admits buffet; this is a handle index, not degrees.
Aero · Gain0 Sets gear aerodynamic buffet; movement and ground-contact cues are separate.
Aero · Shaker enabledFalse Permits shaker at supported warning conditions; the switch does not establish aircraft equipment.
Aero · Amplitude0.5 Sets triggered shaker strength; inactive while the shaker feature is disabled.
Ground · EnabledTrue Enables ground effects; each still needs its own strength and contact or motion telemetry.
Ground · Gain0.4 Sets rolling texture strength, modified by speed, surface and undercarriage configuration.
Ground · Gain0.25 Sets gear-bump texture during ground motion, separate from touchdown impact.
Ground · Gain0.65 Sets landing-impact strength; landing telemetry and response shape determine the pulse.
Ground · Gain0 Sets reverse-thrust vibration with valid reverser and engine conditions. Zero removes the cue.
Engine · EnabledFalse Enables engine cues with nonzero settings and valid running-engine telemetry.
Engine · Gain0 Sets estimated engine vibration using configured telemetry and response, not measured cockpit vibration.
Mechanical · EnabledTrue Enables accessory cues with configured strengths and observed accessory movement.
Mechanical · Gain0.018 Sets texture from observed flap movement; a command without movement does not establish the cue.
Mechanical · Gain0.025 Sets texture from observed gear movement, separate from aerodynamic and touchdown effects.
公开来源 10
  1. McDonnell Douglas F-4 Phantom IIResearch background · Wikipedia revision 1373929760 · retrieved 2026-09-12
  2. DC Designs F-4E, F-4J and FGR2 Phantom product and simulator compatibilityCompatibility, model and aircraft systemsProduct listing captured 28 September 2026; MSFS 2020 and 2024
  3. XPlane12 F4 flight modelAustin Meyer · February 2022
  4. X-Plane 12 Desktop Manual
  5. X-Plane aircraft and avionics manuals
  6. X-Plane 11 Desktop Manual
  7. Flying the F-4 Phantom II, British styleChris Bolton · 31 July 2017
  8. Meet the last U.S. Air Force F-4 pilotInterview with Jim Harkins · 30 December 2016
  9. Interview with Gary RubusInterview by Sandor Farkas · 16 January 2016
  10. ICAO Doc 8643 — aircraft type designatorsPublic search data retrieved 2026-09-14; authority update 2026-09-03

社区与纠错

如果你的真机经验表明本页有误,请在此指正。

飞行员纠错

飞过这款飞机?纠正本页。

本页基于引用资料构建,而真机经验胜过任何引用。 请引用有误的主张,并告诉我们真机的实际表现。纠错 将交由维护者审核,并纳入本研究的下一次修订。

机库闲谈

关于 McDonnell Douglas F-4 Phantom II 的飞行与调校的公开讨论(社区论坛)。上方的纠错将私下送达维护者;机库闲谈是公开的。

McDonnell Douglas F-4 Phantom II 还没有机库闲谈。来做第一个吧。

社区

该机型的社区配置

该机型还没有社区配置。 调出了自己的风格? 分享一个配置 它就会出现在这里。