Built for mail and passengers
The Latécoère 28 was a civil transport carrying mail and up to eight passengers. It became an important aircraft in Aéropostale’s intercontinental network, particularly its South American services.
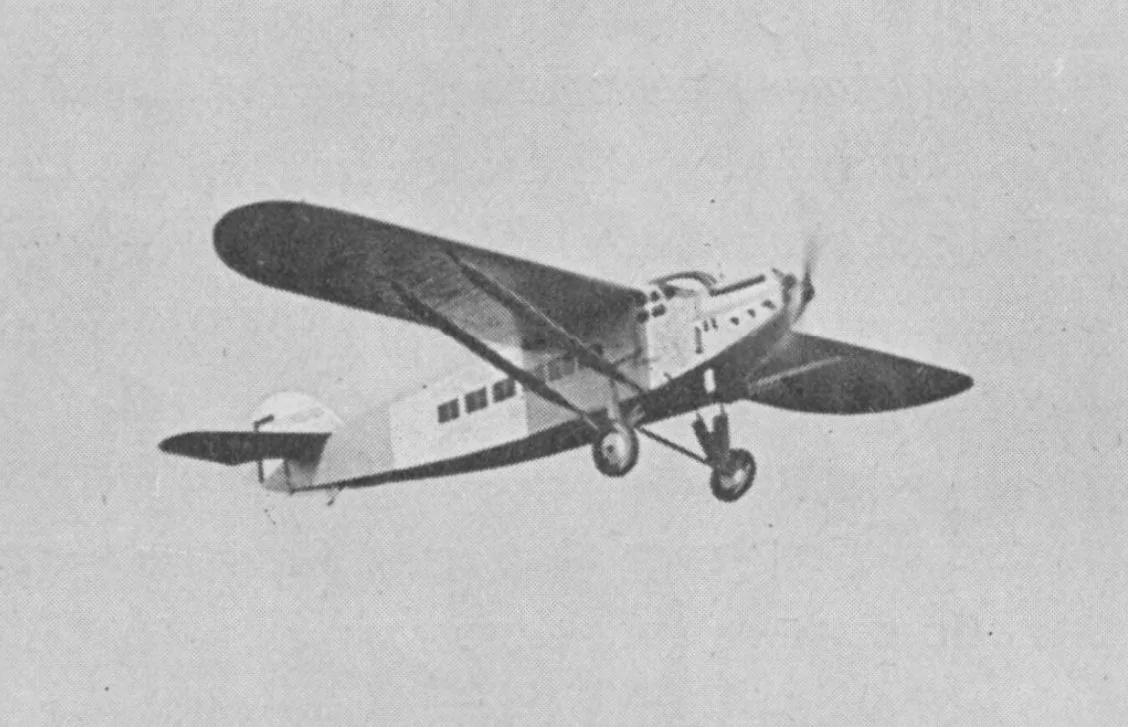 L'Aéronautique magazine · Public domain · Latécoère 28.1 L'Aéronautique March,1929.
RedWing's Latécoère 28 package includes the fixed-wheel 28.1 and float-equipped 28.3. The single-piston aircraft has cable-operated controls, pitch and rudder trim, and no wing flaps. The float version carries larger tanks for long-range flying.
Mais sobre esta aeronave no AirframeDB
The Latécoère 28 was a civil transport carrying mail and up to eight passengers. It became an important aircraft in Aéropostale’s intercontinental network, particularly its South American services.
In May 1930, Jean Mermoz flew a float-equipped Latécoère 28 from Senegal to Brazil with 130 kg of mail. The foundation records a flight of 19 hours 35 minutes. This achievement belongs to the modified seaplane, rather than every landplane version of the type.
The 28.1 supports passenger and cargo payloads. The 28.3 uses fixed floats without wheel braking. The released manual covers both versions; older website work-in-progress wording describes an earlier development state.
A single-engine mail aircraft with land and long-range float versions.
Spring resistance builds with the selected airspeed response. A separate aerodynamic term adds speed-dependent control load.
Valid trim provides the configured pressure relief. Autopilot following is off.
Single-piston mail aircraft, no wing flaps. Fixed wheels with passenger/cargo payload options.
The 28.1 supports passenger and cargo payloads. The 28.3 uses fixed floats without wheel braking. The released manual covers both versions; older website work-in-progress wording describes an earlier development state.
Strengths are normalized hardware-feel settings. They set the effect balance; hand force depends on the device and its limits. The IAS reference is a tuning value.
A escala final de saída aplicada a tudo que o modelo produz, antes do teto do dispositivo.
Mais: tudo (mola, cargas, efeitos) fica mais forte junto.
Menos: tudo amacia junto.
Por que aqui: Scales overall profile strength while preserving effect balance, subject to device and output limits.
A força base de centragem que puxa o manche de volta ao centro. Todas as outras forças se empilham sobre ela. Baixa demais e o manche parece frouxo em voo normal; alta demais e ele briga com sua mão e mascara os sinais menores por cima.
Mais: uma centragem mais firme que resiste mais à mão.
Menos: um manche mais mole que depende só da carga aerodinâmica.
Por que aqui: The 28.1 supports passenger and cargo payloads. The baseline spring is 0.74. Its low-speed blend reaches baseline strength at 52.5 KIAS.
Latecoere 28.1 Wheels — simulator documentationUma escala mestra sobre as duas cargas sustentadas de eixo, aplicada antes do balanço independente delas. Os perfis normalmente a deixam quieta e ajustam as duas cargas de eixo.
Mais: os dois eixos carregam mais forte.
Menos: os dois eixos aliviam juntos.
Por que aqui: The aerodynamic-load gain is 0.8 with an indicated-speed reference of 105 KIAS. This supplies speed-dependent loading alongside the spring.
A carga sustentada de arfagem da deflexão do profundor e da velocidade, balanceada independentemente da rolagem. É a alavanca principal por trás do peso de arfagem de um tipo. Não toca aileron, mola, compensador nem forças de buffet.
Mais: esforços sustentados de arfagem mais pesados em velocidade.
Menos: um profundor mais leve, com menos músculo para segurar.
Por que aqui: Scales pitch aerodynamic loading; pitch spring travel and trim responses are separate settings.
A carga sustentada de rolagem da deflexão dos ailerons e da velocidade, balanceada independentemente da arfagem. Junto com a carga do profundor define a razão de harmonia de comandos de que falam as resenhas.
Mais: esforços de rolagem mais pesados.
Menos: ailerons mais leves e vivos.
Por que aqui: Roll and pitch aerodynamic scales are 0.72 and 1, respectively. They set the aerodynamic axis balance. No custom spring-travel curve is enabled.
Um teto sobre cada força estável de arfagem ou rolagem antes de chegar ao dispositivo, protegendo contra pancadas ou saturação do hardware em manobras fortes.
Mais: picos de força estável mais altos antes do corte.
Menos: um teto mais suave; manobras duras achatam antes.
Por que aqui: Caps directed-force output. Native spring effects and device limits remain separate.
A velocidade indicada em que a carga aerodinâmica atinge seu nível pleno de projeto. Ela ancora toda a curva de carga à faixa real de velocidades do avião: um 172 carrega por volta de 110 nós, um jato bem depois.
Mais: as cargas chegam mais tarde; o manche fica leve até mais velocidade.
Menos: as cargas chegam antes e o cruzeiro pesa mais.
Por que aqui: Sets the IAS reference for aerodynamic loading. It is an estimate, not published cruise TAS or a flight limit.
Uma pequena zona neutra ao redor do centro onde a mola fica quieta, para que movimentos mínimos em repouso não trepidem. Mais larga é mais calma porém mais solta; mais estreita é mais precisa mas pode tremer no centro.
Mais: um centro mais calmo porém mais solto, com mais folga.
Menos: um centro mais apertado que pode tremer em repouso.
Por que aqui: Sets travel around the centre before the baseline spring resists. Smaller values engage it sooner.
Ativa a janela de engate da mola em baixa velocidade (nós de início/pleno acima). Desligado, a mola é constante em todas as velocidades.
Por que aqui: Allows baseline spring strength to rise with indicated airspeed where the control law permits it.
Quanto da mola sobrevive parado, antes que a velocidade possa gerar força aerodinâmica. Um piso alto mantém o manche estacionado firme; um piso baixo dá a sensação solta, de cabos com folga, de um avião leve estacionado.
Mais: um manche mais firme estacionado e no táxi.
Menos: um manche mole estacionado que só desperta com velocidade.
Por que aqui: Sets low-speed spring strength as a fraction of baseline when blending is enabled. One keeps full strength.
A velocidade em que a mola começa a subir do piso de baixa velocidade rumo à força plena: os comandos "ganhando vida" na corrida de decolagem.
Por que aqui: Sets the IAS where the low-speed spring blend starts rising. This is a feel threshold, not a flight limit.
A velocidade em que a mola atinge força plena. Entre o início e este ponto, a centragem endurece progressivamente à medida que o fluxo de ar cresce sobre os comandos.
Por que aqui: Sets the IAS where the low-speed blend reaches baseline strength; high-speed stiffening also uses it.
Quanto a própria centragem endurece com a velocidade, além das cargas de deflexão. Zero mantém a sensação de centro constante; mais faz o manche centrar mais duro em cruzeiro e mais solto no circuito.
Mais: um centro que endurece nitidamente com a velocidade.
Menos: uma sensação de centro constante em qualquer velocidade.
Por que aqui: The high-speed spring-stiffening gain is 0.15. It strengthens the permitted spring response above 52.5 KIAS, with the squared-speed ratio capped at 5.
O limite superior do endurecimento de centro pela velocidade, para que voos muito rápidos não tensionem a mola sem freio.
Mais: mais endurecimento total permitido em alta velocidade.
Menos: o endurecimento corta antes.
Por que aqui: Limits the squared airspeed ratio used for high-speed spring stiffening; it is not a device-force cap.
Com que força o compensador de profundor alivia o esforço de arfagem mantido e desloca onde o manche assenta. Em 100 %, um avião bem compensado não precisa de pressão mantida: o fluxo de trabalho de compensar-a-carga do voo real.
Mais: o compensador tira mais esforço mantido; em 100 %, todo compensado o anula.
Menos: você segue segurando esforço mesmo compensado.
Por que aqui: The profile uses the trim behaviour configured below. Pitch authority 0.3 provides load relief and permitted centre movement; roll authority is 0.
Latecoere 28.1 Wheels — simulator documentationO mesmo alívio para o compensador de rolagem. A maioria dos tipos de aviação geral não tem compensador de aileron real, então isto fica em zero; tipos com compensador de rolagem recebem um valor correspondente.
Mais: o compensador de rolagem tira mais esforço mantido.
Menos: o compensador de rolagem faz menos.
Por que aqui: Scales supported roll-trim relief and permitted centre movement. Zero removes roll response.
Vibração de rolagem no solo pela velocidade das rodas e tipo de superfície: asfalto, grama ou cascalho sob o trem.
Mais: uma textura de superfície mais forte no manche.
Menos: um táxi mais liso.
Por que aqui: Sets rolling texture strength, modified by speed, surface and undercarriage configuration.
Solavancos curtos e discretos de juntas de dilatação, sulcos e superfície irregular, pontuando o ronco contínuo.
Mais: solavancos mais nítidos de juntas e sulcos.
Menos: detalhes de solo mais suaves.
Por que aqui: Sets gear-bump texture during ground motion, separate from touchdown impact.
Sacudida da célula ao se aproximar do estol e enquanto o aviso soa: quão alto esta asa anuncia que está infeliz. Tipos de quebra seca recebem buffet modesto e deixam a buzina levar o aviso.
Mais: um tremor pré-estol mais forte.
Menos: uma asa mais discreta; a buzina leva o aviso.
Por que aqui: Sets stall-buffet strength. Zero removes the cue without changing simulator stalls or warnings.
Buffet transônico ao se aproximar do limite de Mach. Significativo para jatos perto de MMO, zero para pistões e turboélices que nunca chegam lá.
Mais: um buffet transônico mais forte perto do limite de Mach.
Menos: um voo mais liso em Mach alto.
Por que aqui: Sets high-Mach buffet strength; onset and full-strength thresholds are separate.
Vibração de baixa frequência da célula com flapes estendidos no fluxo, na janela de velocidade em que eles realmente trabalham o ar.
Mais: um voo mais áspero com flapes trabalhando.
Menos: flapes de aproximação mais suaves.
Por que aqui: Sets flap buffet at the configured position and speed gates. Flap movement texture is separate.
Tamborilar da célula pelo trem retrátil pendurado na corrente de ar. Zero para tipos de trem fixo, onde a célula nunca muda de forma.
Mais: mais tamborilar com o trem embaixo.
Menos: um voo com trem embaixo mais limpo.
Por que aqui: Sets gear aerodynamic buffet; movement and ground-contact cues are separate.
O zumbido dedicado do stick shaker de estol, disparado pelo próprio sistema de aviso do avião. Só tipos com shaker real recebem valor; o resto confia no buffet aerodinâmico e na buzina.
Mais: um shaker mais duro.
Menos: um shaker mais discreto.
Por que aqui: Sets triggered shaker strength; inactive while the shaker feature is disabled.
O golpe único quando as rodas tocam a pista, escalado pela razão de descida: um pouso macio sussurra, uma chegada firme bate.
Mais: um golpe mais duro no toque.
Menos: chegadas mais suaves.
Por que aqui: Sets landing-impact strength; landing telemetry and response shape determine the pulse.
Vibração na corrida enquanto o reverso ou as hélices em beta trabalham. Zero para tipos sem reverso.
Mais: uma corrida mais áspera sob reverso.
Menos: um reverso mais discreto.
Por que aqui: Sets reverse-thrust vibration with valid reverser and engine conditions. Zero removes the cue.
Vibração contínua do grupo motopropulsor seguindo a rotação entre marcha lenta e potência máxima, o lembrete sempre presente de que algo queima combustível lá na frente.
Mais: mais motor no manche.
Menos: um motor mais discreto.
Por que aqui: Sets estimated engine vibration using configured telemetry and response, not measured cockpit vibration.
Vibração contínua apenas enquanto o simulador informa as superfícies de flape realmente em movimento. Segue o movimento e as falhas reais do atuador, não um cronômetro estimado.
Mais: mais vibração com os flapes em movimento.
Menos: cursos de flape mais discretos.
Por que aqui: Sets texture from observed flap movement; a command without movement does not establish the cue.
Quanto os comandos do piloto automático podem mover fisicamente o manche. Mantido minúsculo no MSFS, onde um eixo movido pode ser lido de volta como entrada do piloto; zero desativa o seguimento por completo.
Mais: o piloto automático move seu manche visivelmente mais.
Menos: um seguimento quase imperceptível.
Por que aqui: Sets admitted AP-follow gain, not a percentage of travel. Runtime ownership and input limits still apply.
Whether this feature is active in this profile.
Por que aqui: Retained for compatibility and group membership. Trim relief, rather than this flag, controls centre movement.
Whether this feature is active in this profile.
Por que aqui: Allows trim relief with supported control law and valid telemetry. Axis authorities set its amount.
Whether this feature is active in this profile.
Por que aqui: Enables local force trim, separate from aircraft-owned trim and add-on integration qualification.
Whether this feature is active in this profile.
Por que aqui: Allows load-factor changes to modify permitted spring laws. Passive fly-by-wire feel can suppress it.
Whether this feature is active in this profile.
Por que aqui: Enables rate damping with the configured coefficients and control law.
Whether this feature is active in this profile.
Por que aqui: Autopilot following is off; the configured spring and load retain the hardware feel.
Whether this feature is active in this profile.
Por que aqui: Permits centering hold during a supported AP state, separate from following a moving target.
Por que aqui: Sets admitted AP neutral-hold strength; inactive while neutral hold is disabled.
Whether this feature is active in this profile.
Por que aqui: Enables aerodynamic cues; each still needs nonzero strength and its simulator conditions.
Where this effect reaches full strength (or has fully faded, for washouts).
Mais: a more gradual build to a later peak.
Menos: a quicker build.
Por que aqui: Sets the final flap index for detent normalization. UP plus three detents uses maximum index3.
Where this effect begins fading in.
Mais: the effect begins later.
Menos: it begins earlier.
Por que aqui: Sets the first flap detent that admits buffet; this is a handle index, not degrees.
Whether this feature is active in this profile.
Por que aqui: Permits shaker at supported warning conditions; the switch does not establish aircraft equipment.
Whether this feature is active in this profile.
Por que aqui: Enables ground effects; each still needs its own strength and contact or motion telemetry.
Whether this feature is active in this profile.
Por que aqui: Enables engine cues with nonzero settings and valid running-engine telemetry.
Whether this feature is active in this profile.
Por que aqui: Enables accessory cues with configured strengths and observed accessory movement.
The strength of this effect.
Mais: a stronger effect.
Menos: a weaker one.
Por que aqui: Sets texture from observed gear movement, separate from aerodynamic and touchdown effects.
| Parâmetro | Valor | O que controla e por quê |
|---|---|---|
| Spring strength | 0.74 | The 28.1 supports passenger and cargo payloads. The baseline spring is 0.74. Its low-speed blend reaches baseline strength at 52.5 KIAS. |
| Force gain | 0.8 | The aerodynamic-load gain is 0.8 with an indicated-speed reference of 105 KIAS. This supplies speed-dependent loading alongside the spring. |
| Elevator force scale | 1.0 | Scales pitch aerodynamic loading; pitch spring travel and trim responses are separate settings. |
| Aileron force scale | 0.72 | Roll and pitch aerodynamic scales are 0.72 and 1, respectively. They set the aerodynamic axis balance. No custom spring-travel curve is enabled. |
| Maximum output force | 0.55 | Caps directed-force output. Native spring effects and device limits remain separate. |
| StickFeel · Elevator authority | 0.3 | The profile uses the trim behaviour configured below. Pitch authority 0.3 provides load relief and permitted centre movement; roll authority is 0. |
| StickFeel · Aileron authority | 0 | Scales supported roll-trim relief and permitted centre movement. Zero removes roll response. |
| Velocidade de ajuste de força | 105 kt | Sets the IAS reference for aerodynamic loading. It is an estimate, not published cruise TAS or a flight limit. |
| Spring deadband | 0.04 | Sets travel around the centre before the baseline spring resists. Smaller values engage it sooner. |
| Master gain | 0.85 | Scales overall profile strength while preserving effect balance, subject to device and output limits. |
| Dynamic-pressure blend | True | Allows baseline spring strength to rise with indicated airspeed where the control law permits it. |
| Minimum spring factor | 0.55 | Sets low-speed spring strength as a fraction of baseline when blending is enabled. One keeps full strength. |
| Spring wake-up speed | 8 kt | Sets the IAS where the low-speed spring blend starts rising. This is a feel threshold, not a flight limit. |
| Spring full-strength speed | 52.5 kt | Sets the IAS where the low-speed blend reaches baseline strength; high-speed stiffening also uses it. |
| Airspeed spring stiffening | 0.15 | The high-speed spring-stiffening gain is 0.15. It strengthens the permitted spring response above 52.5 KIAS, with the squared-speed ratio capped at 5. |
| Airspeed stiffening cap | 5 | Limits the squared airspeed ratio used for high-speed spring stiffening; it is not a device-force cap. |
| StickFeel · Trim feel enabled | False | Retained for compatibility and group membership. Trim relief, rather than this flag, controls centre movement. |
| StickFeel · Trim relief enabled | True | Allows trim relief with supported control law and valid telemetry. Axis authorities set its amount. |
| StickFeel · Force trim enabled | False | Enables local force trim, separate from aircraft-owned trim and add-on integration qualification. |
| StickFeel · G load enabled | True | Allows load-factor changes to modify permitted spring laws. Passive fly-by-wire feel can suppress it. |
| StickFeel · Rate damping enabled | True | Enables rate damping with the configured coefficients and control law. |
| Autopilot · Follow enabled | False | Autopilot following is off; the configured spring and load retain the hardware feel. |
| Autopilot · Follow authority | 0.1 | Sets admitted AP-follow gain, not a percentage of travel. Runtime ownership and input limits still apply. |
| Autopilot · Neutral hold enabled | False | Permits centering hold during a supported AP state, separate from following a moving target. |
| Autopilot · Neutral hold strength | 0.6 | Sets admitted AP neutral-hold strength; inactive while neutral hold is disabled. |
| Aero · Enabled | True | Enables aerodynamic cues; each still needs nonzero strength and its simulator conditions. |
| Aero · Gain | 0.35 | Sets stall-buffet strength. Zero removes the cue without changing simulator stalls or warnings. |
| Aero · Gain | 0 | Sets high-Mach buffet strength; onset and full-strength thresholds are separate. |
| Aero · Gain | 0 | Sets flap buffet at the configured position and speed gates. Flap movement texture is separate. |
| Aero · Max flap index | 3 | Sets the final flap index for detent normalization. UP plus three detents uses maximum index3. |
| Aero · Min flap index | 2 | Sets the first flap detent that admits buffet; this is a handle index, not degrees. |
| Aero · Gain | 0 | Sets gear aerodynamic buffet; movement and ground-contact cues are separate. |
| Aero · Shaker enabled | False | Permits shaker at supported warning conditions; the switch does not establish aircraft equipment. |
| Aero · Amplitude | 0.5 | Sets triggered shaker strength; inactive while the shaker feature is disabled. |
| Ground · Enabled | True | Enables ground effects; each still needs its own strength and contact or motion telemetry. |
| Ground · Gain | 0.4 | Sets rolling texture strength, modified by speed, surface and undercarriage configuration. |
| Ground · Gain | 0.25 | Sets gear-bump texture during ground motion, separate from touchdown impact. |
| Ground · Gain | 0.65 | Sets landing-impact strength; landing telemetry and response shape determine the pulse. |
| Ground · Gain | 0 | Sets reverse-thrust vibration with valid reverser and engine conditions. Zero removes the cue. |
| Engine · Enabled | True | Enables engine cues with nonzero settings and valid running-engine telemetry. |
| Engine · Gain | 0.12 | Sets estimated engine vibration using configured telemetry and response, not measured cockpit vibration. |
| Mechanical · Enabled | True | Enables accessory cues with configured strengths and observed accessory movement. |
| Mechanical · Gain | 0 | Sets texture from observed flap movement; a command without movement does not establish the cue. |
| Mechanical · Gain | 0 | Sets texture from observed gear movement, separate from aerodynamic and touchdown effects. |
Se a sua experiência no tipo diz que esta página errou, corrija aqui.
Esta página é construída com referências citadas, e experiência real no tipo vale mais que citação. Cite a afirmação errada e conte o que a aeronave real faz. As correções vão ao mantenedor para revisão e alimentam a próxima revisão desta pesquisa.
Conversa aberta sobre voar e ajustar o Latecoere 28.1 Wheels, no fórum da comunidade. As correções acima vão em particular ao mantenedor; o papo de hangar é público.