Development milestones
First flight: 2 November 1992 ( 1992-11-02 )
Developed from: Airbus A300
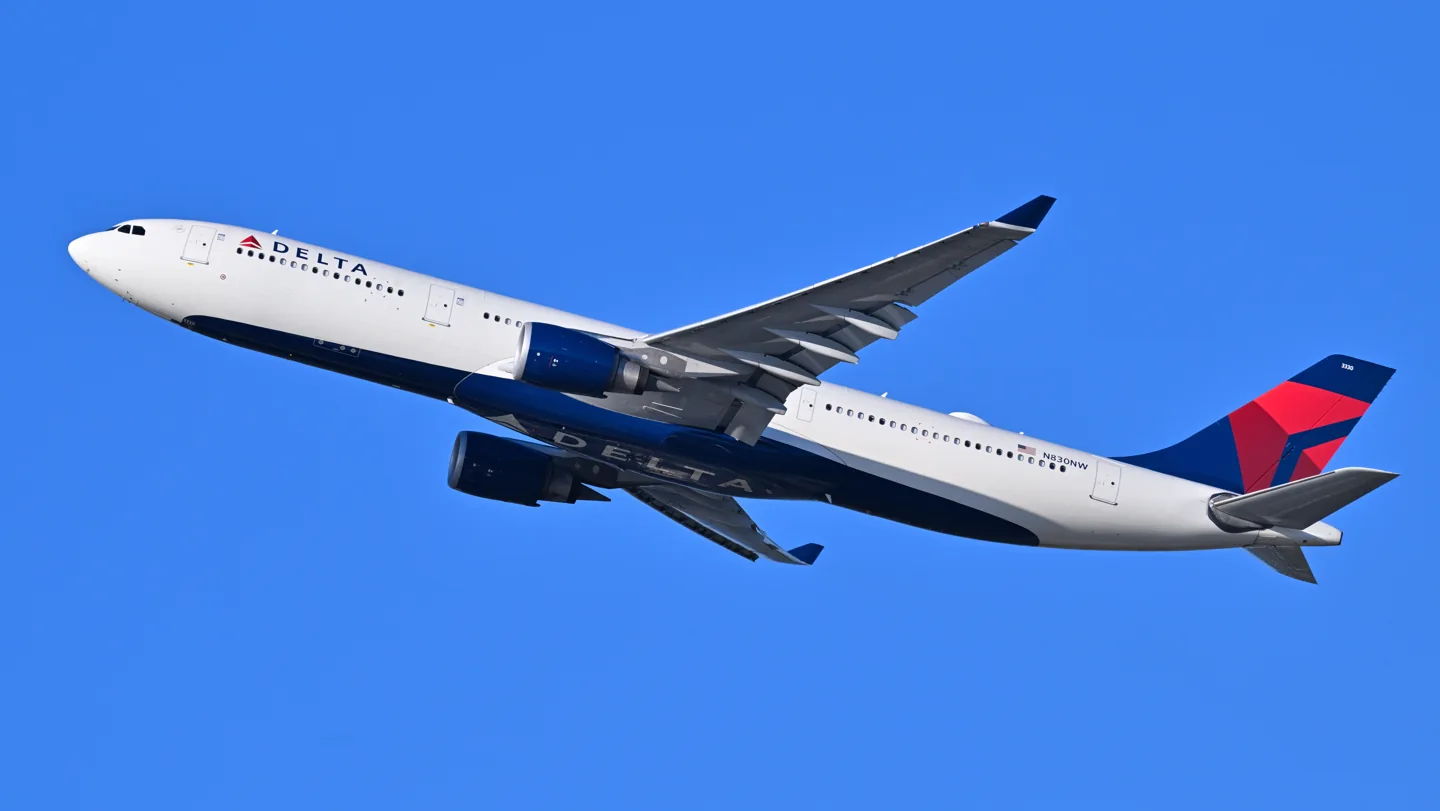 4300streetcar · CC BY 4.0 · Delta Air Lines A330-300
Airbus developed the A330 alongside the four-engine A340. The two programmes shared substantial airframe and cockpit work, but the A330 used two engines. The initial A330-300 entered service in 1994; the shorter A330-200 followed in 1998.
The family includes several engine choices, different fuselage lengths and later A330neo developments. These distinctions reach inside the cockpit: engine indications and fuel arrangements are not identical across every version. The simulator products cover different variants, each with its own developer documentation.
First flight: 2 November 1992 ( 1992-11-02 )
Developed from: Airbus A300
Mirpuri's log describes the preparation behind Hi Fly's A330 mission from Cape Town to Wolf's Fang. The aircraft carried fuel for the return as well as the outward journey, and the team monitored fuel temperature, destination weather and runway condition throughout the flight. Forecast discussions began days beforehand. Ground power and starting equipment at the remote strip were also part of making the twin-engine operation possible.
Four pilots shared the long duty, supported by engineers, cabin crew, a ground coordinator and colleagues at both bases. Mirpuri recalls touching down just before midnight local time, when the Antarctic summer sun was still above the horizon and katabatic winds were beginning to rise. The aircraft stopped as planned, turned and taxied to parking before returning to Cape Town later. His airline-published account stresses the contribution of the whole team to a landing intended to feel uneventful.
Gerzanics flew the A330-800 test aircraft F-WTTO from Toulouse with Airbus test pilot Thomas Wilhelm. Although he did not routinely fly Airbus aircraft, the common cockpit felt familiar. The aircraft was still contributing to flight-control development, and a special display helped him practise the consistent sidestick input needed for the takeoff test. In the air, he found it easy to establish bank angles and roll out accurately on a heading.
On the return, the instrument landing system's glideslope went out of service. Wilhelm suggested using the head-up display while setting up an alternative ground-augmented satellite approach. Gerzanics then assessed the aircraft's response by deliberately offsetting from, and rejoining, the final approach course. He found the response crisp and the landing straightforward. This was an organised evaluation in an instrumented A330-800, including test manoeuvres.
After thirteen years flying the A320 family around Europe, Harder was preparing to return to long-haul work on the A330. He describes receiving the training assignment after applying for a conversion, then working through technical material at home before moving into procedural and full-flight simulators. His Airbus experience shortened part of the training, but the new aircraft still had different systems to learn.
Asked how the A330 felt in the simulator, he noticed a more delayed response to control inputs, reminding him of his earlier experience as a Boeing 747 first officer. He had to allow a little time for the larger aircraft to respond. At the time of the interview, his simulator check and line training still lay ahead. His conversion training took place in the simulator; he had not yet completed his A330 qualification.
Airbus developed the A330 alongside the four-engine A340. The two programmes shared substantial airframe and cockpit work, but the A330 used two engines. The initial A330-300 entered service in 1994; the shorter A330-200 followed in 1998.
This starting point selects Airbus A330-743L Beluga XL. Its aircraft-level settings do not select a particular developer’s custom systems.
The spring stays independent of airspeed. Directed aerodynamic loading is omitted.
Pitch-trim relief is off. Autopilot following is off.
The A330 cockpit uses Airbus sidesticks and fly-by-wire. The bundled manual separates the -200/-300 fuel and trim-tank arrangements, while the Beluga XL has its own flight-control and autopilot guide. A330neo, passenger-to-freighter and corporate configurations retain their model identities. Aircraft trim and autopilot guidance belong to the flight-control system; they do not establish surface-airload feedback through a passive stick.
The gains are normalized profile settings. They describe the chosen effect balance; hand force depends on the device and its output limits. IAS references are tuning values rather than operating limits. Physical acceptance of this revision remains pending.
모델이 만드는 모든 것에 적용되는 최종 전체 출력 스케일로, 장치 상한 이전에 적용됩니다.
올리면: 모든 것(스프링, 하중, 효과)이 함께 강해집니다.
내리면: 모든 것이 함께 부드러워집니다.
이 값의 이유: Scales overall profile strength while preserving effect balance, subject to device and output limits.
스틱을 중앙으로 되돌리는 기본 센터링 힘입니다. 다른 모든 힘이 이 위에 쌓입니다. 너무 낮으면 정상 비행에서 스틱이 흐물거리고, 너무 높으면 손에 맞서며 그 위에 겹쳐진 작은 신호들을 가립니다.
올리면: 손에 더 저항하는 단단한 센터링.
내리면: 공기역학 하중에만 기대는 무른 스틱.
이 값의 이유: Fixed sidestick centering represents the Airbus control arrangement while keeping aircraft control-law behavior separate from hardware resistance. The baseline spring is 0.55. Low-speed spring blending is off.
Cockpit and flight control familiesAirbus A330Airbus Beluga XL중앙 주변에서 스프링이 조용히 머무는 작은 중립 구역으로, 정지 시의 미세한 움직임이 덜컹거리지 않게 합니다. 넓을수록 차분하지만 느슨해지고, 좁을수록 정밀하지만 중앙에서 떨릴 수 있습니다.
올리면: 더 차분하지만 더 느슨한, 유격이 큰 중앙.
내리면: 정지 시 떨릴 수 있는 더 조인 중앙.
이 값의 이유: Sets travel around the centre before the baseline spring resists. Smaller values engage it sooner.
이 값의 이유: The centre preload is 0.03. It ramps outside the 0.01 deadband across 0.05 travel, shaping the passive centre independently of aircraft autotrim.
이 값의 이유: Sets the travel used to ramp in centre preload. Wider intervals make its onset more gradual.
두 지속 축 하중에 걸리는 마스터 스케일로, 각 축의 독립 균형 이전에 적용됩니다. 프로파일은 보통 이것을 두고 두 축 하중을 조정합니다.
올리면: 두 축이 더 강하게 하중을 받습니다.
내리면: 두 축이 함께 가벼워집니다.
이 값의 이유: The stored 0.04 aerodynamic-load gain is inactive under the fixed-centre control law.
저속 스프링 진입 구간(위의 시작/최대 노트)을 켭니다. 끄면 스프링은 모든 속도에서 일정합니다.
이 값의 이유: Allows baseline spring strength to rise with indicated airspeed where the control law permits it.
속도가 공기역학적 힘을 만들기 전, 정지 상태에서 스프링이 얼마나 남는지입니다. 바닥이 높으면 주기된 스틱이 단단하고, 낮으면 주기된 경비행기의 케이블이 늘어진 듯한 느슨한 감각이 됩니다.
올리면: 주기·지상활주 시 더 단단한 스틱.
내리면: 속도로만 깨어나는 주기 시의 무른 스틱.
이 값의 이유: Sets low-speed spring strength as a fraction of baseline when blending is enabled. One keeps full strength.
스프링이 저속 바닥에서 전체 강도를 향해 오르기 시작하는 속도입니다. 이륙 활주에서 조종면이 "살아나는" 지점입니다.
이 값의 이유: Sets the IAS where the low-speed spring blend starts rising. This is a feel threshold, not a flight limit.
스프링이 전체 강도에 도달하는 속도입니다. 시작점과 이 지점 사이에서 조종면 위 기류가 늘며 센터링이 점차 단단해집니다.
이 값의 이유: Sets the IAS where the low-speed blend reaches baseline strength; high-speed stiffening also uses it.
공기역학 하중이 설계된 최대치에 도달하는 지시 속도입니다. 하중 곡선 전체를 기체의 실제 속도 범위에 고정합니다. 172는 110노트에서 하중이 차오르고, 제트기는 훨씬 나중입니다.
올리면: 하중이 늦게 오고, 더 빠른 속도까지 스틱이 가볍습니다.
내리면: 하중이 일찍 오고 순항이 더 무겁습니다.
이 값의 이유: Sets the IAS reference for aerodynamic loading. It is an estimate, not published cruise TAS or a flight limit.
변위 하중에 더해 센터링 자체가 속도에 따라 얼마나 단단해지는지입니다. 0이면 중앙 감각이 일정하고, 클수록 순항에서 더 단단히, 장주에서 더 느슨하게 센터링됩니다.
올리면: 속도에 따라 뚜렷이 단단해지는 중앙.
내리면: 어떤 속도에서도 일정한 중앙 감각.
이 값의 이유: Adds permitted spring resistance above the full-blend speed. Zero removes this high-speed increase.
속도로 인한 중앙 경화의 상한으로, 초고속 비행이 스프링을 무한정 감아올리지 못하게 합니다.
올리면: 고속에서 더 많은 총 경화 허용.
내리면: 경화가 더 일찍 멈춥니다.
이 값의 이유: Limits the squared airspeed ratio used for high-speed spring stiffening; it is not a device-force cap.
에일러론 변위와 속도에 의한 지속적인 롤 하중으로, 피치와 독립적으로 조정됩니다. 승강타 하중과 함께 리뷰에서 말하는 조종 조화 비율을 정합니다.
올리면: 더 무거운 롤 힘.
내리면: 더 가볍고 생기 있는 에일러론.
이 값의 이유: Roll and pitch aerodynamic scales are 1 and 1, respectively. These stored weights do not create directed aerodynamic loading while that term is inactive. The pitch spring-travel curve reaches output 1 at input 1. The roll spring-travel curve reaches output 0.3 at input 1. Spring-travel response contributes separately to axis balance.
승강타 변위와 속도에 의한 지속적인 피치 하중으로, 롤과 독립적으로 조정됩니다. 기종별 피치 무게를 결정하는 주 레버입니다. 에일러론, 스프링, 트림, 버핏 힘에는 관여하지 않습니다.
올리면: 속도에서 더 무거운 지속 피치 힘.
내리면: 붙들기 가벼운, 더 가뿐한 승강타.
이 값의 이유: Scales pitch aerodynamic loading; pitch spring travel and trim responses are separate settings.
각 정상 피치·롤 힘이 장치에 닿기 전의 상한으로, 강한 기동에서 하드웨어를 때리거나 포화시키지 않게 보호합니다.
올리면: 잘리기 전의 더 높은 정상 힘 피크.
내리면: 더 부드러운 상한. 거친 기동이 더 일찍 평평해집니다.
이 값의 이유: Caps directed-force output. Native spring effects and device limits remain separate.
승강타 트림이 유지 중인 피치 힘을 얼마나 덜어내고 스틱이 안착하는 지점을 옮기는지입니다. 100 %에서는 제대로 트림된 기체에 유지 압력이 필요 없어져, 실제 비행의 하중을-트림으로-지우는 절차 그대로입니다.
올리면: 트림이 더 많은 유지 힘을 덜어냅니다. 100 %에서는 완전 트림이 상쇄합니다.
내리면: 트림해도 힘을 계속 붙들게 됩니다.
이 값의 이유: Aircraft automatic trim is independent of the selected passive stick centre; the trim-tank arrangement is not a hardware trim command. Pitch relief is off, with stored authority 0; roll authority is 0.
Cockpit and flight control familiesAirbus A330Airbus Beluga XL롤 트림에 대한 같은 경감입니다. 대부분의 GA 기종에는 실제 에일러론 트림이 없어 0으로 두고, 롤 트림이 있는 기종은 상응하는 값을 받습니다.
올리면: 롤 트림이 더 많은 유지 힘을 덜어냅니다.
내리면: 롤 트림의 효과가 줄어듭니다.
이 값의 이유: Scales supported roll-trim relief and permitted centre movement. Zero removes roll response.
바퀴 속도와 노면 종류(포장, 잔디, 자갈)에 따른 구름 진동입니다.
올리면: 스틱의 노면 질감이 더 강하게.
내리면: 더 매끄러운 지상활주.
이 값의 이유: Sets rolling texture strength, modified by speed, surface and undercarriage configuration.
신축 이음, 바퀴 자국, 거친 노면의 짧고 분리된 충격으로, 연속적인 우르릉거림에 마디를 찍습니다.
올리면: 이음과 자국의 더 또렷한 충격.
내리면: 더 부드러운 지면 디테일.
이 값의 이유: Sets gear-bump texture during ground motion, separate from touchdown impact.
실속 접근 시와 실속 경고가 울리는 동안의 기체 흔들림, 이 날개가 불만을 얼마나 크게 알리는지입니다. 깔끔하게 떨어지는 기종은 버핏을 절제하고 경적이 경고를 맡습니다.
올리면: 더 강한 실속 전 떨림.
내리면: 더 은은한 날개. 경적이 경고를 맡습니다.
이 값의 이유: Sets stall-buffet strength. Zero removes the cue without changing simulator stalls or warnings.
마하 한계 접근 시의 천음속 버핏입니다. MMO 근처의 제트기에는 의미가 있고, 거기 도달하지 못하는 피스톤과 터보프롭은 0입니다.
올리면: 마하 한계 근처의 더 강한 천음속 버핏.
내리면: 높은 마하에서 더 매끄러운 비행.
이 값의 이유: Sets high-Mach buffet strength; onset and full-strength thresholds are separate.
플랩이 실제로 공기를 일하는 속도 창에서, 기류에 펼쳐진 플랩에 의한 기체의 저주파 진동입니다.
올리면: 플랩 작동 중 더 거친 비행.
내리면: 더 부드러운 접근 플랩.
이 값의 이유: Sets flap buffet at the configured position and speed gates. Flap movement texture is separate.
기류에 매달린 접이식 착륙장치에 의한 기체의 북소리입니다. 기체 형상이 변하지 않는 고정식 기종은 0입니다.
올리면: 착륙장치 내림 시 더 많은 북소리.
내리면: 더 깔끔한 착륙장치 내림 비행.
이 값의 이유: Sets gear aerodynamic buffet; movement and ground-contact cues are separate.
기체 자체의 실속 경보 시스템이 발동하는 전용 스틱 셰이커 진동입니다. 실제 셰이커가 있는 기종만 값을 받고, 나머지는 공기역학 버핏과 경적에 의존합니다.
올리면: 더 단단한 셰이커.
내리면: 더 은은한 셰이커.
이 값의 이유: Sets triggered shaker strength; inactive while the shaker feature is disabled.
바퀴가 활주로에 닿는 순간의 단발 충격으로, 강하율에 따라 스케일됩니다. 부드러운 착륙은 속삭이고 단단한 도착은 쿵 울립니다.
올리면: 접지 시 더 단단한 충격.
내리면: 더 부드러운 도착.
이 값의 이유: Sets landing-impact strength; landing telemetry and response shape determine the pulse.
역추력이나 베타 범위 프로펠러가 작동하는 동안의 활주 진동입니다. 리버스가 없는 기종은 0입니다.
올리면: 리버스 중 더 거친 활주.
내리면: 더 은은한 리버스.
이 값의 이유: Sets reverse-thrust vibration with valid reverser and engine conditions. Zero removes the cue.
공회전부터 최대 출력까지 회전수를 따르는 연속적인 동력장치 진동으로, 앞에서 무언가 연료를 태우고 있다는 늘 존재하는 상기입니다.
올리면: 스틱에 더 많은 엔진.
내리면: 더 은은한 엔진.
이 값의 이유: Sets estimated engine vibration using configured telemetry and response, not measured cockpit vibration.
시뮬레이터가 플랩 조종면의 실제 이동을 보고하는 동안만의 연속 진동입니다. 추정 타이머가 아니라 실제 액추에이터 동작과 고장을 따릅니다.
올리면: 플랩 이동 중 더 많은 진동.
내리면: 더 은은한 플랩 이동.
이 값의 이유: Sets texture from observed flap movement; a command without movement does not establish the cue.
자동조종 명령이 스틱을 물리적으로 얼마나 움직일 수 있는지입니다. 움직인 축이 조종사 입력으로 읽힐 수 있는 MSFS에서는 극소로 유지하며, 0이면 따라가기가 완전히 꺼집니다.
올리면: 자동조종이 스틱을 눈에 띄게 더 움직입니다.
내리면: 거의 느껴지지 않는 따라가기.
이 값의 이유: Sets admitted AP-follow gain, not a percentage of travel. Runtime ownership and input limits still apply.
Whether this feature is active in this profile.
이 값의 이유: Applies the configured pitch and roll spring travel curves.
이 값의 이유: Sets response at the second pitch-curve point; it is an endpoint only if its input position is full travel.
이 값의 이유: Sets response at the second roll-curve point; its input position and other points determine the travel law.
Whether this feature is active in this profile.
이 값의 이유: Retained for compatibility and group membership. Trim relief, rather than this flag, controls centre movement.
Whether this feature is active in this profile.
이 값의 이유: Allows trim relief with supported control law and valid telemetry. Axis authorities set its amount.
Whether this feature is active in this profile.
이 값의 이유: Enables local force trim, separate from aircraft-owned trim and add-on integration qualification.
Whether this feature is active in this profile.
이 값의 이유: Allows load-factor changes to modify permitted spring laws. Passive fly-by-wire feel can suppress it.
Whether this feature is active in this profile.
이 값의 이유: Enables rate damping with the configured coefficients and control law.
Whether this feature is active in this profile.
이 값의 이유: Autopilot following is off; the configured spring and load retain the hardware feel. Separate neutral hold is on at strength 0.28, when a supported autopilot state admits it.
Whether this feature is active in this profile.
이 값의 이유: Permits centering hold during a supported AP state, separate from following a moving target.
이 값의 이유: Sets admitted AP neutral-hold strength; inactive while neutral hold is disabled.
Whether this feature is active in this profile.
이 값의 이유: Enables aerodynamic cues; each still needs nonzero strength and its simulator conditions.
Where this effect reaches full strength (or has fully faded, for washouts).
올리면: a more gradual build to a later peak.
내리면: a quicker build.
이 값의 이유: Sets the final flap index for detent normalization. UP plus three detents uses maximum index3.
Where this effect begins fading in.
올리면: the effect begins later.
내리면: it begins earlier.
이 값의 이유: Sets the first flap detent that admits buffet; this is a handle index, not degrees.
Whether this feature is active in this profile.
이 값의 이유: Permits shaker at supported warning conditions; the switch does not establish aircraft equipment.
Whether this feature is active in this profile.
이 값의 이유: Enables ground effects; each still needs its own strength and contact or motion telemetry.
Whether this feature is active in this profile.
이 값의 이유: Enables engine cues with nonzero settings and valid running-engine telemetry.
Whether this feature is active in this profile.
이 값의 이유: Enables accessory cues with configured strengths and observed accessory movement.
The strength of this effect.
올리면: a stronger effect.
내리면: a weaker one.
이 값의 이유: Sets texture from observed gear movement, separate from aerodynamic and touchdown effects.
| 매개변수 | 값 | 제어 대상과 설정 이유 |
|---|---|---|
| Spring strength | 0.55 | Fixed sidestick centering represents the Airbus control arrangement while keeping aircraft control-law behavior separate from hardware resistance. The baseline spring is 0.55. Low-speed spring blending is off. |
| Spring deadband | 0.01 | Sets travel around the centre before the baseline spring resists. Smaller values engage it sooner. |
| Forces · Center starting force | 0.03 | The centre preload is 0.03. It ramps outside the 0.01 deadband across 0.05 travel, shaping the passive centre independently of aircraft autotrim. |
| Forces · Center starting force transition | 0.05 | Sets the travel used to ramp in centre preload. Wider intervals make its onset more gradual. |
| Force gain | 0.04 | The stored 0.04 aerodynamic-load gain is inactive under the fixed-centre control law. |
| Master gain | 0.85 | Scales overall profile strength while preserving effect balance, subject to device and output limits. |
| Dynamic-pressure blend | False | Allows baseline spring strength to rise with indicated airspeed where the control law permits it. |
| Minimum spring factor | 0.5 | Sets low-speed spring strength as a fraction of baseline when blending is enabled. One keeps full strength. |
| Spring wake-up speed | 20 kt | Sets the IAS where the low-speed spring blend starts rising. This is a feel threshold, not a flight limit. |
| Spring full-strength speed | 90 kt | Sets the IAS where the low-speed blend reaches baseline strength; high-speed stiffening also uses it. |
| 포스 조정 속도 | 270.0 kt | Sets the IAS reference for aerodynamic loading. It is an estimate, not published cruise TAS or a flight limit. |
| Airspeed spring stiffening | 0 | Adds permitted spring resistance above the full-blend speed. Zero removes this high-speed increase. |
| Airspeed stiffening cap | 5 | Limits the squared airspeed ratio used for high-speed spring stiffening; it is not a device-force cap. |
| Aileron force scale | 1 | Roll and pitch aerodynamic scales are 1 and 1, respectively. These stored weights do not create directed aerodynamic loading while that term is inactive. The pitch spring-travel curve reaches output 1 at input 1. The roll spring-travel curve reaches output 0.3 at input 1. Spring-travel response contributes separately to axis balance. |
| Elevator force scale | 1 | Scales pitch aerodynamic loading; pitch spring travel and trim responses are separate settings. |
| Maximum output force | 0.55 | Caps directed-force output. Native spring effects and device limits remain separate. |
| SpringResponse · Travel enabled | True | Applies the configured pitch and roll spring travel curves. |
| SpringResponse · Output | 1 | Sets response at the second pitch-curve point; it is an endpoint only if its input position is full travel. |
| SpringResponse · Output | 0.3 | Sets response at the second roll-curve point; its input position and other points determine the travel law. |
| StickFeel · Trim feel enabled | False | Retained for compatibility and group membership. Trim relief, rather than this flag, controls centre movement. |
| StickFeel · Trim relief enabled | False | Allows trim relief with supported control law and valid telemetry. Axis authorities set its amount. |
| StickFeel · Elevator authority | 0 | Aircraft automatic trim is independent of the selected passive stick centre; the trim-tank arrangement is not a hardware trim command. Pitch relief is off, with stored authority 0; roll authority is 0. |
| StickFeel · Aileron authority | 0 | Scales supported roll-trim relief and permitted centre movement. Zero removes roll response. |
| StickFeel · Force trim enabled | False | Enables local force trim, separate from aircraft-owned trim and add-on integration qualification. |
| StickFeel · G load enabled | False | Allows load-factor changes to modify permitted spring laws. Passive fly-by-wire feel can suppress it. |
| StickFeel · Rate damping enabled | False | Enables rate damping with the configured coefficients and control law. |
| Autopilot · Follow enabled | False | Autopilot following is off; the configured spring and load retain the hardware feel. Separate neutral hold is on at strength 0.28, when a supported autopilot state admits it. |
| Autopilot · Follow authority | 0.05 | Sets admitted AP-follow gain, not a percentage of travel. Runtime ownership and input limits still apply. |
| Autopilot · Neutral hold enabled | True | Permits centering hold during a supported AP state, separate from following a moving target. |
| Autopilot · Neutral hold strength | 0.28 | Sets admitted AP neutral-hold strength; inactive while neutral hold is disabled. |
| Aero · Enabled | True | Enables aerodynamic cues; each still needs nonzero strength and its simulator conditions. |
| Aero · Gain | 0.06 | Sets stall-buffet strength. Zero removes the cue without changing simulator stalls or warnings. |
| Aero · Gain | 0.06 | Sets high-Mach buffet strength; onset and full-strength thresholds are separate. |
| Aero · Gain | 0 | Sets flap buffet at the configured position and speed gates. Flap movement texture is separate. |
| Aero · Max flap index | 4 | Sets the final flap index for detent normalization. UP plus three detents uses maximum index3. |
| Aero · Min flap index | 2 | Sets the first flap detent that admits buffet; this is a handle index, not degrees. |
| Aero · Gain | 0 | Sets gear aerodynamic buffet; movement and ground-contact cues are separate. |
| Aero · Shaker enabled | False | Permits shaker at supported warning conditions; the switch does not establish aircraft equipment. |
| Aero · Amplitude | 0.5 | Sets triggered shaker strength; inactive while the shaker feature is disabled. |
| Ground · Enabled | False | Enables ground effects; each still needs its own strength and contact or motion telemetry. |
| Ground · Gain | 0 | Sets rolling texture strength, modified by speed, surface and undercarriage configuration. |
| Ground · Gain | 0 | Sets gear-bump texture during ground motion, separate from touchdown impact. |
| Ground · Gain | 0 | Sets landing-impact strength; landing telemetry and response shape determine the pulse. |
| Ground · Gain | 0 | Sets reverse-thrust vibration with valid reverser and engine conditions. Zero removes the cue. |
| Engine · Enabled | False | Enables engine cues with nonzero settings and valid running-engine telemetry. |
| Engine · Gain | 0 | Sets estimated engine vibration using configured telemetry and response, not measured cockpit vibration. |
| Mechanical · Enabled | True | Enables accessory cues with configured strengths and observed accessory movement. |
| Mechanical · Gain | 0 | Sets texture from observed flap movement; a command without movement does not establish the cue. |
| Mechanical · Gain | 0 | Sets texture from observed gear movement, separate from aerodynamic and touchdown effects. |
실기종 경험상 이 페이지가 틀렸다면 여기서 바로잡아 주세요.
이 페이지는 인용된 자료로 만들어졌지만, 실기종 경험은 인용을 이깁니다. 틀린 주장을 인용하고 실제 기체는 어떤지 알려주세요. 정정은 메인테이너가 검토하며 이 조사의 다음 개정에 반영됩니다.
Airbus A330 family의 비행과 튜닝에 대한 열린 대화(커뮤니티 포럼)입니다. 위의 정정은 메인테이너에게 비공개로 전달되며, 행어 토크는 공개입니다.