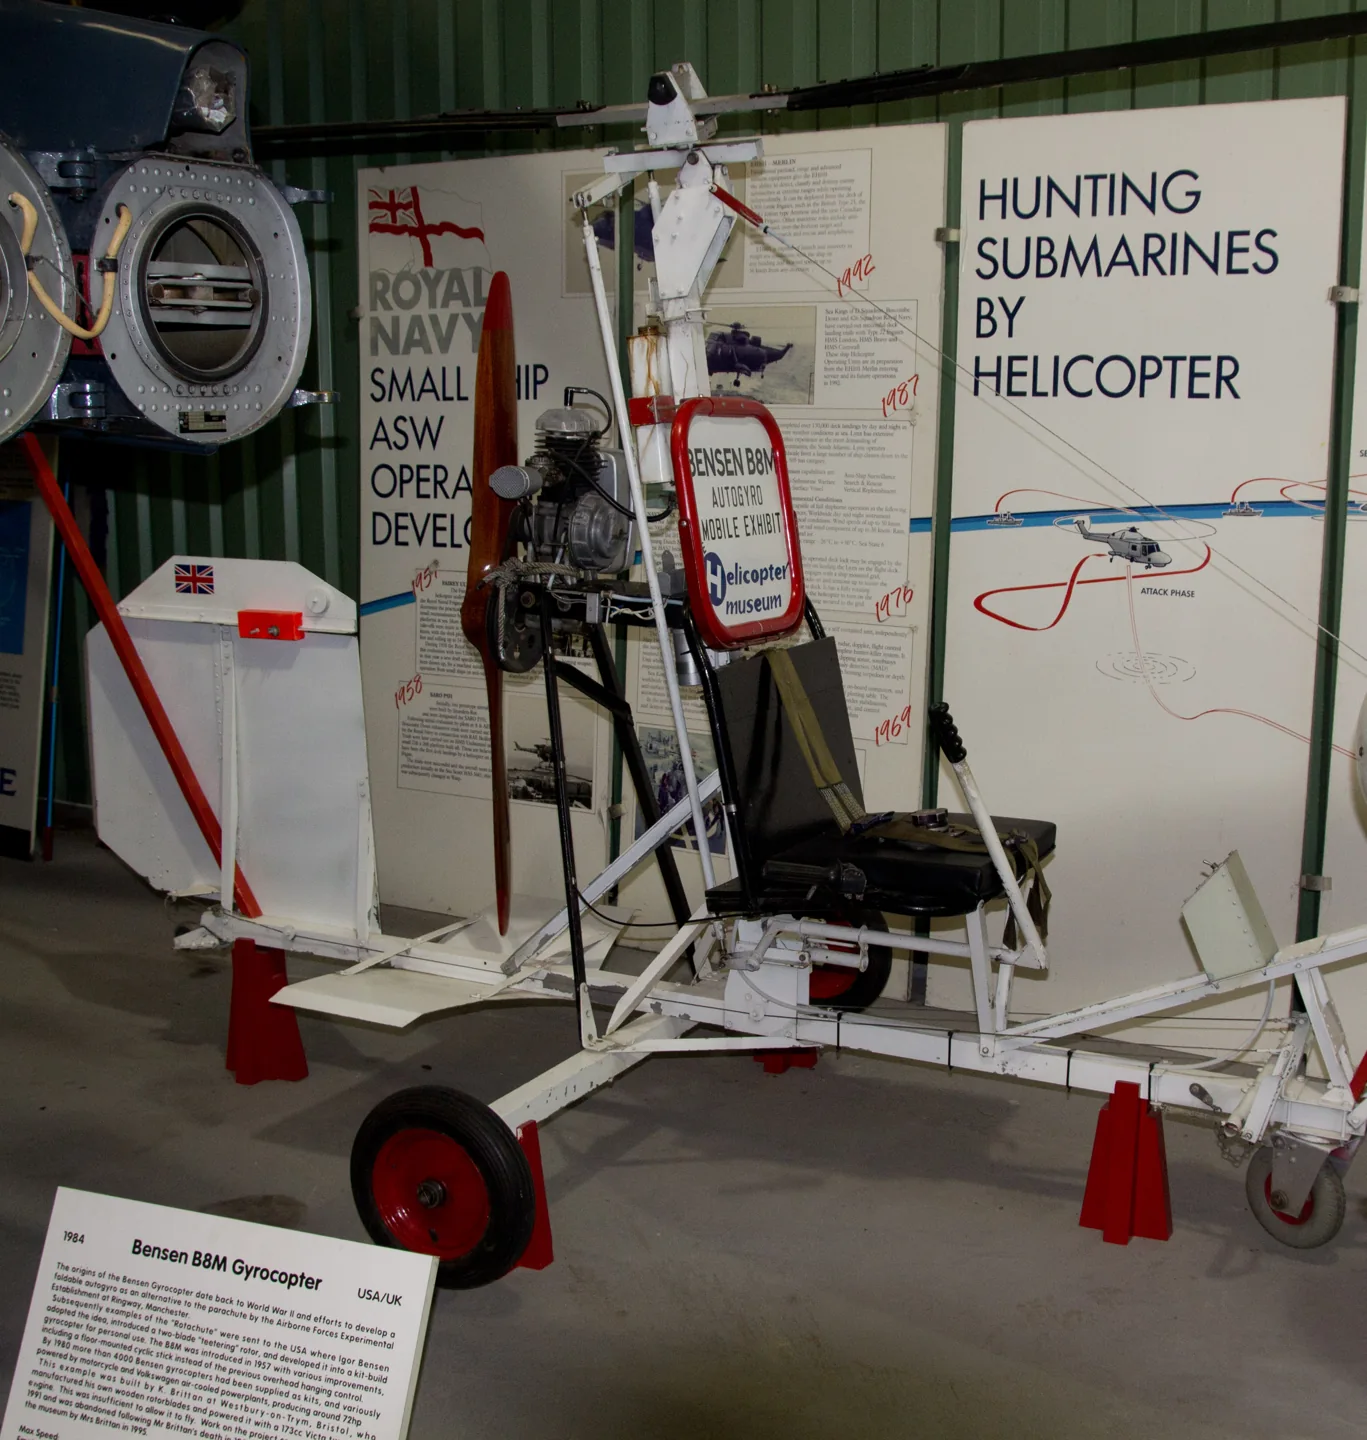
Bensen B-8MTGCP · CC BY-SA 4.0 · Bensen B-8M family reference; the VSKYLABS model incorporates its own modifications.

Bensen B-8M

A small open gyroplane with an unpowered rotor and pusher propulsion.
Gyroplane2 choix de profil

Connaître l'avion

The Bensen B-8M is an open gyroplane design in which the main rotor turns through airflow rather than engine drive. A separate engine and propeller provide forward thrust, while rotor tilt and rudder control the aircraft.

VSKYLABS’ VSL B-8M is a modified interpretation of the design, with a longer tail boom and a 45 hp half-Volkswagen engine. The longer boom and engine installation belong to VSKYLABS' simulated variant.

B-8M museum reference

Length
11 ft 4 in↗
Height
6 ft 3 in↗
Rotor diameter
20 ft 6 in↗
Crew
One↗
Maximum gross mass
435 lb↗
Empty mass
185 lb↗
Engine
McCulloch 4318 piston engine↗

En savoir plus sur cet aéronef sur AirframeDB

Private flying with a rotor

Igor Bensen established his company in 1953 to develop light rotorcraft for private owners. The B-8M was the powered development of the B-8 gyroglider, first flown in 1957. Its small open structure and homebuilt format made it a distinctive route into rotary-wing flying.

Spirit of Kittyhawk

The prototype recreated the speed, distance and duration of the Wrights’ first powered flight for its sixtieth anniversary. Bensen later used it to establish twelve gyroplane records in 1967 and 1968. The aircraft joined the Smithsonian collection in 1969.

The rotor is not the engine-driven propeller

Forward motion supplies airflow through the freely turning rotor. The pusher propeller provides propulsion, while the rotor generates lift by autorotation. Unlike a helicopter, this arrangement does not allow a hover or a vertical takeoff.

Sources publiques 4
  1. VSKYLABS Aerospace Simulations Aircraft Center: VSKYLABS VSL B-8M GyrocopterOfficial developer / designated-store reference · checked 2026-09-14
  2. VSKYLABS B-8M Gyrocopter. Highly Engineered lightweight Gyroplane for X-Plane.Official developer / designated-store reference · checked 2026-09-14
  3. Bensen B-8M GyrocopterSmithsonian B-8M and Spirit of Kittyhawk history
  4. B-8M GyrocopterMarch Field B-8M reference specification; engine options vary

Comment le profil le modélise

Bensen B-8M

Free + Pro
X-Plane 12X-Plane 11

The Bensen B-8M is an open gyroplane design in which the main rotor turns through airflow rather than engine drive. A separate engine and propeller provide forward thrust, while rotor tilt and rudder control the aircraft.

This starting point selects Bensen B-8M. Its aircraft-level settings do not select a particular developer’s custom systems.

The spring stays independent of airspeed. A separate aerodynamic term adds speed-dependent control load.

Pitch-trim relief is off. Autopilot following is off.

Controls and trim

VSKYLABS describes a modified Bensen-inspired gyroplane with a 45-hp half-VW engine and mechanical rotor-head tilt. The engine drives the pusher propeller; the rotor freely autorotates, apart from clutch-driven prerotation. Engine and free-rotor speeds are independent. Its short instructions establish no trim actuator or autopilot, so its spring and damping are nominal hardware feel. This revision also retains speed-dependent directed loading, whose relationship to rotor-head effort is unresolved.

VSKYLABS B-8M InstructionsVSKYLABS VSL B-8M Gyrocopter ProjectVSKYLABS Aerospace Simulations Aircraft Center: VSKYLABS VSL B-8M Gyrocopter

About the values

The gains are normalized profile settings. They describe the chosen effect balance; hand force depends on the device and its output limits. IAS references are tuning values rather than operating limits. Physical acceptance of this revision remains pending.

Master gain & control system

Master gain85%

L'échelle globale finale appliquée à tout ce que produit le modèle, avant la limite du périphérique.

Plus : tout (ressort, charges, effets) se renforce ensemble.

Moins : tout s'adoucit ensemble.

Pourquoi ici : Scales overall profile strength while preserving effect balance, subject to device and output limits.

Forces

Spring strength22%

La force de rappel de base qui ramène le manche au neutre. Toutes les autres forces s'empilent dessus. Trop faible, le manche paraît mou en vol normal ; trop forte, elle lutte contre la main et masque les signaux plus fins.

Plus : un centrage plus ferme qui résiste davantage à la main.

Moins : un manche plus mou qui ne compte que sur la charge aérodynamique.

Pourquoi ici : Nominal centering and damping approximate rotor-head control; this revision also retains a selected speed-dependent directed load. The baseline spring is 0.22. Low-speed spring blending is off.

VSKYLABS B-8M InstructionsVSKYLABS VSL B-8M Gyrocopter ProjectVSKYLABS Aerospace Simulations Aircraft Center: VSKYLABS VSL B-8M Gyrocopter
Spring deadband2%

Une petite zone neutre autour du centre où le ressort reste muet, pour que les micro-mouvements à l'arrêt ne vibrent pas. Plus large, c'est plus calme mais plus lâche ; plus étroite, plus précis mais parfois nerveux au neutre.

Plus : un centre plus calme mais plus lâche, avec plus de jeu.

Moins : un centre plus serré qui peut vibrer au repos.

Pourquoi ici : Sets travel around the centre before the baseline spring resists. Smaller values engage it sooner.

Overall aerodynamic load35%

Une échelle maîtresse sur les deux charges d'axe, appliquée avant leur équilibre individuel. Les profils la laissent en général en place et règlent les deux axes.

Plus : les deux axes chargent plus fort.

Moins : les deux axes s'allègent ensemble.

Pourquoi ici : The aerodynamic-load gain is 0.35 with an indicated-speed reference of 60 KIAS. This supplies speed-dependent loading alongside the spring.

Airspeed blendingFalse

Active la fenêtre d'engagement basse vitesse du ressort (début/plein en nœuds ci-dessus). Désactivé, le ressort est constant à toute vitesse.

Pourquoi ici : Allows baseline spring strength to rise with indicated airspeed where the control law permits it.

Low-speed spring floor100%

La part du ressort qui survit à l'arrêt, avant que la vitesse ne crée la moindre force aérodynamique. Un plancher haut garde le manche ferme au parking ; un plancher bas donne le jeu de câbles d'un avion léger au parking.

Plus : un manche plus ferme au parking et au roulage.

Moins : un manche mou au parking qui ne s'éveille qu'avec la vitesse.

Pourquoi ici : Sets low-speed spring strength as a fraction of baseline when blending is enabled. One keeps full strength.

Spring engagement start8.4 kt

La vitesse à laquelle le ressort quitte son plancher basse vitesse vers la pleine raideur : le début du réveil des commandes au roulage de décollage.

Pourquoi ici : Sets the IAS where the low-speed spring blend starts rising. This is a feel threshold, not a flight limit.

Spring engagement full30.0 kt

La vitesse où le ressort atteint sa pleine raideur. Entre le début et ce point, le centrage se raffermit avec le vent relatif.

Pourquoi ici : Sets the IAS where the low-speed blend reaches baseline strength; high-speed stiffening also uses it.

Vitesse de réglage des forces60

La vitesse indiquée où la charge aérodynamique atteint son niveau de conception. Elle ancre toute la courbe au domaine réel : un 172 charge dès 110 nœuds, un jet bien plus tard.

Plus : les charges arrivent plus tard ; le manche reste léger jusqu'à plus vite.

Moins : les charges arrivent plus tôt et la croisière pèse davantage.

Pourquoi ici : Sets the IAS reference for aerodynamic loading. It is an estimate, not published cruise TAS or a flight limit.

Centre firmness vs speed0%

Combien le centrage lui-même se raidit avec la vitesse, en plus des charges de braquage. Zéro garde un centre constant ; plus fait centrer dur en croisière et souple en tour de piste.

Plus : un centre qui durcit nettement avec la vitesse.

Moins : une sensation de centre constante à toute vitesse.

Pourquoi ici : The high-speed spring-stiffening gain is 0. No additional speed-driven stiffening is added; this does not disable independent aerodynamic loading.

Centre stiffening cap5

La limite haute du raidissement lié à la vitesse, pour que le vol très rapide ne remonte pas le ressort sans borne.

Plus : plus de raidissement total permis à haute vitesse.

Moins : le raidissement se bride plus tôt.

Pourquoi ici : Limits the squared airspeed ratio used for high-speed spring stiffening; it is not a device-force cap.

Aileron load22%

La charge de roulis soutenue issue du braquage d'ailerons et de la vitesse, équilibrée indépendamment du tangage. Avec la charge de profondeur, elle fixe l'harmonie des commandes dont parlent les essais.

Plus : des efforts de roulis plus lourds.

Moins : des ailerons plus légers, plus vifs.

Pourquoi ici : Roll and pitch aerodynamic scales are 0.22 and 0.22, respectively. They set the aerodynamic axis balance. No custom spring-travel curve is enabled.

Elevator load22%

La charge de tangage soutenue issue du braquage de profondeur et de la vitesse, équilibrée indépendamment du roulis. Le levier principal du poids en tangage d'un type. Il ne touche ni ailerons, ni ressort, ni trim, ni buffet.

Plus : des efforts de tangage soutenus plus lourds en vitesse.

Moins : une profondeur plus légère, moins musclée à tenir.

Pourquoi ici : Scales pitch aerodynamic loading; pitch spring travel and trim responses are separate settings.

Max output force55%

Un plafond par force stable de tangage ou roulis avant le périphérique : la garde contre le claquement ou la saturation du matériel en manœuvre forte.

Plus : des pics de force stable plus élevés avant écrêtage.

Moins : un plafond plus doux ; les manœuvres dures s'aplatissent plus tôt.

Pourquoi ici : Caps directed-force output. Native spring effects and device limits remain separate.

Trim

Trim relief (elevator)30%

Combien le trim de profondeur soulage l'effort tenu et déplace le point de repos du manche. À 100 %, un avion bien compensé ne demande aucune pression : le geste réel de compenser la charge.

Plus : le trim retire plus d'effort tenu ; à 100 %, plein trim l'annule.

Moins : vous continuez à tenir de l'effort même compensé.

Pourquoi ici : Hardware trim displacement is omitted because the selected instructions do not establish an adjustable trim mechanism. Pitch relief is off, with stored authority 0.3; roll authority is 0.3.

VSKYLABS B-8M InstructionsVSKYLABS VSL B-8M Gyrocopter ProjectVSKYLABS Aerospace Simulations Aircraft Center: VSKYLABS VSL B-8M Gyrocopter
Trim relief (aileron)30%

Le même soulagement pour le trim de roulis. La plupart des avions légers n'ont pas de vrai trim d'ailerons, donc zéro ; les types qui en ont reçoivent une valeur adaptée.

Plus : le trim de roulis retire plus d'effort tenu.

Moins : le trim de roulis fait moins.

Pourquoi ici : Scales supported roll-trim relief and permitted centre movement. Zero removes roll response.

Effect gains · Ground

Runway rumble15%

Vibration de roulement issue de la vitesse des roues et du revêtement : la texture du bitume, de l'herbe ou du gravier sous le train.

Plus : une texture de surface plus forte dans le manche.

Moins : un roulage plus lisse.

Pourquoi ici : Sets rolling texture strength, modified by speed, surface and undercarriage configuration.

Gear bumps0%

Chocs courts et distincts des joints, ornières et surfaces rugueuses : la ponctuation au-dessus du grondement continu.

Plus : des chocs plus nets des joints et ornières.

Moins : des détails de sol plus doux.

Pourquoi ici : Sets gear-bump texture during ground motion, separate from touchdown impact.

Effect gains · Airframe

Stall buffet0%

Buffet de cellule à l'approche du décrochage et pendant l'avertisseur : la voix de cette aile quand elle est mécontente. Les types à décrochage franc reçoivent un buffet modéré, le klaxon porte l'alerte.

Plus : un tremblement pré-décrochage plus fort.

Moins : une aile plus discrète ; le klaxon porte l'alerte.

Pourquoi ici : Sets stall-buffet strength. Zero removes the cue without changing simulator stalls or warnings.

Mach buffet0%

Buffet transsonique près de la limite de Mach. Parlant pour les jets près de MMO, zéro pour pistons et turbopropulseurs qui n'y vont jamais.

Plus : un buffet transsonique plus fort près de la limite de Mach.

Moins : un vol plus lisse à haut Mach.

Pourquoi ici : Sets high-Mach buffet strength; onset and full-strength thresholds are separate.

Flap buffet0%

Vibration basse fréquence de cellule avec les volets dans le vent, dans la fenêtre où ils travaillent vraiment l'air.

Plus : un vol plus rugueux volets au travail.

Moins : des volets d'approche plus doux.

Pourquoi ici : Sets flap buffet at the configured position and speed gates. Flap movement texture is separate.

Gear buffet0%

Le tambourinement du train rentrant sorti dans le flux. Zéro pour les trains fixes, dont la cellule ne change jamais de forme.

Plus : plus de tambourinement train sorti.

Moins : un vol train sorti plus propre.

Pourquoi ici : Sets gear aerodynamic buffet; movement and ground-contact cues are separate.

Stick shaker50%

Le vibreur de manche dédié, déclenché par l'avertisseur de décrochage de l'avion. Seuls les types à vrai vibreur reçoivent une valeur ; les autres comptent sur buffet et klaxon.

Plus : un vibreur plus dur.

Moins : un vibreur plus discret.

Pourquoi ici : Sets triggered shaker strength; inactive while the shaker feature is disabled.

Effect gains · Engine, mechanical & drag

Touchdown thump50%

Le coup unique au toucher, proportionnel au taux de chute : un kiss se murmure, une arrivée ferme cogne.

Plus : un coup plus dur au toucher.

Moins : des arrivées plus douces.

Pourquoi ici : Sets landing-impact strength; landing telemetry and response shape determine the pulse.

Reverse rumble0%

Vibration de roulage sous inversion de poussée ou plage bêta. Zéro pour les types sans reverse.

Plus : un roulage plus rugueux sous reverse.

Moins : une reverse plus discrète.

Pourquoi ici : Sets reverse-thrust vibration with valid reverser and engine conditions. Zero removes the cue.

Engine rumble12%

Vibration continue du moteur suivant le régime du ralenti à la pleine puissance : le rappel permanent que quelque chose brûle du carburant devant.

Plus : plus de moteur dans le manche.

Moins : un moteur plus discret.

Pourquoi ici : Sets estimated engine vibration using configured telemetry and response, not measured cockpit vibration.

Flap motion0%

Vibration continue seulement pendant que le simulateur signale les volets réellement en mouvement. Elle suit la course réelle et les pannes, pas un minuteur estimé.

Plus : plus de vibration volets en mouvement.

Moins : des courses de volets plus discrètes.

Pourquoi ici : Sets texture from observed flap movement; a command without movement does not establish the cue.

Autopilot follow

AP follow authority5%

Jusqu'où les ordres du pilote automatique peuvent bouger le manche physique. Minuscule dans MSFS, où un axe déplacé peut être relu comme entrée pilote ; zéro coupe le suivi.

Plus : le pilote automatique bouge visiblement plus votre manche.

Moins : un suivi à peine perceptible.

Pourquoi ici : Sets admitted AP-follow gain, not a percentage of travel. Runtime ownership and input limits still apply.

Stick feel

StickFeel · Trim feel enabledFalse

Whether this feature is active in this profile.

Pourquoi ici : Retained for compatibility and group membership. Trim relief, rather than this flag, controls centre movement.

StickFeel · Trim relief enabledFalse

Whether this feature is active in this profile.

Pourquoi ici : Allows trim relief with supported control law and valid telemetry. Axis authorities set its amount.

StickFeel · Force trim enabledFalse

Whether this feature is active in this profile.

Pourquoi ici : Enables local force trim, separate from aircraft-owned trim and add-on integration qualification.

StickFeel · G load enabledFalse

Whether this feature is active in this profile.

Pourquoi ici : Allows load-factor changes to modify permitted spring laws. Passive fly-by-wire feel can suppress it.

StickFeel · Rate damping enabledTrue

Whether this feature is active in this profile.

Pourquoi ici : Enables rate damping with the configured coefficients and control law.

Autopilot

Autopilot · Follow enabledFalse

Whether this feature is active in this profile.

Pourquoi ici : Autopilot following is off; the configured spring and load retain the hardware feel.

Autopilot · Neutral hold enabledFalse

Whether this feature is active in this profile.

Pourquoi ici : Permits centering hold during a supported AP state, separate from following a moving target.

Autopilot · Neutral hold strength0.6

Pourquoi ici : Sets admitted AP neutral-hold strength; inactive while neutral hold is disabled.

Aero

Aero · EnabledTrue

Whether this feature is active in this profile.

Pourquoi ici : Enables aerodynamic cues; each still needs nonzero strength and its simulator conditions.

Aero · Max flap index1

Where this effect reaches full strength (or has fully faded, for washouts).

Plus : a more gradual build to a later peak.

Moins : a quicker build.

Pourquoi ici : Sets the final flap index for detent normalization. UP plus three detents uses maximum index3.

Aero · Min flap index1

Where this effect begins fading in.

Plus : the effect begins later.

Moins : it begins earlier.

Pourquoi ici : Sets the first flap detent that admits buffet; this is a handle index, not degrees.

Aero · Shaker enabledFalse

Whether this feature is active in this profile.

Pourquoi ici : Permits shaker at supported warning conditions; the switch does not establish aircraft equipment.

Ground

Ground · EnabledTrue

Whether this feature is active in this profile.

Pourquoi ici : Enables ground effects; each still needs its own strength and contact or motion telemetry.

Engine

Engine · EnabledTrue

Whether this feature is active in this profile.

Pourquoi ici : Enables engine cues with nonzero settings and valid running-engine telemetry.

Mechanical

Mechanical · EnabledTrue

Whether this feature is active in this profile.

Pourquoi ici : Enables accessory cues with configured strengths and observed accessory movement.

Mechanical · Gain0

The strength of this effect.

Plus : a stronger effect.

Moins : a weaker one.

Pourquoi ici : Sets texture from observed gear movement, separate from aerodynamic and touchdown effects.

Tous les réglages du profil
Réglages estimés du profil
ParamètreValeurCe que cela contrôle et pourquoi
Spring strength0.22 Nominal centering and damping approximate rotor-head control; this revision also retains a selected speed-dependent directed load. The baseline spring is 0.22. Low-speed spring blending is off.
Spring deadband0.02 Sets travel around the centre before the baseline spring resists. Smaller values engage it sooner.
Force gain0.35 The aerodynamic-load gain is 0.35 with an indicated-speed reference of 60 KIAS. This supplies speed-dependent loading alongside the spring.
Master gain0.85 Scales overall profile strength while preserving effect balance, subject to device and output limits.
Dynamic-pressure blendFalse Allows baseline spring strength to rise with indicated airspeed where the control law permits it.
Minimum spring factor1 Sets low-speed spring strength as a fraction of baseline when blending is enabled. One keeps full strength.
Spring wake-up speed8.4 ktSets the IAS where the low-speed spring blend starts rising. This is a feel threshold, not a flight limit.
Spring full-strength speed30.0 ktSets the IAS where the low-speed blend reaches baseline strength; high-speed stiffening also uses it.
Vitesse de réglage des forces60.0 ktSets the IAS reference for aerodynamic loading. It is an estimate, not published cruise TAS or a flight limit.
Airspeed spring stiffening0 The high-speed spring-stiffening gain is 0. No additional speed-driven stiffening is added; this does not disable independent aerodynamic loading.
Airspeed stiffening cap5 Limits the squared airspeed ratio used for high-speed spring stiffening; it is not a device-force cap.
Aileron force scale0.22 Roll and pitch aerodynamic scales are 0.22 and 0.22, respectively. They set the aerodynamic axis balance. No custom spring-travel curve is enabled.
Elevator force scale0.22 Scales pitch aerodynamic loading; pitch spring travel and trim responses are separate settings.
Maximum output force0.55 Caps directed-force output. Native spring effects and device limits remain separate.
StickFeel · Trim feel enabledFalse Retained for compatibility and group membership. Trim relief, rather than this flag, controls centre movement.
StickFeel · Trim relief enabledFalse Allows trim relief with supported control law and valid telemetry. Axis authorities set its amount.
StickFeel · Elevator authority0.3 Hardware trim displacement is omitted because the selected instructions do not establish an adjustable trim mechanism. Pitch relief is off, with stored authority 0.3; roll authority is 0.3.
StickFeel · Aileron authority0.3 Scales supported roll-trim relief and permitted centre movement. Zero removes roll response.
StickFeel · Force trim enabledFalse Enables local force trim, separate from aircraft-owned trim and add-on integration qualification.
StickFeel · G load enabledFalse Allows load-factor changes to modify permitted spring laws. Passive fly-by-wire feel can suppress it.
StickFeel · Rate damping enabledTrue Enables rate damping with the configured coefficients and control law.
Autopilot · Follow enabledFalse Autopilot following is off; the configured spring and load retain the hardware feel.
Autopilot · Follow authority0.05 Sets admitted AP-follow gain, not a percentage of travel. Runtime ownership and input limits still apply.
Autopilot · Neutral hold enabledFalse Permits centering hold during a supported AP state, separate from following a moving target.
Autopilot · Neutral hold strength0.6 Sets admitted AP neutral-hold strength; inactive while neutral hold is disabled.
Aero · EnabledTrue Enables aerodynamic cues; each still needs nonzero strength and its simulator conditions.
Aero · Gain0 Sets stall-buffet strength. Zero removes the cue without changing simulator stalls or warnings.
Aero · Gain0 Sets high-Mach buffet strength; onset and full-strength thresholds are separate.
Aero · Gain0 Sets flap buffet at the configured position and speed gates. Flap movement texture is separate.
Aero · Max flap index1 Sets the final flap index for detent normalization. UP plus three detents uses maximum index3.
Aero · Min flap index1 Sets the first flap detent that admits buffet; this is a handle index, not degrees.
Aero · Gain0 Sets gear aerodynamic buffet; movement and ground-contact cues are separate.
Aero · Shaker enabledFalse Permits shaker at supported warning conditions; the switch does not establish aircraft equipment.
Aero · Amplitude0.5 Sets triggered shaker strength; inactive while the shaker feature is disabled.
Ground · EnabledTrue Enables ground effects; each still needs its own strength and contact or motion telemetry.
Ground · Gain0.15 Sets rolling texture strength, modified by speed, surface and undercarriage configuration.
Ground · Gain0 Sets gear-bump texture during ground motion, separate from touchdown impact.
Ground · Gain0.5 Sets landing-impact strength; landing telemetry and response shape determine the pulse.
Ground · Gain0 Sets reverse-thrust vibration with valid reverser and engine conditions. Zero removes the cue.
Engine · EnabledTrue Enables engine cues with nonzero settings and valid running-engine telemetry.
Engine · Gain0.12 Sets estimated engine vibration using configured telemetry and response, not measured cockpit vibration.
Mechanical · EnabledTrue Enables accessory cues with configured strengths and observed accessory movement.
Mechanical · Gain0 Sets texture from observed flap movement; a command without movement does not establish the cue.
Mechanical · Gain0 Sets texture from observed gear movement, separate from aerodynamic and touchdown effects.
Sources publiques 6
  1. VSKYLABS Aerospace Simulations Aircraft Center: VSKYLABS VSL B-8M GyrocopterOfficial developer / designated-store reference ·Official developer / designated-store reference · checked 2026-09-14
  2. VSKYLABS B-8M InstructionsDeveloper POH selected systems and control paragraphs; flight controls and configuration
  3. VSKYLABS VSL B-8M Gyrocopter ProjectCurrent XP12 store product
  4. VSKYLABS B-8M Gyrocopter. Highly Engineered lightweight Gyroplane for X-Plane.Official developer / designated-store reference · checked 2026-09-14
  5. Bensen B-8M GyrocopterSmithsonian B-8M and Spirit of Kittyhawk history
  6. B-8M GyrocopterMarch Field B-8M reference specification; engine options vary

Communauté et corrections

Si votre expérience du type dit que cette page se trompe, corrigez-la ici.

Corrections de pilotes

Vous volez sur cet appareil ? Corrigez cette page.

Cette page repose sur des références citées, et l'expérience réelle du type vaut mieux qu'une citation. Citez l'affirmation erronée et dites-nous ce que fait l'appareil réel. Les corrections vont au mainteneur pour examen et nourrissent la prochaine révision de cette recherche.

Discussions de hangar

Conversation ouverte sur le pilotage et le réglage du Bensen B-8M, sur le forum communautaire. Les corrections ci-dessus vont en privé au mainteneur ; les discussions de hangar sont publiques.

Pas encore de discussion de hangar sur le Bensen B-8M. Lancez-la.

Communauté

Profils communautaires pour cet appareil

Pas encore de profils communautaires pour cet appareil. Réglé à votre façon ? Partagez un profil et il apparaîtra ici.