FlugzeugbibliothekEurocopter EC135
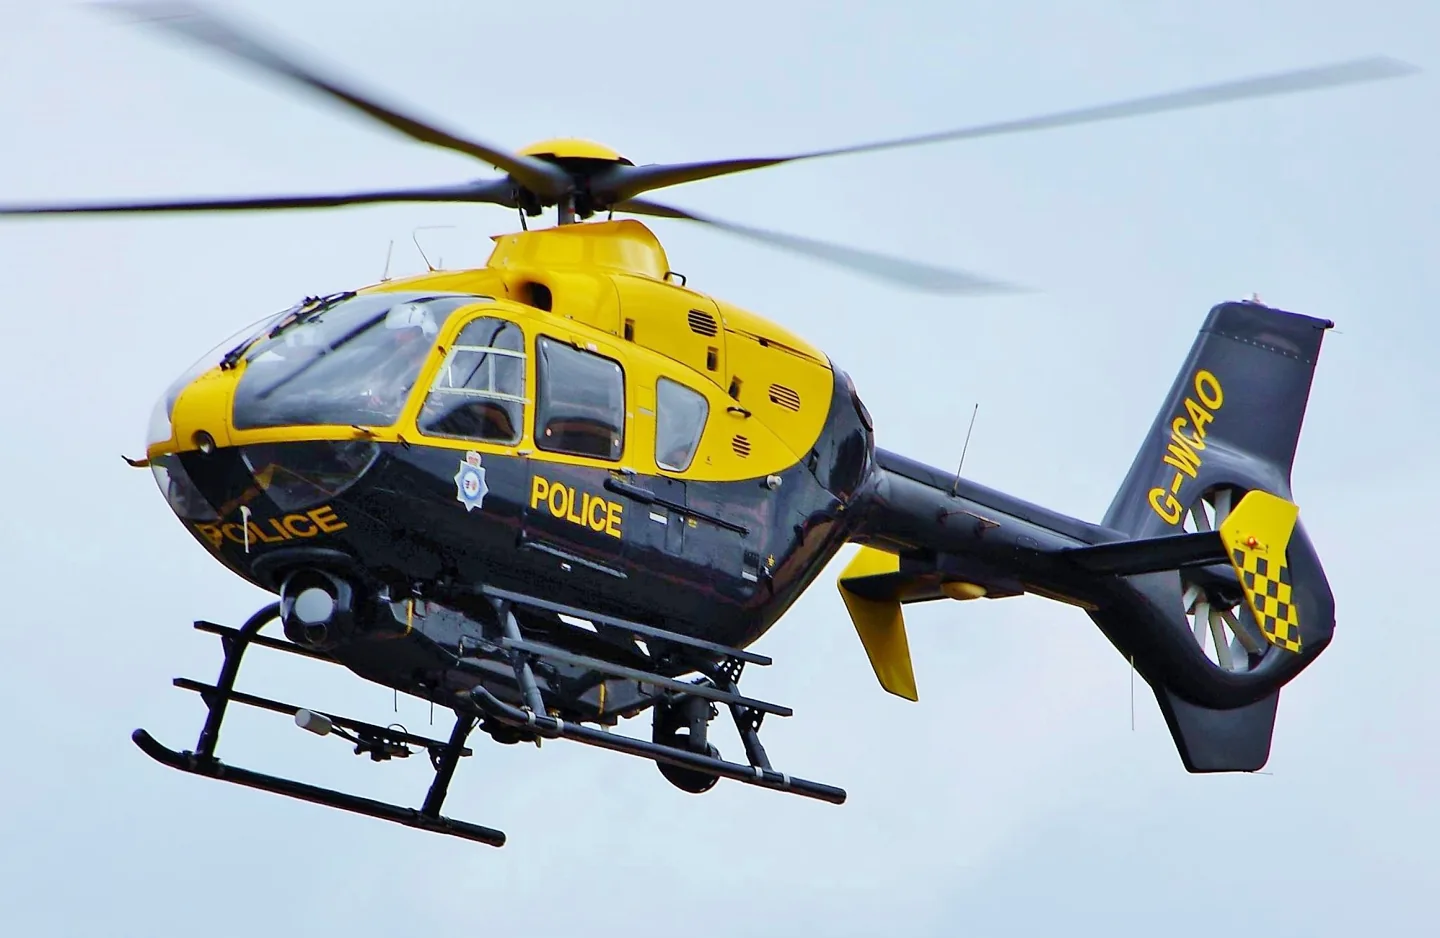
Eurocopter EC135Tim Felce (Airwolfhound) · CC BY-SA 2.0 · Eurocopter EC135 pictured

Eurocopter EC135

A compact twin-engine helicopter widely used for medical, police and training work.
Helicopter3 Profiloptionen

Kenne das Flugzeug

The EC135, later renamed H135, developed from the MBB Bo 108 programme. Its enclosed tail rotor, twin turbines and practical cabin made it a useful platform for emergency services and other operators. The type first flew in 1994 and entered service in 1996.

The H135 name covers later development of the same lineage. Mission interiors, avionics and flight-control equipment differ between operators and versions. The photograph depicts a medical installation; simulator documentation identifies the included mission equipment.

Aircraft / family

Propulsion
Twin turboshaft↗
Configuration
Utility / medical / training↗

Eurocopter EC135 · Specifications (EC135 P2+/T2+) · real aircraft; source units retained

Length
10.2 m (33 ft 6 in)↗
Height
3.51 m (11 ft 6 in)↗
Empty weight
1,455 kg (3,208 lb)↗
Max takeoff weight
2,910 kg (6,415 lb)↗
Powerplant
2 × Turbomeca Arrius 2B2 turboshaft engines, 472 kW (633 hp) each or 2 × Pratt & Whitney Canada PW206B turboshaft engines rated at 463 kW (621 hp) (take-off power)↗
Main rotor diameter
10.2 m (33 ft 6 in)↗
Main rotor area
81.7 m² (879 sq ft)↗
Cruise speed
254 km/h (158 mph, 137 kn)↗
Range
635 km (395 mi, 343 nmi)↗
Service ceiling
6,096 m (20,000 ft)↗

Mehr über dieses Flugzeug auf AirframeDB

The H135 changes its cockpit while retaining its identity

Duke’s 2017 report places Helionix after the earlier P3/T3 performance improvements. His evaluation deliberately concentrates on displays and automation, distinguishing a cockpit transition from a new engine or increased carrying capacity.

A simulator developer discovers what hovering feels like

Meyer’s visit began with measurements on the ground for an X-Plane project. Flying the real EC135 was the next step, and he was conscious that his own experience was in aeroplanes. The glass surrounding the cockpit made the view both spectacular and slightly unsettling as the chief pilot introduced him to the aircraft.

Once given the controls, he found forward flight manageable but hovering much more demanding. The instructor intervened when the aircraft’s motion exceeded Meyer’s ability to contain it, then gave him further opportunities to try. He came away with aching hands, excitement and observations he wanted to bring back to the simulator. His exuberant account is a personal learning experience; its explanations and claims about simulator transfer are not independent validation of a flight model.

Learning to trust a quieter instrument scan

Duke wanted to understand what the new displays and automation added to an established helicopter. During the brief start, Neuhaus explained a cockpit that brought abnormal trends to the pilot’s attention instead of requiring constant checks of scattered gauges. Duke had to adjust to the absence of familiar indications before appreciating the spare attention it created.

The flight included a confined-area approach and experiments with different levels of autopilot assistance. The display was easy to interpret, but Duke remained cautious about judging tail clearance through a camera image. An automated approach completed the return to Donauwörth. His evaluation focuses on how the pilot interacts with the equipment, preserving both the features he enjoyed and the particular task for which he preferred a more cautious judgment.

Trying the updated helicopter at its intended test weight

Gray arrived curious about how far the EC135 family had developed since the magazine’s earlier evaluation. The team planned the fuel load so that his first hover would take place at the intended maximum weight despite time spent briefing on the ground. Even accepting the aircraft involved a detail he appreciated: an electronic system linking the pilot’s acceptance to the technician’s sign-off.

In flight, Gray tried the handling and followed Neuhaus through more energetic manoeuvres. He found the power indications easy to interpret and the cockpit comfortable to work in. The return demonstrated an automated approach and hover before Gray took control for the landing. His overall impression was of considerable complexity made accessible to the pilot. The report did not include an autorotation or a passenger-cabin evaluation.

Öffentliche Quellen 10
  1. Eurocopter EC135Research background · Wikipedia revision 1373321906 · retrieved 2026-09-12
  2. Microsoft Flight Simulator aircraft manuals
  3. EC135 free for MSFS 2024 owners
  4. H135 freewareOfficial developer / designated store catalogue · checked 2026-09-12
  5. The Magical FishbowlAustin Meyer · July 2002
  6. Glass of its Own: H135Jon Duke · 21 July 2017
  7. Continually improvingPeter Gray · 29 November–5 December 2016; archived magazine pages
  8. ICAO Doc 8643 — aircraft type designatorsPublic search data retrieved 2026-09-14; authority update 2026-09-03
  9. Airbus H135 v1.4 release notesSteve Daniels · 26 July 2021Product listing captured 2026-09-30; edition scope from the reviewed catalogue
  10. rotorsim – Das Portal für die HubschraubersimulationProduct listing captured 2026-09-23; edition scope from the reviewed catalogue

Wie das Profil es modelliert

Eurocopter EC135

Free + Pro
MSFS 2024MSFS 2020

The EC135, later renamed H135, developed from the MBB Bo 108 programme. Its enclosed tail rotor, twin turbines and practical cabin made it a useful platform for emergency services and other operators. The type first flew in 1994 and entered service in 1996.

This starting point selects Eurocopter EC135. Its aircraft-level settings do not select a particular developer’s custom systems.

The cyclic response works around an aircraft-owned neutral where the integration provides it. Spring resistance builds with the selected airspeed response. A separate aerodynamic term adds speed-dependent control load. Cyclic damping adds resistance to hardware motion.

Plugin-written trim describes the control neutral, separately from AP engagement. Local force trim is off. Autopilot following is off.

About the values

The gains are normalized profile settings. They describe the chosen effect balance; hand force depends on the device and its output limits. IAS references are tuning values rather than operating limits. Physical acceptance of this revision remains pending.

Master gain & control system

Master gain85%

Die letzte Gesamtskalierung über alles, was das Modell erzeugt, vor der Gerätegrenze.

Mehr: alles (Feder, Lasten, Effekte) wird gemeinsam stärker.

Weniger: alles wird gemeinsam weicher.

Warum hier: Scales overall profile strength while preserving effect balance, subject to device and output limits.

Forces

Spring strength0%

Die Grundzentrierkraft, die den Stick zur Mitte zieht. Jede andere Kraft baut darauf auf. Zu niedrig fühlt sich der Stick im Normalflug schlaff an; zu hoch kämpft er gegen deine Hand und überdeckt die feineren Signale.

Mehr: festere Zentrierung, die der Hand jederzeit mehr widersteht.

Weniger: ein schlafferer Stick, der sich allein auf die aerodynamische Last stützt.

Warum hier: The cyclic response works around an aircraft-owned neutral where the integration provides it. The baseline spring is 0. Its low-speed blend reaches baseline strength at 60 KIAS.

H135 build447 guide based on HPG guidewww.rotorsim.deDeveloper controls, versions and configuration documentationDeveloper controls, versions and configuration documentationDeveloper controls, versions and configuration documentationDeveloper controls, versions and configuration documentationPublished EC135 MOZA preset, location from supplied updater configuration and installation guideOfficial dataref catalog JSONEC135 original updater skunkcrafts_updater.cfgEC1355.36 original plugins/ec135/lin.xplEC1355.36 original plugins/ec135/win.xplEC135 published original file CRCsAirbus H135 v1.4 release notesH135 freeware
Spring deadband2%

Eine kleine neutrale Zone um die Mitte, in der die Feder ruhig bleibt, damit kleinste Bewegungen im Stand nicht flattern. Breiter ist ruhiger, aber lockerer; enger ist präziser, kann aber um die Mitte zittern.

Mehr: eine ruhigere, aber lockerere Mitte mit mehr Spiel.

Weniger: eine straffere Mitte, die in Ruhe zittern kann.

Warum hier: Sets travel around the centre before the baseline spring resists. Smaller values engage it sooner.

Overall aerodynamic load35%

Ein Gesamtmaß über beide anhaltenden Achslasten, vor ihrer Einzelbalance angewendet. Profile lassen es normalerweise stehen und stimmen die beiden Achslasten ab.

Mehr: beide Achsen laden härter auf.

Weniger: beide Achsen werden gemeinsam leichter.

Warum hier: The aerodynamic-load gain is 0.35 with an indicated-speed reference of 120 KIAS. This supplies speed-dependent loading alongside the spring.

Airspeed blendingTrue

Aktiviert das Niedrigfahrt-Einblendfenster der Feder (Beginn/Voll in Knoten oben). Aus bleibt die Feder bei jeder Fahrt konstant.

Warum hier: Allows baseline spring strength to rise with indicated airspeed where the control law permits it.

Low-speed spring floor100%

Wie viel Feder im Stillstand übrig bleibt, bevor Fahrt überhaupt aerodynamische Kraft aufbauen kann. Ein hoher Sockel hält den geparkten Stick straff; ein niedriger ergibt das lose Seilzuggefühl eines geparkten Leichtflugzeugs.

Mehr: ein festerer Stick beim Parken und Rollen.

Weniger: ein schlaffer geparkter Stick, der erst mit Fahrt aufwacht.

Warum hier: Sets low-speed spring strength as a fraction of baseline when blending is enabled. One keeps full strength.

Spring engagement start16.8 kt

Die Fahrt, ab der die Feder vom Niedrigfahrt-Sockel Richtung volle Stärke steigt: der Beginn des "Lebendigwerdens" der Ruder im Startlauf.

Warum hier: Sets the IAS where the low-speed spring blend starts rising. This is a feel threshold, not a flight limit.

Spring engagement full60.0 kt

Die Fahrt, bei der die Feder volle Stärke erreicht. Zwischen Beginn und diesem Punkt strafft sich die Zentrierung zunehmend mit der Anströmung.

Warum hier: Sets the IAS where the low-speed blend reaches baseline strength; high-speed stiffening also uses it.

Geschwindigkeit zur Kraftabstimmung120

Die angezeigte Fahrt, bei der die aerodynamische Last ihr ausgelegtes Vollniveau erreicht. Sie verankert die gesamte Lastkurve am realen Geschwindigkeitsbereich: eine 172 lädt bis 110 Knoten auf, ein Jet viel später.

Mehr: Lasten kommen später; der Stick bleibt bis zu höherer Fahrt leicht.

Weniger: Lasten kommen früher, und die Reise fühlt sich schwerer an.

Warum hier: Sets the IAS reference for aerodynamic loading. It is an estimate, not published cruise TAS or a flight limit.

Centre firmness vs speed0%

Wie stark sich die Zentrierung selbst mit der Fahrt strafft, zusätzlich zu den Ausschlaglasten. Null hält das Mittengefühl konstant; mehr lässt den Stick im Reiseflug härter und im Anflug lockerer zentrieren.

Mehr: eine Mitte, die mit Fahrt spürbar härter wird.

Weniger: konstantes Mittengefühl bei jeder Fahrt.

Warum hier: Adds permitted spring resistance above the full-blend speed. Zero removes this high-speed increase.

Centre stiffening cap5

Die Obergrenze der fahrtabhängigen Mittenstraffung, damit sehr hohe Fahrt die Feder nicht grenzenlos aufzieht.

Mehr: mehr Gesamtstraffung bei hoher Fahrt erlaubt.

Weniger: die Straffung klemmt früher ab.

Warum hier: Limits the squared airspeed ratio used for high-speed spring stiffening; it is not a device-force cap.

Aileron load100%

Die anhaltende Rolllast aus Querruderausschlag und Fahrt, unabhängig vom Nick balanciert. Zusammen mit der Höhenruderlast bestimmt sie die Ruderharmonie, von der Testberichte sprechen.

Mehr: schwerere Rollkräfte.

Weniger: leichtere, quirligere Querruder.

Warum hier: Roll and pitch aerodynamic scales are 1 and 1, respectively. They set the aerodynamic axis balance. No custom spring-travel curve is enabled.

Elevator load100%

Die anhaltende Nicklast aus Höhenruderausschlag und Fahrt, unabhängig von der Rollachse balanciert. Der Haupthebel für das Nickgewicht eines Musters. Er verändert weder Querruder, Feder, Trimmung noch Schüttelkräfte.

Mehr: schwerere anhaltende Nickkräfte bei Fahrt.

Weniger: ein leichteres Höhenruder, das weniger Muskel braucht.

Warum hier: Scales pitch aerodynamic loading; pitch spring travel and trim responses are separate settings.

Max output force55%

Eine Kappe je stetiger Nick- oder Rollkraft vor dem Gerät. Der Schutz davor, die Hardware in harten Manövern zu überfahren oder zu sättigen.

Mehr: stärkere Spitzenkräfte vor dem Abschneiden.

Weniger: eine sanftere Decke; harte Manöver flachen früher ab.

Warum hier: Caps directed-force output. Native spring effects and device limits remain separate.

Trim

Trim relief (elevator)30%

Wie stark Höhenrudertrimmung die gehaltene Nickkraft abbaut und den Ruhepunkt des Sticks verschiebt. Bei 100 % braucht ein sauber getrimmtes Flugzeug keinen gehaltenen Druck: das Wegtrimmen der Last wie im echten Fliegen.

Mehr: Trimmung nimmt mehr der gehaltenen Nickkraft; bei 100 % nullt volle Trimmung sie.

Weniger: du hältst auch getrimmt weiter Kraft.

Warum hier: Scales supported pitch-trim relief and permitted centre movement. Zero removes pitch response.

Trim relief (aileron)30%

Dieselbe Entlastung für Rolltrimmung. Die meisten GA-Muster haben keine echte Querrudertrimmung, daher bleibt sie bei null; Muster mit Rolltrimmung bekommen einen passenden Wert.

Mehr: Rolltrimmung nimmt mehr gehaltene Rollkraft.

Weniger: Rolltrimmung bewirkt weniger.

Warum hier: Scales supported roll-trim relief and permitted centre movement. Zero removes roll response.

Effect gains · Ground

Runway rumble0%

Rollende Untergrundvibration aus Radgeschwindigkeit und Oberflächenart: die Textur von Asphalt, Gras oder Schotter unter dem Fahrwerk.

Mehr: lautere Oberflächentextur durch den Stick.

Weniger: ruhigeres Rollen.

Warum hier: Sets rolling texture strength, modified by speed, surface and undercarriage configuration.

Gear bumps0%

Kurze einzelne Stöße von Dehnfugen, Spurrillen und rauem Belag: die Interpunktion über dem kontinuierlichen Rumpeln.

Mehr: schärfere Stöße von Fugen und Rillen.

Weniger: weichere Bodendetails.

Warum hier: Sets gear-bump texture during ground motion, separate from touchdown impact.

Effect gains · Airframe

Stall buffet0%

Zellenschütteln vor dem Überziehen und bei aktiver Überziehwarnung: wie laut diese Fläche ihr Unbehagen ankündigt. Muster mit sauberem Abriss bekommen moderates Schütteln, das Horn trägt die Warnung.

Mehr: lauteres Schütteln vor dem Überziehen.

Weniger: eine leisere Fläche; das Horn trägt die Warnung.

Warum hier: Sets stall-buffet strength. Zero removes the cue without changing simulator stalls or warnings.

Mach buffet0%

Transsonisches Schütteln nahe der Machgrenze. Relevant für Jets nahe MMO, null für Kolben und Turboprops, die nie dort ankommen.

Mehr: stärkeres transsonisches Schütteln nahe der Machgrenze.

Weniger: ruhigerer Flug bei hohem Mach.

Warum hier: Sets high-Mach buffet strength; onset and full-strength thresholds are separate.

Flap buffet0%

Niederfrequente Zellenvibration mit Klappen im Fahrtwind, im Fenster, in dem sie wirklich Luft arbeiten.

Mehr: ein rauerer Lauf mit arbeitenden Klappen.

Weniger: ruhigere Anflugklappen.

Warum hier: Sets flap buffet at the configured position and speed gates. Flap movement texture is separate.

Gear buffet0%

Zellentrommeln vom ausgefahrenen Einziehfahrwerk im Fahrtwind. Null für Festfahrwerke, deren Zelle nie die Form ändert.

Mehr: mehr Trommeln mit hängendem Fahrwerk.

Weniger: saubererer Flug mit Fahrwerk.

Warum hier: Sets gear aerodynamic buffet; movement and ground-contact cues are separate.

Stick shaker50%

Der dedizierte Stall-Stickshaker-Buzz, ausgelöst von der Überziehwarnanlage des Flugzeugs. Nur Muster mit echtem Shaker bekommen einen Wert; alle anderen verlassen sich auf Schütteln und Horn.

Mehr: ein härterer Shaker-Buzz.

Weniger: ein dezenterer Shaker.

Warum hier: Sets triggered shaker strength; inactive while the shaker feature is disabled.

Effect gains · Engine, mechanical & drag

Touchdown thump50%

Der Einmalstoß beim Aufsetzen, skaliert mit der Sinkrate: ein Butterlander flüstert, ein fester Aufsetzer wummst.

Mehr: ein härterer Tritt beim Aufsetzen.

Weniger: weichere Ankünfte.

Warum hier: Sets landing-impact strength; landing telemetry and response shape determine the pulse.

Reverse rumble0%

Ausrollvibration bei Schubumkehr oder Beta-Verstellung. Null für Muster ohne Umkehr.

Mehr: ein rauerer Ausrollvorgang unter Umkehrschub.

Weniger: leisere Umkehr.

Warum hier: Sets reverse-thrust vibration with valid reverser and engine conditions. Zero removes the cue.

Engine rumble6%

Kontinuierliche Triebwerksvibration, die der Drehzahl von Leerlauf bis Volllast folgt: die allgegenwärtige Erinnerung, dass vorn etwas Kraftstoff verbrennt.

Mehr: mehr Triebwerk im Stick.

Weniger: ein leiseres Triebwerk.

Warum hier: Sets estimated engine vibration using configured telemetry and response, not measured cockpit vibration.

Flap motion0%

Dauervibration nur, solange der Simulator tatsächlich fahrende Klappenflächen meldet. Folgt echter Aktuatorbewegung und Ausfällen, keinem geschätzten Timer.

Mehr: mehr Vibration bei fahrenden Klappen.

Weniger: leisere Klappenläufe.

Warum hier: Sets texture from observed flap movement; a command without movement does not establish the cue.

Autopilot follow

AP follow authority5%

Wie weit Autopilotbefehle den physischen Stick bewegen dürfen. In MSFS winzig gehalten, weil eine bewegte Achse als Pilotene ingabe zurückgelesen werden kann; null schaltet das Folgen ab.

Mehr: der Autopilot bewegt deinen Stick sichtbar weiter.

Weniger: ein kaum wahrnehmbares Folgen.

Warum hier: Sets admitted AP-follow gain, not a percentage of travel. Runtime ownership and input limits still apply.

Stick feel

StickFeel · Trim feel enabledFalse

Whether this feature is active in this profile.

Warum hier: Retained for compatibility and group membership. Trim relief, rather than this flag, controls centre movement.

StickFeel · Trim relief enabledFalse

Whether this feature is active in this profile.

Warum hier: Allows trim relief with supported control law and valid telemetry. Axis authorities set its amount.

StickFeel · Force trim enabledFalse

Whether this feature is active in this profile.

Warum hier: Plugin-written trim describes the control neutral, separately from AP engagement. Local force trim is off. The stored latch parameters are inactive; the profile does not supply a local hold-where-left neutral.

H135 build447 guide based on HPG guidewww.rotorsim.deDeveloper controls, versions and configuration documentationDeveloper controls, versions and configuration documentationDeveloper controls, versions and configuration documentationDeveloper controls, versions and configuration documentationPublished EC135 MOZA preset, location from supplied updater configuration and installation guideOfficial dataref catalog JSONEC135 original updater skunkcrafts_updater.cfgEC1355.36 original plugins/ec135/lin.xplEC1355.36 original plugins/ec135/win.xplEC135 published original file CRCsAirbus H135 v1.4 release notesH135 freeware
StickFeel · G load enabledFalse

Whether this feature is active in this profile.

Warum hier: Allows load-factor changes to modify permitted spring laws. Passive fly-by-wire feel can suppress it.

StickFeel · Rate damping enabledTrue

Whether this feature is active in this profile.

Warum hier: Enables rate damping with the configured coefficients and control law.

Autopilot

Autopilot · Follow enabledFalse

Whether this feature is active in this profile.

Warum hier: Autopilot following is off; the configured spring and load retain the hardware feel.

Autopilot · Neutral hold enabledFalse

Whether this feature is active in this profile.

Warum hier: Permits centering hold during a supported AP state, separate from following a moving target.

Autopilot · Neutral hold strength0.6

Warum hier: Sets admitted AP neutral-hold strength; inactive while neutral hold is disabled.

Aero

Aero · EnabledTrue

Whether this feature is active in this profile.

Warum hier: Enables aerodynamic cues; each still needs nonzero strength and its simulator conditions.

Aero · Max flap index1

Where this effect reaches full strength (or has fully faded, for washouts).

Mehr: a more gradual build to a later peak.

Weniger: a quicker build.

Warum hier: Sets the final flap index for detent normalization. UP plus three detents uses maximum index3.

Aero · Min flap index1

Where this effect begins fading in.

Mehr: the effect begins later.

Weniger: it begins earlier.

Warum hier: Sets the first flap detent that admits buffet; this is a handle index, not degrees.

Aero · Shaker enabledFalse

Whether this feature is active in this profile.

Warum hier: Permits shaker at supported warning conditions; the switch does not establish aircraft equipment.

Ground

Ground · EnabledTrue

Whether this feature is active in this profile.

Warum hier: Enables ground effects; each still needs its own strength and contact or motion telemetry.

Engine

Engine · EnabledTrue

Whether this feature is active in this profile.

Warum hier: Enables engine cues with nonzero settings and valid running-engine telemetry.

Mechanical

Mechanical · EnabledTrue

Whether this feature is active in this profile.

Warum hier: Enables accessory cues with configured strengths and observed accessory movement.

Mechanical · Gain0

The strength of this effect.

Mehr: a stronger effect.

Weniger: a weaker one.

Warum hier: Sets texture from observed gear movement, separate from aerodynamic and touchdown effects.

Alle Profileinstellungen
Geschätzte Profileinstellungen
ParameterWertWas es steuert und warum
Spring strength0 The cyclic response works around an aircraft-owned neutral where the integration provides it. The baseline spring is 0. Its low-speed blend reaches baseline strength at 60 KIAS.
Spring deadband0.02 Sets travel around the centre before the baseline spring resists. Smaller values engage it sooner.
Force gain0.35 The aerodynamic-load gain is 0.35 with an indicated-speed reference of 120 KIAS. This supplies speed-dependent loading alongside the spring.
Master gain0.85 Scales overall profile strength while preserving effect balance, subject to device and output limits.
Dynamic-pressure blendTrue Allows baseline spring strength to rise with indicated airspeed where the control law permits it.
Minimum spring factor1 Sets low-speed spring strength as a fraction of baseline when blending is enabled. One keeps full strength.
Spring wake-up speed16.8 ktSets the IAS where the low-speed spring blend starts rising. This is a feel threshold, not a flight limit.
Spring full-strength speed60.0 ktSets the IAS where the low-speed blend reaches baseline strength; high-speed stiffening also uses it.
Geschwindigkeit zur Kraftabstimmung120.0 ktSets the IAS reference for aerodynamic loading. It is an estimate, not published cruise TAS or a flight limit.
Airspeed spring stiffening0 Adds permitted spring resistance above the full-blend speed. Zero removes this high-speed increase.
Airspeed stiffening cap5 Limits the squared airspeed ratio used for high-speed spring stiffening; it is not a device-force cap.
Aileron force scale1 Roll and pitch aerodynamic scales are 1 and 1, respectively. They set the aerodynamic axis balance. No custom spring-travel curve is enabled.
Elevator force scale1 Scales pitch aerodynamic loading; pitch spring travel and trim responses are separate settings.
Maximum output force0.55 Caps directed-force output. Native spring effects and device limits remain separate.
StickFeel · Trim feel enabledFalse Retained for compatibility and group membership. Trim relief, rather than this flag, controls centre movement.
StickFeel · Trim relief enabledFalse Allows trim relief with supported control law and valid telemetry. Axis authorities set its amount.
StickFeel · Elevator authority0.3 Scales supported pitch-trim relief and permitted centre movement. Zero removes pitch response.
StickFeel · Aileron authority0.3 Scales supported roll-trim relief and permitted centre movement. Zero removes roll response.
StickFeel · Force trim enabledFalse Plugin-written trim describes the control neutral, separately from AP engagement. Local force trim is off. The stored latch parameters are inactive; the profile does not supply a local hold-where-left neutral.
StickFeel · G load enabledFalse Allows load-factor changes to modify permitted spring laws. Passive fly-by-wire feel can suppress it.
StickFeel · Rate damping enabledTrue Enables rate damping with the configured coefficients and control law.
Autopilot · Follow enabledFalse Autopilot following is off; the configured spring and load retain the hardware feel.
Autopilot · Follow authority0.05 Sets admitted AP-follow gain, not a percentage of travel. Runtime ownership and input limits still apply.
Autopilot · Neutral hold enabledFalse Permits centering hold during a supported AP state, separate from following a moving target.
Autopilot · Neutral hold strength0.6 Sets admitted AP neutral-hold strength; inactive while neutral hold is disabled.
Aero · EnabledTrue Enables aerodynamic cues; each still needs nonzero strength and its simulator conditions.
Aero · Gain0 Sets stall-buffet strength. Zero removes the cue without changing simulator stalls or warnings.
Aero · Gain0 Sets high-Mach buffet strength; onset and full-strength thresholds are separate.
Aero · Gain0 Sets flap buffet at the configured position and speed gates. Flap movement texture is separate.
Aero · Max flap index1 Sets the final flap index for detent normalization. UP plus three detents uses maximum index3.
Aero · Min flap index1 Sets the first flap detent that admits buffet; this is a handle index, not degrees.
Aero · Gain0 Sets gear aerodynamic buffet; movement and ground-contact cues are separate.
Aero · Shaker enabledFalse Permits shaker at supported warning conditions; the switch does not establish aircraft equipment.
Aero · Amplitude0.5 Sets triggered shaker strength; inactive while the shaker feature is disabled.
Ground · EnabledTrue Enables ground effects; each still needs its own strength and contact or motion telemetry.
Ground · Gain0 Sets rolling texture strength, modified by speed, surface and undercarriage configuration.
Ground · Gain0 Sets gear-bump texture during ground motion, separate from touchdown impact.
Ground · Gain0.5 Sets landing-impact strength; landing telemetry and response shape determine the pulse.
Ground · Gain0 Sets reverse-thrust vibration with valid reverser and engine conditions. Zero removes the cue.
Engine · EnabledTrue Enables engine cues with nonzero settings and valid running-engine telemetry.
Engine · Gain0.06 Sets estimated engine vibration using configured telemetry and response, not measured cockpit vibration.
Mechanical · EnabledTrue Enables accessory cues with configured strengths and observed accessory movement.
Mechanical · Gain0 Sets texture from observed flap movement; a command without movement does not establish the cue.
Mechanical · Gain0 Sets texture from observed gear movement, separate from aerodynamic and touchdown effects.
Öffentliche Quellen 22
  1. Eurocopter EC135Research background · Wikipedia revision 1373321906 · retrieved 2026-09-12
  2. H135 build447 guide based on HPG guideDeveloper operating notes or exact systems listing; HPG-based guide build447, pages10-12
  3. www.rotorsim.deXP12 installation requirements
  4. Developer controls, versions and configuration documentationChangelog5.32 through5.36
  5. Developer controls, versions and configuration documentationControls, force trim and joystick modes
  6. Developer controls, versions and configuration documentationSETTINGS JoystickHasFtr; AFCS ResetTrimAtDisengage
  7. Developer controls, versions and configuration documentationDeveloper reply570
  8. Published EC135 MOZA preset, location from supplied updater configuration and installation guidePublished moza_ab9_ec135.preset from official updater repository
  9. Official dataref catalog JSONdrefs sim/cockpit2/controls/elevator_trim and aileron_trim
  10. EC135 original updater skunkcrafts_updater.cfgOriginal updater configuration
  11. EC1355.36 original plugins/ec135/lin.xplTrimSystem constructor, setFfbTrim, setTrimPitch and setTrimRoll; static symbol review
  12. EC1355.36 original plugins/ec135/win.xplOriginal Windows plugin strings and official updater CRC
  13. EC135 published original file CRCsplugins/ec135/lin.xpl and win.xpl; ec135.acf and config.ini
  14. Airbus H135 v1.4 release notesProduct listing captured 2026-09-30; edition scope from the reviewed catalogueSteve Daniels · 26 July 2021
  15. H135 freewareOfficial developer / designated store catalogue ·Official developer / designated store catalogue · checked 2026-09-12
  16. Microsoft Flight Simulator aircraft manuals
  17. EC135 free for MSFS 2024 owners
  18. The Magical FishbowlAustin Meyer · July 2002
  19. Glass of its Own: H135Jon Duke · 21 July 2017
  20. Continually improvingPeter Gray · 29 November–5 December 2016; archived magazine pages
  21. ICAO Doc 8643 — aircraft type designatorsPublic search data retrieved 2026-09-14; authority update 2026-09-03
  22. rotorsim – Das Portal für die HubschraubersimulationProduct listing captured 2026-09-23; edition scope from the reviewed catalogue

Community & Korrekturen

Wenn deine Erfahrung im Muster sagt, dass hier etwas falsch ist, korrigiere es hier.

Pilotenkorrekturen

Du fliegst dieses Muster? Korrigiere diese Seite.

Diese Seite basiert auf zitierten Quellen, und echte Erfahrung im Muster schlägt jedes Zitat. Zitiere die falsche Aussage und sag uns, was das echte Flugzeug tut. Korrekturen gehen zur Prüfung an den Maintainer und fließen in die nächste Fassung dieser Recherche ein.

Hangargespräche

Offene Unterhaltung über das Fliegen und Tunen der Eurocopter EC135, im Community-Forum. Korrekturen oben gehen privat an den Maintainer; Hangargespräche sind öffentlich.

Noch keine Hangargespräche zur Eurocopter EC135. Sei die erste Stimme.

Community

Community-Profile für dieses Luftfahrzeug

Noch keine Community-Profile für dieses Luftfahrzeug. Nach deinem Geschmack getunt? Teile ein Profil und es erscheint hier.