A flight-test engineer remembers the Gazelle
Andrew Cranfield recalled a journey from Yeovil to London with Westland test pilot Don Farquharson, as well as Army exercise flying. His role on those flights is not established as pilot in command.
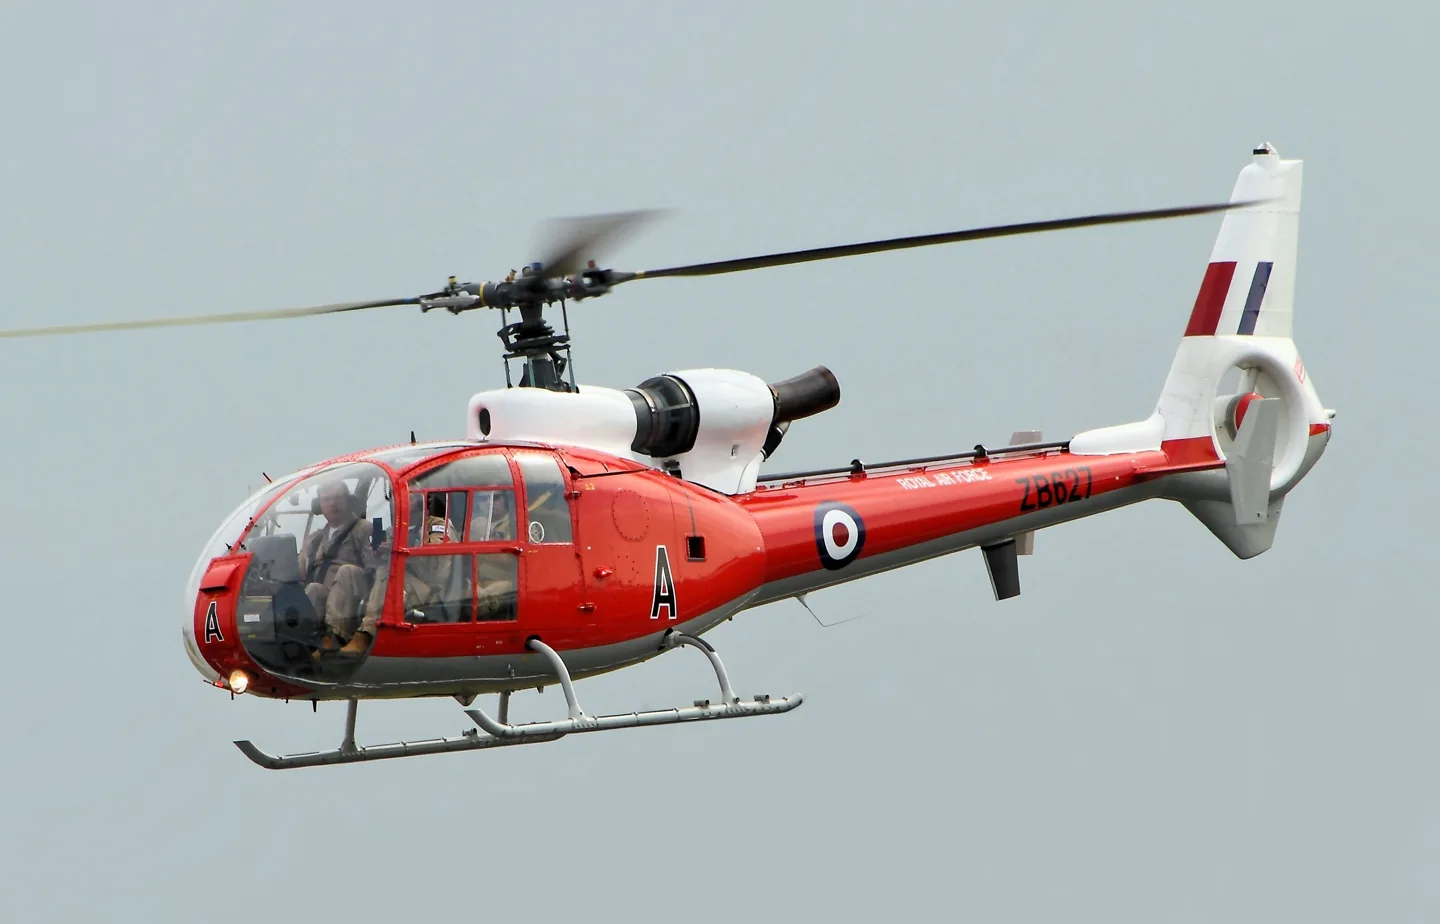 Tim Felce · CC BY-SA 2.0 · Aérospatiale Gazelle — real-aircraft reference photograph.
Sud Aviation developed the Gazelle as a light helicopter with room for five. The design passed into Aérospatiale's range and combined a streamlined cabin with an enclosed anti-torque rotor. Civil and military operators used the same compact airframe for different tasks; equipment and powerplant details depend on the version.
Aérospatiale Gazelle · Specifications (SA 341G) · real aircraft; source units retained
Andrew Cranfield recalled a journey from Yeovil to London with Westland test pilot Don Farquharson, as well as Army exercise flying. His role on those flights is not established as pilot in command.
First flight: 7 April 1967 (SA.340)
Developed from: Aérospatiale Alouette III
A sightseeing flight in Belgium started van Zutphen thinking about learning to fly helicopters himself. He eventually trained on an R44 and later owned other types, but the Gazelle became his favourite. Interviewed at Teuge, he spoke about its appearance and the pleasure of flying with an enthusiasm that extended beyond using it as transport.
The helicopter also served a practical purpose, taking him to customers in Germany and Belgium. Away from work, he flew for Make-A-Wish and shared rides with people with disabilities. Those trips gave a different meaning to the same aircraft. His technical opinions are personal assessments, not independently verified specifications.
Accustomed to seeing the country from a business jet, the writer chose a Gazelle for a family holiday along the California coast. Preparation included helping with rotor-blade installation and checking whether the suitcases would fit. The baggage compartment proved a puzzle, and some belongings later travelled home by parcel delivery as the family made room.
Stops at Santa Barbara and Monterey turned the journey into a series of visits, while the approach to San Francisco offered a view very different from the author’s usual high-altitude flying. Friends shared time in the helicopter during the trip. At home, the family kept talking about the experience and soon proposed another outing. The diary preserves their enjoyment while its historical flying practices remain the author’s account.
After an injury ended his RAF flying career, McQuillan regained fixed-wing flying skills and began working towards helicopters. He recalled developing a pneumatic aid to operate the pedals, with the Gazelle among the aircraft flown during the work. His account also distinguishes the later Schweizer 300 training and check ride from those earlier Gazelle experiences.
Years afterwards, he returned to the type while planning a flight intended to raise awareness of veterans’ needs. A former acquaintance offered two dismantled Gazelles from which the project hoped to prepare an aircraft. McQuillan valued the low cabin height for access and described considerable preparation still ahead. The interview does not document a completed circumnavigation.
Sud Aviation developed the Gazelle as a light helicopter with room for five. The design passed into Aérospatiale's range and combined a streamlined cabin with an enclosed anti-torque rotor. Civil and military operators used the same compact airframe for different tasks; equipment and powerplant details depend on the version.
This profile selects JRX SA341B Gazelle for X-Plane 12.
The spring stays independent of airspeed. Directed aerodynamic loading is omitted.
Local force trim is off. Autopilot following is off.
Cyclic damping is on. Its configured gain is 0.12; it resists hardware motion separately from the spring and aircraft stabilization.
The Gazelle's enclosed Fenestron distinguishes its anti-torque system. JRX separates the military SA341B from the civil SA342J, with different engine, avionics and autopilot equipment. Its custom friction and hydraulic interactions belong to that implementation. FlyInside uses its own flight dynamics and systems. Civil SA342J type data should not be presented as direct military SA341B qualification.
JRX separates military341B/civil342J engines, avionics and AP. XP12 governor/rotor changes supersede older XP11 setup advice.
The gains are normalized profile settings. They describe the chosen effect balance; hand force depends on the device and its output limits. IAS references are tuning values rather than operating limits. Physical acceptance of this revision remains pending.
施加於模型產出的一切、在裝置上限之前的最終整體輸出縮放。
調高: 一切(彈簧、載荷、效果)一同增強。
調低: 一切一同變柔。
設定理由: Scales overall profile strength while preserving effect balance, subject to device and output limits.
把搖桿拉回中央的基礎回中力。其他所有力都疊加在它之上。太低,正常飛行中搖桿會發軟;太高,它會與你的手較勁,並掩蓋疊加其上的細微提示。
調高: 更硬的回中,更抗手。
調低: 更軟的桿,只靠氣動載荷。
設定理由: The profile provides cyclic resistance for the selected Gazelle; JRX friction controls and FlyInside dynamics remain separate simulator implementations. The baseline spring is 0.1. Low-speed spring blending is off.
SA341B / SA342J GazelleGazelle 341中央附近彈簧保持安靜的小中立區,讓靜止時的微小移動不會咔嗒作響。更寬更安穩但更松,更窄更精確但可能在中央附近抖動。
調高: 更安靜但更松的中央,曠量更大。
調低: 更緊的中央,靜止時可能抖動。
設定理由: Sets travel around the centre before the baseline spring resists. Smaller values engage it sooner.
作用於兩條持續軸載荷的主縮放,在它們各自的獨立平衡之前施加。設定檔通常不動它,而是調校兩條軸載荷。
調高: 兩軸載荷一同加重。
調低: 兩軸一同減輕。
設定理由: The 0 gain omits sustained directed airspeed loading. Spring resistance remains independent.
啟用低速彈簧介入視窗(上面的起始/全強度節數)。關閉時彈簧在所有速度下恆定。
設定理由: Allows baseline spring strength to rise with indicated airspeed where the control law permits it.
在靜止、空速尚未產生氣動力之前,彈簧還剩多少。下限高,停機時搖桿結實;下限低,則是停放輕型飛機那種鋼索鬆弛的感覺。
調高: 停機和滑行時桿更結實。
調低: 停機時桿發軟,只隨速度甦醒。
設定理由: Sets low-speed spring strength as a fraction of baseline when blending is enabled. One keeps full strength.
彈簧從低速下限開始向全強度攀升的空速:起飛滑跑中操縱面"甦醒"的那一刻。
設定理由: Sets the IAS where the low-speed spring blend starts rising. This is a feel threshold, not a flight limit.
彈簧達到全強度的空速。從起點到這裡,隨著氣流在操縱面上增強,回中逐漸變硬。
設定理由: Sets the IAS where the low-speed blend reaches baseline strength; high-speed stiffening also uses it.
氣動載荷達到設計滿值的指示空速。它把整條載荷曲線錨定在飛機真實的速度範圍:172在110節就載滿,噴氣機要晚得多。
調高: 載荷來得更晚;桿輕到更高速度。
調低: 載荷來得更早,巡航更沉。
設定理由: Sets the IAS reference for aerodynamic loading. It is an estimate, not published cruise TAS or a flight limit.
在偏轉載荷之外,回中本身隨速度變硬的程度。零則中央手感恆定;越大,巡航時回中越硬,起落航線上越松。
調高: 中央隨速度明顯變硬。
調低: 任何速度下中央手感恆定。
設定理由: Adds permitted spring resistance above the full-blend speed. Zero removes this high-speed increase.
速度驅動的中央變硬上限,防止高速飛行把彈簧無限上緊。
調高: 高速允許更多總硬化。
調低: 硬化更早封頂。
設定理由: Limits the squared airspeed ratio used for high-speed spring stiffening; it is not a device-force cap.
由副翼偏轉和空速產生的持續橫滾載荷,獨立於俯仰調校。與升降舵載荷一起,決定評測中常說的操縱協調比。
調高: 橫滾力更重。
調低: 副翼更輕更靈。
設定理由: Roll and pitch aerodynamic scales are 1 and 1, respectively. These stored weights do not create directed aerodynamic loading while that term is inactive. No custom spring-travel curve is enabled.
由升降舵偏轉和空速產生的持續俯仰載荷,獨立於橫滾調校。這是決定機型俯仰重量的主槓桿。它不影響副翼、彈簧、配平或抖振力。
調高: 速度下持續俯仰力更重。
調低: 升降舵更輕,握持更省力。
設定理由: Scales pitch aerodynamic loading; pitch spring travel and trim responses are separate settings.
每個穩態俯仰或橫滾力到達裝置前的上限,防止猛烈機動中砸擊或飽和硬體。
調高: 削波前更高的穩態力峰值。
調低: 更柔的上限;猛烈機動更早被抹平。
設定理由: Caps directed-force output. Native spring effects and device limits remain separate.
升降舵配平緩解持續俯仰力、移動桿的安定位置的強度。在100 %時,配平得當的飛機不需要保持壓力——正是真實飛行中"用配平消掉載荷"的流程。
調高: 配平消掉更多持續力;100 %時滿配平可完全抵消。
調低: 即使配平也仍要持續用力。
設定理由: Scales supported pitch-trim relief and permitted centre movement. Zero removes pitch response.
橫滾配平的同類緩解。多數通航機型沒有真正的副翼配平,所以保持為零;有橫滾配平的機型獲得相應的值。
調高: 橫滾配平消掉更多持續力。
調低: 橫滾配平作用更小。
設定理由: Scales supported roll-trim relief and permitted centre movement. Zero removes roll response.
由輪速和地面型別(鋪裝、草地、礫石)產生的滾動振動。
調高: 桿上更強的地面質感。
調低: 更平滑的滑行。
設定理由: Sets rolling texture strength, modified by speed, surface and undercarriage configuration.
來自伸縮縫、車轍和粗糙地面的短促離散顛簸,為持續隆隆聲打上標點。
調高: 接縫與車轍的衝擊更清晰。
調低: 更柔的地面細節。
設定理由: Sets gear-bump texture during ground motion, separate from touchdown impact.
接近失速及失速警告響起時的機體抖動:這副機翼宣告不滿的音量。斷失乾脆的機型抖振收斂,讓喇叭承擔警告。
調高: 更強的失速前顫抖。
調低: 更含蓄的機翼;警告交給喇叭。
設定理由: Sets stall-buffet strength. Zero removes the cue without changing simulator stalls or warnings.
接近馬赫極限的跨音速抖振。對接近MMO的噴氣機有意義,對到不了那裡的活塞機和渦槳機為零。
調高: 接近馬赫極限時更強的跨音速抖振。
調低: 高馬赫下更平滑的飛行。
設定理由: Sets high-Mach buffet strength; onset and full-strength thresholds are separate.
襟翼伸入氣流後機體的低頻振動,發生在它們真正做功的速度視窗內。
調高: 襟翼做功時更粗糙的飛行。
調低: 更柔的進近襟翼。
設定理由: Sets flap buffet at the configured position and speed gates. Flap movement texture is separate.
可收放起落架懸在氣流中引起的機體鼓振。固定起落架機型為零,它們的機體外形從不改變。
調高: 放起落架時更多鼓振。
調低: 放起落架飛行更乾淨。
設定理由: Sets gear aerodynamic buffet; movement and ground-contact cues are separate.
由飛機自身失速警告系統觸發的專用抖桿器振動。只有真有抖桿器的機型才有值;其餘全靠氣動抖振和喇叭。
調高: 更硬的抖桿器。
調低: 更含蓄的抖桿器。
設定理由: Sets triggered shaker strength; inactive while the shaker feature is disabled.
機輪觸及跑道那一下的單次衝擊,按下沉率縮放:輕柔著陸是耳語,結實到達是一記悶響。
調高: 觸地時更硬的一擊。
調低: 更柔的到達。
設定理由: Sets landing-impact strength; landing telemetry and response shape determine the pulse.
反推或槳葉beta區工作時的滑跑振動。無反推機型為零。
調高: 反推下更粗糙的滑跑。
調低: 更含蓄的反推。
設定理由: Sets reverse-thrust vibration with valid reverser and engine conditions. Zero removes the cue.
從慢車到全功率跟隨轉速的持續動力裝置振動——前方有東西在燒油的永恆提醒。
調高: 桿裡更多引擎。
調低: 更含蓄的引擎。
設定理由: Sets estimated engine vibration using configured telemetry and response, not measured cockpit vibration.
僅在模擬器報告襟翼舵面確實移動時的持續振動。它跟隨真實作動器的運動和故障,而非估算的計時器。
調高: 襟翼移動中更多振動。
調低: 更含蓄的襟翼行程。
設定理由: Sets texture from observed flap movement; a command without movement does not establish the cue.
自動駕駛指令可以讓桿實際移動多遠。在MSFS中保持極小,因為移動的軸可能被讀回為飛行員輸入;零則完全停用跟隨。
調高: 自動駕駛讓你的桿移動得明顯更多。
調低: 幾乎察覺不到的跟隨。
設定理由: Sets admitted AP-follow gain, not a percentage of travel. Runtime ownership and input limits still apply.
Whether this feature is active in this profile.
設定理由: Retained for compatibility and group membership. Trim relief, rather than this flag, controls centre movement.
Whether this feature is active in this profile.
設定理由: Allows trim relief with supported control law and valid telemetry. Axis authorities set its amount.
Whether this feature is active in this profile.
設定理由: A local force-trim latch is an approximation of a hardware neutral, not a complete representation of every Gazelle's friction, hydraulic or autopilot system. Local force trim is off. The stored latch parameters are inactive; the profile does not supply a local hold-where-left neutral.
SA341B / SA342J GazelleGazelle 341Whether this feature is active in this profile.
設定理由: Allows load-factor changes to modify permitted spring laws. Passive fly-by-wire feel can suppress it.
Whether this feature is active in this profile.
設定理由: Enables rate damping with the configured coefficients and control law.
Whether this feature is active in this profile.
設定理由: Autopilot following is off; the configured spring and load retain the hardware feel.
Whether this feature is active in this profile.
設定理由: Permits centering hold during a supported AP state, separate from following a moving target.
設定理由: Sets admitted AP neutral-hold strength; inactive while neutral hold is disabled.
Whether this feature is active in this profile.
設定理由: Enables aerodynamic cues; each still needs nonzero strength and its simulator conditions.
Where this effect reaches full strength (or has fully faded, for washouts).
調高: a more gradual build to a later peak.
調低: a quicker build.
設定理由: Sets the final flap index for detent normalization. UP plus three detents uses maximum index3.
Where this effect begins fading in.
調高: the effect begins later.
調低: it begins earlier.
設定理由: Sets the first flap detent that admits buffet; this is a handle index, not degrees.
Whether this feature is active in this profile.
設定理由: Permits shaker at supported warning conditions; the switch does not establish aircraft equipment.
Whether this feature is active in this profile.
設定理由: Enables ground effects; each still needs its own strength and contact or motion telemetry.
Whether this feature is active in this profile.
設定理由: Enables engine cues with nonzero settings and valid running-engine telemetry.
Whether this feature is active in this profile.
設定理由: Enables accessory cues with configured strengths and observed accessory movement.
The strength of this effect.
調高: a stronger effect.
調低: a weaker one.
設定理由: Sets texture from observed gear movement, separate from aerodynamic and touchdown effects.
| 引數 | 數值 | 控制作用及原因 |
|---|---|---|
| Spring strength | 0.1 | The profile provides cyclic resistance for the selected Gazelle; JRX friction controls and FlyInside dynamics remain separate simulator implementations. The baseline spring is 0.1. Low-speed spring blending is off. |
| Spring deadband | 0.02 | Sets travel around the centre before the baseline spring resists. Smaller values engage it sooner. |
| Force gain | 0 | The 0 gain omits sustained directed airspeed loading. Spring resistance remains independent. |
| Master gain | 0.65 | Scales overall profile strength while preserving effect balance, subject to device and output limits. |
| Dynamic-pressure blend | False | Allows baseline spring strength to rise with indicated airspeed where the control law permits it. |
| Minimum spring factor | 1 | Sets low-speed spring strength as a fraction of baseline when blending is enabled. One keeps full strength. |
| Spring wake-up speed | 15.4 kt | Sets the IAS where the low-speed spring blend starts rising. This is a feel threshold, not a flight limit. |
| Spring full-strength speed | 55.0 kt | Sets the IAS where the low-speed blend reaches baseline strength; high-speed stiffening also uses it. |
| 力回饋調校速度 | 110 kt | Sets the IAS reference for aerodynamic loading. It is an estimate, not published cruise TAS or a flight limit. |
| Airspeed spring stiffening | 0 | Adds permitted spring resistance above the full-blend speed. Zero removes this high-speed increase. |
| Airspeed stiffening cap | 5 | Limits the squared airspeed ratio used for high-speed spring stiffening; it is not a device-force cap. |
| Aileron force scale | 1 | Roll and pitch aerodynamic scales are 1 and 1, respectively. These stored weights do not create directed aerodynamic loading while that term is inactive. No custom spring-travel curve is enabled. |
| Elevator force scale | 1 | Scales pitch aerodynamic loading; pitch spring travel and trim responses are separate settings. |
| Maximum output force | 0.55 | Caps directed-force output. Native spring effects and device limits remain separate. |
| StickFeel · Trim feel enabled | False | Retained for compatibility and group membership. Trim relief, rather than this flag, controls centre movement. |
| StickFeel · Trim relief enabled | False | Allows trim relief with supported control law and valid telemetry. Axis authorities set its amount. |
| StickFeel · Elevator authority | 0 | Scales supported pitch-trim relief and permitted centre movement. Zero removes pitch response. |
| StickFeel · Aileron authority | 0 | Scales supported roll-trim relief and permitted centre movement. Zero removes roll response. |
| StickFeel · Force trim enabled | False | A local force-trim latch is an approximation of a hardware neutral, not a complete representation of every Gazelle's friction, hydraulic or autopilot system. Local force trim is off. The stored latch parameters are inactive; the profile does not supply a local hold-where-left neutral. |
| StickFeel · G load enabled | True | Allows load-factor changes to modify permitted spring laws. Passive fly-by-wire feel can suppress it. |
| StickFeel · Rate damping enabled | False | Enables rate damping with the configured coefficients and control law. |
| Autopilot · Follow enabled | False | Autopilot following is off; the configured spring and load retain the hardware feel. |
| Autopilot · Follow authority | 0.05 | Sets admitted AP-follow gain, not a percentage of travel. Runtime ownership and input limits still apply. |
| Autopilot · Neutral hold enabled | False | Permits centering hold during a supported AP state, separate from following a moving target. |
| Autopilot · Neutral hold strength | 0.6 | Sets admitted AP neutral-hold strength; inactive while neutral hold is disabled. |
| Aero · Enabled | True | Enables aerodynamic cues; each still needs nonzero strength and its simulator conditions. |
| Aero · Gain | 0 | Sets stall-buffet strength. Zero removes the cue without changing simulator stalls or warnings. |
| Aero · Gain | 0 | Sets high-Mach buffet strength; onset and full-strength thresholds are separate. |
| Aero · Gain | 0 | Sets flap buffet at the configured position and speed gates. Flap movement texture is separate. |
| Aero · Max flap index | 1 | Sets the final flap index for detent normalization. UP plus three detents uses maximum index3. |
| Aero · Min flap index | 1 | Sets the first flap detent that admits buffet; this is a handle index, not degrees. |
| Aero · Gain | 0 | Sets gear aerodynamic buffet; movement and ground-contact cues are separate. |
| Aero · Shaker enabled | False | Permits shaker at supported warning conditions; the switch does not establish aircraft equipment. |
| Aero · Amplitude | 0.5 | Sets triggered shaker strength; inactive while the shaker feature is disabled. |
| Ground · Enabled | True | Enables ground effects; each still needs its own strength and contact or motion telemetry. |
| Ground · Gain | 0 | Sets rolling texture strength, modified by speed, surface and undercarriage configuration. |
| Ground · Gain | 0 | Sets gear-bump texture during ground motion, separate from touchdown impact. |
| Ground · Gain | 0.2 | Sets landing-impact strength; landing telemetry and response shape determine the pulse. |
| Ground · Gain | 0 | Sets reverse-thrust vibration with valid reverser and engine conditions. Zero removes the cue. |
| Engine · Enabled | True | Enables engine cues with nonzero settings and valid running-engine telemetry. |
| Engine · Gain | 0 | Sets estimated engine vibration using configured telemetry and response, not measured cockpit vibration. |
| Mechanical · Enabled | True | Enables accessory cues with configured strengths and observed accessory movement. |
| Mechanical · Gain | 0 | Sets texture from observed flap movement; a command without movement does not establish the cue. |
| Mechanical · Gain | 0 | Sets texture from observed gear movement, separate from aerodynamic and touchdown effects. |
如果你的真機經驗表明本頁有誤,請在此指正。
本頁基於引用資料構建,而真機經驗勝過任何引用。 請引用有誤的主張,並告訴我們真機的實際表現。糾錯 將交由維護者稽核,並納入本研究的下一次修訂。