A joint-service observation aircraft
The Bronco originated in a Marine Corps concept and a joint Air Force, Navy and Marine Corps programme. The first production OV-10A was ordered in 1966 and flew in August 1967.
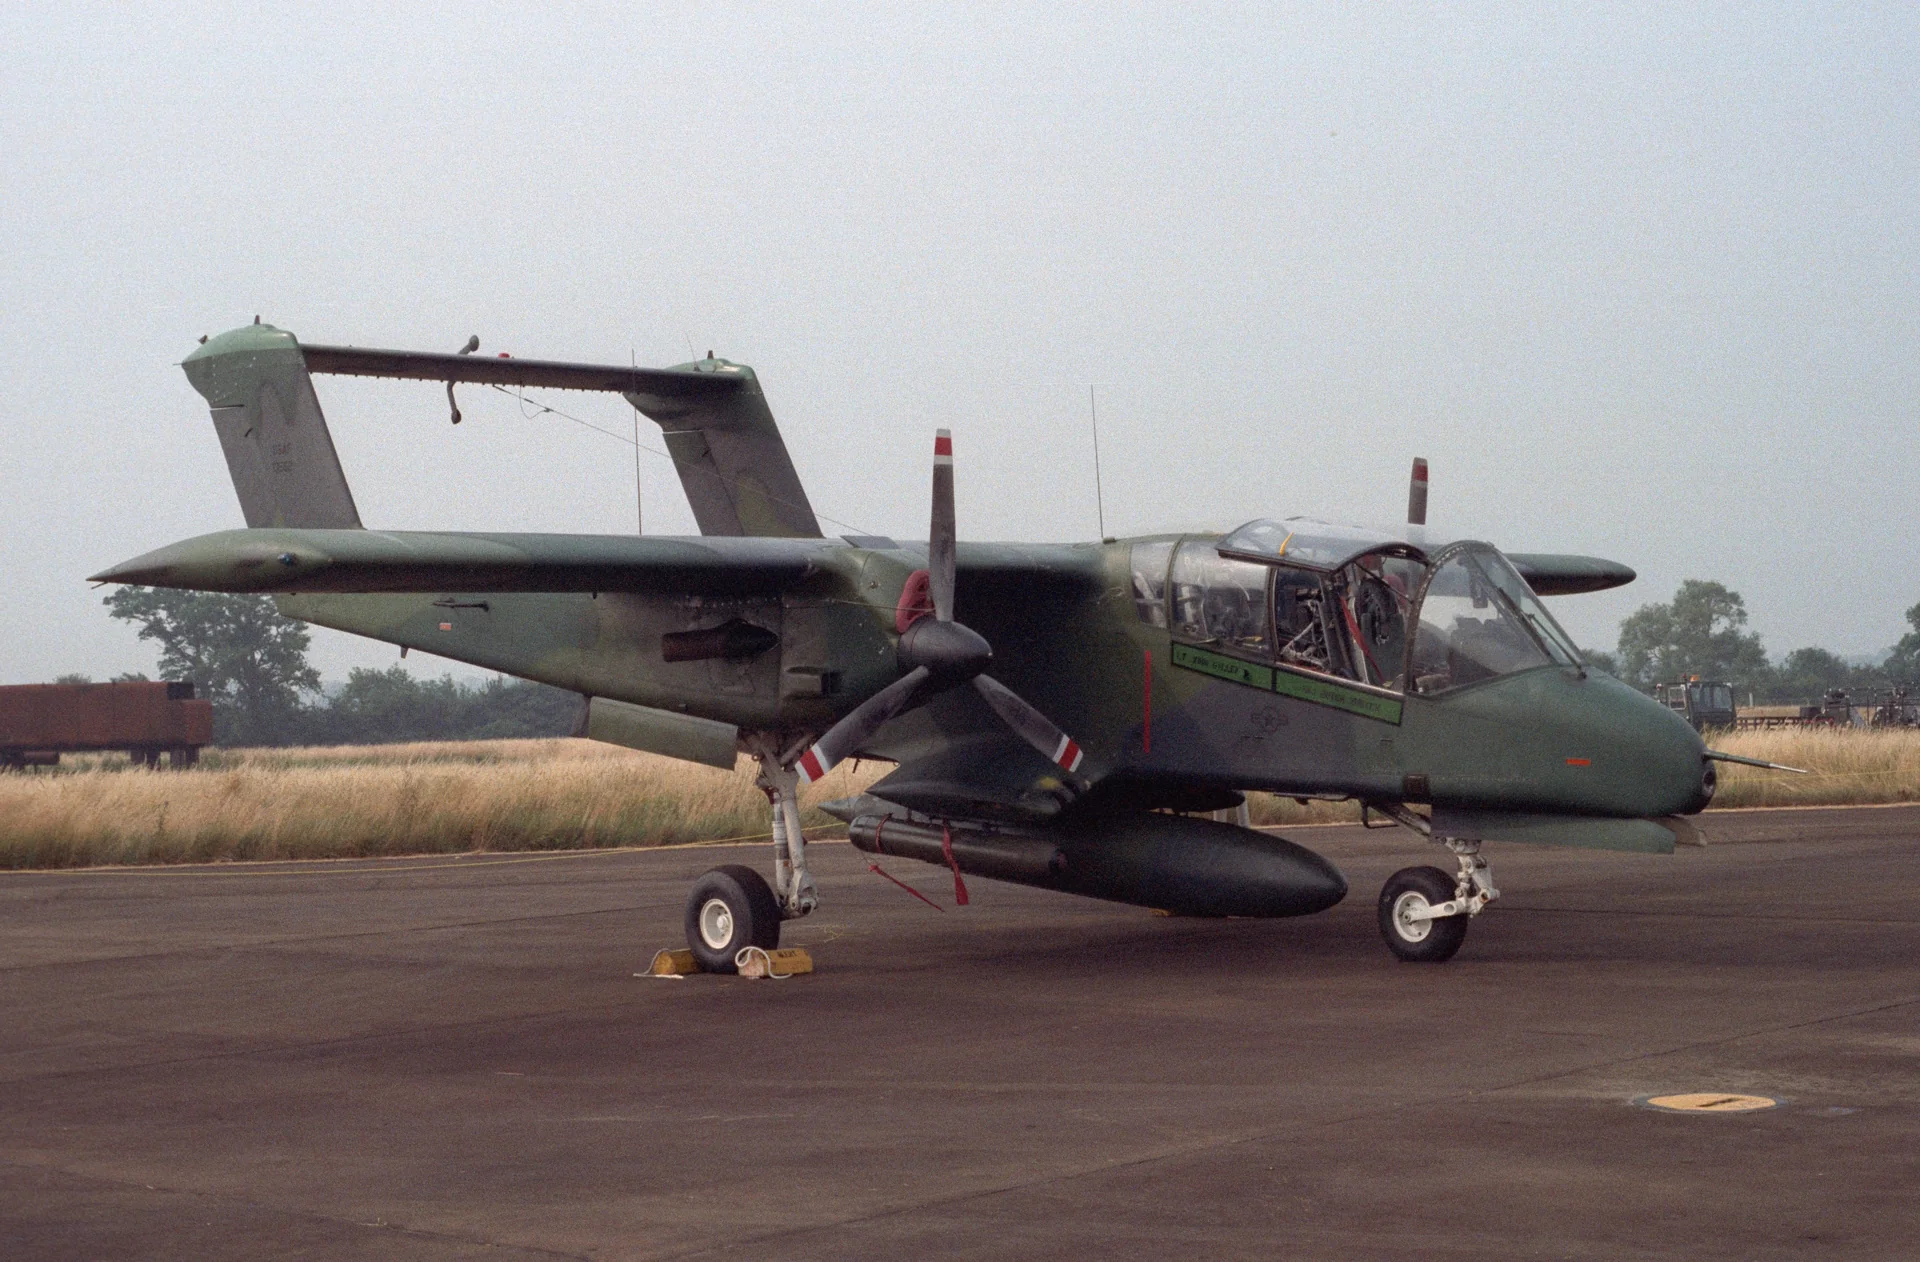 Anidaat · CC BY-SA 4.0 · 1983 Bronco Fairford.
The OV-10 Bronco served in light armed reconnaissance and forward air control. The National Naval Aviation Museum records U.S. Navy VAL-4 using OV-10As in South Vietnam to support riverine forces.
OV-10A museum reference
The Bronco originated in a Marine Corps concept and a joint Air Force, Navy and Marine Corps programme. The first production OV-10A was ordered in 1966 and flew in August 1967.
The first combat-bound USAF Broncos arrived in Vietnam in July 1968. The Air Force acquired 157 OV-10As before production for it ended in April 1969, using the type primarily for forward air control.
The short-take-off-and-landing design also served reconnaissance, helicopter escort and artillery spotting. A rear compartment could carry cargo, troops or stretcher patients, giving the twin-turboprop aircraft utility work alongside observation.
The dimensions and power here belong to the OV-10A. Later Bronco versions and upgraded engines need their own references; their performance should not be assumed from this baseline.
AzurPoly OV-10B Bronco Unarmed Target Tug is the selected AzurPoly configuration.
Spring resistance builds with the selected airspeed response. A separate aerodynamic term adds speed-dependent control load.
Valid trim provides the configured pressure relief. Autopilot following is off.
The OV-10B model represents the German target-tug variant and does not carry weapons.
The primary controls are reversible mechanical systems with aerodynamic tab assistance; hydraulic power serves gear and flaps.
Strengths are normalized hardware-feel settings. They set the effect balance; hand force depends on the device and its limits. The IAS reference is a tuning value.
施加于模型产出的一切、在设备上限之前的最终整体输出缩放。
调高: 一切(弹簧、载荷、效果)一同增强。
调低: 一切一同变柔。
设定理由: Scales overall profile strength while preserving effect balance, subject to device and output limits.
把摇杆拉回中央的基础回中力。其他所有力都叠加在它之上。太低,正常飞行中摇杆会发软;太高,它会与你的手较劲,并掩盖叠加其上的细微提示。
调高: 更硬的回中,更抗手。
调低: 更软的杆,只靠气动载荷。
设定理由: This profile uses reversible-control loading for North American Rockwell OV-10 Bronco. The baseline spring is 0.74. Its low-speed blend reaches baseline strength at 70 KIAS.
中央附近弹簧保持安静的小中立区,让静止时的微小移动不会咔嗒作响。更宽更安稳但更松,更窄更精确但可能在中央附近抖动。
调高: 更安静但更松的中央,旷量更大。
调低: 更紧的中央,静止时可能抖动。
设定理由: Sets travel around the centre before the baseline spring resists. Smaller values engage it sooner.
作用于两条持续轴载荷的主缩放,在它们各自的独立平衡之前施加。配置文件通常不动它,而是调校两条轴载荷。
调高: 两轴载荷一同加重。
调低: 两轴一同减轻。
设定理由: The aerodynamic-load gain is 0.68 with an indicated-speed reference of 180 KIAS. This supplies speed-dependent loading alongside the spring.
启用低速弹簧介入窗口(上面的起始/全强度节数)。关闭时弹簧在所有速度下恒定。
设定理由: Allows baseline spring strength to rise with indicated airspeed where the control law permits it.
在静止、空速尚未产生气动力之前,弹簧还剩多少。下限高,停机时摇杆结实;下限低,则是停放轻型飞机那种钢索松弛的感觉。
调高: 停机和滑行时杆更结实。
调低: 停机时杆发软,只随速度苏醒。
设定理由: Sets low-speed spring strength as a fraction of baseline when blending is enabled. One keeps full strength.
弹簧从低速下限开始向全强度攀升的空速:起飞滑跑中操纵面"苏醒"的那一刻。
设定理由: Sets the IAS where the low-speed spring blend starts rising. This is a feel threshold, not a flight limit.
弹簧达到全强度的空速。从起点到这里,随着气流在操纵面上增强,回中逐渐变硬。
设定理由: Sets the IAS where the low-speed blend reaches baseline strength; high-speed stiffening also uses it.
气动载荷达到设计满值的指示空速。它把整条载荷曲线锚定在飞机真实的速度范围:172在110节就载满,喷气机要晚得多。
调高: 载荷来得更晚;杆轻到更高速度。
调低: 载荷来得更早,巡航更沉。
设定理由: Sets the IAS reference for aerodynamic loading. It is an estimate, not published cruise TAS or a flight limit.
在偏转载荷之外,回中本身随速度变硬的程度。零则中央手感恒定;越大,巡航时回中越硬,起落航线上越松。
调高: 中央随速度明显变硬。
调低: 任何速度下中央手感恒定。
设定理由: The high-speed spring-stiffening gain is 0.1. It strengthens the permitted spring response above 70 KIAS, with the squared-speed ratio capped at 5.
速度驱动的中央变硬上限,防止高速飞行把弹簧无限上紧。
调高: 高速允许更多总硬化。
调低: 硬化更早封顶。
设定理由: Limits the squared airspeed ratio used for high-speed spring stiffening; it is not a device-force cap.
由副翼偏转和空速产生的持续横滚载荷,独立于俯仰调校。与升降舵载荷一起,决定评测中常说的操纵协调比。
调高: 横滚力更重。
调低: 副翼更轻更灵。
设定理由: Roll and pitch aerodynamic scales are 0.72 and 1, respectively. They set the aerodynamic axis balance. No custom spring-travel curve is enabled.
由升降舵偏转和空速产生的持续俯仰载荷,独立于横滚调校。这是决定机型俯仰重量的主杠杆。它不影响副翼、弹簧、配平或抖振力。
调高: 速度下持续俯仰力更重。
调低: 升降舵更轻,握持更省力。
设定理由: Scales pitch aerodynamic loading; pitch spring travel and trim responses are separate settings.
每个稳态俯仰或横滚力到达设备前的上限,防止猛烈机动中砸击或饱和硬件。
调高: 削波前更高的稳态力峰值。
调低: 更柔的上限;猛烈机动更早被抹平。
设定理由: Caps directed-force output. Native spring effects and device limits remain separate.
升降舵配平缓解持续俯仰力、移动杆的安定位置的强度。在100 %时,配平得当的飞机不需要保持压力——正是真实飞行中"用配平消掉载荷"的流程。
调高: 配平消掉更多持续力;100 %时满配平可完全抵消。
调低: 即使配平也仍要持续用力。
设定理由: The profile uses the trim behaviour configured below. Pitch authority 0.3 provides load relief and permitted centre movement; roll authority is 0.14.
横滚配平的同类缓解。多数通航机型没有真正的副翼配平,所以保持为零;有横滚配平的机型获得相应的值。
调高: 横滚配平消掉更多持续力。
调低: 横滚配平作用更小。
设定理由: Scales supported roll-trim relief and permitted centre movement. Zero removes roll response.
由轮速和地面类型(铺装、草地、砾石)产生的滚动振动。
调高: 杆上更强的地面质感。
调低: 更平滑的滑行。
设定理由: Sets rolling texture strength, modified by speed, surface and undercarriage configuration.
来自伸缩缝、车辙和粗糙地面的短促离散颠簸,为持续隆隆声打上标点。
调高: 接缝与车辙的冲击更清晰。
调低: 更柔的地面细节。
设定理由: Sets gear-bump texture during ground motion, separate from touchdown impact.
接近失速及失速警告响起时的机体抖动:这副机翼宣告不满的音量。断失干脆的机型抖振收敛,让喇叭承担警告。
调高: 更强的失速前颤抖。
调低: 更含蓄的机翼;警告交给喇叭。
设定理由: Sets stall-buffet strength. Zero removes the cue without changing simulator stalls or warnings.
接近马赫极限的跨音速抖振。对接近MMO的喷气机有意义,对到不了那里的活塞机和涡桨机为零。
调高: 接近马赫极限时更强的跨音速抖振。
调低: 高马赫下更平滑的飞行。
设定理由: Sets high-Mach buffet strength; onset and full-strength thresholds are separate.
襟翼伸入气流后机体的低频振动,发生在它们真正做功的速度窗口内。
调高: 襟翼做功时更粗糙的飞行。
调低: 更柔的进近襟翼。
设定理由: Sets flap buffet at the configured position and speed gates. Flap movement texture is separate.
可收放起落架悬在气流中引起的机体鼓振。固定起落架机型为零,它们的机体外形从不改变。
调高: 放起落架时更多鼓振。
调低: 放起落架飞行更干净。
设定理由: Sets gear aerodynamic buffet; movement and ground-contact cues are separate.
由飞机自身失速警告系统触发的专用抖杆器振动。只有真有抖杆器的机型才有值;其余全靠气动抖振和喇叭。
调高: 更硬的抖杆器。
调低: 更含蓄的抖杆器。
设定理由: Sets triggered shaker strength; inactive while the shaker feature is disabled.
机轮触及跑道那一下的单次冲击,按下沉率缩放:轻柔着陆是耳语,结实到达是一记闷响。
调高: 触地时更硬的一击。
调低: 更柔的到达。
设定理由: Sets landing-impact strength; landing telemetry and response shape determine the pulse.
反推或桨叶beta区工作时的滑跑振动。无反推机型为零。
调高: 反推下更粗糙的滑跑。
调低: 更含蓄的反推。
设定理由: Sets reverse-thrust vibration with valid reverser and engine conditions. Zero removes the cue.
从慢车到全功率跟随转速的持续动力装置振动——前方有东西在烧油的永恒提醒。
调高: 杆里更多发动机。
调低: 更含蓄的发动机。
设定理由: Sets estimated engine vibration using configured telemetry and response, not measured cockpit vibration.
仅在模拟器报告襟翼舵面确实移动时的持续振动。它跟随真实作动器的运动和故障,而非估算的计时器。
调高: 襟翼移动中更多振动。
调低: 更含蓄的襟翼行程。
设定理由: Sets texture from observed flap movement; a command without movement does not establish the cue.
自动驾驶指令可以让杆实际移动多远。在MSFS中保持极小,因为移动的轴可能被读回为飞行员输入;零则完全禁用跟随。
调高: 自动驾驶让你的杆移动得明显更多。
调低: 几乎察觉不到的跟随。
设定理由: Sets admitted AP-follow gain, not a percentage of travel. Runtime ownership and input limits still apply.
Whether this feature is active in this profile.
设定理由: Retained for compatibility and group membership. Trim relief, rather than this flag, controls centre movement.
Whether this feature is active in this profile.
设定理由: Allows trim relief with supported control law and valid telemetry. Axis authorities set its amount.
Whether this feature is active in this profile.
设定理由: Enables local force trim, separate from aircraft-owned trim and add-on integration qualification.
Whether this feature is active in this profile.
设定理由: Allows load-factor changes to modify permitted spring laws. Passive fly-by-wire feel can suppress it.
Whether this feature is active in this profile.
设定理由: Enables rate damping with the configured coefficients and control law.
Whether this feature is active in this profile.
设定理由: Autopilot following is off; the configured spring and load retain the hardware feel.
Whether this feature is active in this profile.
设定理由: Permits centering hold during a supported AP state, separate from following a moving target.
设定理由: Sets admitted AP neutral-hold strength; inactive while neutral hold is disabled.
Whether this feature is active in this profile.
设定理由: Enables aerodynamic cues; each still needs nonzero strength and its simulator conditions.
Where this effect reaches full strength (or has fully faded, for washouts).
调高: a more gradual build to a later peak.
调低: a quicker build.
设定理由: Sets the final flap index for detent normalization. UP plus three detents uses maximum index3.
Where this effect begins fading in.
调高: the effect begins later.
调低: it begins earlier.
设定理由: Sets the first flap detent that admits buffet; this is a handle index, not degrees.
Whether this feature is active in this profile.
设定理由: Permits shaker at supported warning conditions; the switch does not establish aircraft equipment.
Whether this feature is active in this profile.
设定理由: Enables ground effects; each still needs its own strength and contact or motion telemetry.
Whether this feature is active in this profile.
设定理由: Enables engine cues with nonzero settings and valid running-engine telemetry.
Whether this feature is active in this profile.
设定理由: Enables accessory cues with configured strengths and observed accessory movement.
The strength of this effect.
调高: a stronger effect.
调低: a weaker one.
设定理由: Sets texture from observed gear movement, separate from aerodynamic and touchdown effects.
| 参数 | 数值 | 控制作用及原因 |
|---|---|---|
| Spring strength | 0.74 | This profile uses reversible-control loading for North American Rockwell OV-10 Bronco. The baseline spring is 0.74. Its low-speed blend reaches baseline strength at 70 KIAS. |
| Spring deadband | 0.04 | Sets travel around the centre before the baseline spring resists. Smaller values engage it sooner. |
| Force gain | 0.68 | The aerodynamic-load gain is 0.68 with an indicated-speed reference of 180 KIAS. This supplies speed-dependent loading alongside the spring. |
| Master gain | 0.85 | Scales overall profile strength while preserving effect balance, subject to device and output limits. |
| Dynamic-pressure blend | True | Allows baseline spring strength to rise with indicated airspeed where the control law permits it. |
| Minimum spring factor | 0.55 | Sets low-speed spring strength as a fraction of baseline when blending is enabled. One keeps full strength. |
| Spring wake-up speed | 20 kt | Sets the IAS where the low-speed spring blend starts rising. This is a feel threshold, not a flight limit. |
| Spring full-strength speed | 70 kt | Sets the IAS where the low-speed blend reaches baseline strength; high-speed stiffening also uses it. |
| 力反馈调校速度 | 180 kt | Sets the IAS reference for aerodynamic loading. It is an estimate, not published cruise TAS or a flight limit. |
| Airspeed spring stiffening | 0.1 | The high-speed spring-stiffening gain is 0.1. It strengthens the permitted spring response above 70 KIAS, with the squared-speed ratio capped at 5. |
| Airspeed stiffening cap | 5 | Limits the squared airspeed ratio used for high-speed spring stiffening; it is not a device-force cap. |
| Aileron force scale | 0.72 | Roll and pitch aerodynamic scales are 0.72 and 1, respectively. They set the aerodynamic axis balance. No custom spring-travel curve is enabled. |
| Elevator force scale | 1.0 | Scales pitch aerodynamic loading; pitch spring travel and trim responses are separate settings. |
| Maximum output force | 0.55 | Caps directed-force output. Native spring effects and device limits remain separate. |
| StickFeel · Trim feel enabled | False | Retained for compatibility and group membership. Trim relief, rather than this flag, controls centre movement. |
| StickFeel · Trim relief enabled | True | Allows trim relief with supported control law and valid telemetry. Axis authorities set its amount. |
| StickFeel · Elevator authority | 0.3 | The profile uses the trim behaviour configured below. Pitch authority 0.3 provides load relief and permitted centre movement; roll authority is 0.14. |
| StickFeel · Aileron authority | 0.14 | Scales supported roll-trim relief and permitted centre movement. Zero removes roll response. |
| StickFeel · Force trim enabled | False | Enables local force trim, separate from aircraft-owned trim and add-on integration qualification. |
| StickFeel · G load enabled | True | Allows load-factor changes to modify permitted spring laws. Passive fly-by-wire feel can suppress it. |
| StickFeel · Rate damping enabled | True | Enables rate damping with the configured coefficients and control law. |
| Autopilot · Follow enabled | False | Autopilot following is off; the configured spring and load retain the hardware feel. |
| Autopilot · Follow authority | 0.1 | Sets admitted AP-follow gain, not a percentage of travel. Runtime ownership and input limits still apply. |
| Autopilot · Neutral hold enabled | False | Permits centering hold during a supported AP state, separate from following a moving target. |
| Autopilot · Neutral hold strength | 0.6 | Sets admitted AP neutral-hold strength; inactive while neutral hold is disabled. |
| Aero · Enabled | True | Enables aerodynamic cues; each still needs nonzero strength and its simulator conditions. |
| Aero · Gain | 0.28 | Sets stall-buffet strength. Zero removes the cue without changing simulator stalls or warnings. |
| Aero · Gain | 0 | Sets high-Mach buffet strength; onset and full-strength thresholds are separate. |
| Aero · Gain | 0 | Sets flap buffet at the configured position and speed gates. Flap movement texture is separate. |
| Aero · Max flap index | 3 | Sets the final flap index for detent normalization. UP plus three detents uses maximum index3. |
| Aero · Min flap index | 2 | Sets the first flap detent that admits buffet; this is a handle index, not degrees. |
| Aero · Gain | 0 | Sets gear aerodynamic buffet; movement and ground-contact cues are separate. |
| Aero · Shaker enabled | False | Permits shaker at supported warning conditions; the switch does not establish aircraft equipment. |
| Aero · Amplitude | 0.5 | Sets triggered shaker strength; inactive while the shaker feature is disabled. |
| Ground · Enabled | True | Enables ground effects; each still needs its own strength and contact or motion telemetry. |
| Ground · Gain | 0.42 | Sets rolling texture strength, modified by speed, surface and undercarriage configuration. |
| Ground · Gain | 0.32 | Sets gear-bump texture during ground motion, separate from touchdown impact. |
| Ground · Gain | 0.82 | Sets landing-impact strength; landing telemetry and response shape determine the pulse. |
| Ground · Gain | 0 | Sets reverse-thrust vibration with valid reverser and engine conditions. Zero removes the cue. |
| Engine · Enabled | True | Enables engine cues with nonzero settings and valid running-engine telemetry. |
| Engine · Gain | 0.06 | Sets estimated engine vibration using configured telemetry and response, not measured cockpit vibration. |
| Mechanical · Enabled | True | Enables accessory cues with configured strengths and observed accessory movement. |
| Mechanical · Gain | 0.12 | Sets texture from observed flap movement; a command without movement does not establish the cue. |
| Mechanical · Gain | 0.12 | Sets texture from observed gear movement, separate from aerodynamic and touchdown effects. |
如果你的真机经验表明本页有误,请在此指正。
本页基于引用资料构建,而真机经验胜过任何引用。 请引用有误的主张,并告诉我们真机的实际表现。纠错 将交由维护者审核,并纳入本研究的下一次修订。
关于 North American Rockwell OV-10 Bronco 的飞行与调校的公开讨论(社区论坛)。上方的纠错将私下送达维护者;机库闲谈是公开的。