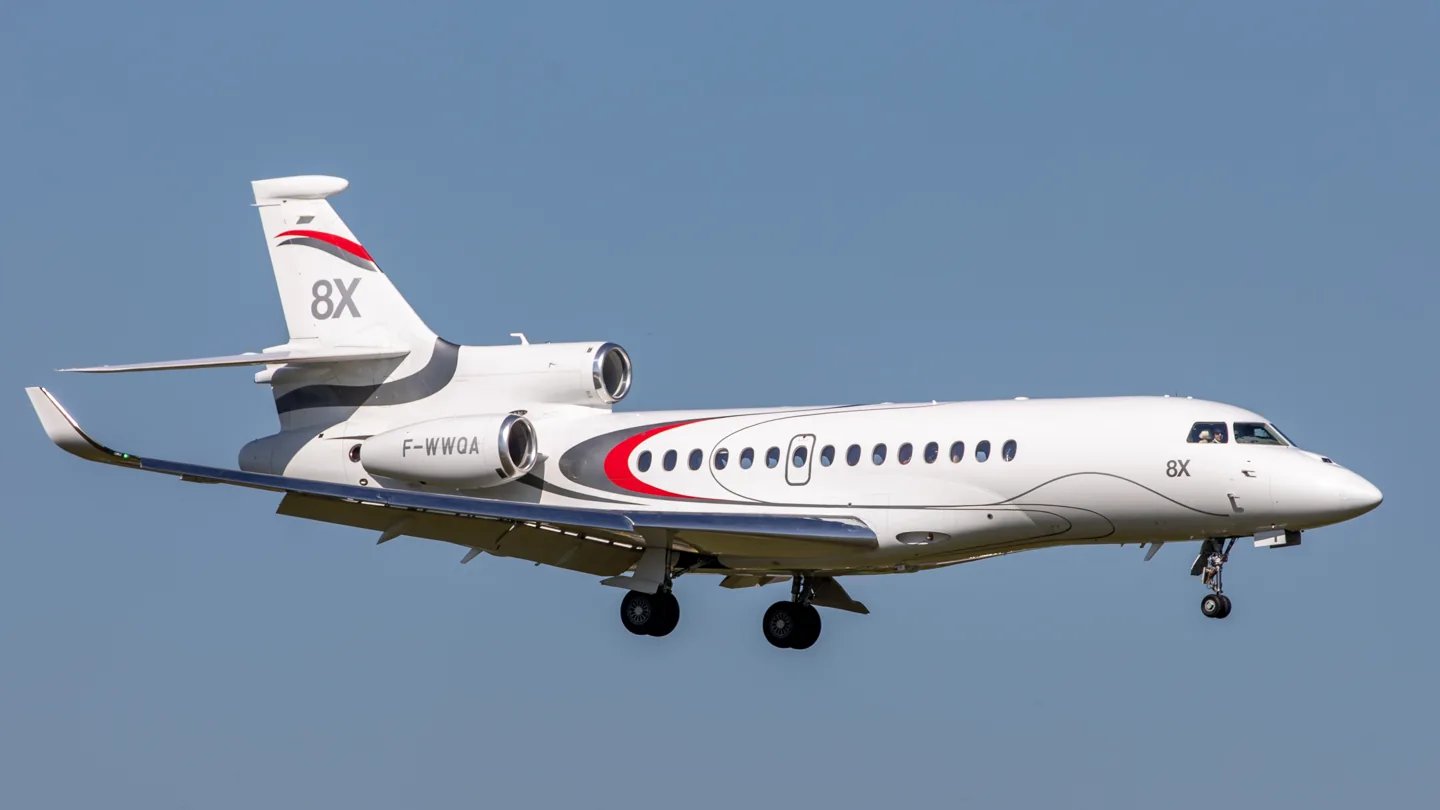
Dassault Falcon 8XMatti Blume · CC BY-SA 4.0 · Falcon 8X in flight (Paris Air Show 2019)

Dassault Falcon 8X

Dassault's long-range Falcon 8X, developed from the three-engine 7X.
Business jetLiczba opcji profilu: 1

Poznaj maszynę

The Falcon 8X extends the 7X lineage through aerodynamic changes, engine optimization and additional fuel capacity. First deliveries took place in October 2016. The selected background reference covers the 7X and 8X, with figures labelled by model. The simulator listing records its product's development status.

Falcon 8X: manufacturer specifications

Wingspan
26.29 m↗
Length
24.46 m↗
Height
7.94 m↗
Maximum takeoff weight
33,113 kg↗
Engines
3 Pratt & Whitney Canada PW307D↗
Maximum operating Mach
0.90↗
Maximum certified altitude
51,000 ft↗
Cabin length
13 m↗
Range
6,450 nm; 8 passengers, NBAA IFR reserves↗

Więcej o tym statku powietrznym w AirframeDB

Bordeaux launches the 8X flight-test campaign

Dassault’s announcement dates the first flight to 6 February 2015 at Bordeaux-Mérignac. Eric Gérard and Hervé Laverne flew the first prototype, beginning the airborne phase of a programme whose remaining test and certification work lay ahead.

Approach figures depend on landing weight

Dassault quotes a 107 KIAS reference approach speed at typical landing weight. That condition belongs with the number: it is not a single approach speed for every weight and configuration. The 8X uses digital flight controls and three PW307D engines.

Learning the feel of an instrumented prototype

George encountered the 8X as a working test aircraft, with ballast tanks and instrumentation taking the place of a finished passenger cabin. Gérard occupied the right seat and Lascourrèges the jumpseat. He assessed handling during development in a test aircraft.

The first moments of taxiing required adjustment to the steering and brakes, which initially felt sensitive. Once flying, George appreciated the sidestick’s balance of pitch and roll forces and the feedback through his hand. His account follows the process of becoming comfortable with unfamiliar controls, keeping those personal impressions separate from the performance work still belonging to the wider test programme.

A first flight brings a test pilot both pride and anticipation

Gérard and Laverne took the first Falcon 8X prototype into the air from Bordeaux-Mérignac for a flight lasting one hour and forty-five minutes. The programme included handling checks, system tests and a climb to high altitude before the crew returned to the departure airport. It was the beginning of the aircraft’s flying test campaign.

Gérard described the experience with pride, saying the flight had met its objectives and exceeded some of them. He felt honoured to participate and expressed confidence about the work ahead. Those remarks record the pilot’s reaction to a successful first outing; his optimism concerned a programme still to be completed, rather than an announcement that development or certification had already finished.

Simulator preparation meets a real traffic alert and an imperfect flare

A simulator session gave Thurber time to explore the 8X’s controls before flying the aircraft at Istres the next day. In the air, small sidestick movements soon felt comfortable, although steep turns were less tidy when he worked against the stick’s resistance. He became more familiar with the aircraft through the manoeuvres.

The return included his first actual traffic-collision avoidance resolution advisory, followed by a landing that needed correction after he began the flare too high. A little additional power helped produce a smooth arrival.

Źródła publiczne 7
  1. Dassault Falcon 7XResearch background · retrieved 2026-09-12
  2. Falcon 8XOfficial developer / designated store catalogue · checked 2026-09-12
  3. Left Seat on Flight 92: Falcon 8XFred George · November 2015 issue
  4. Falcon 8X Completes First Flight6 February 2015 · Eric Gérard and Hervé Laverne
  5. Pilot Report: Falcon 8XMatt Thurber · January 2017; seven-page publisher PDF preserved by the Internet Archive
  6. ICAO Doc 8643 — aircraft type designatorsPublic search data retrieved 2026-09-14; authority update 2026-09-03
  7. Falcon 8X specificationsFalcon 8X: manufacturer specifications

Jak odwzorowuje to profil

Dassault Falcon 8X

Free + Pro

The Falcon 8X extends the 7X lineage through aerodynamic changes, engine optimization and additional fuel capacity. First deliveries took place in October 2016. The selected background reference covers the 7X and 8X, with figures labelled by model. The simulator listing records its product's development status.

This starting point selects Dassault Falcon 8X. Its aircraft-level settings do not select a particular developer’s custom systems.

The fixed-centre choice represents an electronic-control inceptor. The spring stays independent of airspeed. Directed aerodynamic loading is omitted. Enabled travel curves shape pitch and roll resistance separately.

Aircraft trim is separate from the configured hardware centre. Aircraft trim retains the fixed hardware centre. Autopilot following is off.

Ta konkretna rewizja nie została jeszcze udostępniona do publicznej instalacji.

Controls and trim

The Falcon 8X extends the 7X through aerodynamic changes, optimized engines and additional fuel capacity. Deliveries began in October 2016. Its electronic flight-control background belongs to this later aircraft, while the simulator’s development status is a separate product fact.

Dassault DFCS backgrounder

About the values

The gains are normalized profile settings. They describe the chosen effect balance; hand force depends on the device and its output limits. IAS references are tuning values rather than operating limits. Physical acceptance of this revision remains pending.

Wzmocnienie główne i układ sterowania

Master gain85%

Końcowy, ogólny mnożnik wyjścia stosowany do wszystkiego, co wytwarza model, przed ograniczeniem urządzenia.

Więcej: wszystko (sprężyna, obciążenia, efekty) staje się silniejsze jednocześnie.

Mniej: wszystko jednocześnie łagodnieje.

Dlaczego tutaj: Scales overall profile strength while preserving effect balance, subject to device and output limits.

Siły

Spring strength55%

Podstawowa siła centrująca, która ściąga drążek z powrotem do środka. Wszystkie inne siły nakładają się na nią. Zbyt niska, a drążek w normalnym locie jest wiotki; zbyt wysoka, a walczy z twoją ręką i zagłusza drobniejsze efekty nałożone na nią.

Więcej: mocniejsze centrowanie, które przez cały czas stawia opór twojej ręce.

Mniej: bardziej wiotki drążek, który opiera się wyłącznie na obciążeniu aerodynamicznym.

Dlaczego tutaj: The fixed-centre choice represents an electronic-control inceptor. The baseline spring is 0.55. The electronic-control law keeps centering independent of airspeed.

Dassault DFCS backgrounder
Spring deadband1%

Niewielka neutralna strefa wokół środka, w której sprężyna pozostaje nieaktywna, dzięki czemu drobne ruchy w spoczynku nie wywołują trzepotania. Szersza strefa jest spokojniejsza, ale luźniejsza; węższa jest precyzyjniejsza, ale drążek może podrygiwać wokół środka.

Więcej: spokojniejszy, lecz swobodniejszy środek z większym luzem.

Mniej: bardziej zwarty środek, który w spoczynku może trzepotać.

Dlaczego tutaj: Sets travel around the centre before the baseline spring resists. Smaller values engage it sooner.

Forces · Center starting force0.03

Dlaczego tutaj: The centre preload is 0.03. It ramps outside the 0.01 deadband across 0.05 travel, shaping the passive centre independently of aircraft autotrim.

Forces · Center starting force transition0.05

Dlaczego tutaj: Sets the travel used to ramp in centre preload. Wider intervals make its onset more gradual.

Overall aerodynamic load4%

Nadrzędny mnożnik dla obu utrzymujących się obciążeń osi, stosowany przed ich niezależnym wyważeniem. Profile zwykle zostawiają go bez zmian i zamiast tego dostrajają oba obciążenia osi.

Więcej: obie osie są mocniej obciążone.

Mniej: obie osie jednocześnie stają się lżejsze.

Dlaczego tutaj: The stored 0.04 aerodynamic-load gain is inactive under the fixed-centre control law.

Airspeed blendingFalse

Włącza okno stopniowego włączania sprężyny przy małej prędkości (węzły początku i pełnej siły powyżej). Po wyłączeniu sprężyna jest stała przy każdej prędkości.

Dlaczego tutaj: Allows baseline spring strength to rise with indicated airspeed where the control law permits it.

Low-speed spring floor50%

Jaka część sprężyny pozostaje na postoju, zanim prędkość zdąży wytworzyć jakąkolwiek siłę aerodynamiczną. Przy wysokiej dolnej granicy drążek na postoju pozostaje sztywny; przy niskiej jest luźny, z luzem linek jak w zaparkowanym lekkim statku powietrznym.

Więcej: sztywniejszy drążek na postoju i podczas kołowania.

Mniej: luźniejszy drążek na postoju, który ożywa dopiero wraz z prędkością.

Dlaczego tutaj: Sets low-speed spring strength as a fraction of baseline when blending is enabled. One keeps full strength.

Spring engagement start20 kt

Prędkość, przy której sprężyna zaczyna rosnąć od dolnej granicy dla małej prędkości w stronę pełnej siły: stery „ożywają” podczas rozbiegu.

Dlaczego tutaj: Sets the IAS where the low-speed spring blend starts rising. This is a feel threshold, not a flight limit.

Spring engagement full90 kt

Prędkość, przy której sprężyna osiąga pełną siłę. Między punktem początkowym a tym punktem centrowanie stopniowo sztywnieje w miarę narastania opływu powietrza wokół sterów.

Dlaczego tutaj: Sets the IAS where the low-speed blend reaches baseline strength; high-speed stiffening also uses it.

Prędkość dostrajania siły270

Prędkość przyrządowa, przy której obciążenie aerodynamiczne osiąga zakładany pełny poziom. Zakotwicza całą krzywą obciążenia w rzeczywistym zakresie prędkości statku powietrznego: 172 nabiera pełnego obciążenia do 110 węzłów, odrzutowiec znacznie później.

Więcej: obciążenia pojawiają się później; drążek pozostaje lekki do wyższej prędkości.

Mniej: obciążenia pojawiają się wcześniej, a przelot wydaje się cięższy.

Dlaczego tutaj: Sets the IAS reference for aerodynamic loading. It is an estimate, not published cruise TAS or a flight limit.

Centre firmness vs speed0%

Jak bardzo samo centrowanie sztywnieje wraz z prędkością, oprócz obciążeń od wychylenia. Zero utrzymuje stałe czucie środka; więcej sprawia, że drążek centruje się mocniej w przelocie i luźniej w kręgu nadlotniskowym.

Więcej: środek, który wyraźnie twardnieje wraz ze wzrostem prędkości.

Mniej: stałe czucie środka przy każdej prędkości.

Dlaczego tutaj: Adds permitted spring resistance above the full-blend speed. Zero removes this high-speed increase.

Centre stiffening cap5

Górna granica zależnego od prędkości sztywnienia środka, aby bardzo szybki lot nie mógł napinać sprężyny bez ograniczeń.

Więcej: większe łączne usztywnienie dopuszczalne przy dużej prędkości.

Mniej: usztywnianie zostaje wcześniej ograniczone.

Dlaczego tutaj: Limits the squared airspeed ratio used for high-speed spring stiffening; it is not a device-force cap.

Aileron load100%

Utrzymujące się obciążenie przechylenia wynikające z wychylenia lotek i prędkości, wyważane niezależnie od pochylenia. Razem z obciążeniem steru wysokości wyznacza proporcję harmonii sterów, o której piszą recenzenci.

Więcej: większe siły przechylenia.

Mniej: lżejsze lotki, które wydają się szybsze.

Dlaczego tutaj: Roll and pitch aerodynamic scales are 1 and 1, respectively. These stored weights do not create directed aerodynamic loading while that term is inactive. The pitch spring-travel curve reaches output 1 at input 1. The roll spring-travel curve reaches output 0.3 at input 1. Spring-travel response contributes separately to axis balance.

Elevator load100%

Utrzymujące się obciążenie pochylenia wynikające z wychylenia steru wysokości i prędkości, wyważane niezależnie od przechylenia. To główny parametr decydujący o ciężarze pochylenia danego typu. Nie wpływa na siły lotek, sprężyny, trymera ani drgań.

Więcej: większe utrzymujące się siły pochylenia w locie.

Mniej: lżejszy ster wysokości, którego utrzymanie wymaga mniej siły mięśni.

Dlaczego tutaj: Scales pitch aerodynamic loading; pitch spring travel and trim responses are separate settings.

Max output force55%

Ograniczenie każdej ustalonej siły pochylenia lub przechylenia, zanim dotrze do urządzenia; chroni sprzęt przed gwałtownymi uderzeniami lub nasyceniem podczas mocnych manewrów.

Więcej: silniejsze szczytowe siły ustalone przed obcięciem.

Mniej: łagodniejszy limit; przy ostrych manewrach siły wcześniej się wypłaszczają.

Dlaczego tutaj: Caps directed-force output. Native spring effects and device limits remain separate.

Trymer

Trim relief (elevator)0%

Jak mocno trymer steru wysokości odciąża utrzymywaną siłę pochylenia i przesuwa punkt, w którym drążek się ustala. Przy 100% poprawnie wytrymowany statek powietrzny nie wymaga utrzymywania nacisku — tak jak w prawdziwym lataniu, gdzie obciążenie usuwa się trymerem.

Więcej: trymer usuwa większą część utrzymywanej siły pochylenia; przy 100% pełne wytrymowanie całkowicie ją znosi.

Mniej: nawet po wytrymowaniu nadal musisz utrzymywać siłę.

Dlaczego tutaj: Aircraft trim is separate from the configured hardware centre. Pitch relief is off, with stored authority 0; roll authority is 0.

Dassault DFCS backgrounder
Trim relief (aileron)0%

To samo odciążenie dla trymera przechylenia. Większość typów lotnictwa ogólnego nie ma prawdziwego trymera lotek, więc wartość pozostaje zerowa; typy z trymerem przechylenia otrzymują odpowiednią wartość.

Więcej: trymer przechylenia usuwa więcej utrzymywanej siły przechylenia.

Mniej: trymer przechylenia działa słabiej.

Dlaczego tutaj: Scales supported roll-trim relief and permitted centre movement. Zero removes roll response.

Wzmocnienia efektów · Podłoże

Runway rumble0%

Wibracje toczenia zależne od prędkości kół i rodzaju nawierzchni: asfalt, trawa lub żwir pod podwoziem.

Więcej: wyraźniejsza faktura nawierzchni wyczuwalna w drążku.

Mniej: płynniejsze kołowanie.

Dlaczego tutaj: Sets rolling texture strength, modified by speed, surface and undercarriage configuration.

Gear bumps0%

Krótkie, pojedyncze wstrząsy od szczelin dylatacyjnych, kolein i nierównej nawierzchni, przerywające ciągłe wibracje.

Więcej: ostrzejsze uderzenia od szczelin i kolein.

Mniej: łagodniejsze szczegóły nawierzchni.

Dlaczego tutaj: Sets gear-bump texture during ground motion, separate from touchdown impact.

Wzmocnienia efektów · Płatowiec

Stall buffet6%

Drgania płatowca przy zbliżaniu się do przeciągnięcia i gdy aktywne jest ostrzeżenie o przeciągnięciu: jak głośno to skrzydło sygnalizuje, że coś mu nie odpowiada. Typy z wyraźnym, ostrym przeciągnięciem dostają umiarkowane drgania, a ostrzeżenie przekazuje sygnalizator dźwiękowy.

Więcej: wyraźniejsze drgania przy zbliżaniu się do przeciągnięcia.

Mniej: spokojniejsze skrzydło; ostrzeżenie przekazuje sygnalizator dźwiękowy.

Dlaczego tutaj: Sets stall-buffet strength. Zero removes the cue without changing simulator stalls or warnings.

Mach buffet6%

Drgania transoniczne przy zbliżaniu się do ograniczenia liczby Macha. Istotne dla odrzutowców w pobliżu MMO, zero dla samolotów tłokowych i turbośmigłowych, które nigdy tam nie docierają.

Więcej: silniejsze drgania transoniczne w pobliżu ograniczenia liczby Macha.

Mniej: spokojniejszy lot przy dużej liczbie Macha.

Dlaczego tutaj: Sets high-Mach buffet strength; onset and full-strength thresholds are separate.

Flap buffet0%

Niskoczęstotliwościowe wibracje płatowca przy klapach wypuszczonych w strumień powietrza, w zakresie prędkości, w którym faktycznie pracują w opływie.

Więcej: mniej spokojny lot przy klapach pracujących w opływie.

Mniej: spokojniejsze klapy w podejściu.

Dlaczego tutaj: Sets flap buffet at the configured position and speed gates. Flap movement texture is separate.

Gear buffet0%

Dudnienie płatowca od chowanego podwozia wypuszczonego w strumień powietrza. Zero dla typów z podwoziem stałym, w których kształt płatowca nigdy się nie zmienia.

Więcej: więcej dudnienia przy wypuszczonych kołach.

Mniej: czystszy lot z wypuszczonym podwoziem.

Dlaczego tutaj: Sets gear aerodynamic buffet; movement and ground-contact cues are separate.

Stick shaker50%

Osobne wibracje układu stick shaker ostrzegające o przeciągnięciu, wyzwalane przez własny system ostrzegania o przeciągnięciu statku powietrznego. Wartość otrzymują tylko typy z prawdziwym układem stick shaker; wszystkie pozostałe polegają na drganiach aerodynamicznych i sygnalizatorze dźwiękowym.

Więcej: mocniejsze wibracje układu stick shaker.

Mniej: subtelniejszy stick shaker.

Dlaczego tutaj: Sets triggered shaker strength; inactive while the shaker feature is disabled.

Wzmocnienia efektów · Silnik, mechanika i opór

Touchdown thump0%

Jednorazowe szarpnięcie w chwili zetknięcia kół z pasem startowym, skalowane prędkością opadania: miękkie przyziemienie ledwie szepcze, twarde wyraźnie uderza.

Więcej: mocniejsze szarpnięcie przy przyziemieniu.

Mniej: łagodniejsze przyziemienia.

Dlaczego tutaj: Sets landing-impact strength; landing telemetry and response shape determine the pulse.

Reverse rumble0%

Wibracje podczas dobiegu, gdy pracuje ciąg wsteczny lub śmigła w zakresie beta. Zero dla typów bez ciągu wstecznego.

Więcej: bardziej niespokojny dobieg przy ciągu wstecznym.

Mniej: cichszy ciąg wsteczny.

Dlaczego tutaj: Sets reverse-thrust vibration with valid reverser and engine conditions. Zero removes the cue.

Engine rumble0%

Ciągłe wibracje zespołu napędowego zależne od obrotów, od biegu jałowego do pełnej mocy — stale obecne przypomnienie, że z przodu coś spala paliwo.

Więcej: silnik bardziej wyczuwalny w drążku.

Mniej: cichszy zespół napędowy.

Dlaczego tutaj: Sets estimated engine vibration using configured telemetry and response, not measured cockpit vibration.

Flap motion0%

Ciągłe wibracje tylko wtedy, gdy symulator zgłasza, że klapy faktycznie się przemieszczają. Efekt odwzorowuje rzeczywisty ruch siłowników i ich awarie, a nie szacowany licznik czasu.

Więcej: więcej wibracji podczas ruchu klap.

Mniej: cichsze przestawianie klap.

Dlaczego tutaj: Sets texture from observed flap movement; a command without movement does not establish the cue.

Podążanie za autopilotem

AP follow authority5%

Jak daleko polecenia autopilota mogą fizycznie przesunąć drążek. W MSFS utrzymywane na minimalnym poziomie, bo przesunięta oś może zostać odczytana jako działanie pilota; zero całkowicie wyłącza podążanie.

Więcej: autopilot widocznie wychyla twój drążek dalej.

Mniej: ledwo wyczuwalne podążanie.

Dlaczego tutaj: Sets admitted AP-follow gain, not a percentage of travel. Runtime ownership and input limits still apply.

Spring response

SpringResponse · Travel enabledTrue

Whether this feature is active in this profile.

Dlaczego tutaj: Applies the configured pitch and roll spring travel curves.

SpringResponse · Output1

Dlaczego tutaj: Sets response at the second pitch-curve point; it is an endpoint only if its input position is full travel.

SpringResponse · Output0.3

Dlaczego tutaj: Sets response at the second roll-curve point; its input position and other points determine the travel law.

Stick feel

StickFeel · Trim feel enabledFalse

Whether this feature is active in this profile.

Dlaczego tutaj: Retained for compatibility and group membership. Trim relief, rather than this flag, controls centre movement.

StickFeel · Trim relief enabledFalse

Whether this feature is active in this profile.

Dlaczego tutaj: Allows trim relief with supported control law and valid telemetry. Axis authorities set its amount.

StickFeel · Force trim enabledFalse

Whether this feature is active in this profile.

Dlaczego tutaj: Enables local force trim, separate from aircraft-owned trim and add-on integration qualification.

StickFeel · G load enabledFalse

Whether this feature is active in this profile.

Dlaczego tutaj: Allows load-factor changes to modify permitted spring laws. Passive fly-by-wire feel can suppress it.

StickFeel · Rate damping enabledFalse

Whether this feature is active in this profile.

Dlaczego tutaj: Enables rate damping with the configured coefficients and control law.

Autopilot

Autopilot · Follow enabledFalse

Whether this feature is active in this profile.

Dlaczego tutaj: Autopilot following is off; the configured spring and load retain the hardware feel. Separate neutral hold is on at strength 0.28, when a supported autopilot state admits it.

Autopilot · Neutral hold enabledTrue

Whether this feature is active in this profile.

Dlaczego tutaj: Permits centering hold during a supported AP state, separate from following a moving target.

Autopilot · Neutral hold strength0.28

Dlaczego tutaj: Sets admitted AP neutral-hold strength; inactive while neutral hold is disabled.

Aero

Aero · EnabledTrue

Whether this feature is active in this profile.

Dlaczego tutaj: Enables aerodynamic cues; each still needs nonzero strength and its simulator conditions.

Aero · Max flap index3

Where this effect reaches full strength (or has fully faded, for washouts).

Więcej: a more gradual build to a later peak.

Mniej: a quicker build.

Dlaczego tutaj: Sets the final flap index for detent normalization. UP plus three detents uses maximum index3.

Aero · Min flap index2

Where this effect begins fading in.

Więcej: the effect begins later.

Mniej: it begins earlier.

Dlaczego tutaj: Sets the first flap detent that admits buffet; this is a handle index, not degrees.

Aero · Shaker enabledFalse

Whether this feature is active in this profile.

Dlaczego tutaj: Permits shaker at supported warning conditions; the switch does not establish aircraft equipment.

Ground

Ground · EnabledFalse

Whether this feature is active in this profile.

Dlaczego tutaj: Enables ground effects; each still needs its own strength and contact or motion telemetry.

Engine

Engine · EnabledFalse

Whether this feature is active in this profile.

Dlaczego tutaj: Enables engine cues with nonzero settings and valid running-engine telemetry.

Mechanical

Mechanical · EnabledTrue

Whether this feature is active in this profile.

Dlaczego tutaj: Enables accessory cues with configured strengths and observed accessory movement.

Mechanical · Gain0

The strength of this effect.

Więcej: a stronger effect.

Mniej: a weaker one.

Dlaczego tutaj: Sets texture from observed gear movement, separate from aerodynamic and touchdown effects.

Wszystkie ustawienia profilu
Szacowane ustawienia profilu
ParametrWartośćCo reguluje i dlaczego
Spring strength0.55 The fixed-centre choice represents an electronic-control inceptor. The baseline spring is 0.55. The electronic-control law keeps centering independent of airspeed.
Spring deadband0.01 Sets travel around the centre before the baseline spring resists. Smaller values engage it sooner.
Forces · Center starting force0.03 The centre preload is 0.03. It ramps outside the 0.01 deadband across 0.05 travel, shaping the passive centre independently of aircraft autotrim.
Forces · Center starting force transition0.05 Sets the travel used to ramp in centre preload. Wider intervals make its onset more gradual.
Force gain0.04 The stored 0.04 aerodynamic-load gain is inactive under the fixed-centre control law.
Master gain0.85 Scales overall profile strength while preserving effect balance, subject to device and output limits.
Dynamic-pressure blendFalse Allows baseline spring strength to rise with indicated airspeed where the control law permits it.
Minimum spring factor0.5 Sets low-speed spring strength as a fraction of baseline when blending is enabled. One keeps full strength.
Spring wake-up speed20 ktSets the IAS where the low-speed spring blend starts rising. This is a feel threshold, not a flight limit.
Spring full-strength speed90 ktSets the IAS where the low-speed blend reaches baseline strength; high-speed stiffening also uses it.
Prędkość dostrajania siły270.0 ktSets the IAS reference for aerodynamic loading. It is an estimate, not published cruise TAS or a flight limit.
Airspeed spring stiffening0 Adds permitted spring resistance above the full-blend speed. Zero removes this high-speed increase.
Airspeed stiffening cap5 Limits the squared airspeed ratio used for high-speed spring stiffening; it is not a device-force cap.
Aileron force scale1 Roll and pitch aerodynamic scales are 1 and 1, respectively. These stored weights do not create directed aerodynamic loading while that term is inactive. The pitch spring-travel curve reaches output 1 at input 1. The roll spring-travel curve reaches output 0.3 at input 1. Spring-travel response contributes separately to axis balance.
Elevator force scale1 Scales pitch aerodynamic loading; pitch spring travel and trim responses are separate settings.
Maximum output force0.55 Caps directed-force output. Native spring effects and device limits remain separate.
SpringResponse · Travel enabledTrue Applies the configured pitch and roll spring travel curves.
SpringResponse · Output1 Sets response at the second pitch-curve point; it is an endpoint only if its input position is full travel.
SpringResponse · Output0.3 Sets response at the second roll-curve point; its input position and other points determine the travel law.
StickFeel · Trim feel enabledFalse Retained for compatibility and group membership. Trim relief, rather than this flag, controls centre movement.
StickFeel · Trim relief enabledFalse Allows trim relief with supported control law and valid telemetry. Axis authorities set its amount.
StickFeel · Elevator authority0 Aircraft trim is separate from the configured hardware centre. Pitch relief is off, with stored authority 0; roll authority is 0.
StickFeel · Aileron authority0 Scales supported roll-trim relief and permitted centre movement. Zero removes roll response.
StickFeel · Force trim enabledFalse Enables local force trim, separate from aircraft-owned trim and add-on integration qualification.
StickFeel · G load enabledFalse Allows load-factor changes to modify permitted spring laws. Passive fly-by-wire feel can suppress it.
StickFeel · Rate damping enabledFalse Enables rate damping with the configured coefficients and control law.
Autopilot · Follow enabledFalse Autopilot following is off; the configured spring and load retain the hardware feel. Separate neutral hold is on at strength 0.28, when a supported autopilot state admits it.
Autopilot · Follow authority0.05 Sets admitted AP-follow gain, not a percentage of travel. Runtime ownership and input limits still apply.
Autopilot · Neutral hold enabledTrue Permits centering hold during a supported AP state, separate from following a moving target.
Autopilot · Neutral hold strength0.28 Sets admitted AP neutral-hold strength; inactive while neutral hold is disabled.
Aero · EnabledTrue Enables aerodynamic cues; each still needs nonzero strength and its simulator conditions.
Aero · Gain0.06 Sets stall-buffet strength. Zero removes the cue without changing simulator stalls or warnings.
Aero · Gain0.06 Sets high-Mach buffet strength; onset and full-strength thresholds are separate.
Aero · Gain0 Sets flap buffet at the configured position and speed gates. Flap movement texture is separate.
Aero · Max flap index3 Sets the final flap index for detent normalization. UP plus three detents uses maximum index3.
Aero · Min flap index2 Sets the first flap detent that admits buffet; this is a handle index, not degrees.
Aero · Gain0 Sets gear aerodynamic buffet; movement and ground-contact cues are separate.
Aero · Shaker enabledFalse Permits shaker at supported warning conditions; the switch does not establish aircraft equipment.
Aero · Amplitude0.5 Sets triggered shaker strength; inactive while the shaker feature is disabled.
Ground · EnabledFalse Enables ground effects; each still needs its own strength and contact or motion telemetry.
Ground · Gain0 Sets rolling texture strength, modified by speed, surface and undercarriage configuration.
Ground · Gain0 Sets gear-bump texture during ground motion, separate from touchdown impact.
Ground · Gain0 Sets landing-impact strength; landing telemetry and response shape determine the pulse.
Ground · Gain0 Sets reverse-thrust vibration with valid reverser and engine conditions. Zero removes the cue.
Engine · EnabledFalse Enables engine cues with nonzero settings and valid running-engine telemetry.
Engine · Gain0 Sets estimated engine vibration using configured telemetry and response, not measured cockpit vibration.
Mechanical · EnabledTrue Enables accessory cues with configured strengths and observed accessory movement.
Mechanical · Gain0 Sets texture from observed flap movement; a command without movement does not establish the cue.
Mechanical · Gain0 Sets texture from observed gear movement, separate from aerodynamic and touchdown effects.
Źródła publiczne 8
  1. Dassault Falcon 7XResearch background · retrieved 2026-09-12
  2. Dassault DFCS backgrounderDassault Falcon 8X
  3. Falcon 8XOfficial developer / designated store catalogue · checked 2026-09-12
  4. Left Seat on Flight 92: Falcon 8XFred George · November 2015 issue
  5. Falcon 8X Completes First Flight6 February 2015 · Eric Gérard and Hervé Laverne
  6. Pilot Report: Falcon 8XMatt Thurber · January 2017; seven-page publisher PDF preserved by the Internet Archive
  7. ICAO Doc 8643 — aircraft type designatorsPublic search data retrieved 2026-09-14; authority update 2026-09-03
  8. Falcon 8X specificationsFalcon 8X: manufacturer specifications

Społeczność i poprawki

Jeśli twój nalot na tym typie wskazuje, że na tej stronie jest błąd, popraw go tutaj.

Poprawki od pilotów

Latasz tym statkiem powietrznym? Popraw tę stronę.

Ta strona powstała na podstawie cytowanych źródeł, ale rzeczywisty nalot na tym typie jest cenniejszy niż cytat. Zacytuj twierdzenie, które wydaje się błędne, i opisz, jak zachowuje się prawdziwy statek powietrzny. Poprawki trafiają do opiekuna do weryfikacji i zasilają następną wersję tego opracowania.

Rozmowy w hangarze

Otwarta rozmowa na forum społeczności o lataniu statkiem powietrznym Dassault Falcon 8X i jego strojeniu. Poprawki powyżej trafiają prywatnie do opiekuna; rozmowy w hangarze są publiczne.

Nie ma jeszcze rozmów w hangarze o statku powietrznym Dassault Falcon 8X. Rozpocznij pierwszą rozmowę.

Społeczność

Profile społeczności dla tego statku powietrznego

Nie ma jeszcze profili społeczności dla tego statku powietrznego. Masz własne strojenie? Udostępnij profil — pojawi się tutaj.