Development milestones
First flight: May 24, 1956
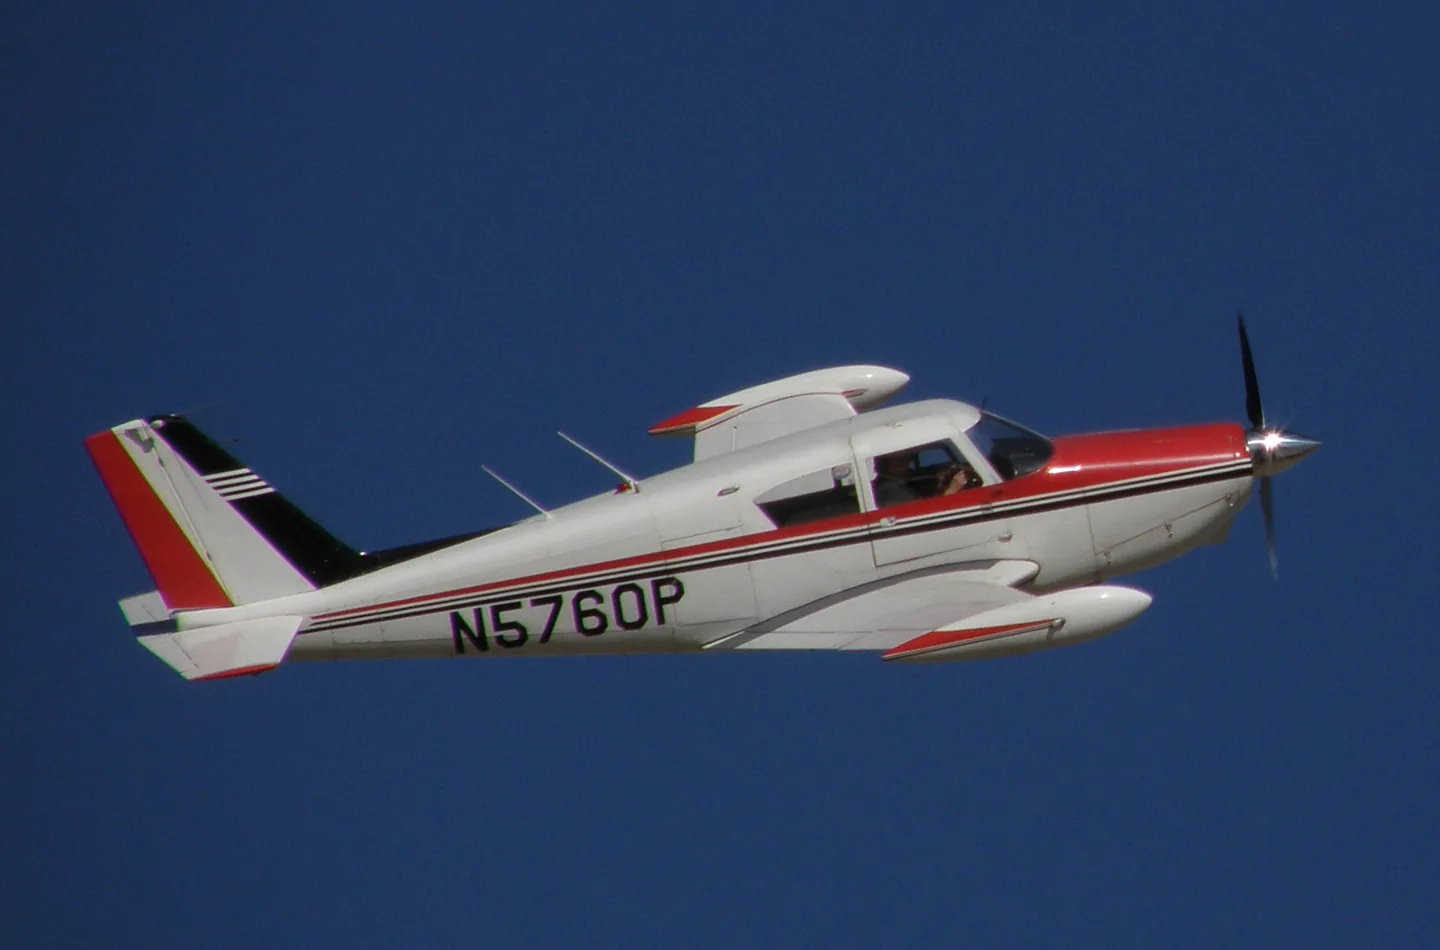 Alan Radecki Akradecki · CC BY-SA 4.0 · Piper PA-24 Comanche pictured
Piper's Comanche first flew in 1956 with an all-metal low-wing airframe, enclosed cabin and retractable tricycle gear. Later versions changed engine power and seating, alongside the separate Twin Comanche line.
Production ended after the 1972 flood at Piper's Lock Haven plant. A2A models a particular Comanche with persistent engine and airframe condition; its manual describes the loading, maintenance and mechanical systems included in the simulation.
Piper PA-24 Comanche · Specifications (PA-24-260C) · real aircraft; source units retained
First flight: May 24, 1956
The Comanche 250’s pitch control uses a stabilator: the horizontal tail moves as a unit instead of carrying a separate hinged elevator. Its anti-servo tab also provides longitudinal trim. A2A’s aircraft description pairs that arrangement with manually operated flaps and conventional yoke-and-pedal controls. This combination gives the cockpit several distinct mechanical controls, even before the separate engine and propeller levers are considered.
An electric motor and reduction mechanism beneath the floor move the three landing-gear units through push-pull cables. The nosewheel steering disconnects as the gear retracts, reducing the steering mechanism’s contribution to airborne rudder-pedal loads. The manual also describes a ground anti-retraction switch and separate indications for gear position. The selector operates the documented electrical and mechanical landing-gear system.
The list supplies trim-required lights and AP controls, and identifies the elevator trim handle with a standard SimVar requested in percent.
Unwin flew Mark Bonsall's refurbished 1963 Comanche 250 from Netherthorpe with instructor Nick Riddin. This particular aircraft had fuel injection and a three-blade propeller, so it was not an untouched factory example. With two aboard and partial fuel, it accelerated briskly from the grass strip. Unwin liked the harmonisation of the primary controls and their low initial resistance, although he found the older instrument and engine-control layout less intuitive than a modern cockpit. In airwork, his stalls gave clear warning and little inclination to drop a wing.
The landing and photo flights exposed different demands. He could feel the aircraft entering ground effect and thought excess approach speed would produce a long float; careful speed control rewarded him with successive satisfactory landings. Flying close formation for the photographer required more work, partly because the view from his chosen seat was restrictive. His overall appreciation was for a capable touring aircraft, with handling observations tied to the loading and modifications of the example he actually flew.
Wall's attachment to the Comanche began with a flying-club comparison in 1958. Interviewed by Bill Cox, he recalled flying a loaded Comanche 250 and a contemporary Bonanza between Burbank and Phoenix. He considered the Comanche the stronger performer in that particular comparison, while acknowledging the appeal of the Beechcraft's handling. Decades later, after a professional flying career, that experience helped draw him back to a 1958 Comanche of his own.
By the 2005 article, Wall had accumulated more than a thousand hours in the type and restored his aircraft extensively. He distinguished brochure claims from his experience: the advertised climb figure seemed optimistic to him, while maximum cruise was closer to what he observed. His usual choice was an economical high-altitude cruise rather than maximum speed. As an owner and mechanic, he also valued access for maintenance and familiarity with the systems he had rebuilt. These are the preferences and reported results of one experienced owner, rather than a controlled comparison of all Comanches and Bonanzas.
Looking back on his test-flying years, Kershner remembered the Comanche 400 as one of the aircraft that stood out. He identified the two final test aircraft and explained Pug Piper's interest in obtaining high-altitude performance without turbocharging. The extra power gave him an impression reminiscent of a fighter, but he also recalled substantial fuel consumption and troublesome hot starts during the flight-test period. His account concerns the eight-cylinder 400, a different proposition from the familiar 180 and 250.
One flight supplied the story's human detail. Over Lock Haven, he overtook a conventional Comanche and made further passes that prompted its pilot to ask what version he was flying. Kershner gave an evasive answer over the radio, then returned to a reprimand for drawing attention to an aircraft Piper had not yet announced. He also remembered watching the fuel indication move towards empty.
In the manual's developer notes, Gentile explains why A2A chose his own Comanche 250, N6229P, for its new Accu-Sim system. He had owned and operated the aeroplane for more than a decade. That familiarity gave the team continuing access to an aircraft they could examine and fly while investigating questions raised during development. His account describes the connection between an owner's long experience and the choice of a simulation subject.
Gentile's affection is equally explicit. He values the Comanche's combination of speed, load-carrying ability, cabin room and manageable handling, and says the aircraft has become part of the family. The appeal began with its appearance and deepened over years of operation. This is an enthusiastic owner's introduction, written by the developer selling the simulation, rather than an independent comparison flight.
Piper's Comanche first flew in 1956 with an all-metal low-wing airframe, enclosed cabin and retractable tricycle gear. Later versions changed engine power and seating, alongside the separate Twin Comanche line.
This profile selects A2A Comanche 250 for MSFS 2020, MSFS 2024.
The stabilator/anti-servo arrangement motivates reversible yoke loading. Spring resistance builds with the selected airspeed response. A separate aerodynamic term adds speed-dependent control load.
The anti-servo tab supplies pitch relief; ALT-mode trim lamps request manual action. Valid trim provides the configured pressure relief. Autopilot following is enabled for supported control references.
The Comanche’s manually controlled stabilator uses an anti-servo tab for longitudinal trim. A2A’s S-TEC30 altitude hold has an elevator servo and lamps requesting pilot trim, without automatic pitch trim. Native 2024 GPSS supplies lateral steering as a separate addition.
A2A’s native 2024 Comanche removes the earlier Elevator Force tablet input option and adds ST901 GPSS lateral guidance; S-TEC30 ALT still requests manual trimming.
The gains are normalized profile settings. They describe the chosen effect balance; hand force depends on the device and its output limits. IAS references are tuning values rather than operating limits. Physical acceptance of this revision remains pending.
모델이 만드는 모든 것에 적용되는 최종 전체 출력 스케일로, 장치 상한 이전에 적용됩니다.
올리면: 모든 것(스프링, 하중, 효과)이 함께 강해집니다.
내리면: 모든 것이 함께 부드러워집니다.
이 값의 이유: Scales overall profile strength while preserving effect balance, subject to device and output limits.
스틱을 중앙으로 되돌리는 기본 센터링 힘입니다. 다른 모든 힘이 이 위에 쌓입니다. 너무 낮으면 정상 비행에서 스틱이 흐물거리고, 너무 높으면 손에 맞서며 그 위에 겹쳐진 작은 신호들을 가립니다.
올리면: 손에 더 저항하는 단단한 센터링.
내리면: 공기역학 하중에만 기대는 무른 스틱.
이 값의 이유: The stabilator/anti-servo arrangement motivates reversible yoke loading. The baseline spring is 0.74. Its low-speed blend reaches baseline strength at 75 KIAS.
Comanche Pilot ManualComanche variables listExact product and documentation researchNative Comanche중앙 주변에서 스프링이 조용히 머무는 작은 중립 구역으로, 정지 시의 미세한 움직임이 덜컹거리지 않게 합니다. 넓을수록 차분하지만 느슨해지고, 좁을수록 정밀하지만 중앙에서 떨릴 수 있습니다.
올리면: 더 차분하지만 더 느슨한, 유격이 큰 중앙.
내리면: 정지 시 떨릴 수 있는 더 조인 중앙.
이 값의 이유: Sets travel around the centre before the baseline spring resists. Smaller values engage it sooner.
두 지속 축 하중에 걸리는 마스터 스케일로, 각 축의 독립 균형 이전에 적용됩니다. 프로파일은 보통 이것을 두고 두 축 하중을 조정합니다.
올리면: 두 축이 더 강하게 하중을 받습니다.
내리면: 두 축이 함께 가벼워집니다.
이 값의 이유: The aerodynamic-load gain is 0.8 with an indicated-speed reference of 150 KIAS. This supplies speed-dependent loading alongside the spring.
저속 스프링 진입 구간(위의 시작/최대 노트)을 켭니다. 끄면 스프링은 모든 속도에서 일정합니다.
이 값의 이유: Allows baseline spring strength to rise with indicated airspeed where the control law permits it.
속도가 공기역학적 힘을 만들기 전, 정지 상태에서 스프링이 얼마나 남는지입니다. 바닥이 높으면 주기된 스틱이 단단하고, 낮으면 주기된 경비행기의 케이블이 늘어진 듯한 느슨한 감각이 됩니다.
올리면: 주기·지상활주 시 더 단단한 스틱.
내리면: 속도로만 깨어나는 주기 시의 무른 스틱.
이 값의 이유: Sets low-speed spring strength as a fraction of baseline when blending is enabled. One keeps full strength.
스프링이 저속 바닥에서 전체 강도를 향해 오르기 시작하는 속도입니다. 이륙 활주에서 조종면이 "살아나는" 지점입니다.
이 값의 이유: Sets the IAS where the low-speed spring blend starts rising. This is a feel threshold, not a flight limit.
스프링이 전체 강도에 도달하는 속도입니다. 시작점과 이 지점 사이에서 조종면 위 기류가 늘며 센터링이 점차 단단해집니다.
이 값의 이유: Sets the IAS where the low-speed blend reaches baseline strength; high-speed stiffening also uses it.
공기역학 하중이 설계된 최대치에 도달하는 지시 속도입니다. 하중 곡선 전체를 기체의 실제 속도 범위에 고정합니다. 172는 110노트에서 하중이 차오르고, 제트기는 훨씬 나중입니다.
올리면: 하중이 늦게 오고, 더 빠른 속도까지 스틱이 가볍습니다.
내리면: 하중이 일찍 오고 순항이 더 무겁습니다.
이 값의 이유: Sets the IAS reference for aerodynamic loading. It is an estimate, not published cruise TAS or a flight limit.
변위 하중에 더해 센터링 자체가 속도에 따라 얼마나 단단해지는지입니다. 0이면 중앙 감각이 일정하고, 클수록 순항에서 더 단단히, 장주에서 더 느슨하게 센터링됩니다.
올리면: 속도에 따라 뚜렷이 단단해지는 중앙.
내리면: 어떤 속도에서도 일정한 중앙 감각.
이 값의 이유: The high-speed spring-stiffening gain is 0.15. It strengthens the permitted spring response above 75 KIAS, with the squared-speed ratio capped at 5.
속도로 인한 중앙 경화의 상한으로, 초고속 비행이 스프링을 무한정 감아올리지 못하게 합니다.
올리면: 고속에서 더 많은 총 경화 허용.
내리면: 경화가 더 일찍 멈춥니다.
이 값의 이유: Limits the squared airspeed ratio used for high-speed spring stiffening; it is not a device-force cap.
에일러론 변위와 속도에 의한 지속적인 롤 하중으로, 피치와 독립적으로 조정됩니다. 승강타 하중과 함께 리뷰에서 말하는 조종 조화 비율을 정합니다.
올리면: 더 무거운 롤 힘.
내리면: 더 가볍고 생기 있는 에일러론.
이 값의 이유: Roll and pitch aerodynamic scales are 0.72 and 1, respectively. They set the aerodynamic axis balance. No custom spring-travel curve is enabled.
승강타 변위와 속도에 의한 지속적인 피치 하중으로, 롤과 독립적으로 조정됩니다. 기종별 피치 무게를 결정하는 주 레버입니다. 에일러론, 스프링, 트림, 버핏 힘에는 관여하지 않습니다.
올리면: 속도에서 더 무거운 지속 피치 힘.
내리면: 붙들기 가벼운, 더 가뿐한 승강타.
이 값의 이유: Scales pitch aerodynamic loading; pitch spring travel and trim responses are separate settings.
각 정상 피치·롤 힘이 장치에 닿기 전의 상한으로, 강한 기동에서 하드웨어를 때리거나 포화시키지 않게 보호합니다.
올리면: 잘리기 전의 더 높은 정상 힘 피크.
내리면: 더 부드러운 상한. 거친 기동이 더 일찍 평평해집니다.
이 값의 이유: Caps directed-force output. Native spring effects and device limits remain separate.
승강타 트림이 유지 중인 피치 힘을 얼마나 덜어내고 스틱이 안착하는 지점을 옮기는지입니다. 100 %에서는 제대로 트림된 기체에 유지 압력이 필요 없어져, 실제 비행의 하중을-트림으로-지우는 절차 그대로입니다.
올리면: 트림이 더 많은 유지 힘을 덜어냅니다. 100 %에서는 완전 트림이 상쇄합니다.
내리면: 트림해도 힘을 계속 붙들게 됩니다.
이 값의 이유: The anti-servo tab supplies pitch relief; ALT-mode trim lamps request manual action. Pitch authority 0.3 provides load relief and permitted centre movement; roll authority is 0.
Comanche Pilot ManualComanche variables listExact product and documentation researchNative Comanche롤 트림에 대한 같은 경감입니다. 대부분의 GA 기종에는 실제 에일러론 트림이 없어 0으로 두고, 롤 트림이 있는 기종은 상응하는 값을 받습니다.
올리면: 롤 트림이 더 많은 유지 힘을 덜어냅니다.
내리면: 롤 트림의 효과가 줄어듭니다.
이 값의 이유: Scales supported roll-trim relief and permitted centre movement. Zero removes roll response.
바퀴 속도와 노면 종류(포장, 잔디, 자갈)에 따른 구름 진동입니다.
올리면: 스틱의 노면 질감이 더 강하게.
내리면: 더 매끄러운 지상활주.
이 값의 이유: Sets rolling texture strength, modified by speed, surface and undercarriage configuration.
신축 이음, 바퀴 자국, 거친 노면의 짧고 분리된 충격으로, 연속적인 우르릉거림에 마디를 찍습니다.
올리면: 이음과 자국의 더 또렷한 충격.
내리면: 더 부드러운 지면 디테일.
이 값의 이유: Sets gear-bump texture during ground motion, separate from touchdown impact.
실속 접근 시와 실속 경고가 울리는 동안의 기체 흔들림, 이 날개가 불만을 얼마나 크게 알리는지입니다. 깔끔하게 떨어지는 기종은 버핏을 절제하고 경적이 경고를 맡습니다.
올리면: 더 강한 실속 전 떨림.
내리면: 더 은은한 날개. 경적이 경고를 맡습니다.
이 값의 이유: Sets stall-buffet strength. Zero removes the cue without changing simulator stalls or warnings.
마하 한계 접근 시의 천음속 버핏입니다. MMO 근처의 제트기에는 의미가 있고, 거기 도달하지 못하는 피스톤과 터보프롭은 0입니다.
올리면: 마하 한계 근처의 더 강한 천음속 버핏.
내리면: 높은 마하에서 더 매끄러운 비행.
이 값의 이유: Sets high-Mach buffet strength; onset and full-strength thresholds are separate.
플랩이 실제로 공기를 일하는 속도 창에서, 기류에 펼쳐진 플랩에 의한 기체의 저주파 진동입니다.
올리면: 플랩 작동 중 더 거친 비행.
내리면: 더 부드러운 접근 플랩.
이 값의 이유: Sets flap buffet at the configured position and speed gates. Flap movement texture is separate.
기류에 매달린 접이식 착륙장치에 의한 기체의 북소리입니다. 기체 형상이 변하지 않는 고정식 기종은 0입니다.
올리면: 착륙장치 내림 시 더 많은 북소리.
내리면: 더 깔끔한 착륙장치 내림 비행.
이 값의 이유: Sets gear aerodynamic buffet; movement and ground-contact cues are separate.
기체 자체의 실속 경보 시스템이 발동하는 전용 스틱 셰이커 진동입니다. 실제 셰이커가 있는 기종만 값을 받고, 나머지는 공기역학 버핏과 경적에 의존합니다.
올리면: 더 단단한 셰이커.
내리면: 더 은은한 셰이커.
이 값의 이유: Sets triggered shaker strength; inactive while the shaker feature is disabled.
바퀴가 활주로에 닿는 순간의 단발 충격으로, 강하율에 따라 스케일됩니다. 부드러운 착륙은 속삭이고 단단한 도착은 쿵 울립니다.
올리면: 접지 시 더 단단한 충격.
내리면: 더 부드러운 도착.
이 값의 이유: Sets landing-impact strength; landing telemetry and response shape determine the pulse.
역추력이나 베타 범위 프로펠러가 작동하는 동안의 활주 진동입니다. 리버스가 없는 기종은 0입니다.
올리면: 리버스 중 더 거친 활주.
내리면: 더 은은한 리버스.
이 값의 이유: Sets reverse-thrust vibration with valid reverser and engine conditions. Zero removes the cue.
공회전부터 최대 출력까지 회전수를 따르는 연속적인 동력장치 진동으로, 앞에서 무언가 연료를 태우고 있다는 늘 존재하는 상기입니다.
올리면: 스틱에 더 많은 엔진.
내리면: 더 은은한 엔진.
이 값의 이유: Sets estimated engine vibration using configured telemetry and response, not measured cockpit vibration.
시뮬레이터가 플랩 조종면의 실제 이동을 보고하는 동안만의 연속 진동입니다. 추정 타이머가 아니라 실제 액추에이터 동작과 고장을 따릅니다.
올리면: 플랩 이동 중 더 많은 진동.
내리면: 더 은은한 플랩 이동.
이 값의 이유: Sets texture from observed flap movement; a command without movement does not establish the cue.
자동조종 명령이 스틱을 물리적으로 얼마나 움직일 수 있는지입니다. 움직인 축이 조종사 입력으로 읽힐 수 있는 MSFS에서는 극소로 유지하며, 0이면 따라가기가 완전히 꺼집니다.
올리면: 자동조종이 스틱을 눈에 띄게 더 움직입니다.
내리면: 거의 느껴지지 않는 따라가기.
이 값의 이유: Sets admitted AP-follow gain, not a percentage of travel. Runtime ownership and input limits still apply.
Whether this feature is active in this profile.
이 값의 이유: Retained for compatibility and group membership. Trim relief, rather than this flag, controls centre movement.
Whether this feature is active in this profile.
이 값의 이유: Allows trim relief with supported control law and valid telemetry. Axis authorities set its amount.
Whether this feature is active in this profile.
이 값의 이유: Enables local force trim, separate from aircraft-owned trim and add-on integration qualification.
Whether this feature is active in this profile.
이 값의 이유: Allows load-factor changes to modify permitted spring laws. Passive fly-by-wire feel can suppress it.
Whether this feature is active in this profile.
이 값의 이유: Enables rate damping with the configured coefficients and control law.
Whether this feature is active in this profile.
이 값의 이유: Following is on at 1 authority when a supported, valid autopilot control reference is available.
Whether this feature is active in this profile.
이 값의 이유: Permits centering hold during a supported AP state, separate from following a moving target.
이 값의 이유: Sets admitted AP neutral-hold strength; inactive while neutral hold is disabled.
Whether this feature is active in this profile.
이 값의 이유: Enables aerodynamic cues; each still needs nonzero strength and its simulator conditions.
Where this effect reaches full strength (or has fully faded, for washouts).
올리면: a more gradual build to a later peak.
내리면: a quicker build.
이 값의 이유: Sets the final flap index for detent normalization. UP plus three detents uses maximum index3.
Where this effect begins fading in.
올리면: the effect begins later.
내리면: it begins earlier.
이 값의 이유: Sets the first flap detent that admits buffet; this is a handle index, not degrees.
Whether this feature is active in this profile.
이 값의 이유: Permits shaker at supported warning conditions; the switch does not establish aircraft equipment.
Whether this feature is active in this profile.
이 값의 이유: Enables ground effects; each still needs its own strength and contact or motion telemetry.
Whether this feature is active in this profile.
이 값의 이유: Enables engine cues with nonzero settings and valid running-engine telemetry.
Whether this feature is active in this profile.
이 값의 이유: Enables accessory cues with configured strengths and observed accessory movement.
The strength of this effect.
올리면: a stronger effect.
내리면: a weaker one.
이 값의 이유: Sets texture from observed gear movement, separate from aerodynamic and touchdown effects.
| 매개변수 | 값 | 제어 대상과 설정 이유 |
|---|---|---|
| Spring strength | 0.74 | The stabilator/anti-servo arrangement motivates reversible yoke loading. The baseline spring is 0.74. Its low-speed blend reaches baseline strength at 75 KIAS. |
| Spring deadband | 0.045 | Sets travel around the centre before the baseline spring resists. Smaller values engage it sooner. |
| Force gain | 0.8 | The aerodynamic-load gain is 0.8 with an indicated-speed reference of 150 KIAS. This supplies speed-dependent loading alongside the spring. |
| Master gain | 0.85 | Scales overall profile strength while preserving effect balance, subject to device and output limits. |
| Dynamic-pressure blend | True | Allows baseline spring strength to rise with indicated airspeed where the control law permits it. |
| Minimum spring factor | 0.5 | Sets low-speed spring strength as a fraction of baseline when blending is enabled. One keeps full strength. |
| Spring wake-up speed | 20 kt | Sets the IAS where the low-speed spring blend starts rising. This is a feel threshold, not a flight limit. |
| Spring full-strength speed | 75.0 kt | Sets the IAS where the low-speed blend reaches baseline strength; high-speed stiffening also uses it. |
| 포스 조정 속도 | 150.0 kt | Sets the IAS reference for aerodynamic loading. It is an estimate, not published cruise TAS or a flight limit. |
| Airspeed spring stiffening | 0.15 | The high-speed spring-stiffening gain is 0.15. It strengthens the permitted spring response above 75 KIAS, with the squared-speed ratio capped at 5. |
| Airspeed stiffening cap | 5 | Limits the squared airspeed ratio used for high-speed spring stiffening; it is not a device-force cap. |
| Aileron force scale | 0.72 | Roll and pitch aerodynamic scales are 0.72 and 1, respectively. They set the aerodynamic axis balance. No custom spring-travel curve is enabled. |
| Elevator force scale | 1.0 | Scales pitch aerodynamic loading; pitch spring travel and trim responses are separate settings. |
| Maximum output force | 0.55 | Caps directed-force output. Native spring effects and device limits remain separate. |
| StickFeel · Trim feel enabled | True | Retained for compatibility and group membership. Trim relief, rather than this flag, controls centre movement. |
| StickFeel · Trim relief enabled | True | Allows trim relief with supported control law and valid telemetry. Axis authorities set its amount. |
| StickFeel · Elevator authority | 0.3 | The anti-servo tab supplies pitch relief; ALT-mode trim lamps request manual action. Pitch authority 0.3 provides load relief and permitted centre movement; roll authority is 0. |
| StickFeel · Aileron authority | 0 | Scales supported roll-trim relief and permitted centre movement. Zero removes roll response. |
| StickFeel · Force trim enabled | False | Enables local force trim, separate from aircraft-owned trim and add-on integration qualification. |
| StickFeel · G load enabled | True | Allows load-factor changes to modify permitted spring laws. Passive fly-by-wire feel can suppress it. |
| StickFeel · Rate damping enabled | True | Enables rate damping with the configured coefficients and control law. |
| Autopilot · Follow enabled | True | Following is on at 1 authority when a supported, valid autopilot control reference is available. |
| Autopilot · Follow authority | 1.0 | Sets admitted AP-follow gain, not a percentage of travel. Runtime ownership and input limits still apply. |
| Autopilot · Neutral hold enabled | False | Permits centering hold during a supported AP state, separate from following a moving target. |
| Autopilot · Neutral hold strength | 0.6 | Sets admitted AP neutral-hold strength; inactive while neutral hold is disabled. |
| Aero · Enabled | True | Enables aerodynamic cues; each still needs nonzero strength and its simulator conditions. |
| Aero · Gain | 0.35 | Sets stall-buffet strength. Zero removes the cue without changing simulator stalls or warnings. |
| Aero · Gain | 0 | Sets high-Mach buffet strength; onset and full-strength thresholds are separate. |
| Aero · Gain | 0.14 | Sets flap buffet at the configured position and speed gates. Flap movement texture is separate. |
| Aero · Max flap index | 3 | Sets the final flap index for detent normalization. UP plus three detents uses maximum index3. |
| Aero · Min flap index | 2 | Sets the first flap detent that admits buffet; this is a handle index, not degrees. |
| Aero · Gain | 0.1 | Sets gear aerodynamic buffet; movement and ground-contact cues are separate. |
| Aero · Shaker enabled | False | Permits shaker at supported warning conditions; the switch does not establish aircraft equipment. |
| Aero · Amplitude | 0.5 | Sets triggered shaker strength; inactive while the shaker feature is disabled. |
| Ground · Enabled | True | Enables ground effects; each still needs its own strength and contact or motion telemetry. |
| Ground · Gain | 0.4 | Sets rolling texture strength, modified by speed, surface and undercarriage configuration. |
| Ground · Gain | 0.25 | Sets gear-bump texture during ground motion, separate from touchdown impact. |
| Ground · Gain | 0.65 | Sets landing-impact strength; landing telemetry and response shape determine the pulse. |
| Ground · Gain | 0 | Sets reverse-thrust vibration with valid reverser and engine conditions. Zero removes the cue. |
| Engine · Enabled | True | Enables engine cues with nonzero settings and valid running-engine telemetry. |
| Engine · Gain | 0.12 | Sets estimated engine vibration using configured telemetry and response, not measured cockpit vibration. |
| Mechanical · Enabled | True | Enables accessory cues with configured strengths and observed accessory movement. |
| Mechanical · Gain | 0.12 | Sets texture from observed flap movement; a command without movement does not establish the cue. |
| Mechanical · Gain | 0.12 | Sets texture from observed gear movement, separate from aerodynamic and touchdown effects. |
실기종 경험상 이 페이지가 틀렸다면 여기서 바로잡아 주세요.
이 페이지는 인용된 자료로 만들어졌지만, 실기종 경험은 인용을 이깁니다. 틀린 주장을 인용하고 실제 기체는 어떤지 알려주세요. 정정은 메인테이너가 검토하며 이 조사의 다음 개정에 반영됩니다.
Piper Comanche의 비행과 튜닝에 대한 열린 대화(커뮤니티 포럼)입니다. 위의 정정은 메인테이너에게 비공개로 전달되며, 행어 토크는 공개입니다.