기체 라이브러리Embraer ERJ family
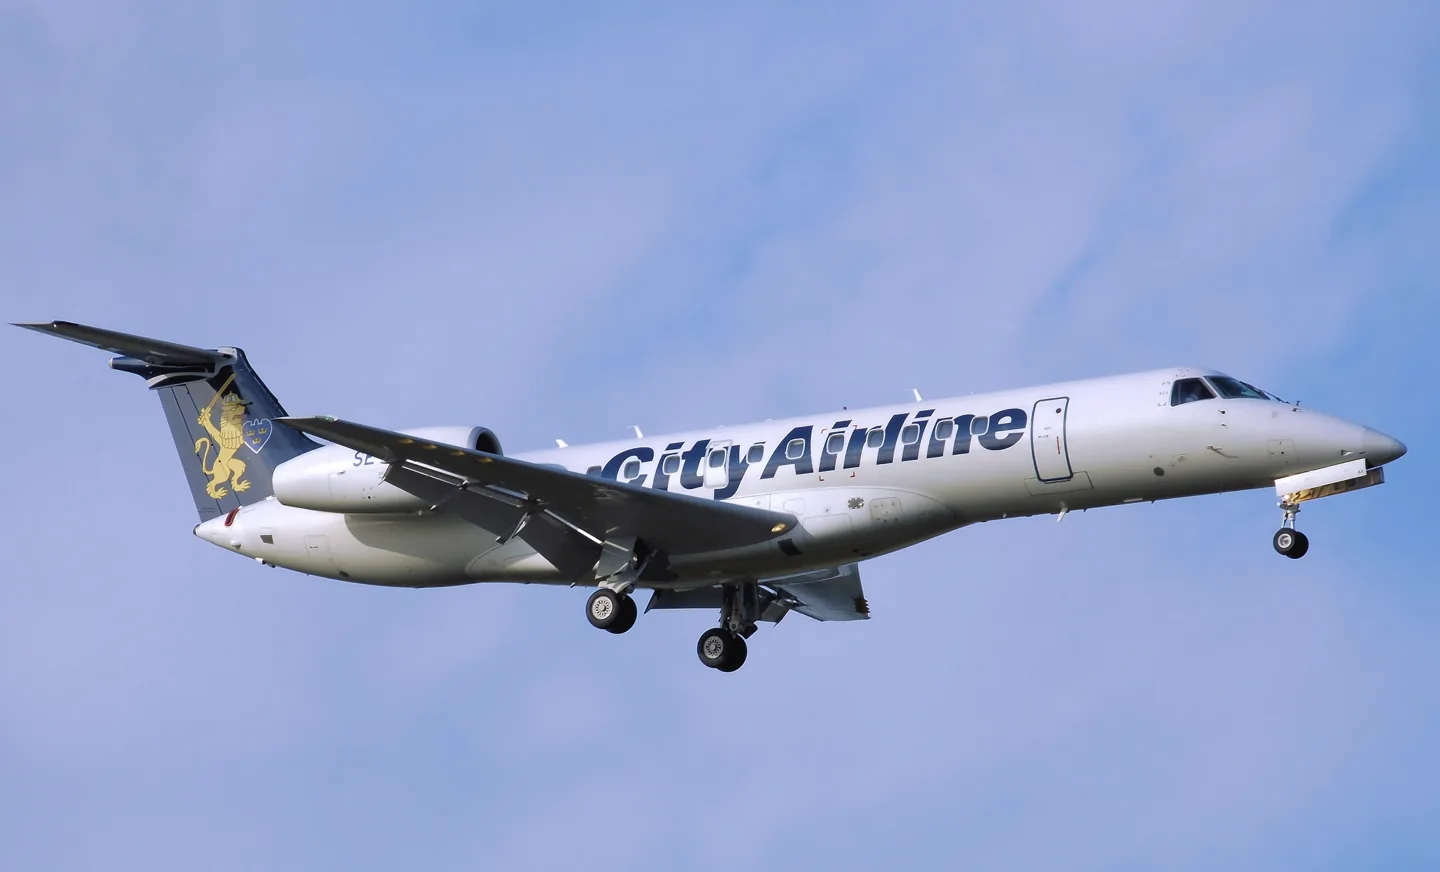
Embraer ERJ familyAdrian Pingstone (Arpingstone) · Public domain · City airline embraer erj135 se-raa arp.

Embraer ERJ family

Embraer's regional-jet family, from the ERJ 135 to the longer ERJ 145.
Airliner프로필 선택: 10개

기체 알기

The ERJ family grew into several related regional jets, including the 135, 140 and 145. The same lineage also led to Legacy business jets and military derivatives. Specifications and simulator packages identify the regional-airliner variants they describe.

E145 family: indicative EUROCONTROL technical data

Wingspan
20.2 m↗
Length
29.8 m↗
Height
6.7 m↗
Configuration
Low wing; rear-mounted twin jets; T-tail↗
Landing gear
Retractable tricycle↗
Flight crew
2↗

ERJ145 LR: Embraer indicative range

Range
Up to 1,550 nm, full passenger load, ISA and zero wind↗

AirframeDB에서 이 항공기에 대해 더 알아보기

A turboprop operator builds a regional-jet fleet

AirlineGeeks describes CommutAir receiving its first ERJ145XR in November 2015 and beginning passenger jet service in June 2016. Training crews and moving away from Dash 8 operations were central parts of the transition, giving the aircraft a role in reshaping the regional airline.

Read the range with its variant

Embraer’s 1,550 nm figure applies to the Long Range ERJ145 with a full standard passenger load in ISA conditions and zero wind. The manufacturer treats it as an indicative comparison. The ERJ145XR is a separate variant, so its weight and range should not be substituted.

Turning a type rating into everyday airline flying

Vetter arrived at airline flying after decades in general aviation, but the first supervised trips still demanded adjustment. Short sectors left little time to catch up, late arrivals made meals difficult, and a cold midnight walkaround in Quebec added a very physical reminder that the job extended beyond the cockpit. Food packed in his bag proved useful on another late finish.

Landing the taller jet also required him to relearn a familiar view. He initially struggled to judge the flare and bring the nosewheel down smoothly. Asking a captain for additional callouts helped him understand what was happening. As experience accumulated, tasks that had filled a new first officer’s attention became more routine, illustrating the gap between passing a checkride and feeling settled in daily operations.

A first officer notices that the approach is slipping below the glidepath

The captain believed the aircraft had captured the instrument approach correctly. The first officer noticed that it was below the glideslope and drew attention to the vertical mode actually shown on the display. The crew corrected the flight path, regained the glidepath and subsequently completed a visual landing after emerging from cloud.

Both pilots reflected on the difference between selecting a function and checking that it had become active. The captain acknowledged relying too heavily on the automation and allowing the instrument scan to lapse. The first officer’s accompanying report reached the same lesson about verifying the aircraft’s response. Together, their accounts show a routine cross-check becoming valuable at a moment when the crew’s expectation and the aircraft’s behaviour had diverged.

A slowing aircraft reveals an unnoticed climb

While receiving vectors for a visual approach, the crew selected a lower altitude and began a descent. Neither pilot noticed a change in the indicated vertical mode. The aircraft eventually started climbing instead, and the reporting pilot first recognised trouble when the airspeed fell substantially below the assigned value.

Adding thrust and reversing the climb brought the aircraft back towards its clearance. Air traffic control also queried the unexpected climb, and the crew ultimately completed the approach. Looking back, the reporter focused on the monitoring that had been missed by both pilots. The account describes how attention to basic flight information became more urgent than confidence in an earlier selection, without establishing why the mode change originally occurred.

공개 출처 9
  1. Embraer ERJ familyResearch background · retrieved 2026-09-12
  2. ERJ 135 / 140 / 145 / 145XR / Legacy 650Official developer / designated store catalogue · checked 2026-09-12
  3. My journey as an airline pilot: one year on propertyDoug Vetter, ATP/CFI · recollection of training and line flying beginning in 2019
  4. Flight management errors à la mode: Myth versus truthIssue 412 · May 2014 · paired reports from one ERJ-145 crew
  5. Back to basicsIssue 456 · January 2018 · ERJ-145 pilot report
  6. Inside CommutAir’s transition to the Embraer ERJ14529 August 2018
  7. ICAO Doc 8643 — aircraft type designatorsPublic search data retrieved 2026-09-14; authority update 2026-09-03
  8. Aircraft Performance Database: E145E145 family: indicative EUROCONTROL technical data
  9. ERJ145 aircraft overviewERJ145 LR manufacturer range conditions

프로필의 모델링 방식

X-Crafts ERJ 135

Free + Pro
X-Plane 12X-Crafts

The ERJ family grew into several related regional jets, including the 135, 140 and 145. The same lineage also led to Legacy business jets and military derivatives. Specifications and simulator packages identify the regional-airliner variants they describe.

This profile selects X-Crafts ERJ 135 for X-Plane 12.

Manual elevator loading and powered lateral control require different axis context. Spring resistance builds with the selected airspeed response. A separate aerodynamic term adds speed-dependent control load.

Whole-stabilizer pitch trim uses electric motors; AP and speedbrakes can also command it. Valid trim provides the configured pressure relief. Autopilot following is off.

Controls and trim

The EMB135/145 elevators use cables and spring tabs. Electric trim moves the whole stabilizer through main and backup motors. Other primary controls use hydraulic power, giving pitch and lateral control different mechanisms. X-Crafts separately documents binary speedbrakes, omitted 18-degree flaps and its exact automatic-flight functions.

EMB145EU G-EMBN AAIB pitch control and electric stabilizer descriptionEMB145EP G-RJXC AAIB flight controls and spoiler hydraulic systemsEmbraer EMB140/145 AOM volume 1 excerpts preserved in NTSB docketX-Crafts documentation hardware-setupERJ Family 2.x current system and integration changesX-Crafts documentation erj-familyEMB145LR stick-shaker equipment evidence DFW08CA215X-Crafts free preview limitations

About the values

The gains are normalized profile settings. They describe the chosen effect balance; hand force depends on the device and its output limits. IAS references are tuning values rather than operating limits. Physical acceptance of this revision remains pending.

Master gain & control system

Master gain85%

모델이 만드는 모든 것에 적용되는 최종 전체 출력 스케일로, 장치 상한 이전에 적용됩니다.

올리면: 모든 것(스프링, 하중, 효과)이 함께 강해집니다.

내리면: 모든 것이 함께 부드러워집니다.

이 값의 이유: Scales overall profile strength while preserving effect balance, subject to device and output limits.

Forces

Spring strength72%

스틱을 중앙으로 되돌리는 기본 센터링 힘입니다. 다른 모든 힘이 이 위에 쌓입니다. 너무 낮으면 정상 비행에서 스틱이 흐물거리고, 너무 높으면 손에 맞서며 그 위에 겹쳐진 작은 신호들을 가립니다.

올리면: 손에 더 저항하는 단단한 센터링.

내리면: 공기역학 하중에만 기대는 무른 스틱.

이 값의 이유: Manual elevator loading and powered lateral control require different axis context. The baseline spring is 0.72. Its low-speed blend reaches baseline strength at 100 KIAS.

EMB145EU G-EMBN AAIB pitch control and electric stabilizer descriptionEMB145EP G-RJXC AAIB flight controls and spoiler hydraulic systemsEmbraer EMB140/145 AOM volume 1 excerpts preserved in NTSB docketX-Crafts documentation hardware-setupERJ Family 2.x current system and integration changesX-Crafts documentation erj-familyEMB145LR stick-shaker equipment evidence DFW08CA215X-Crafts free preview limitations
Spring deadband4%

중앙 주변에서 스프링이 조용히 머무는 작은 중립 구역으로, 정지 시의 미세한 움직임이 덜컹거리지 않게 합니다. 넓을수록 차분하지만 느슨해지고, 좁을수록 정밀하지만 중앙에서 떨릴 수 있습니다.

올리면: 더 차분하지만 더 느슨한, 유격이 큰 중앙.

내리면: 정지 시 떨릴 수 있는 더 조인 중앙.

이 값의 이유: Sets travel around the centre before the baseline spring resists. Smaller values engage it sooner.

Overall aerodynamic load64%

두 지속 축 하중에 걸리는 마스터 스케일로, 각 축의 독립 균형 이전에 적용됩니다. 프로파일은 보통 이것을 두고 두 축 하중을 조정합니다.

올리면: 두 축이 더 강하게 하중을 받습니다.

내리면: 두 축이 함께 가벼워집니다.

이 값의 이유: The aerodynamic-load gain is 0.64 with an indicated-speed reference of 250 KIAS. This supplies speed-dependent loading alongside the spring.

Airspeed blendingTrue

저속 스프링 진입 구간(위의 시작/최대 노트)을 켭니다. 끄면 스프링은 모든 속도에서 일정합니다.

이 값의 이유: Allows baseline spring strength to rise with indicated airspeed where the control law permits it.

Low-speed spring floor50%

속도가 공기역학적 힘을 만들기 전, 정지 상태에서 스프링이 얼마나 남는지입니다. 바닥이 높으면 주기된 스틱이 단단하고, 낮으면 주기된 경비행기의 케이블이 늘어진 듯한 느슨한 감각이 됩니다.

올리면: 주기·지상활주 시 더 단단한 스틱.

내리면: 속도로만 깨어나는 주기 시의 무른 스틱.

이 값의 이유: Sets low-speed spring strength as a fraction of baseline when blending is enabled. One keeps full strength.

Spring engagement start30 kt

스프링이 저속 바닥에서 전체 강도를 향해 오르기 시작하는 속도입니다. 이륙 활주에서 조종면이 "살아나는" 지점입니다.

이 값의 이유: Sets the IAS where the low-speed spring blend starts rising. This is a feel threshold, not a flight limit.

Spring engagement full100 kt

스프링이 전체 강도에 도달하는 속도입니다. 시작점과 이 지점 사이에서 조종면 위 기류가 늘며 센터링이 점차 단단해집니다.

이 값의 이유: Sets the IAS where the low-speed blend reaches baseline strength; high-speed stiffening also uses it.

포스 조정 속도250

공기역학 하중이 설계된 최대치에 도달하는 지시 속도입니다. 하중 곡선 전체를 기체의 실제 속도 범위에 고정합니다. 172는 110노트에서 하중이 차오르고, 제트기는 훨씬 나중입니다.

올리면: 하중이 늦게 오고, 더 빠른 속도까지 스틱이 가볍습니다.

내리면: 하중이 일찍 오고 순항이 더 무겁습니다.

이 값의 이유: Sets the IAS reference for aerodynamic loading. It is an estimate, not published cruise TAS or a flight limit.

Centre firmness vs speed15%

변위 하중에 더해 센터링 자체가 속도에 따라 얼마나 단단해지는지입니다. 0이면 중앙 감각이 일정하고, 클수록 순항에서 더 단단히, 장주에서 더 느슨하게 센터링됩니다.

올리면: 속도에 따라 뚜렷이 단단해지는 중앙.

내리면: 어떤 속도에서도 일정한 중앙 감각.

이 값의 이유: The high-speed spring-stiffening gain is 0.15. It strengthens the permitted spring response above 100 KIAS, with the squared-speed ratio capped at 5.

Centre stiffening cap5

속도로 인한 중앙 경화의 상한으로, 초고속 비행이 스프링을 무한정 감아올리지 못하게 합니다.

올리면: 고속에서 더 많은 총 경화 허용.

내리면: 경화가 더 일찍 멈춥니다.

이 값의 이유: Limits the squared airspeed ratio used for high-speed spring stiffening; it is not a device-force cap.

Aileron load48%

에일러론 변위와 속도에 의한 지속적인 롤 하중으로, 피치와 독립적으로 조정됩니다. 승강타 하중과 함께 리뷰에서 말하는 조종 조화 비율을 정합니다.

올리면: 더 무거운 롤 힘.

내리면: 더 가볍고 생기 있는 에일러론.

이 값의 이유: Roll and pitch aerodynamic scales are 0.48 and 1, respectively. They set the aerodynamic axis balance. No custom spring-travel curve is enabled.

Elevator load100%

승강타 변위와 속도에 의한 지속적인 피치 하중으로, 롤과 독립적으로 조정됩니다. 기종별 피치 무게를 결정하는 주 레버입니다. 에일러론, 스프링, 트림, 버핏 힘에는 관여하지 않습니다.

올리면: 속도에서 더 무거운 지속 피치 힘.

내리면: 붙들기 가벼운, 더 가뿐한 승강타.

이 값의 이유: Scales pitch aerodynamic loading; pitch spring travel and trim responses are separate settings.

Max output force55%

각 정상 피치·롤 힘이 장치에 닿기 전의 상한으로, 강한 기동에서 하드웨어를 때리거나 포화시키지 않게 보호합니다.

올리면: 잘리기 전의 더 높은 정상 힘 피크.

내리면: 더 부드러운 상한. 거친 기동이 더 일찍 평평해집니다.

이 값의 이유: Caps directed-force output. Native spring effects and device limits remain separate.

Trim

Trim relief (elevator)30%

승강타 트림이 유지 중인 피치 힘을 얼마나 덜어내고 스틱이 안착하는 지점을 옮기는지입니다. 100 %에서는 제대로 트림된 기체에 유지 압력이 필요 없어져, 실제 비행의 하중을-트림으로-지우는 절차 그대로입니다.

올리면: 트림이 더 많은 유지 힘을 덜어냅니다. 100 %에서는 완전 트림이 상쇄합니다.

내리면: 트림해도 힘을 계속 붙들게 됩니다.

이 값의 이유: Whole-stabilizer pitch trim uses electric motors; AP and speedbrakes can also command it. Pitch authority 0.3 provides load relief and permitted centre movement; roll authority is 0.12.

EMB145EU G-EMBN AAIB pitch control and electric stabilizer descriptionEMB145EP G-RJXC AAIB flight controls and spoiler hydraulic systemsEmbraer EMB140/145 AOM volume 1 excerpts preserved in NTSB docketX-Crafts documentation hardware-setupERJ Family 2.x current system and integration changesX-Crafts documentation erj-familyEMB145LR stick-shaker equipment evidence DFW08CA215X-Crafts free preview limitations
Trim relief (aileron)12%

롤 트림에 대한 같은 경감입니다. 대부분의 GA 기종에는 실제 에일러론 트림이 없어 0으로 두고, 롤 트림이 있는 기종은 상응하는 값을 받습니다.

올리면: 롤 트림이 더 많은 유지 힘을 덜어냅니다.

내리면: 롤 트림의 효과가 줄어듭니다.

이 값의 이유: Scales supported roll-trim relief and permitted centre movement. Zero removes roll response.

Effect gains · Ground

Runway rumble23%

바퀴 속도와 노면 종류(포장, 잔디, 자갈)에 따른 구름 진동입니다.

올리면: 스틱의 노면 질감이 더 강하게.

내리면: 더 매끄러운 지상활주.

이 값의 이유: Sets rolling texture strength, modified by speed, surface and undercarriage configuration.

Gear bumps25%

신축 이음, 바퀴 자국, 거친 노면의 짧고 분리된 충격으로, 연속적인 우르릉거림에 마디를 찍습니다.

올리면: 이음과 자국의 더 또렷한 충격.

내리면: 더 부드러운 지면 디테일.

이 값의 이유: Sets gear-bump texture during ground motion, separate from touchdown impact.

Effect gains · Airframe

Stall buffet18%

실속 접근 시와 실속 경고가 울리는 동안의 기체 흔들림, 이 날개가 불만을 얼마나 크게 알리는지입니다. 깔끔하게 떨어지는 기종은 버핏을 절제하고 경적이 경고를 맡습니다.

올리면: 더 강한 실속 전 떨림.

내리면: 더 은은한 날개. 경적이 경고를 맡습니다.

이 값의 이유: Sets stall-buffet strength. Zero removes the cue without changing simulator stalls or warnings.

Mach buffet0%

마하 한계 접근 시의 천음속 버핏입니다. MMO 근처의 제트기에는 의미가 있고, 거기 도달하지 못하는 피스톤과 터보프롭은 0입니다.

올리면: 마하 한계 근처의 더 강한 천음속 버핏.

내리면: 높은 마하에서 더 매끄러운 비행.

이 값의 이유: Sets high-Mach buffet strength; onset and full-strength thresholds are separate.

Flap buffet8%

플랩이 실제로 공기를 일하는 속도 창에서, 기류에 펼쳐진 플랩에 의한 기체의 저주파 진동입니다.

올리면: 플랩 작동 중 더 거친 비행.

내리면: 더 부드러운 접근 플랩.

이 값의 이유: Sets flap buffet at the configured position and speed gates. Flap movement texture is separate.

Gear buffet6%

기류에 매달린 접이식 착륙장치에 의한 기체의 북소리입니다. 기체 형상이 변하지 않는 고정식 기종은 0입니다.

올리면: 착륙장치 내림 시 더 많은 북소리.

내리면: 더 깔끔한 착륙장치 내림 비행.

이 값의 이유: Sets gear aerodynamic buffet; movement and ground-contact cues are separate.

Stick shaker30%

기체 자체의 실속 경보 시스템이 발동하는 전용 스틱 셰이커 진동입니다. 실제 셰이커가 있는 기종만 값을 받고, 나머지는 공기역학 버핏과 경적에 의존합니다.

올리면: 더 단단한 셰이커.

내리면: 더 은은한 셰이커.

이 값의 이유: Sets triggered shaker strength; inactive while the shaker feature is disabled.

Effect gains · Engine, mechanical & drag

Touchdown thump40%

바퀴가 활주로에 닿는 순간의 단발 충격으로, 강하율에 따라 스케일됩니다. 부드러운 착륙은 속삭이고 단단한 도착은 쿵 울립니다.

올리면: 접지 시 더 단단한 충격.

내리면: 더 부드러운 도착.

이 값의 이유: Sets landing-impact strength; landing telemetry and response shape determine the pulse.

Reverse rumble10%

역추력이나 베타 범위 프로펠러가 작동하는 동안의 활주 진동입니다. 리버스가 없는 기종은 0입니다.

올리면: 리버스 중 더 거친 활주.

내리면: 더 은은한 리버스.

이 값의 이유: Sets reverse-thrust vibration with valid reverser and engine conditions. Zero removes the cue.

Engine rumble2%

공회전부터 최대 출력까지 회전수를 따르는 연속적인 동력장치 진동으로, 앞에서 무언가 연료를 태우고 있다는 늘 존재하는 상기입니다.

올리면: 스틱에 더 많은 엔진.

내리면: 더 은은한 엔진.

이 값의 이유: Sets estimated engine vibration using configured telemetry and response, not measured cockpit vibration.

Flap motion5%

시뮬레이터가 플랩 조종면의 실제 이동을 보고하는 동안만의 연속 진동입니다. 추정 타이머가 아니라 실제 액추에이터 동작과 고장을 따릅니다.

올리면: 플랩 이동 중 더 많은 진동.

내리면: 더 은은한 플랩 이동.

이 값의 이유: Sets texture from observed flap movement; a command without movement does not establish the cue.

Autopilot follow

AP follow authority10%

자동조종 명령이 스틱을 물리적으로 얼마나 움직일 수 있는지입니다. 움직인 축이 조종사 입력으로 읽힐 수 있는 MSFS에서는 극소로 유지하며, 0이면 따라가기가 완전히 꺼집니다.

올리면: 자동조종이 스틱을 눈에 띄게 더 움직입니다.

내리면: 거의 느껴지지 않는 따라가기.

이 값의 이유: Sets admitted AP-follow gain, not a percentage of travel. Runtime ownership and input limits still apply.

Stick feel

StickFeel · Trim feel enabledTrue

Whether this feature is active in this profile.

이 값의 이유: Retained for compatibility and group membership. Trim relief, rather than this flag, controls centre movement.

StickFeel · Trim relief enabledTrue

Whether this feature is active in this profile.

이 값의 이유: Allows trim relief with supported control law and valid telemetry. Axis authorities set its amount.

StickFeel · Force trim enabledFalse

Whether this feature is active in this profile.

이 값의 이유: Enables local force trim, separate from aircraft-owned trim and add-on integration qualification.

StickFeel · G load enabledTrue

Whether this feature is active in this profile.

이 값의 이유: Allows load-factor changes to modify permitted spring laws. Passive fly-by-wire feel can suppress it.

StickFeel · Rate damping enabledTrue

Whether this feature is active in this profile.

이 값의 이유: Enables rate damping with the configured coefficients and control law.

Autopilot

Autopilot · Follow enabledFalse

Whether this feature is active in this profile.

이 값의 이유: Autopilot following is off; the configured spring and load retain the hardware feel.

Autopilot · Neutral hold enabledFalse

Whether this feature is active in this profile.

이 값의 이유: Permits centering hold during a supported AP state, separate from following a moving target.

Autopilot · Neutral hold strength0.6

이 값의 이유: Sets admitted AP neutral-hold strength; inactive while neutral hold is disabled.

Aero

Aero · EnabledTrue

Whether this feature is active in this profile.

이 값의 이유: Enables aerodynamic cues; each still needs nonzero strength and its simulator conditions.

Aero · Max flap index3

Where this effect reaches full strength (or has fully faded, for washouts).

올리면: a more gradual build to a later peak.

내리면: a quicker build.

이 값의 이유: Sets the final flap index for detent normalization. UP plus three detents uses maximum index3.

Aero · Min flap index2

Where this effect begins fading in.

올리면: the effect begins later.

내리면: it begins earlier.

이 값의 이유: Sets the first flap detent that admits buffet; this is a handle index, not degrees.

Aero · Shaker enabledTrue

Whether this feature is active in this profile.

이 값의 이유: Permits shaker at supported warning conditions; the switch does not establish aircraft equipment.

Ground

Ground · EnabledTrue

Whether this feature is active in this profile.

이 값의 이유: Enables ground effects; each still needs its own strength and contact or motion telemetry.

Engine

Engine · EnabledTrue

Whether this feature is active in this profile.

이 값의 이유: Enables engine cues with nonzero settings and valid running-engine telemetry.

Mechanical

Mechanical · EnabledTrue

Whether this feature is active in this profile.

이 값의 이유: Enables accessory cues with configured strengths and observed accessory movement.

Mechanical · Gain0.05

The strength of this effect.

올리면: a stronger effect.

내리면: a weaker one.

이 값의 이유: Sets texture from observed gear movement, separate from aerodynamic and touchdown effects.

모든 프로필 설정
추정 프로필 설정
매개변수값제어 대상과 설정 이유
Spring strength0.72 Manual elevator loading and powered lateral control require different axis context. The baseline spring is 0.72. Its low-speed blend reaches baseline strength at 100 KIAS.
Spring deadband0.045 Sets travel around the centre before the baseline spring resists. Smaller values engage it sooner.
Force gain0.64 The aerodynamic-load gain is 0.64 with an indicated-speed reference of 250 KIAS. This supplies speed-dependent loading alongside the spring.
Master gain0.85 Scales overall profile strength while preserving effect balance, subject to device and output limits.
Dynamic-pressure blendTrue Allows baseline spring strength to rise with indicated airspeed where the control law permits it.
Minimum spring factor0.5 Sets low-speed spring strength as a fraction of baseline when blending is enabled. One keeps full strength.
Spring wake-up speed30 ktSets the IAS where the low-speed spring blend starts rising. This is a feel threshold, not a flight limit.
Spring full-strength speed100 ktSets the IAS where the low-speed blend reaches baseline strength; high-speed stiffening also uses it.
포스 조정 속도250 ktSets the IAS reference for aerodynamic loading. It is an estimate, not published cruise TAS or a flight limit.
Airspeed spring stiffening0.15 The high-speed spring-stiffening gain is 0.15. It strengthens the permitted spring response above 100 KIAS, with the squared-speed ratio capped at 5.
Airspeed stiffening cap5 Limits the squared airspeed ratio used for high-speed spring stiffening; it is not a device-force cap.
Aileron force scale0.48 Roll and pitch aerodynamic scales are 0.48 and 1, respectively. They set the aerodynamic axis balance. No custom spring-travel curve is enabled.
Elevator force scale1 Scales pitch aerodynamic loading; pitch spring travel and trim responses are separate settings.
Maximum output force0.55 Caps directed-force output. Native spring effects and device limits remain separate.
StickFeel · Trim feel enabledTrue Retained for compatibility and group membership. Trim relief, rather than this flag, controls centre movement.
StickFeel · Trim relief enabledTrue Allows trim relief with supported control law and valid telemetry. Axis authorities set its amount.
StickFeel · Elevator authority0.3 Whole-stabilizer pitch trim uses electric motors; AP and speedbrakes can also command it. Pitch authority 0.3 provides load relief and permitted centre movement; roll authority is 0.12.
StickFeel · Aileron authority0.12 Scales supported roll-trim relief and permitted centre movement. Zero removes roll response.
StickFeel · Force trim enabledFalse Enables local force trim, separate from aircraft-owned trim and add-on integration qualification.
StickFeel · G load enabledTrue Allows load-factor changes to modify permitted spring laws. Passive fly-by-wire feel can suppress it.
StickFeel · Rate damping enabledTrue Enables rate damping with the configured coefficients and control law.
Autopilot · Follow enabledFalse Autopilot following is off; the configured spring and load retain the hardware feel.
Autopilot · Follow authority0.1 Sets admitted AP-follow gain, not a percentage of travel. Runtime ownership and input limits still apply.
Autopilot · Neutral hold enabledFalse Permits centering hold during a supported AP state, separate from following a moving target.
Autopilot · Neutral hold strength0.6 Sets admitted AP neutral-hold strength; inactive while neutral hold is disabled.
Aero · EnabledTrue Enables aerodynamic cues; each still needs nonzero strength and its simulator conditions.
Aero · Gain0.18 Sets stall-buffet strength. Zero removes the cue without changing simulator stalls or warnings.
Aero · Gain0 Sets high-Mach buffet strength; onset and full-strength thresholds are separate.
Aero · Gain0.08 Sets flap buffet at the configured position and speed gates. Flap movement texture is separate.
Aero · Max flap index3 Sets the final flap index for detent normalization. UP plus three detents uses maximum index3.
Aero · Min flap index2 Sets the first flap detent that admits buffet; this is a handle index, not degrees.
Aero · Gain0.06 Sets gear aerodynamic buffet; movement and ground-contact cues are separate.
Aero · Shaker enabledTrue Permits shaker at supported warning conditions; the switch does not establish aircraft equipment.
Aero · Amplitude0.3 Sets triggered shaker strength; inactive while the shaker feature is disabled.
Ground · EnabledTrue Enables ground effects; each still needs its own strength and contact or motion telemetry.
Ground · Gain0.23 Sets rolling texture strength, modified by speed, surface and undercarriage configuration.
Ground · Gain0.25 Sets gear-bump texture during ground motion, separate from touchdown impact.
Ground · Gain0.4 Sets landing-impact strength; landing telemetry and response shape determine the pulse.
Ground · Gain0.1 Sets reverse-thrust vibration with valid reverser and engine conditions. Zero removes the cue.
Engine · EnabledTrue Enables engine cues with nonzero settings and valid running-engine telemetry.
Engine · Gain0.025 Sets estimated engine vibration using configured telemetry and response, not measured cockpit vibration.
Mechanical · EnabledTrue Enables accessory cues with configured strengths and observed accessory movement.
Mechanical · Gain0.05 Sets texture from observed flap movement; a command without movement does not establish the cue.
Mechanical · Gain0.05 Sets texture from observed gear movement, separate from aerodynamic and touchdown effects.
공개 출처 18
  1. Embraer ERJ familyResearch background · retrieved 2026-09-12
  2. EMB145EU G-EMBN AAIB pitch control and electric stabilizer descriptionPDF p5, pitch controls and pitch-trim system
  3. EMB145EP G-RJXC AAIB flight controls and spoiler hydraulic systemsPDF pp2-4, recorded aileron trim and Aircraft description
  4. Embraer EMB140/145 AOM volume 1 excerpts preserved in NTSB docketPDF pp17-18, AOM 5.4-5.5; both tables/pages
  5. X-Crafts documentation hardware-setupHardware setup, Speedbrakes and Flaps, extracted lines 47-65
  6. ERJ Family 2.x current system and integration changesRelease notes 2.1.0/2.1.1 and 2.0.0-b5, selected speedbrake and pusher entries
  7. X-Crafts documentation erj-familyAutopilot and systems; extended-range variants, extracted lines 146-154 and 193-195Official developer / designated store catalogue · checked 2026-09-12
  8. EMB145LR stick-shaker equipment evidence DFW08CA215NTSB DFW08CA215 final report, PDF p1 Analysis
  9. X-Crafts free preview limitationsFree Preview, included/excluded features
  10. ERJ Family FAQFAQ, 18-degree flaps; Gust Lock; SPS/ICE SPEEDS; Autothrottle sections
  11. X-Crafts Embraer E135 2.0Embraer ERJ family
  12. My journey as an airline pilot: one year on propertyDoug Vetter, ATP/CFI · recollection of training and line flying beginning in 2019
  13. Flight management errors à la mode: Myth versus truthIssue 412 · May 2014 · paired reports from one ERJ-145 crew
  14. Back to basicsIssue 456 · January 2018 · ERJ-145 pilot report
  15. Inside CommutAir’s transition to the Embraer ERJ14529 August 2018
  16. ICAO Doc 8643 — aircraft type designatorsPublic search data retrieved 2026-09-14; authority update 2026-09-03
  17. Aircraft Performance Database: E145E145 family: indicative EUROCONTROL technical data
  18. ERJ145 aircraft overviewERJ145 LR manufacturer range conditions

커뮤니티와 정정

실기종 경험상 이 페이지가 틀렸다면 여기서 바로잡아 주세요.

조종사 정정

이 기체를 모시나요? 이 페이지를 정정하세요.

이 페이지는 인용된 자료로 만들어졌지만, 실기종 경험은 인용을 이깁니다. 틀린 주장을 인용하고 실제 기체는 어떤지 알려주세요. 정정은 메인테이너가 검토하며 이 조사의 다음 개정에 반영됩니다.

행어 토크

Embraer ERJ family의 비행과 튜닝에 대한 열린 대화(커뮤니티 포럼)입니다. 위의 정정은 메인테이너에게 비공개로 전달되며, 행어 토크는 공개입니다.

Embraer ERJ family의 행어 토크가 아직 없습니다. 첫 번째가 되어 보세요.

커뮤니티

이 기체의 커뮤니티 프로필

이 기체의 커뮤니티 프로필이 아직 없습니다. 나만의 방식으로 튜닝했나요? 프로필 공유하기 그러면 여기에 표시됩니다.