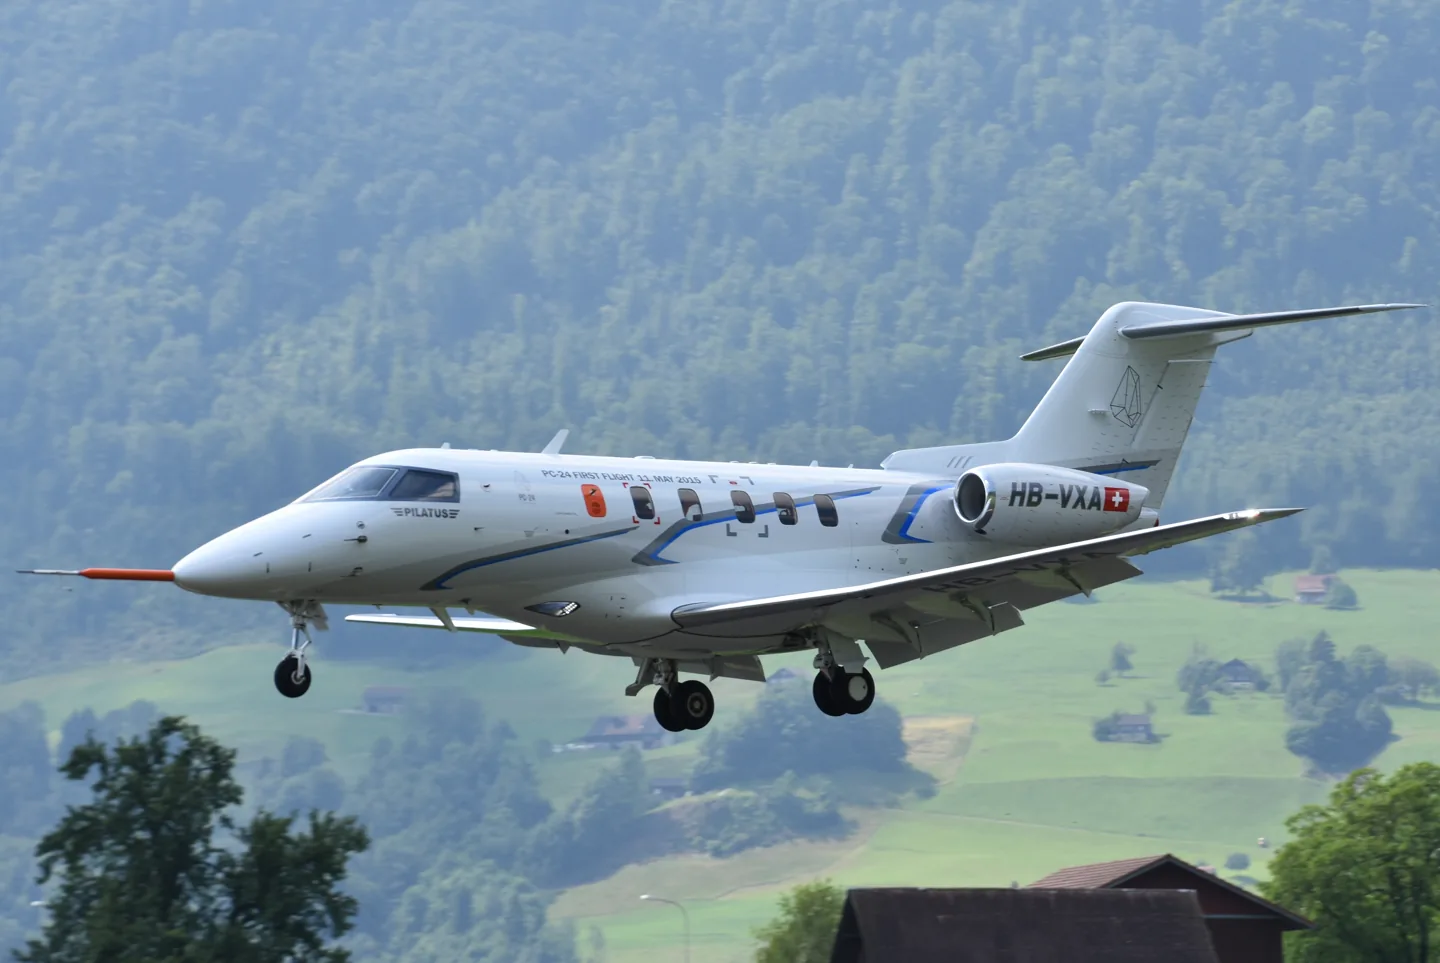
Pilatus PC-24Stephan Widmer · CC BY-SA 2.0 · Pilatus PC-24 pictured

Pilatus PC-24

A twin-engine business jet designed to retain some of the utility flexibility associated with the PC-12.
Business jet2 choix de profil

Connaître l'avion

Pilatus designed the PC-24 to combine a business-jet cabin with access to shorter and less conventional airfields. Rear-mounted Williams engines leave the wing clear, and a large cargo door supports several cabin roles. It first flew in 2015.

The PC-24 shares the PC-12's utility emphasis through a separate jet airframe, propulsion system and flight deck. Simulator documentation describes the represented avionics, ground and cargo features.

Aircraft / family

Propulsion
Twin jet↗
Configuration
Utility-oriented business jet↗

Pilatus PC-24 · Specifications · real aircraft; source units retained

Length
16.85 m (55 ft 3 in)↗
Wingspan
17.0 m (55 ft 9 in)↗
Height
5.4 m (17 ft 4 in)↗
Wing area
30.91 m² (332.6 sq ft)↗
Empty weight
5,244 kg (11,561 lb)↗
Max takeoff weight
8,500 kg (18,739 lb) Max ramp weight: 8,545 kg (18,839 lb)↗
Powerplant
2 × Williams FJ44-4A turbofans , 15 kN (3,400 lbf) thrust each↗
Cruise speed
810 km/h (510 mph, 440 kn)↗
Stall speed
154 km/h (96 mph, 83 kn)↗
Range
3,700 km (2,300 mi, 2,000 nmi) , 6 passengers (1,200 lb payload)↗

En savoir plus sur cet aéronef sur AirframeDB

Familiar avionics, a new jet and a flight over Provence

Ceretti brought both Falcon and recent PC-12 experience to Jetfly’s new aircraft. The PC-24’s cockpit looked clear and uncluttered to him, with good forward visibility and familiar ideas carried over from the PC-12’s avionics. He welcomed weather datalink information, while also seeing room to improve the electronic checklists in this early configuration.

His most memorable flight was a formation photography mission over Provence after delivery, alongside an unusual group that included an OV-10, L-39, PC-7 and PC-12. The scenery and company made it stand out from routine operation. With only about fifty hours in the jet, he was still learning its details; the interview preserves that early enthusiasm and experience level rather than presenting a long-term fleet verdict.

From the PC-12 into a first jet

Fredricks came to the PC-24 through PC-12 charter and instruction, making it her first jet type. Familiarity with the turboprop’s avionics helped the transition, but the greater speed required thinking further ahead. Training and study remained an important part of becoming comfortable in the new aircraft, despite those recognisable cockpit features.

One journey took her from the mountain-valley airfield at Valemount, British Columbia, to San Jose, California. She enjoyed bringing the jet into smaller airports where it attracted curious onlookers. Regular clients moving from the PC-12 also made the work feel familiar: the aircraft changed, but the people aboard remained central to the job.

Testing a new jet while still flying a Catalina

Mulcahy joined Pilatus in 2014, bringing experience with twin-engine business jets from his work for the UK Civil Aviation Authority. Helping take the PC-24 through its early development offered a rare chance to follow an aircraft from the drawing board into flight. Away from the jet, he also flew a Catalina, providing a very different reference for cockpit workload and handling.

He described the PC-24 as well balanced and less demanding than the older flying boat. Its development testing took him onto dirt, gravel, frozen gravel, grass and compacted sand, including wet surfaces. He also identified limits when water and mud became too deep. That combination of enthusiasm and qualification makes his recollection useful: varied runway work was a test programme with boundaries, not a claim that every surface would be suitable.

Sources publiques 9
  1. Pilatus PC-24Research background · Wikipedia revision 1371757439 · retrieved 2026-09-12
  2. Microsoft Flight Simulator aircraft manuals
  3. MSFS 2024 FAQ and edition aircraft inventory
  4. 60 Days PC-24: Talking to owner and pilotJetfly interviews · early operation following September 2018 delivery
  5. Ashley Fredricks and the PC-24Western Aircraft chief pilot interview · manufacturer-hosted
  6. Pilot’s interview: pilot for PC-24 and CatalinaPaul Mulcahy interview · anticipates the 2021 display season
  7. ICAO Doc 8643 — aircraft type designatorsPublic search data retrieved 2026-09-14; authority update 2026-09-03
  8. Release Notes — Sim Update 2 [1.4.20.0]15 May 2025 · PC-24 version 1.0.9
  9. Pilatus PC-24 XP12-MSGIER-PC24Product listing captured 2026-09-23; edition scope from the reviewed catalogue

Comment le profil le modélise

Michael Sgier PC-24

Free + Pro
X-Plane 12Michael Sgier

Pilatus designed the PC-24 to combine a business-jet cabin with access to shorter and less conventional airfields. Rear-mounted Williams engines leave the wing clear, and a large cargo door supports several cabin roles. It first flew in 2015.

This profile selects Michael Sgier PC-24 for X-Plane 12.

The mechanical/tab-assisted system motivates sustained yoke resistance. Spring resistance builds with the selected airspeed response. A separate aerodynamic term adds speed-dependent control load.

A trimmable stabilizer and aileron tab provide independent pitch and roll context. Valid trim provides the configured pressure relief. Autopilot following is off.

Cette révision précise n’est pas encore autorisée à l’installation publique.

Controls and trim

The PC-24 documentation describes cables, pushrods and torque tubes with tension regulation. Balance tabs, a left-aileron trim tab and a trimmable stabilizer support the primary-control system, while secondary controls use electrical actuation.

Manufacturer mechanical control cable designManufacturer hosted pilot evaluation and control architecture

The selected implementation

The PC-24 package offers executive, cargo and rescue equipment with a custom instrument plugin and an updated X-Plane 12 model.

Manufacturer mechanical control cable designManufacturer hosted pilot evaluation and control architecturePilatus PC-24 XP12-MSGIER-PC24

About the values

The gains are normalized profile settings. They describe the chosen effect balance; hand force depends on the device and its output limits. IAS references are tuning values rather than operating limits. Physical acceptance of this revision remains pending.

Master gain & control system

Master gain85%

L'échelle globale finale appliquée à tout ce que produit le modèle, avant la limite du périphérique.

Plus : tout (ressort, charges, effets) se renforce ensemble.

Moins : tout s'adoucit ensemble.

Pourquoi ici : Scales overall profile strength while preserving effect balance, subject to device and output limits.

Forces

Spring strength74%

La force de rappel de base qui ramène le manche au neutre. Toutes les autres forces s'empilent dessus. Trop faible, le manche paraît mou en vol normal ; trop forte, elle lutte contre la main et masque les signaux plus fins.

Plus : un centrage plus ferme qui résiste davantage à la main.

Moins : un manche plus mou qui ne compte que sur la charge aérodynamique.

Pourquoi ici : The mechanical/tab-assisted system motivates sustained yoke resistance. The baseline spring is 0.74. Its low-speed blend reaches baseline strength at 65 KIAS.

Manufacturer mechanical control cable designManufacturer hosted pilot evaluation and control architecture
Spring deadband4%

Une petite zone neutre autour du centre où le ressort reste muet, pour que les micro-mouvements à l'arrêt ne vibrent pas. Plus large, c'est plus calme mais plus lâche ; plus étroite, plus précis mais parfois nerveux au neutre.

Plus : un centre plus calme mais plus lâche, avec plus de jeu.

Moins : un centre plus serré qui peut vibrer au repos.

Pourquoi ici : Sets travel around the centre before the baseline spring resists. Smaller values engage it sooner.

Overall aerodynamic load80%

Une échelle maîtresse sur les deux charges d'axe, appliquée avant leur équilibre individuel. Les profils la laissent en général en place et règlent les deux axes.

Plus : les deux axes chargent plus fort.

Moins : les deux axes s'allègent ensemble.

Pourquoi ici : The aerodynamic-load gain is 0.8 with an indicated-speed reference of 220 KIAS. This supplies speed-dependent loading alongside the spring.

Airspeed blendingTrue

Active la fenêtre d'engagement basse vitesse du ressort (début/plein en nœuds ci-dessus). Désactivé, le ressort est constant à toute vitesse.

Pourquoi ici : Allows baseline spring strength to rise with indicated airspeed where the control law permits it.

Low-speed spring floor55%

La part du ressort qui survit à l'arrêt, avant que la vitesse ne crée la moindre force aérodynamique. Un plancher haut garde le manche ferme au parking ; un plancher bas donne le jeu de câbles d'un avion léger au parking.

Plus : un manche plus ferme au parking et au roulage.

Moins : un manche mou au parking qui ne s'éveille qu'avec la vitesse.

Pourquoi ici : Sets low-speed spring strength as a fraction of baseline when blending is enabled. One keeps full strength.

Spring engagement start8 kt

La vitesse à laquelle le ressort quitte son plancher basse vitesse vers la pleine raideur : le début du réveil des commandes au roulage de décollage.

Pourquoi ici : Sets the IAS where the low-speed spring blend starts rising. This is a feel threshold, not a flight limit.

Spring engagement full65 kt

La vitesse où le ressort atteint sa pleine raideur. Entre le début et ce point, le centrage se raffermit avec le vent relatif.

Pourquoi ici : Sets the IAS where the low-speed blend reaches baseline strength; high-speed stiffening also uses it.

Vitesse de réglage des forces220

La vitesse indiquée où la charge aérodynamique atteint son niveau de conception. Elle ancre toute la courbe au domaine réel : un 172 charge dès 110 nœuds, un jet bien plus tard.

Plus : les charges arrivent plus tard ; le manche reste léger jusqu'à plus vite.

Moins : les charges arrivent plus tôt et la croisière pèse davantage.

Pourquoi ici : Sets the IAS reference for aerodynamic loading. It is an estimate, not published cruise TAS or a flight limit.

Centre firmness vs speed15%

Combien le centrage lui-même se raidit avec la vitesse, en plus des charges de braquage. Zéro garde un centre constant ; plus fait centrer dur en croisière et souple en tour de piste.

Plus : un centre qui durcit nettement avec la vitesse.

Moins : une sensation de centre constante à toute vitesse.

Pourquoi ici : The high-speed spring-stiffening gain is 0.15. It strengthens the permitted spring response above 65 KIAS, with the squared-speed ratio capped at 5.

Centre stiffening cap5

La limite haute du raidissement lié à la vitesse, pour que le vol très rapide ne remonte pas le ressort sans borne.

Plus : plus de raidissement total permis à haute vitesse.

Moins : le raidissement se bride plus tôt.

Pourquoi ici : Limits the squared airspeed ratio used for high-speed spring stiffening; it is not a device-force cap.

Aileron load76%

La charge de roulis soutenue issue du braquage d'ailerons et de la vitesse, équilibrée indépendamment du tangage. Avec la charge de profondeur, elle fixe l'harmonie des commandes dont parlent les essais.

Plus : des efforts de roulis plus lourds.

Moins : des ailerons plus légers, plus vifs.

Pourquoi ici : Roll and pitch aerodynamic scales are 0.76 and 1, respectively. They set the aerodynamic axis balance. No custom spring-travel curve is enabled.

Elevator load100%

La charge de tangage soutenue issue du braquage de profondeur et de la vitesse, équilibrée indépendamment du roulis. Le levier principal du poids en tangage d'un type. Il ne touche ni ailerons, ni ressort, ni trim, ni buffet.

Plus : des efforts de tangage soutenus plus lourds en vitesse.

Moins : une profondeur plus légère, moins musclée à tenir.

Pourquoi ici : Scales pitch aerodynamic loading; pitch spring travel and trim responses are separate settings.

Max output force55%

Un plafond par force stable de tangage ou roulis avant le périphérique : la garde contre le claquement ou la saturation du matériel en manœuvre forte.

Plus : des pics de force stable plus élevés avant écrêtage.

Moins : un plafond plus doux ; les manœuvres dures s'aplatissent plus tôt.

Pourquoi ici : Caps directed-force output. Native spring effects and device limits remain separate.

Trim

Trim relief (elevator)30%

Combien le trim de profondeur soulage l'effort tenu et déplace le point de repos du manche. À 100 %, un avion bien compensé ne demande aucune pression : le geste réel de compenser la charge.

Plus : le trim retire plus d'effort tenu ; à 100 %, plein trim l'annule.

Moins : vous continuez à tenir de l'effort même compensé.

Pourquoi ici : A trimmable stabilizer and aileron tab provide independent pitch and roll context. Pitch authority 0.3 provides load relief and permitted centre movement; roll authority is 0.12.

Manufacturer mechanical control cable designManufacturer hosted pilot evaluation and control architecture
Trim relief (aileron)12%

Le même soulagement pour le trim de roulis. La plupart des avions légers n'ont pas de vrai trim d'ailerons, donc zéro ; les types qui en ont reçoivent une valeur adaptée.

Plus : le trim de roulis retire plus d'effort tenu.

Moins : le trim de roulis fait moins.

Pourquoi ici : Scales supported roll-trim relief and permitted centre movement. Zero removes roll response.

Effect gains · Ground

Runway rumble40%

Vibration de roulement issue de la vitesse des roues et du revêtement : la texture du bitume, de l'herbe ou du gravier sous le train.

Plus : une texture de surface plus forte dans le manche.

Moins : un roulage plus lisse.

Pourquoi ici : Sets rolling texture strength, modified by speed, surface and undercarriage configuration.

Gear bumps25%

Chocs courts et distincts des joints, ornières et surfaces rugueuses : la ponctuation au-dessus du grondement continu.

Plus : des chocs plus nets des joints et ornières.

Moins : des détails de sol plus doux.

Pourquoi ici : Sets gear-bump texture during ground motion, separate from touchdown impact.

Effect gains · Airframe

Stall buffet35%

Buffet de cellule à l'approche du décrochage et pendant l'avertisseur : la voix de cette aile quand elle est mécontente. Les types à décrochage franc reçoivent un buffet modéré, le klaxon porte l'alerte.

Plus : un tremblement pré-décrochage plus fort.

Moins : une aile plus discrète ; le klaxon porte l'alerte.

Pourquoi ici : Sets stall-buffet strength. Zero removes the cue without changing simulator stalls or warnings.

Mach buffet0%

Buffet transsonique près de la limite de Mach. Parlant pour les jets près de MMO, zéro pour pistons et turbopropulseurs qui n'y vont jamais.

Plus : un buffet transsonique plus fort près de la limite de Mach.

Moins : un vol plus lisse à haut Mach.

Pourquoi ici : Sets high-Mach buffet strength; onset and full-strength thresholds are separate.

Flap buffet0%

Vibration basse fréquence de cellule avec les volets dans le vent, dans la fenêtre où ils travaillent vraiment l'air.

Plus : un vol plus rugueux volets au travail.

Moins : des volets d'approche plus doux.

Pourquoi ici : Sets flap buffet at the configured position and speed gates. Flap movement texture is separate.

Gear buffet0%

Le tambourinement du train rentrant sorti dans le flux. Zéro pour les trains fixes, dont la cellule ne change jamais de forme.

Plus : plus de tambourinement train sorti.

Moins : un vol train sorti plus propre.

Pourquoi ici : Sets gear aerodynamic buffet; movement and ground-contact cues are separate.

Stick shaker50%

Le vibreur de manche dédié, déclenché par l'avertisseur de décrochage de l'avion. Seuls les types à vrai vibreur reçoivent une valeur ; les autres comptent sur buffet et klaxon.

Plus : un vibreur plus dur.

Moins : un vibreur plus discret.

Pourquoi ici : Sets triggered shaker strength; inactive while the shaker feature is disabled.

Effect gains · Engine, mechanical & drag

Touchdown thump65%

Le coup unique au toucher, proportionnel au taux de chute : un kiss se murmure, une arrivée ferme cogne.

Plus : un coup plus dur au toucher.

Moins : des arrivées plus douces.

Pourquoi ici : Sets landing-impact strength; landing telemetry and response shape determine the pulse.

Reverse rumble0%

Vibration de roulage sous inversion de poussée ou plage bêta. Zéro pour les types sans reverse.

Plus : un roulage plus rugueux sous reverse.

Moins : une reverse plus discrète.

Pourquoi ici : Sets reverse-thrust vibration with valid reverser and engine conditions. Zero removes the cue.

Engine rumble0%

Vibration continue du moteur suivant le régime du ralenti à la pleine puissance : le rappel permanent que quelque chose brûle du carburant devant.

Plus : plus de moteur dans le manche.

Moins : un moteur plus discret.

Pourquoi ici : Sets estimated engine vibration using configured telemetry and response, not measured cockpit vibration.

Flap motion12%

Vibration continue seulement pendant que le simulateur signale les volets réellement en mouvement. Elle suit la course réelle et les pannes, pas un minuteur estimé.

Plus : plus de vibration volets en mouvement.

Moins : des courses de volets plus discrètes.

Pourquoi ici : Sets texture from observed flap movement; a command without movement does not establish the cue.

Autopilot follow

AP follow authority10%

Jusqu'où les ordres du pilote automatique peuvent bouger le manche physique. Minuscule dans MSFS, où un axe déplacé peut être relu comme entrée pilote ; zéro coupe le suivi.

Plus : le pilote automatique bouge visiblement plus votre manche.

Moins : un suivi à peine perceptible.

Pourquoi ici : Sets admitted AP-follow gain, not a percentage of travel. Runtime ownership and input limits still apply.

Stick feel

StickFeel · Trim feel enabledFalse

Whether this feature is active in this profile.

Pourquoi ici : Retained for compatibility and group membership. Trim relief, rather than this flag, controls centre movement.

StickFeel · Trim relief enabledTrue

Whether this feature is active in this profile.

Pourquoi ici : Allows trim relief with supported control law and valid telemetry. Axis authorities set its amount.

StickFeel · Force trim enabledFalse

Whether this feature is active in this profile.

Pourquoi ici : Enables local force trim, separate from aircraft-owned trim and add-on integration qualification.

StickFeel · G load enabledTrue

Whether this feature is active in this profile.

Pourquoi ici : Allows load-factor changes to modify permitted spring laws. Passive fly-by-wire feel can suppress it.

StickFeel · Rate damping enabledTrue

Whether this feature is active in this profile.

Pourquoi ici : Enables rate damping with the configured coefficients and control law.

Autopilot

Autopilot · Follow enabledFalse

Whether this feature is active in this profile.

Pourquoi ici : Autopilot following is off; the configured spring and load retain the hardware feel.

Autopilot · Neutral hold enabledFalse

Whether this feature is active in this profile.

Pourquoi ici : Permits centering hold during a supported AP state, separate from following a moving target.

Autopilot · Neutral hold strength0.6

Pourquoi ici : Sets admitted AP neutral-hold strength; inactive while neutral hold is disabled.

Aero

Aero · EnabledTrue

Whether this feature is active in this profile.

Pourquoi ici : Enables aerodynamic cues; each still needs nonzero strength and its simulator conditions.

Aero · Max flap index3

Where this effect reaches full strength (or has fully faded, for washouts).

Plus : a more gradual build to a later peak.

Moins : a quicker build.

Pourquoi ici : Sets the final flap index for detent normalization. UP plus three detents uses maximum index3.

Aero · Min flap index2

Where this effect begins fading in.

Plus : the effect begins later.

Moins : it begins earlier.

Pourquoi ici : Sets the first flap detent that admits buffet; this is a handle index, not degrees.

Aero · Shaker enabledFalse

Whether this feature is active in this profile.

Pourquoi ici : Permits shaker at supported warning conditions; the switch does not establish aircraft equipment.

Ground

Ground · EnabledTrue

Whether this feature is active in this profile.

Pourquoi ici : Enables ground effects; each still needs its own strength and contact or motion telemetry.

Engine

Engine · EnabledFalse

Whether this feature is active in this profile.

Pourquoi ici : Enables engine cues with nonzero settings and valid running-engine telemetry.

Mechanical

Mechanical · EnabledTrue

Whether this feature is active in this profile.

Pourquoi ici : Enables accessory cues with configured strengths and observed accessory movement.

Mechanical · Gain0.025

The strength of this effect.

Plus : a stronger effect.

Moins : a weaker one.

Pourquoi ici : Sets texture from observed gear movement, separate from aerodynamic and touchdown effects.

Tous les réglages du profil
Réglages estimés du profil
ParamètreValeurCe que cela contrôle et pourquoi
Spring strength0.74 The mechanical/tab-assisted system motivates sustained yoke resistance. The baseline spring is 0.74. Its low-speed blend reaches baseline strength at 65 KIAS.
Spring deadband0.04 Sets travel around the centre before the baseline spring resists. Smaller values engage it sooner.
Force gain0.8 The aerodynamic-load gain is 0.8 with an indicated-speed reference of 220 KIAS. This supplies speed-dependent loading alongside the spring.
Master gain0.85 Scales overall profile strength while preserving effect balance, subject to device and output limits.
Dynamic-pressure blendTrue Allows baseline spring strength to rise with indicated airspeed where the control law permits it.
Minimum spring factor0.55 Sets low-speed spring strength as a fraction of baseline when blending is enabled. One keeps full strength.
Spring wake-up speed8 ktSets the IAS where the low-speed spring blend starts rising. This is a feel threshold, not a flight limit.
Spring full-strength speed65 ktSets the IAS where the low-speed blend reaches baseline strength; high-speed stiffening also uses it.
Vitesse de réglage des forces220 ktSets the IAS reference for aerodynamic loading. It is an estimate, not published cruise TAS or a flight limit.
Airspeed spring stiffening0.15 The high-speed spring-stiffening gain is 0.15. It strengthens the permitted spring response above 65 KIAS, with the squared-speed ratio capped at 5.
Airspeed stiffening cap5 Limits the squared airspeed ratio used for high-speed spring stiffening; it is not a device-force cap.
Aileron force scale0.76 Roll and pitch aerodynamic scales are 0.76 and 1, respectively. They set the aerodynamic axis balance. No custom spring-travel curve is enabled.
Elevator force scale1 Scales pitch aerodynamic loading; pitch spring travel and trim responses are separate settings.
Maximum output force0.55 Caps directed-force output. Native spring effects and device limits remain separate.
StickFeel · Trim feel enabledFalse Retained for compatibility and group membership. Trim relief, rather than this flag, controls centre movement.
StickFeel · Trim relief enabledTrue Allows trim relief with supported control law and valid telemetry. Axis authorities set its amount.
StickFeel · Elevator authority0.3 A trimmable stabilizer and aileron tab provide independent pitch and roll context. Pitch authority 0.3 provides load relief and permitted centre movement; roll authority is 0.12.
StickFeel · Aileron authority0.12 Scales supported roll-trim relief and permitted centre movement. Zero removes roll response.
StickFeel · Force trim enabledFalse Enables local force trim, separate from aircraft-owned trim and add-on integration qualification.
StickFeel · G load enabledTrue Allows load-factor changes to modify permitted spring laws. Passive fly-by-wire feel can suppress it.
StickFeel · Rate damping enabledTrue Enables rate damping with the configured coefficients and control law.
Autopilot · Follow enabledFalse Autopilot following is off; the configured spring and load retain the hardware feel.
Autopilot · Follow authority0.1 Sets admitted AP-follow gain, not a percentage of travel. Runtime ownership and input limits still apply.
Autopilot · Neutral hold enabledFalse Permits centering hold during a supported AP state, separate from following a moving target.
Autopilot · Neutral hold strength0.6 Sets admitted AP neutral-hold strength; inactive while neutral hold is disabled.
Aero · EnabledTrue Enables aerodynamic cues; each still needs nonzero strength and its simulator conditions.
Aero · Gain0.35 Sets stall-buffet strength. Zero removes the cue without changing simulator stalls or warnings.
Aero · Gain0 Sets high-Mach buffet strength; onset and full-strength thresholds are separate.
Aero · Gain0 Sets flap buffet at the configured position and speed gates. Flap movement texture is separate.
Aero · Max flap index3 Sets the final flap index for detent normalization. UP plus three detents uses maximum index3.
Aero · Min flap index2 Sets the first flap detent that admits buffet; this is a handle index, not degrees.
Aero · Gain0 Sets gear aerodynamic buffet; movement and ground-contact cues are separate.
Aero · Shaker enabledFalse Permits shaker at supported warning conditions; the switch does not establish aircraft equipment.
Aero · Amplitude0.5 Sets triggered shaker strength; inactive while the shaker feature is disabled.
Ground · EnabledTrue Enables ground effects; each still needs its own strength and contact or motion telemetry.
Ground · Gain0.4 Sets rolling texture strength, modified by speed, surface and undercarriage configuration.
Ground · Gain0.25 Sets gear-bump texture during ground motion, separate from touchdown impact.
Ground · Gain0.65 Sets landing-impact strength; landing telemetry and response shape determine the pulse.
Ground · Gain0 Sets reverse-thrust vibration with valid reverser and engine conditions. Zero removes the cue.
Engine · EnabledFalse Enables engine cues with nonzero settings and valid running-engine telemetry.
Engine · Gain0 Sets estimated engine vibration using configured telemetry and response, not measured cockpit vibration.
Mechanical · EnabledTrue Enables accessory cues with configured strengths and observed accessory movement.
Mechanical · Gain0.12 Sets texture from observed flap movement; a command without movement does not establish the cue.
Mechanical · Gain0.025 Sets texture from observed gear movement, separate from aerodynamic and touchdown effects.
Sources publiques 11
  1. Pilatus PC-24Research background · Wikipedia revision 1371757439 · retrieved 2026-09-12
  2. Manufacturer mechanical control cable designManufacturer engineering account of PC24control cables
  3. Manufacturer hosted pilot evaluation and control architectureManufacturer-hosted pilot flight review, flight controls
  4. Pilatus PC-24 XP12-MSGIER-PC24Product listing captured 2026-09-23; edition scope from the reviewed catalogue
  5. Microsoft Flight Simulator aircraft manuals
  6. MSFS 2024 FAQ and edition aircraft inventory
  7. 60 Days PC-24: Talking to owner and pilotJetfly interviews · early operation following September 2018 delivery
  8. Ashley Fredricks and the PC-24Western Aircraft chief pilot interview · manufacturer-hosted
  9. Pilot’s interview: pilot for PC-24 and CatalinaPaul Mulcahy interview · anticipates the 2021 display season
  10. ICAO Doc 8643 — aircraft type designatorsPublic search data retrieved 2026-09-14; authority update 2026-09-03
  11. Release Notes — Sim Update 2 [1.4.20.0]15 May 2025 · PC-24 version 1.0.9

Communauté et corrections

Si votre expérience du type dit que cette page se trompe, corrigez-la ici.

Corrections de pilotes

Vous volez sur cet appareil ? Corrigez cette page.

Cette page repose sur des références citées, et l'expérience réelle du type vaut mieux qu'une citation. Citez l'affirmation erronée et dites-nous ce que fait l'appareil réel. Les corrections vont au mainteneur pour examen et nourrissent la prochaine révision de cette recherche.

Discussions de hangar

Conversation ouverte sur le pilotage et le réglage du Pilatus PC-24, sur le forum communautaire. Les corrections ci-dessus vont en privé au mainteneur ; les discussions de hangar sont publiques.

Pas encore de discussion de hangar sur le Pilatus PC-24. Lancez-la.

Communauté

Profils communautaires pour cet appareil

Pas encore de profils communautaires pour cet appareil. Réglé à votre façon ? Partagez un profil et il apparaîtra ici.