A specialist faces a changing market
Vertical’s 2016 report describes Lama operators balancing mountain capability against parts availability and operating costs. Dwight Jones had sold two aircraft as customers moved towards the H125.
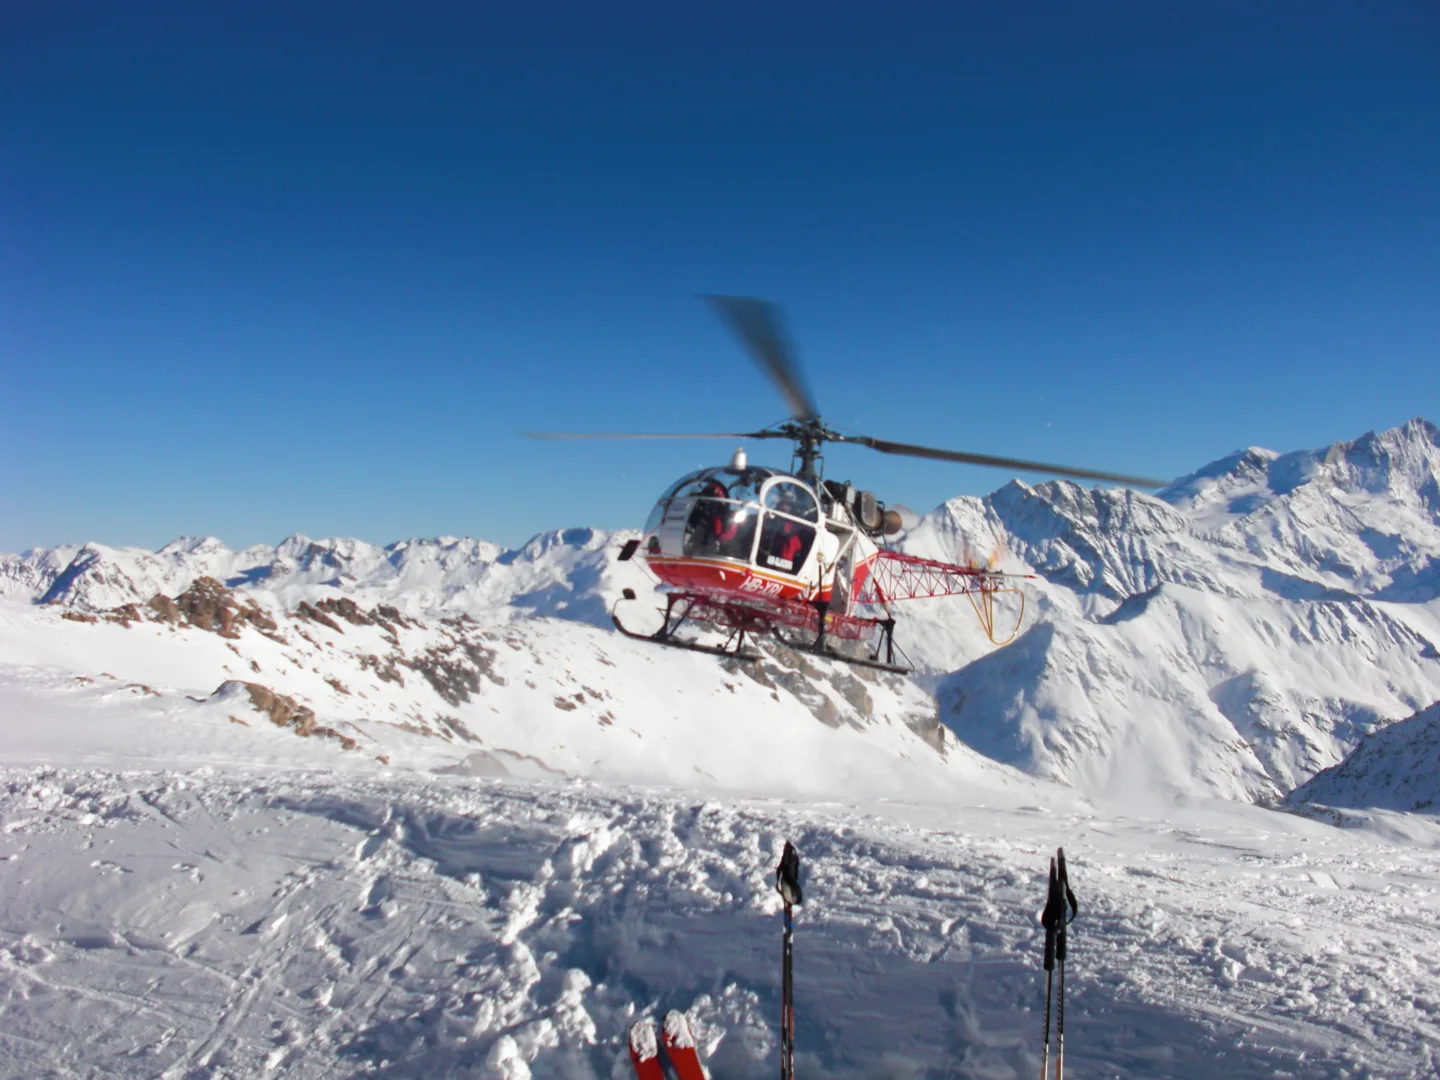 Sputniktilt · CC BY-SA 3.0 · Aérospatiale SA 315B Lama.
The Lama was developed for demanding high-altitude work. Its exposed structure, compact cabin and single turbine retain the visual simplicity of the Alouette II, while the powerplant and other components came from the larger Alouette III lineage.
It became associated with mountain transport and external loads. Simulator add-ons offer different stability options and sling-load features, described with each product.
Aérospatiale SA 315B Lama · Specifications (SA 315B Lama) · real aircraft; source units retained
Mehr über dieses Flugzeug auf AirframeDB
Vertical’s 2016 report describes Lama operators balancing mountain capability against parts availability and operating costs. Dwight Jones had sold two aircraft as customers moved towards the H125.
First flight: 17 March 1969
Developed from: Aérospatiale Alouette II
Boulet recalled a team effort to take the Lama higher after another helicopter had surpassed his earlier altitude record. They lightened the prototype for the attempt at Istres, and he reached 12,442 metres in June 1972. Extreme cold and heavy control forces were part of an experience very different from an ordinary working flight.
Looking back, he also acknowledged the uncomfortable descent through cloud with instruments removed to save weight. In the interview, the value of such a record lay in what it could contribute to the aircraft’s usefulness, especially for rescue work. Boulet spoke modestly about his own achievement and with respect for pilots doing everyday operations.
Vuichard was flying a Lama with an empty long line along a steep mountainside when the supporting air changed and the helicopter began descending towards the trees. He described arresting the descent just before reaching them. The encounter stayed with him afterwards, disturbing his sleep and prompting him to question how a similar situation might be handled differently.
That reflection became a long period of development and testing, beginning with the Lama and extending to other helicopters. Persuading people to consider his ideas proved another challenge. The later meeting with instructor Tim Tucker happened in an R44, a separate part of the story.
Ricks remembered the Lama through the jobs it could do in Colorado’s oil-and-gas country. Carrying people into the mountains, looking over a site and moving equipment on a sling were part of its appeal. With the doors removed, the view made a strong impression, helping explain his affection for this exposed, purposeful little helicopter.
His recollections appear in a report about the changing economics of keeping Lamas at work. Operator Dwight Jones, interviewed separately, described customers moving towards newer helicopters and the costs of continuing with the older type. That context gives Ricks’s enthusiasm a particular setting: a pilot remembering the qualities of a familiar workhorse while the industry around it was changing. The article’s comparisons are those of the people interviewed in 2016.
The Lama was developed for demanding high-altitude work. Its exposed structure, compact cabin and single turbine retain the visual simplicity of the Alouette II, while the powerplant and other components came from the larger Alouette III lineage.
This profile selects Taog's Hangar SA315B Lama for MSFS 2020, MSFS 2024.
The spring stays independent of airspeed. Directed aerodynamic loading is omitted.
Local force trim is off. Autopilot following is off.
Cyclic damping is on. Its configured gain is 0.35; it resists hardware motion separately from the spring and aircraft stabilization.
The SA315B Lama combines a turbine with an articulated three-blade rotor. Taog documents regular and beginner flight-model choices and working external-load interactions. Ubben and Khamsin's X-Plane implementation has its own stability settings, doors and load configuration. Artificial stabilization and an automated checklist are separate functions from an autopilot that commands a physical cyclic centre.
Taog separates regular/beginner input behavior and bucket loads. Ground-handling wheels and changing load weight do not automatically command extra hardware force.
The gains are normalized profile settings. They describe the chosen effect balance; hand force depends on the device and its output limits. IAS references are tuning values rather than operating limits. Physical acceptance of this revision remains pending.
Die letzte Gesamtskalierung über alles, was das Modell erzeugt, vor der Gerätegrenze.
Mehr: alles (Feder, Lasten, Effekte) wird gemeinsam stärker.
Weniger: alles wird gemeinsam weicher.
Warum hier: Scales overall profile strength while preserving effect balance, subject to device and output limits.
Die Grundzentrierkraft, die den Stick zur Mitte zieht. Jede andere Kraft baut darauf auf. Zu niedrig fühlt sich der Stick im Normalflug schlaff an; zu hoch kämpft er gegen deine Hand und überdeckt die feineren Signale.
Mehr: festere Zentrierung, die der Hand jederzeit mehr widersteht.
Weniger: ein schlafferer Stick, der sich allein auf die aerodynamische Last stützt.
Warum hier: Nominal cyclic centering and damping provide the selected handling balance; beginner stability and external-load weight are aircraft behaviors, not additional calibrated spring forces. The baseline spring is 0.14. Low-speed spring blending is off.
Download manualExact product and documentation researchEine kleine neutrale Zone um die Mitte, in der die Feder ruhig bleibt, damit kleinste Bewegungen im Stand nicht flattern. Breiter ist ruhiger, aber lockerer; enger ist präziser, kann aber um die Mitte zittern.
Mehr: eine ruhigere, aber lockerere Mitte mit mehr Spiel.
Weniger: eine straffere Mitte, die in Ruhe zittern kann.
Warum hier: Sets travel around the centre before the baseline spring resists. Smaller values engage it sooner.
Ein Gesamtmaß über beide anhaltenden Achslasten, vor ihrer Einzelbalance angewendet. Profile lassen es normalerweise stehen und stimmen die beiden Achslasten ab.
Mehr: beide Achsen laden härter auf.
Weniger: beide Achsen werden gemeinsam leichter.
Warum hier: The 0 gain omits sustained directed airspeed loading. Spring resistance remains independent.
Aktiviert das Niedrigfahrt-Einblendfenster der Feder (Beginn/Voll in Knoten oben). Aus bleibt die Feder bei jeder Fahrt konstant.
Warum hier: Allows baseline spring strength to rise with indicated airspeed where the control law permits it.
Wie viel Feder im Stillstand übrig bleibt, bevor Fahrt überhaupt aerodynamische Kraft aufbauen kann. Ein hoher Sockel hält den geparkten Stick straff; ein niedriger ergibt das lose Seilzuggefühl eines geparkten Leichtflugzeugs.
Mehr: ein festerer Stick beim Parken und Rollen.
Weniger: ein schlaffer geparkter Stick, der erst mit Fahrt aufwacht.
Warum hier: Sets low-speed spring strength as a fraction of baseline when blending is enabled. One keeps full strength.
Die Fahrt, ab der die Feder vom Niedrigfahrt-Sockel Richtung volle Stärke steigt: der Beginn des "Lebendigwerdens" der Ruder im Startlauf.
Warum hier: Sets the IAS where the low-speed spring blend starts rising. This is a feel threshold, not a flight limit.
Die Fahrt, bei der die Feder volle Stärke erreicht. Zwischen Beginn und diesem Punkt strafft sich die Zentrierung zunehmend mit der Anströmung.
Warum hier: Sets the IAS where the low-speed blend reaches baseline strength; high-speed stiffening also uses it.
Die angezeigte Fahrt, bei der die aerodynamische Last ihr ausgelegtes Vollniveau erreicht. Sie verankert die gesamte Lastkurve am realen Geschwindigkeitsbereich: eine 172 lädt bis 110 Knoten auf, ein Jet viel später.
Mehr: Lasten kommen später; der Stick bleibt bis zu höherer Fahrt leicht.
Weniger: Lasten kommen früher, und die Reise fühlt sich schwerer an.
Warum hier: Sets the IAS reference for aerodynamic loading. It is an estimate, not published cruise TAS or a flight limit.
Wie stark sich die Zentrierung selbst mit der Fahrt strafft, zusätzlich zu den Ausschlaglasten. Null hält das Mittengefühl konstant; mehr lässt den Stick im Reiseflug härter und im Anflug lockerer zentrieren.
Mehr: eine Mitte, die mit Fahrt spürbar härter wird.
Weniger: konstantes Mittengefühl bei jeder Fahrt.
Warum hier: Adds permitted spring resistance above the full-blend speed. Zero removes this high-speed increase.
Die Obergrenze der fahrtabhängigen Mittenstraffung, damit sehr hohe Fahrt die Feder nicht grenzenlos aufzieht.
Mehr: mehr Gesamtstraffung bei hoher Fahrt erlaubt.
Weniger: die Straffung klemmt früher ab.
Warum hier: Limits the squared airspeed ratio used for high-speed spring stiffening; it is not a device-force cap.
Die anhaltende Rolllast aus Querruderausschlag und Fahrt, unabhängig vom Nick balanciert. Zusammen mit der Höhenruderlast bestimmt sie die Ruderharmonie, von der Testberichte sprechen.
Mehr: schwerere Rollkräfte.
Weniger: leichtere, quirligere Querruder.
Warum hier: Roll and pitch aerodynamic scales are 0.72 and 1, respectively. These stored weights do not create directed aerodynamic loading while that term is inactive. No custom spring-travel curve is enabled.
Die anhaltende Nicklast aus Höhenruderausschlag und Fahrt, unabhängig von der Rollachse balanciert. Der Haupthebel für das Nickgewicht eines Musters. Er verändert weder Querruder, Feder, Trimmung noch Schüttelkräfte.
Mehr: schwerere anhaltende Nickkräfte bei Fahrt.
Weniger: ein leichteres Höhenruder, das weniger Muskel braucht.
Warum hier: Scales pitch aerodynamic loading; pitch spring travel and trim responses are separate settings.
Eine Kappe je stetiger Nick- oder Rollkraft vor dem Gerät. Der Schutz davor, die Hardware in harten Manövern zu überfahren oder zu sättigen.
Mehr: stärkere Spitzenkräfte vor dem Abschneiden.
Weniger: eine sanftere Decke; harte Manöver flachen früher ab.
Warum hier: Caps directed-force output. Native spring effects and device limits remain separate.
Wie stark Höhenrudertrimmung die gehaltene Nickkraft abbaut und den Ruhepunkt des Sticks verschiebt. Bei 100 % braucht ein sauber getrimmtes Flugzeug keinen gehaltenen Druck: das Wegtrimmen der Last wie im echten Fliegen.
Mehr: Trimmung nimmt mehr der gehaltenen Nickkraft; bei 100 % nullt volle Trimmung sie.
Weniger: du hältst auch getrimmt weiter Kraft.
Warum hier: Scales supported pitch-trim relief and permitted centre movement. Zero removes pitch response.
Dieselbe Entlastung für Rolltrimmung. Die meisten GA-Muster haben keine echte Querrudertrimmung, daher bleibt sie bei null; Muster mit Rolltrimmung bekommen einen passenden Wert.
Mehr: Rolltrimmung nimmt mehr gehaltene Rollkraft.
Weniger: Rolltrimmung bewirkt weniger.
Warum hier: Scales supported roll-trim relief and permitted centre movement. Zero removes roll response.
Rollende Untergrundvibration aus Radgeschwindigkeit und Oberflächenart: die Textur von Asphalt, Gras oder Schotter unter dem Fahrwerk.
Mehr: lautere Oberflächentextur durch den Stick.
Weniger: ruhigeres Rollen.
Warum hier: Sets rolling texture strength, modified by speed, surface and undercarriage configuration.
Kurze einzelne Stöße von Dehnfugen, Spurrillen und rauem Belag: die Interpunktion über dem kontinuierlichen Rumpeln.
Mehr: schärfere Stöße von Fugen und Rillen.
Weniger: weichere Bodendetails.
Warum hier: Sets gear-bump texture during ground motion, separate from touchdown impact.
Zellenschütteln vor dem Überziehen und bei aktiver Überziehwarnung: wie laut diese Fläche ihr Unbehagen ankündigt. Muster mit sauberem Abriss bekommen moderates Schütteln, das Horn trägt die Warnung.
Mehr: lauteres Schütteln vor dem Überziehen.
Weniger: eine leisere Fläche; das Horn trägt die Warnung.
Warum hier: Sets stall-buffet strength. Zero removes the cue without changing simulator stalls or warnings.
Transsonisches Schütteln nahe der Machgrenze. Relevant für Jets nahe MMO, null für Kolben und Turboprops, die nie dort ankommen.
Mehr: stärkeres transsonisches Schütteln nahe der Machgrenze.
Weniger: ruhigerer Flug bei hohem Mach.
Warum hier: Sets high-Mach buffet strength; onset and full-strength thresholds are separate.
Niederfrequente Zellenvibration mit Klappen im Fahrtwind, im Fenster, in dem sie wirklich Luft arbeiten.
Mehr: ein rauerer Lauf mit arbeitenden Klappen.
Weniger: ruhigere Anflugklappen.
Warum hier: Sets flap buffet at the configured position and speed gates. Flap movement texture is separate.
Zellentrommeln vom ausgefahrenen Einziehfahrwerk im Fahrtwind. Null für Festfahrwerke, deren Zelle nie die Form ändert.
Mehr: mehr Trommeln mit hängendem Fahrwerk.
Weniger: saubererer Flug mit Fahrwerk.
Warum hier: Sets gear aerodynamic buffet; movement and ground-contact cues are separate.
Der dedizierte Stall-Stickshaker-Buzz, ausgelöst von der Überziehwarnanlage des Flugzeugs. Nur Muster mit echtem Shaker bekommen einen Wert; alle anderen verlassen sich auf Schütteln und Horn.
Mehr: ein härterer Shaker-Buzz.
Weniger: ein dezenterer Shaker.
Warum hier: Sets triggered shaker strength; inactive while the shaker feature is disabled.
Der Einmalstoß beim Aufsetzen, skaliert mit der Sinkrate: ein Butterlander flüstert, ein fester Aufsetzer wummst.
Mehr: ein härterer Tritt beim Aufsetzen.
Weniger: weichere Ankünfte.
Warum hier: Sets landing-impact strength; landing telemetry and response shape determine the pulse.
Ausrollvibration bei Schubumkehr oder Beta-Verstellung. Null für Muster ohne Umkehr.
Mehr: ein rauerer Ausrollvorgang unter Umkehrschub.
Weniger: leisere Umkehr.
Warum hier: Sets reverse-thrust vibration with valid reverser and engine conditions. Zero removes the cue.
Kontinuierliche Triebwerksvibration, die der Drehzahl von Leerlauf bis Volllast folgt: die allgegenwärtige Erinnerung, dass vorn etwas Kraftstoff verbrennt.
Mehr: mehr Triebwerk im Stick.
Weniger: ein leiseres Triebwerk.
Warum hier: Sets estimated engine vibration using configured telemetry and response, not measured cockpit vibration.
Dauervibration nur, solange der Simulator tatsächlich fahrende Klappenflächen meldet. Folgt echter Aktuatorbewegung und Ausfällen, keinem geschätzten Timer.
Mehr: mehr Vibration bei fahrenden Klappen.
Weniger: leisere Klappenläufe.
Warum hier: Sets texture from observed flap movement; a command without movement does not establish the cue.
Wie weit Autopilotbefehle den physischen Stick bewegen dürfen. In MSFS winzig gehalten, weil eine bewegte Achse als Pilotene ingabe zurückgelesen werden kann; null schaltet das Folgen ab.
Mehr: der Autopilot bewegt deinen Stick sichtbar weiter.
Weniger: ein kaum wahrnehmbares Folgen.
Warum hier: Sets admitted AP-follow gain, not a percentage of travel. Runtime ownership and input limits still apply.
Whether this feature is active in this profile.
Warum hier: Retained for compatibility and group membership. Trim relief, rather than this flag, controls centre movement.
Whether this feature is active in this profile.
Warum hier: Allows trim relief with supported control law and valid telemetry. Axis authorities set its amount.
Whether this feature is active in this profile.
Warum hier: Local force trim, when selected, moves the hardware spring centre; it does not reproduce every developer's stabilization or load-management logic. Local force trim is off. The stored latch parameters are inactive; the profile does not supply a local hold-where-left neutral.
Download manualExact product and documentation researchWhether this feature is active in this profile.
Warum hier: Allows load-factor changes to modify permitted spring laws. Passive fly-by-wire feel can suppress it.
Whether this feature is active in this profile.
Warum hier: Enables rate damping with the configured coefficients and control law.
Whether this feature is active in this profile.
Warum hier: Autopilot following is off; the configured spring and load retain the hardware feel.
Whether this feature is active in this profile.
Warum hier: Permits centering hold during a supported AP state, separate from following a moving target.
Warum hier: Sets admitted AP neutral-hold strength; inactive while neutral hold is disabled.
Whether this feature is active in this profile.
Warum hier: Enables aerodynamic cues; each still needs nonzero strength and its simulator conditions.
Where this effect reaches full strength (or has fully faded, for washouts).
Mehr: a more gradual build to a later peak.
Weniger: a quicker build.
Warum hier: Sets the final flap index for detent normalization. UP plus three detents uses maximum index3.
Where this effect begins fading in.
Mehr: the effect begins later.
Weniger: it begins earlier.
Warum hier: Sets the first flap detent that admits buffet; this is a handle index, not degrees.
Whether this feature is active in this profile.
Warum hier: Permits shaker at supported warning conditions; the switch does not establish aircraft equipment.
Whether this feature is active in this profile.
Warum hier: Enables ground effects; each still needs its own strength and contact or motion telemetry.
Whether this feature is active in this profile.
Warum hier: Enables engine cues with nonzero settings and valid running-engine telemetry.
Whether this feature is active in this profile.
Warum hier: Enables accessory cues with configured strengths and observed accessory movement.
The strength of this effect.
Mehr: a stronger effect.
Weniger: a weaker one.
Warum hier: Sets texture from observed gear movement, separate from aerodynamic and touchdown effects.
| Parameter | Wert | Was es steuert und warum |
|---|---|---|
| Spring strength | 0.14 | Nominal cyclic centering and damping provide the selected handling balance; beginner stability and external-load weight are aircraft behaviors, not additional calibrated spring forces. The baseline spring is 0.14. Low-speed spring blending is off. |
| Spring deadband | 0.02 | Sets travel around the centre before the baseline spring resists. Smaller values engage it sooner. |
| Force gain | 0 | The 0 gain omits sustained directed airspeed loading. Spring resistance remains independent. |
| Master gain | 0.65 | Scales overall profile strength while preserving effect balance, subject to device and output limits. |
| Dynamic-pressure blend | False | Allows baseline spring strength to rise with indicated airspeed where the control law permits it. |
| Minimum spring factor | 1 | Sets low-speed spring strength as a fraction of baseline when blending is enabled. One keeps full strength. |
| Spring wake-up speed | 8 kt | Sets the IAS where the low-speed spring blend starts rising. This is a feel threshold, not a flight limit. |
| Spring full-strength speed | 45.0 kt | Sets the IAS where the low-speed blend reaches baseline strength; high-speed stiffening also uses it. |
| Geschwindigkeit zur Kraftabstimmung | 90 kt | Sets the IAS reference for aerodynamic loading. It is an estimate, not published cruise TAS or a flight limit. |
| Airspeed spring stiffening | 0 | Adds permitted spring resistance above the full-blend speed. Zero removes this high-speed increase. |
| Airspeed stiffening cap | 5 | Limits the squared airspeed ratio used for high-speed spring stiffening; it is not a device-force cap. |
| Aileron force scale | 0.72 | Roll and pitch aerodynamic scales are 0.72 and 1, respectively. These stored weights do not create directed aerodynamic loading while that term is inactive. No custom spring-travel curve is enabled. |
| Elevator force scale | 1 | Scales pitch aerodynamic loading; pitch spring travel and trim responses are separate settings. |
| Maximum output force | 0.55 | Caps directed-force output. Native spring effects and device limits remain separate. |
| StickFeel · Trim feel enabled | False | Retained for compatibility and group membership. Trim relief, rather than this flag, controls centre movement. |
| StickFeel · Trim relief enabled | False | Allows trim relief with supported control law and valid telemetry. Axis authorities set its amount. |
| StickFeel · Elevator authority | 0 | Scales supported pitch-trim relief and permitted centre movement. Zero removes pitch response. |
| StickFeel · Aileron authority | 0 | Scales supported roll-trim relief and permitted centre movement. Zero removes roll response. |
| StickFeel · Force trim enabled | False | Local force trim, when selected, moves the hardware spring centre; it does not reproduce every developer's stabilization or load-management logic. Local force trim is off. The stored latch parameters are inactive; the profile does not supply a local hold-where-left neutral. |
| StickFeel · G load enabled | False | Allows load-factor changes to modify permitted spring laws. Passive fly-by-wire feel can suppress it. |
| StickFeel · Rate damping enabled | False | Enables rate damping with the configured coefficients and control law. |
| Autopilot · Follow enabled | False | Autopilot following is off; the configured spring and load retain the hardware feel. |
| Autopilot · Follow authority | 0.05 | Sets admitted AP-follow gain, not a percentage of travel. Runtime ownership and input limits still apply. |
| Autopilot · Neutral hold enabled | False | Permits centering hold during a supported AP state, separate from following a moving target. |
| Autopilot · Neutral hold strength | 0.6 | Sets admitted AP neutral-hold strength; inactive while neutral hold is disabled. |
| Aero · Enabled | True | Enables aerodynamic cues; each still needs nonzero strength and its simulator conditions. |
| Aero · Gain | 0 | Sets stall-buffet strength. Zero removes the cue without changing simulator stalls or warnings. |
| Aero · Gain | 0 | Sets high-Mach buffet strength; onset and full-strength thresholds are separate. |
| Aero · Gain | 0 | Sets flap buffet at the configured position and speed gates. Flap movement texture is separate. |
| Aero · Max flap index | 1 | Sets the final flap index for detent normalization. UP plus three detents uses maximum index3. |
| Aero · Min flap index | 1 | Sets the first flap detent that admits buffet; this is a handle index, not degrees. |
| Aero · Gain | 0 | Sets gear aerodynamic buffet; movement and ground-contact cues are separate. |
| Aero · Shaker enabled | False | Permits shaker at supported warning conditions; the switch does not establish aircraft equipment. |
| Aero · Amplitude | 0.5 | Sets triggered shaker strength; inactive while the shaker feature is disabled. |
| Ground · Enabled | True | Enables ground effects; each still needs its own strength and contact or motion telemetry. |
| Ground · Gain | 0 | Sets rolling texture strength, modified by speed, surface and undercarriage configuration. |
| Ground · Gain | 0 | Sets gear-bump texture during ground motion, separate from touchdown impact. |
| Ground · Gain | 0.5 | Sets landing-impact strength; landing telemetry and response shape determine the pulse. |
| Ground · Gain | 0 | Sets reverse-thrust vibration with valid reverser and engine conditions. Zero removes the cue. |
| Engine · Enabled | True | Enables engine cues with nonzero settings and valid running-engine telemetry. |
| Engine · Gain | 0 | Sets estimated engine vibration using configured telemetry and response, not measured cockpit vibration. |
| Mechanical · Enabled | True | Enables accessory cues with configured strengths and observed accessory movement. |
| Mechanical · Gain | 0 | Sets texture from observed flap movement; a command without movement does not establish the cue. |
| Mechanical · Gain | 0 | Sets texture from observed gear movement, separate from aerodynamic and touchdown effects. |
Wenn deine Erfahrung im Muster sagt, dass hier etwas falsch ist, korrigiere es hier.
Diese Seite basiert auf zitierten Quellen, und echte Erfahrung im Muster schlägt jedes Zitat. Zitiere die falsche Aussage und sag uns, was das echte Flugzeug tut. Korrekturen gehen zur Prüfung an den Maintainer und fließen in die nächste Fassung dieser Recherche ein.
Offene Unterhaltung über das Fliegen und Tunen der Aérospatiale SA 315B Lama, im Community-Forum. Korrekturen oben gehen privat an den Maintainer; Hangargespräche sind öffentlich.