Development milestones
First flight: 1949
Developed from: Piper PA-11 Cub Special
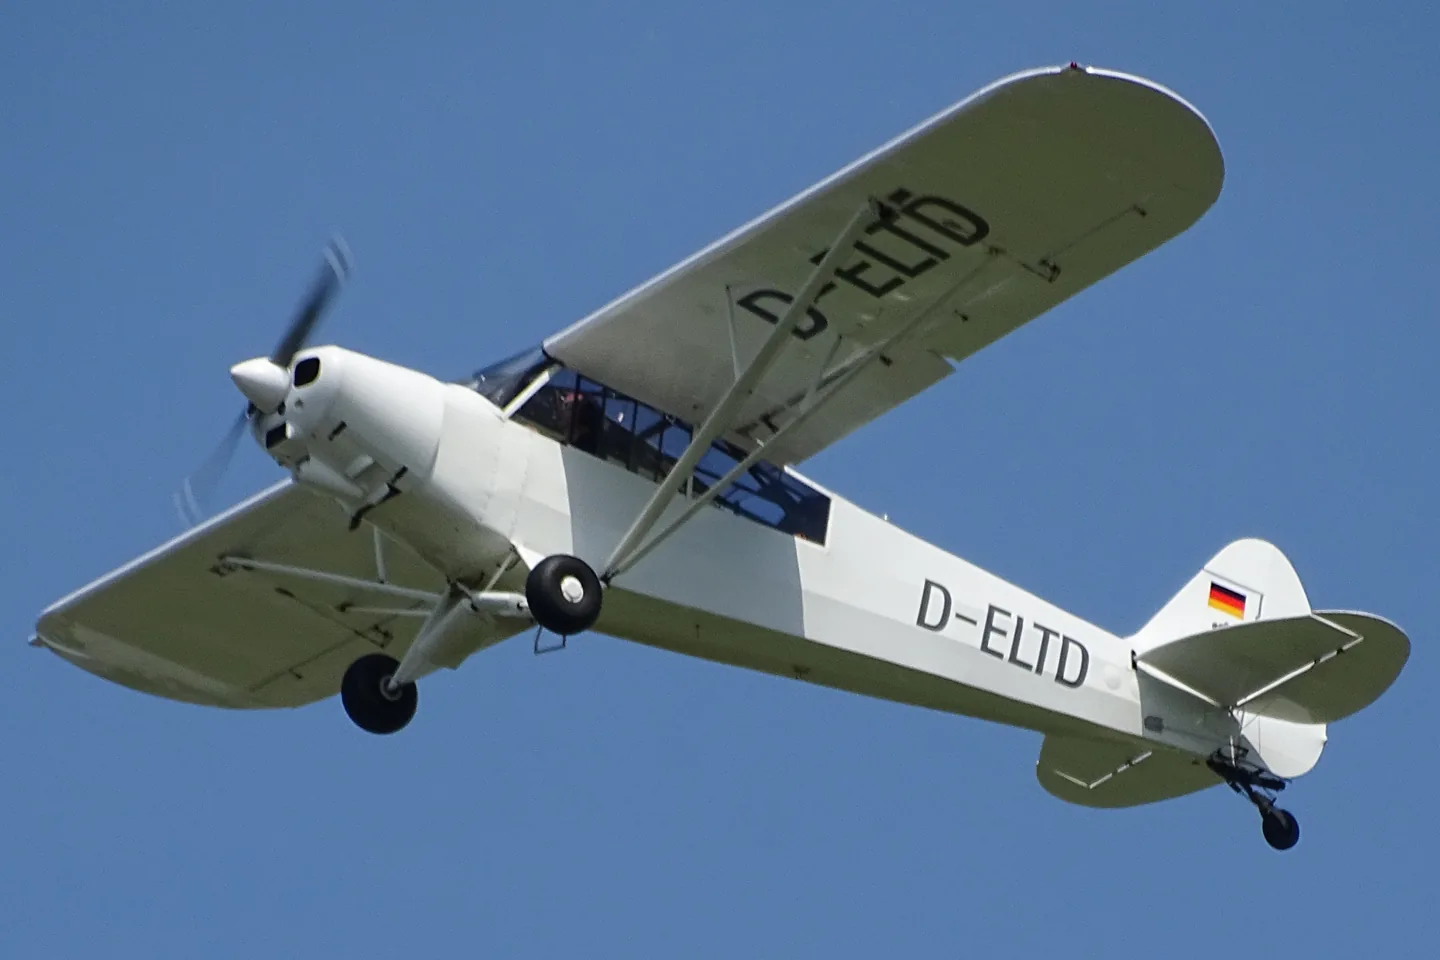 Ad Meskens · CC BY-SA 4.0 · Piper PA-18 Super Cub pictured
The Super Cub joined Piper's range in 1949, developing earlier Cub designs with more power and equipment. It retained the braced high wing, tandem cabin and tailwheel layout. Its working roles include glider towing, banner towing and remote-area transport.
Many individual aircraft are modified with different engines, wheels and equipment. Each simulator package identifies its represented variant and cockpit.
Piper PA-18 Super Cub · Specifications (PA-18-150 landplane) · real aircraft; source units retained
AirframeDB-তে এই বিমান সম্পর্কে আরও জানুন
First flight: 1949
Developed from: Piper PA-11 Cub Special
Laminar’s background chapter describes a fabric-covered steel-tube fuselage, a braced high wing and the extra power, flaps and wing tanks that distinguish the Super Cub from the earliest Cub designs. It also describes the broad modification culture around the type, including large low-pressure tyres, cargo racks and additional storage. Those visible changes help explain why two PA-18 photographs can show quite different working equipment.
Garvey borrowed a new 150-horsepower Super Cub at the factory before its owner, Piper dealer Jim Porter, took it home. His report places it in an interesting period: Piper was promoting its newer designs while customers who needed a Cub already knew where to find one. The aeroplane's fabric covering, tandem seats and simple starting controls made its older lineage immediately apparent, even with the extra power and flaps of the Super Cub.
For the flight, two people and full tanks left the aircraft below its permitted maximum weight. Garvey reported a strong climb that continued at 4,000 feet. He tried stalls with and without power and flap, describing mild breaks and prompt recovery in each case. A half-flap arrival then showed the compact landing performance that helped explain the aircraft's working reputation. His brief evaluation conveys a practical, capable machine encountered during production, with the results tied to that flight's loading rather than an assumed performance standard for today's many modified Cubs.
Davisson returned to the PA-18 after roughly fifteen years away, flying Tom Hampton's restored 150-horsepower Super Cub on the same afternoon as an older J-2. Its larger tyres, comfortable seats and stronger climb made the family resemblance feel distinctly more capable. He liked the control response and could see ahead well enough on the ground without the weaving taxi he might have expected from a tailwheel aircraft. His comparison concerns these particular Cubs, not every version carrying the name.
The landings provided a candid account of relearning the aeroplane. His first clean approach floated and ended with a bounce on the large tyres. Half flap made the next descent easier to manage and reduced the float. For the final attempt, he used full flap but let the speed decay too early, leaving little elevator authority for the flare and another untidy arrival. He did not perform stalls on this flight.
Worthy first flew a Super Cub in 2013 at Alaska Float Ratings in Moose Pass. Most of her previous experience had been in a Cessna 210, so she expected the stick and left-hand throttle to require adjustment. Instead, both felt natural almost immediately. She flew two 160-horsepower examples with different floats and panels, learning the unfamiliar work of manoeuvring on water and choosing a takeoff direction without a marked runway.
From the front seat, the view to either side became a large part of the attraction: the flights passed turquoise lakes and glacier-covered mountains. She found the float Cub much more responsive than the heavier Cessna she knew, while still feeling steady in the canyon winds she encountered. Simulated power-loss exercises also made the extra drag of the floats memorable. Her account is a recollection of supervised seaplane training, and her strongest impression was the simple pleasure of it; she remembers finishing flights with her face aching from smiling.
The Super Cub joined Piper's range in 1949, developing earlier Cub designs with more power and equipment. It retained the braced high wing, tandem cabin and tailwheel layout. Its working roles include glider towing, banner towing and remote-area transport.
This starting point selects Piper PA-18 Super Cub. Its aircraft-level settings do not select a particular developer’s custom systems.
Manual stick control motivates aerodynamic resistance. Spring resistance builds with the selected airspeed response. A separate aerodynamic term adds speed-dependent control load.
The adjustable stabilizer supplies pitch-trim context. Valid trim provides the configured pressure relief. Autopilot following is off.
The Super Cub uses a manual stick, flap lever and pitch-trim handle. Its adjustable horizontal stabilizer supplies the aircraft’s longitudinal trim arrangement. Engine, wheel and float choices identify different utility configurations.
The gains are normalized profile settings. They describe the chosen effect balance; hand force depends on the device and its output limits. IAS references are tuning values rather than operating limits. Physical acceptance of this revision remains pending.
ডিভাইস ক্যাপ-এর আগে মডেল তৈরি করা সবকিছুর জন্য সর্বশেষ সম্পূর্ণ আউটপুট স্কেল প্রয়োগ করা হয়।
আরো: সবকিছু (স্প্রিং, লোড, প্রভাব) একসাথে শক্তিশালী হয়।
কম: সবকিছু একসাথে নরম হয়ে যায়।
এখানে কেন: Scales overall profile strength while preserving effect balance, subject to device and output limits.
বেস কেন্দ্রে ফেরানো বল যা স্টিক-কে কেন্দ্রে ফিরিয়ে আনে। প্রত্যেকটি বল এর ওপর স্ট্যাক করা হয়। খুবই কম হলে স্টিক স্বাভাবিক উড়োজাহাজের মত স্থির মনে হয়; খুবই বেশি হলে আপনার হাতের সাথে লড়াই করে এবং উপরের ছোট স্তরগুলোকে আড়াল করে।
আরো: আরও দৃঢ় কেন্দ্রমুখী বল, যা সব সময় আপনার হাতের নড়াচড়ায় বাধা দেয়।
কম: একটি লিম্পার স্টিক যা শুধুমাত্র বায়ুগতীয় লোডের উপর নির্ভর করে।
এখানে কেন: Manual stick control motivates aerodynamic resistance. The baseline spring is 0.74. Its low-speed blend reaches baseline strength at 42.5 KIAS.
Piper PA-18 Super Cub POHকেন্দ্রের চারপাশে একটি ছোট নিরপেক্ষ অঞ্চল যেখানে স্প্রিং নিরব থাকে, তাই অস্থায়ী অবস্থায় ক্ষুদ্র নড়াচড়া শব্দ করে না। প্রশস্ত হলে তা আরও শান্ত হবে কিন্তু আরামদায়ক; সংকীর্ণ হলে তা আরও নির্ভুল হবে কিন্তু কেন্দ্রের চারদিকে ঝাঁপিয়ে পড়তে পারে।
আরো: একটু শান্ত কিন্তু আরো বেশি মুক্ত খেলার সাথে উন্মুক্ত কেন্দ্র।
কম: একটি সংকীর্ণ কেন্দ্র যে বিশ্রাম সময় কথা বলতে পারে.
এখানে কেন: Sets travel around the centre before the baseline spring resists. Smaller values engage it sooner.
উভয় অক্ষ লোডের উপর একটি মাস্টার স্কেল, তাদের স্বাধীন ভারসাম্য প্রয়োগের পূর্বে প্রয়োগ করা হয়। প্রোফাইল সাধারণত এটিকে একা ছেড়ে দেয় এবং এর পরিবর্তে দুইটি অক্ষ লোড টুইন করে।
আরো: উভয় অক্ষ লোড করা কঠিন।
কম: উভয় অক্ষ একসাথে আলোকিত হয়।
এখানে কেন: The aerodynamic-load gain is 0.8 with an indicated-speed reference of 85 KIAS. This supplies speed-dependent loading alongside the spring.
কম গতির স্প্রিং সংযোগ উইন্ডো সক্রিয় করে (উপরে knots শুরু/পূর্ণ)। নিষ্ক্রিয় হলে, স্প্রিং সব ধরনের গতিতেই একই থাকে।
এখানে কেন: Allows baseline spring strength to rise with indicated airspeed where the control law permits it.
স্প্রিং-এর কতটুকু অস্তিত্ব আছে, যখন বায়ুগতি কোন বায়ুগতীয় বা বল তৈরি করতে পারে না। উচ্চ তলায় পার্ক করা স্টিক-কে দৃঢ় রাখা হয়; নিম্ন তলায় পার্ককৃত হালকা বিমানের মত পাতলা, কেবল-সলাকের অনুভূতি পাওয়া যায়।
আরো: পার্কিং এবং ট্যাক্সি চালানোর সময় আরো দৃঢ় স্টিক।
কম: একটি ফ্লপি পার্ক করা স্টিক যা শুধুমাত্র বায়ুগতি দ্বারা জাগ্রত হয়।
এখানে কেন: Sets low-speed spring strength as a fraction of baseline when blending is enabled. One keeps full strength.
বায়ুগতি যেখানে স্প্রিং তার কম গতির ন্যূনতম সীমা থেকে পূর্ণ শক্তির দিকে উঠতে শুরু করে: রোল-এ উড্ডয়নের সময় নিয়ন্ত্রণ "জীবিত হয়ে ওঠে"।
এখানে কেন: Sets the IAS where the low-speed spring blend starts rising. This is a feel threshold, not a flight limit.
বায়ুগতি যেখানে স্প্রিং সম্পূর্ণ শক্তি অর্জন করে। শুরু এবং এই বিন্দুর মধ্যে, কেন্দ্রে ফেরানো নিয়ন্ত্রণের উপর বায়ু প্রবাহ বৃদ্ধির সাথে সাথে ক্রমবর্ধমানভাবে দৃঢ় হয়ে ওঠে।
এখানে কেন: Sets the IAS where the low-speed blend reaches baseline strength; high-speed stiffening also uses it.
নির্দেশিত বায়ুগতি যেখানে বায়ুগতীয় লোড তার নকশাকৃত সম্পূর্ণ স্তরে পৌঁছে যায়। এটি সমগ্র লোড বক্ররেখাকে বিমানের প্রকৃত গতি সীমার সাথে সংযুক্ত করে: একটি 172 লোড করা হয় 110 knots দ্বারা, একটি জেট অনেক পরে।
আরো: লোড পরে আসে; স্টিক উচ্চতর গতি পর্যন্ত হালকা থাকে।
কম: লোড দ্রুত পৌঁছায় এবং ক্রুজ ভারী মনে হয়।
এখানে কেন: Sets the IAS reference for aerodynamic loading. It is an estimate, not published cruise TAS or a flight limit.
কেন্দ্রে ফেরানো নিজেই কি পরিমাণ দ্রুতগতির সাথে সংকুচিত হয়, বিচ্যুতি লোডের উপরে। শূণ্য হলে কেন্দ্রস্থল স্থির মনে হয়; বেশি হলে স্টিক কেন্দ্রস্থল ক্রুজে কঠিন হয়ে যায় এবং নকশায় পাতলা হয়ে যায়।
আরো: একটি কেন্দ্র যেটি দ্রুতগতিতে যাওয়ার সাথে সাথে দৃশ্যমানভাবে কঠিন হয়ে যায়।
কম: প্রতিটি গতিতেই স্থির কেন্দ্র অনুভূতি।
এখানে কেন: The high-speed spring-stiffening gain is 0.15. It strengthens the permitted spring response above 42.5 KIAS, with the squared-speed ratio capped at 5.
গতি-চালিত কেন্দ্র স্থিরকরণের উপরের সীমা, তাই খুব দ্রুত উড়োজাহাজ সীমা ছাড়া স্প্রিং উড়িয়ে দিতে পারে না।
আরো: উচ্চ গতিতে আরো মোট স্থিরতা অনুমোদিত.
কম: ক্ল্যাম্পগুলো দ্রুত খুলে ফেলো।
এখানে কেন: Limits the squared airspeed ratio used for high-speed spring stiffening; it is not a device-force cap.
এইলারন, বিচ্যুতি এবং বায়ুগতি থেকে স্থায়ী রোল লোড, পিচ এর স্বাধীনভাবে ভারসাম্যপূর্ণ। এলিভেটর লোডের সাথে এটি নিয়ন্ত্রণ-সমঞ্জস্য অনুপাত নির্ধারণ করে যা পর্যালোচনাকারীরা আলোচনা করে।
আরো: ভারী রোল বল।
কম: হালকা, দ্রুত অনুভূতি এয়াররোন.
এখানে কেন: Roll and pitch aerodynamic scales are 0.6 and 0.78, respectively. They set the aerodynamic axis balance. No custom spring-travel curve is enabled.
এলিভেটরের বিচ্যুতি ও বায়ুগতির কারণে তৈরি অবিরাম পিচ লোড, যা রোল থেকে স্বাধীনভাবে সামঞ্জস্য করা হয়। কোনও বিমানের পিচে ভারী অনুভূতি নিয়ন্ত্রণের এটি প্রধান উপায়। এতে এলারন, স্প্রিং, ট্রিম বা বাফেটিংয়ের বল বদলায় না।
আরো: দ্রুতগতিতে ভারী পিচ বল চালানো।
কম: একটি হালকা এলিভেটর যা ধরে রাখতে কম পেশী দরকার।
এখানে কেন: Scales pitch aerodynamic loading; pitch spring travel and trim responses are separate settings.
প্রতিটি স্থির পিচ অথবা রোল বল এর উপর ডিভাইসে পৌঁছানোর পূর্বে একটি ক্যাপ, শক্তিশালী ম্যানুয়ালগুলিতে হার্ডওয়্যারকে স্লিপিং বা সাটিউরেট করার থেকে রক্ষা করে।
আরো: ক্লিপ করার পূর্বে শক্তিশালী পিক স্থির বল।
কম: একটি নরম ছাদ; কঠিন ম্যানুয়াল দ্রুত flatten out.
এখানে কেন: Caps directed-force output. Native spring effects and device limits remain separate.
এলিভেটর ট্রিম কতটা শক্তিশালীভাবে পিচ বল-কে সরিয়ে দেয় এবং যেখানে স্টিক অবস্থিত সেখানে স্থানান্তর করে। 100%-এ, একটি সঠিক ট্রিম করা বিমানের কোন চাপ-এর প্রয়োজন নেই, বাস্তব উড়োজাহাজের ট্রিম-away-the-load workflow।
আরো: ট্রিম ধরে রাখা পিচ বল-এর অধিকাংশ অপসারণ করে; 100% পূর্ণ হলে ট্রিম এটি শূণ্য করে।
কম: ট্রিম করার পরেও আপনাকে বল ধরে রাখতে হয়।
এখানে কেন: The adjustable stabilizer supplies pitch-trim context. Pitch authority 0.3 provides load relief and permitted centre movement; roll authority is 0.
Piper PA-18 Super Cub POHরোল ট্রিমের জন্য একইভাবে বল কমানো। বেশিরভাগ GA বিমানে বাস্তব এলারন ট্রিম নেই, তাই এটি শূন্য থাকে; রোল ট্রিম আছে এমন বিমানে উপযুক্ত মান দেওয়া হয়।
আরো: রোল ট্রিম আরো রোল বল সরিয়ে ফেলে।
কম: রোল ট্রিম কম করে।
এখানে কেন: Scales supported roll-trim relief and permitted centre movement. Zero removes roll response.
চাকার গতি এবং পৃষ্ঠের ধরন থেকে রোলিং পৃষ্ঠের কম্পন: গিয়ার-এর অধীনে পাথর, ঘাস অথবা গর্ত।
আরো: স্টিক-এর মাধ্যমে উচ্চতর পৃষ্ঠের টেক্সচার।
কম: ট্যাক্সি চালানো সহজ হবে।
এখানে কেন: Sets rolling texture strength, modified by speed, surface and undercarriage configuration.
বিস্তৃত সংযোগস্থল, ছিদ্র এবং মসৃণ পৃষ্ঠ থেকে সংক্ষিপ্ত বিচ্ছিন্ন ঝাঁকুনি, যা অবিরাম কম্পন-কে চিহ্নিত করে।
আরো: জয়েন্ট এবং রুট থেকে আরও জোরালো আঘাত।
কম: নরম মাটির বিবরণ.
এখানে কেন: Sets gear-bump texture during ground motion, separate from touchdown impact.
এয়ারফ্রেম স্টল-এর কাছে এসে ঝাঁপিয়ে পড়ে এবং যখন স্টল সতর্কবার্তা সক্রিয় থাকে: এই ডানাটি কতটা জোরে ঘোষণা করে যে এটি অসন্তুষ্ট। তীক্ষ্ণ বিরতিযুক্ত ধরনগুলি বাফেটিং-এ পরিণত হয় এবং হর্নটিকে সতর্কবার্তা বহন করতে দেয়।
আরো: স্টল-এর আগে এক জোরালো ঝাঁকুনি।
কম: একটি শান্ত ডানা; হর্ন সতর্কতা বহন করে।
এখানে কেন: Sets stall-buffet strength. Zero removes the cue without changing simulator stalls or warnings.
ট্রান্সসনিক বাফেটিং Mach সীমার কাছে এসে পৌঁছেছে। এমএমও-এর নিকটবর্তী জেটের জন্য অর্থবহ, পিস্টন এবং টারবাইনপ্রোপের জন্য শূন্য যা কখনোই সেখানে পৌঁছায় না।
আরো: Mach সীমার কাছাকাছি শক্তিশালী ট্রান্সসনিক বাফেটিং।
কম: একটি সুষম উচ্চ-Mach সফর.
এখানে কেন: Sets high-Mach buffet strength; onset and full-strength thresholds are separate.
ফ্ল্যাপ এর সাথে কম-ফ্রিকোয়েন্সি এয়ারফ্রেম কম্পন বায়ুপ্রবাহের মধ্যে প্রসারিত হয়, গতি উইন্ডোতে যেখানে তারা আসলে বায়ুকে কাজ করে।
আরো: ফ্ল্যাপ বাতাসে কাজ করার সাথে একটি কঠিন সার্ভিস।
কম: সুষম প্রক্রিয়া ফ্ল্যাপ।
এখানে কেন: Sets flap buffet at the configured position and speed gates. Flap movement texture is separate.
এয়ারফ্রেম এয়ারস্ট্রিম-এ ঝুলন্ত গিয়ার থেকে ড্রাম বাজানো। শূন্য নির্দিষ্ট-গিয়ার ধরনের জন্য, যেখানে এয়ারফ্রেম কখনোই আকৃতি পরিবর্তন করে না।
আরো: চাকার সাথে আরো ড্রাম বাজানো।
কম: পরিষ্কার গিয়ার-ডাউন ফ্লাইট.
এখানে কেন: Sets gear aerodynamic buffet; movement and ground-contact cues are separate.
বিমানের নিজস্ব স্টল সতর্কতা ব্যবস্থা থেকে চালু হওয়া বিশেষ স্টল স্টিক-শেকারের কম্পন। বাস্তবে শেকার আছে এমন বিমানেই মান দেওয়া হয়; অন্যগুলি বায়ুগত বাফেটিং ও সতর্কতার হর্নের ওপর নির্ভর করে।
আরো: আরো কঠিন স্টিক-Shaker buzz।
কম: একটি সুক্ষ্ম শেকার.
এখানে কেন: Sets triggered shaker strength; inactive while the shaker feature is disabled.
যখন চাকাগুলো রানওয়েতে ধাক্কা দেয়, তখন এক ধাক্কায় উড়োজাহাজটি নিচে নেমে যায়: একটি গরম চুম্বন, একটি দৃঢ় আবির্ভাব।
আরো: টাচডাউনে কঠিন কিক.
কম: নরম আবির্ভাব.
এখানে কেন: Sets landing-impact strength; landing telemetry and response shape determine the pulse.
রিভার্স থ্রাস্ট অথবা beta-রেঞ্জের প্রপস কাজ করার সময় ভ্রমণের প্রদর্শন। বিপরীতমুখী না হওয়া ধরনের ক্ষেত্রে শূণ্য।
আরো: বিপরীত দিক থেকে আরো কঠিন ভাবে বেরিয়ে আসবে।
কম: শান্ত বিপরীত.
এখানে কেন: Sets reverse-thrust vibration with valid reverser and engine conditions. Zero removes the cue.
RPM-এর পর নিরবচ্ছিন্ন শক্তি উৎপাদনকারী যন্ত্রের কম্পন, অকার্যকর এবং সম্পূর্ণ শক্তির মধ্যে, সবসময় উপস্থিত স্মরণ করিয়ে দেয় যে সামনে কিছু জ্বালানি পুড়ে যাচ্ছে।
আরো: স্টিক এর মাধ্যমে আরো ইঞ্জিন।
কম: একটি নিরব শক্তি উৎপাদন কেন্দ্র.
এখানে কেন: Sets estimated engine vibration using configured telemetry and response, not measured cockpit vibration.
শুধুমাত্র সিম যখন ফ্ল্যাপ পৃষ্ঠ প্রকৃতপক্ষে ভ্রমণ করছে তা রিপোর্ট করে তখনই অবিরাম কম্পন। এটি বাস্তব অ্যাক্টর নড়াচড়া এবং ব্যর্থতা অনুসরণ করে, একটি অনুমানিত টাইমার নয়।
আরো: ফ্ল্যাপ পৃষ্ঠের ভ্রমণের সময় আরও বেশি কম্পন।
কম: নিরব ফ্ল্যাপ চলছে।
এখানে কেন: Sets texture from observed flap movement; a command without movement does not establish the cue.
অটোপাইলট কমান্ড দ্বারা স্টিক কে কত দূর সরানো যাবে। MSFS-এ ছোট করে রাখা হয়েছে, যেখানে একটি সরানো অক্ষ পাইলট ইনপুট হিসেবে পড়তে পারে; শূন্য অনুসরণ করা সম্পূর্ণ নিষ্ক্রিয় করে।
আরো: অটোপাইলট দৃশ্যমানভাবে আপনার স্টিক-কে আরো এগিয়ে নিয়ে যায়।
কম: খুবই অদৃশ্য অনুসরণ.
এখানে কেন: Sets admitted AP-follow gain, not a percentage of travel. Runtime ownership and input limits still apply.
Whether this feature is active in this profile.
এখানে কেন: Retained for compatibility and group membership. Trim relief, rather than this flag, controls centre movement.
Whether this feature is active in this profile.
এখানে কেন: Allows trim relief with supported control law and valid telemetry. Axis authorities set its amount.
Whether this feature is active in this profile.
এখানে কেন: Enables local force trim, separate from aircraft-owned trim and add-on integration qualification.
Whether this feature is active in this profile.
এখানে কেন: Allows load-factor changes to modify permitted spring laws. Passive fly-by-wire feel can suppress it.
Whether this feature is active in this profile.
এখানে কেন: Enables rate damping with the configured coefficients and control law.
Whether this feature is active in this profile.
এখানে কেন: Autopilot following is off; the configured spring and load retain the hardware feel.
Whether this feature is active in this profile.
এখানে কেন: Permits centering hold during a supported AP state, separate from following a moving target.
এখানে কেন: Sets admitted AP neutral-hold strength; inactive while neutral hold is disabled.
Whether this feature is active in this profile.
এখানে কেন: Enables aerodynamic cues; each still needs nonzero strength and its simulator conditions.
Where this effect reaches full strength (or has fully faded, for washouts).
আরো: a more gradual build to a later peak.
কম: a quicker build.
এখানে কেন: Sets the final flap index for detent normalization. UP plus three detents uses maximum index3.
Where this effect begins fading in.
আরো: the effect begins later.
কম: it begins earlier.
এখানে কেন: Sets the first flap detent that admits buffet; this is a handle index, not degrees.
Whether this feature is active in this profile.
এখানে কেন: Permits shaker at supported warning conditions; the switch does not establish aircraft equipment.
Whether this feature is active in this profile.
এখানে কেন: Enables ground effects; each still needs its own strength and contact or motion telemetry.
Whether this feature is active in this profile.
এখানে কেন: Enables engine cues with nonzero settings and valid running-engine telemetry.
Whether this feature is active in this profile.
এখানে কেন: Enables accessory cues with configured strengths and observed accessory movement.
The strength of this effect.
আরো: a stronger effect.
কম: a weaker one.
এখানে কেন: Sets texture from observed gear movement, separate from aerodynamic and touchdown effects.
| প্যারামিটার | মান | কী নিয়ন্ত্রণ করে এবং কেন |
|---|---|---|
| Spring strength | 0.74 | Manual stick control motivates aerodynamic resistance. The baseline spring is 0.74. Its low-speed blend reaches baseline strength at 42.5 KIAS. |
| Spring deadband | 0.045 | Sets travel around the centre before the baseline spring resists. Smaller values engage it sooner. |
| Force gain | 0.8 | The aerodynamic-load gain is 0.8 with an indicated-speed reference of 85 KIAS. This supplies speed-dependent loading alongside the spring. |
| Master gain | 0.85 | Scales overall profile strength while preserving effect balance, subject to device and output limits. |
| Dynamic-pressure blend | True | Allows baseline spring strength to rise with indicated airspeed where the control law permits it. |
| Minimum spring factor | 0.5 | Sets low-speed spring strength as a fraction of baseline when blending is enabled. One keeps full strength. |
| Spring wake-up speed | 11.9 kt | Sets the IAS where the low-speed spring blend starts rising. This is a feel threshold, not a flight limit. |
| Spring full-strength speed | 42.5 kt | Sets the IAS where the low-speed blend reaches baseline strength; high-speed stiffening also uses it. |
| বল টিউনিংয়ের গতি | 85.0 kt | Sets the IAS reference for aerodynamic loading. It is an estimate, not published cruise TAS or a flight limit. |
| Airspeed spring stiffening | 0.15 | The high-speed spring-stiffening gain is 0.15. It strengthens the permitted spring response above 42.5 KIAS, with the squared-speed ratio capped at 5. |
| Airspeed stiffening cap | 5 | Limits the squared airspeed ratio used for high-speed spring stiffening; it is not a device-force cap. |
| Aileron force scale | 0.6 | Roll and pitch aerodynamic scales are 0.6 and 0.78, respectively. They set the aerodynamic axis balance. No custom spring-travel curve is enabled. |
| Elevator force scale | 0.78 | Scales pitch aerodynamic loading; pitch spring travel and trim responses are separate settings. |
| Maximum output force | 0.55 | Caps directed-force output. Native spring effects and device limits remain separate. |
| StickFeel · Trim feel enabled | True | Retained for compatibility and group membership. Trim relief, rather than this flag, controls centre movement. |
| StickFeel · Trim relief enabled | True | Allows trim relief with supported control law and valid telemetry. Axis authorities set its amount. |
| StickFeel · Elevator authority | 0.3 | The adjustable stabilizer supplies pitch-trim context. Pitch authority 0.3 provides load relief and permitted centre movement; roll authority is 0. |
| StickFeel · Aileron authority | 0 | Scales supported roll-trim relief and permitted centre movement. Zero removes roll response. |
| StickFeel · Force trim enabled | False | Enables local force trim, separate from aircraft-owned trim and add-on integration qualification. |
| StickFeel · G load enabled | True | Allows load-factor changes to modify permitted spring laws. Passive fly-by-wire feel can suppress it. |
| StickFeel · Rate damping enabled | True | Enables rate damping with the configured coefficients and control law. |
| Autopilot · Follow enabled | False | Autopilot following is off; the configured spring and load retain the hardware feel. |
| Autopilot · Follow authority | 0.1 | Sets admitted AP-follow gain, not a percentage of travel. Runtime ownership and input limits still apply. |
| Autopilot · Neutral hold enabled | False | Permits centering hold during a supported AP state, separate from following a moving target. |
| Autopilot · Neutral hold strength | 0.6 | Sets admitted AP neutral-hold strength; inactive while neutral hold is disabled. |
| Aero · Enabled | True | Enables aerodynamic cues; each still needs nonzero strength and its simulator conditions. |
| Aero · Gain | 0.35 | Sets stall-buffet strength. Zero removes the cue without changing simulator stalls or warnings. |
| Aero · Gain | 0 | Sets high-Mach buffet strength; onset and full-strength thresholds are separate. |
| Aero · Gain | 0.14 | Sets flap buffet at the configured position and speed gates. Flap movement texture is separate. |
| Aero · Max flap index | 3 | Sets the final flap index for detent normalization. UP plus three detents uses maximum index3. |
| Aero · Min flap index | 2 | Sets the first flap detent that admits buffet; this is a handle index, not degrees. |
| Aero · Gain | 0 | Sets gear aerodynamic buffet; movement and ground-contact cues are separate. |
| Aero · Shaker enabled | False | Permits shaker at supported warning conditions; the switch does not establish aircraft equipment. |
| Aero · Amplitude | 0.5 | Sets triggered shaker strength; inactive while the shaker feature is disabled. |
| Ground · Enabled | True | Enables ground effects; each still needs its own strength and contact or motion telemetry. |
| Ground · Gain | 0.4 | Sets rolling texture strength, modified by speed, surface and undercarriage configuration. |
| Ground · Gain | 0.25 | Sets gear-bump texture during ground motion, separate from touchdown impact. |
| Ground · Gain | 0.65 | Sets landing-impact strength; landing telemetry and response shape determine the pulse. |
| Ground · Gain | 0 | Sets reverse-thrust vibration with valid reverser and engine conditions. Zero removes the cue. |
| Engine · Enabled | True | Enables engine cues with nonzero settings and valid running-engine telemetry. |
| Engine · Gain | 0.12 | Sets estimated engine vibration using configured telemetry and response, not measured cockpit vibration. |
| Mechanical · Enabled | True | Enables accessory cues with configured strengths and observed accessory movement. |
| Mechanical · Gain | 0.12 | Sets texture from observed flap movement; a command without movement does not establish the cue. |
| Mechanical · Gain | 0 | Sets texture from observed gear movement, separate from aerodynamic and touchdown effects. |
আপনার সময় যদি বলে যে এই পৃষ্ঠায় কিছু ভুল হয়েছে, তাহলে এখানে সংশোধন করুন।
এই পৃষ্ঠাটি উদ্ধৃত রেফারেন্স থেকে তৈরি করা হয়েছে, এবং টাইপের রিয়েল টাইম একটি উদ্ধৃতি বীট করে। ভুল পড়া দাবিটি উদ্ধৃত করুন এবং প্রকৃত বিমানটি কী করে তা আমাদের বলুন। সংশোধন পর্যালোচনার জন্য রক্ষণাবেক্ষণকারীর কাছে যান এবং এই গবেষণার পরবর্তী সংশোধনটি খাওয়ান।
কমিউনিটি ফোরামে Piper PA-18 Super Cub উড়তে এবং টিউন করার বিষয়ে খোলা কথোপকথন। উপরের সংশোধনগুলি ব্যক্তিগতভাবে রক্ষণাবেক্ষণকারীর কাছে যায়; হ্যাঙ্গার আলোচনা সর্বজনীন।