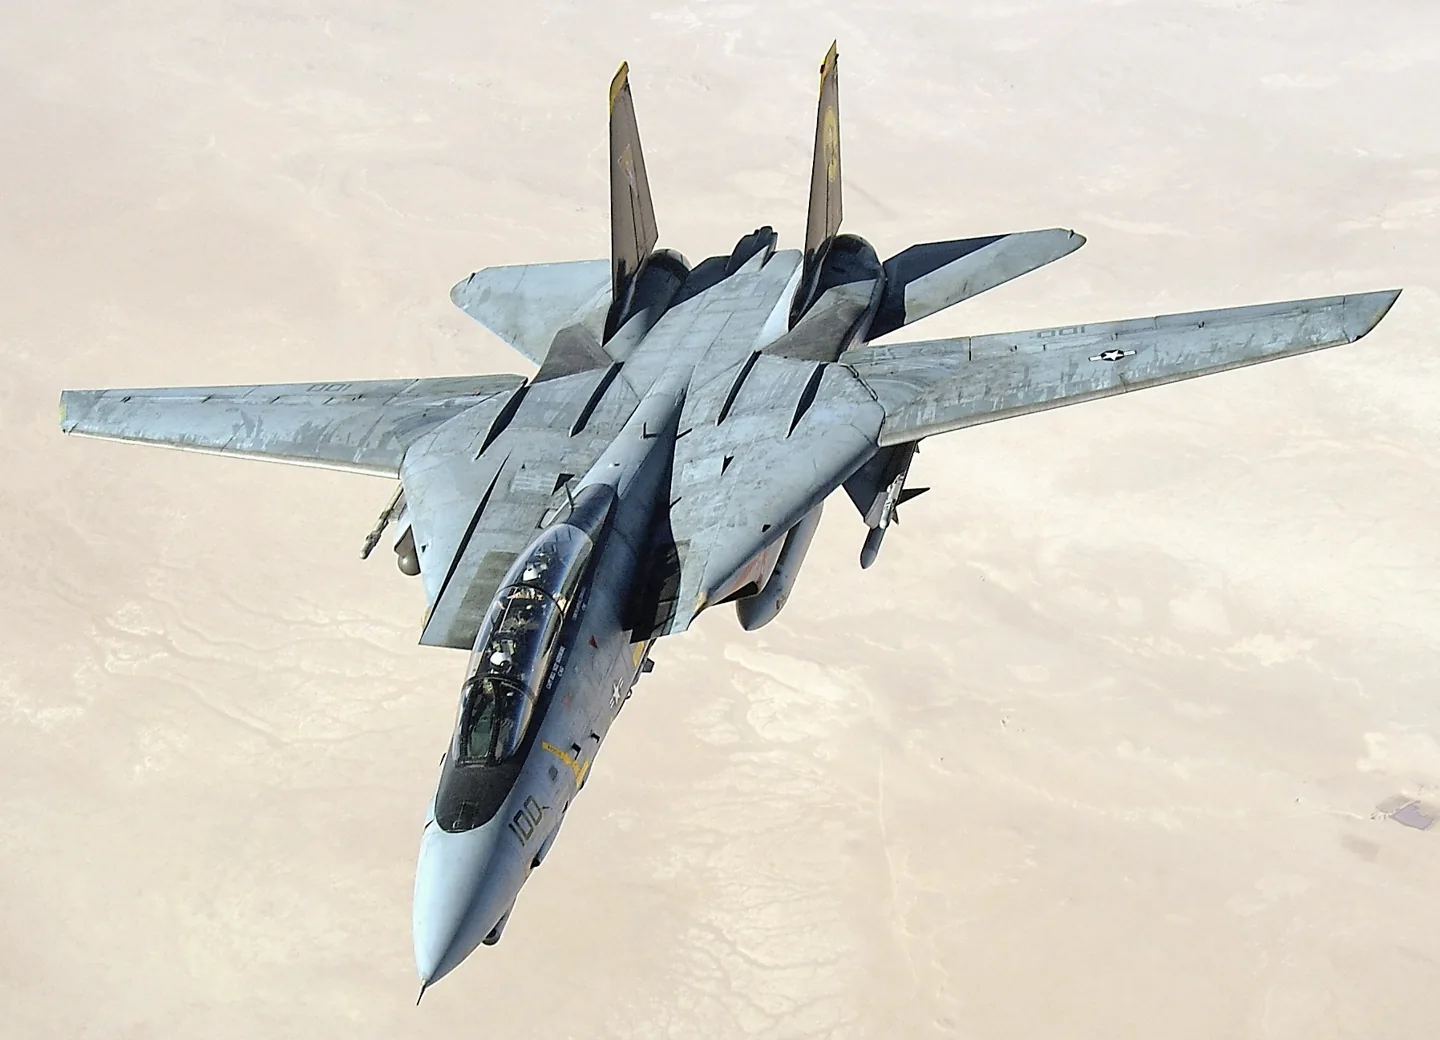
Grumman F-14 TomcatU.S. Navy photo · Public domain · US Navy F-14D Tomcat

Grumman F-14 Tomcat

A two-seat naval fighter with variable-sweep wings and a cockpit built around pilot and radar-intercept officer roles.
Military jetপ্রোফাইলের বিকল্প: 5

প্লেন চেনেন

The Tomcat was developed for the US Navy after the F-111B programme ended. Twin engines, widely spaced tails and variable-sweep wings supported fleet defence and, later, strike missions.

Pilot and radar-intercept officer divided the work between two cockpits. Engines, avionics and other systems changed between F-14 versions; the X-Plane documentation describes the model included in that simulation.

Aircraft / family

Propulsion
Twin jet↗
Configuration
Variable-sweep wing · Tandem crew↗

Grumman F-14 Tomcat · Specifications (F-14D) · real aircraft; source units retained

Length
62 ft 9 in (19.13 m)↗
Wingspan
64 ft 1.5 in (19.545 m)↗
Height
16 ft (4.9 m)↗
Wing area
565 sq ft (52.5 m² ) wings only 1,008 sq ft (94 m² ) effective area including fuselage↗
Empty weight
43,735 lb (19,838 kg)↗
Gross weight
61,000 lb (27,669 kg)↗
Max takeoff weight
74,350 lb (33,725 kg)↗
Powerplant
2 × General Electric F110 -GE-400 afterburning turbofans , 16,333 lbf (72.65 kN) thrust each dry, 26,950 lbf (119.9 kN) with afterburner↗
Maximum speed
Mach 2.34, 1,544 mph (1,342 kn; 2,485 km/h) at 40,000 ft (12,190 m) Mach 1.2, 794 kn (914 mph; 1,470 km/h) at sea level↗
Cruise speed
420 kn (480 mph, 780 km/h)↗

AirframeDB-তে এই বিমান সম্পর্কে আরও জানুন

A preserved Tomcat carries a specific service history

The National Naval Aviation Museum identifies its displayed F-14D with a combat sortie from USS Theodore Roosevelt on 8 February 2006, its 224th. The museum’s airframe history gives the preserved aircraft a connection to the final period of U.S. Navy Tomcat operations.

A demanding cockpit depends on people on the ground

Erie remembered the Tomcat as an aircraft that demanded attention to the stick and throttles, particularly during landing. Flying it also meant working closely with the radar intercept officer behind him. His affection for the aircraft included respect for the effort required from both seats, rather than treating the pilot as the whole crew.

One of his favourite maintenance memories concerned a young sailor who had just arrived after a long journey. A persistent fault had resisted previous attempts to fix it, but the newcomer offered to investigate and found a hidden connector problem. Erie’s recollection gives that practical success as much personality as the flying.

A first cockpit visit becomes a career ambition

Roustaie first encountered the Tomcat during his training years in the United States. A chance to look inside its cockpit left a strong impression: it seemed roomy and inviting, and he hoped he would eventually fly it. Returning to Iran and flying the F-4E did not displace that ambition.

When he finally reached the F-14’s front seat, the view became one of its strongest attractions. He compared it with the more restrictive feeling he remembered in the Phantom, where looking around could mean moving his helmet against the canopy. He also liked the arrangement of the controls and the cockpit environment.

A familiar cockpit still demands an alert crew

Mazandarani appreciated the Tomcat’s accessible controls and outward view, comparing the cockpit favourably with the F-5 he had flown earlier. Yet his interview also describes a moment when a familiar aircraft and airfield did not prevent a dangerous loss of awareness. The contrast is part of his own recollection of long operational nights.

Returning to Isfahan in the early morning, he saw another Tomcat in an inverted attitude near the airfield. A calm radio call prompted the other pilot to level the aircraft. Mazandarani connected the episode with fatigue and the need to keep watching what was happening around the crew. The story conveys his concern for a colleague without treating his later explanation as an independently established accident finding.

প্রকাশ্য সূত্র 11
  1. Grumman F-14 TomcatResearch background · Wikipedia revision 1374360313 · retrieved 2026-09-12
  2. Grumman F-14 POH
  3. X-Plane 12 Desktop Manual
  4. X-Plane aircraft and avionics manuals
  5. An interview with Tomcat pilot Richard Erie27 November 2022
  6. Flying and fighting in the F-14: Mostafa Roustaie27 February 2020
  7. Interview with F-14 pilot Fereydoun Mazandarani7 April 2020
  8. F-14D TomcatMuseum airframe history · retrieved September 2026
  9. ICAO Doc 8643 — aircraft type designatorsPublic search data retrieved 2026-09-14; authority update 2026-09-03
  10. F-14A/B Tomcat exact product reviewProduct listing captured 2026-09-24; edition scope from the reviewed catalogue
  11. F-14 TomcatProduct listing captured 2026-09-24; edition scope from the reviewed catalogue

কিভাবে প্রোফাইল মডেল এটি

Grumman F-14 Tomcat

Free + Pro
X-Plane 12

The Tomcat was developed for the US Navy after the F-111B programme ended. Twin engines, widely spaced tails and variable-sweep wings supported fleet defence and, later, strike missions.

This starting point selects Grumman F-14 Tomcat. Its aircraft-level settings do not select a particular developer’s custom systems.

Artificial feel supplies centering around powered primary controls. Spring resistance builds with the selected airspeed response. A separate aerodynamic term adds speed-dependent control load.

Documented pitch/lateral trim shifts stick neutral; the profile’s powered-trim option represents that mechanism. Valid trim provides the configured pressure relief. Autopilot following is off.

Controls and trim

The F-14 uses powered stabilators and spoilers with artificial feel. Heatblur’s A/B reference describes pitch and lateral trim shifting stick neutral. DLC, wing sweep and automatic slats/flaps are separate functions; MSFS documentation also identifies systems omitted from that rendition.

F-14A/B TomcatF-14A/B underlying flight controls and trim; DCS differences must be excludedUser GuideIndiaFoxtEcho F-14 Tomcat Microsoft Flight Simulator The Grumman F-14 Tomcat Price $53.33 AUDGrumman F-14 POH

About the values

The gains are normalized profile settings. They describe the chosen effect balance; hand force depends on the device and its output limits. IAS references are tuning values rather than operating limits. Physical acceptance of this revision remains pending.

মাস্টার গেইন নিয়ন্ত্রণ সিস্টেম

Master gain85%

ডিভাইস ক্যাপ-এর আগে মডেল তৈরি করা সবকিছুর জন্য সর্বশেষ সম্পূর্ণ আউটপুট স্কেল প্রয়োগ করা হয়।

আরো: সবকিছু (স্প্রিং, লোড, প্রভাব) একসাথে শক্তিশালী হয়।

কম: সবকিছু একসাথে নরম হয়ে যায়।

এখানে কেন: Scales overall profile strength while preserving effect balance, subject to device and output limits.

বল

Spring strength80%

বেস কেন্দ্রে ফেরানো বল যা স্টিক-কে কেন্দ্রে ফিরিয়ে আনে। প্রত্যেকটি বল এর ওপর স্ট্যাক করা হয়। খুবই কম হলে স্টিক স্বাভাবিক উড়োজাহাজের মত স্থির মনে হয়; খুবই বেশি হলে আপনার হাতের সাথে লড়াই করে এবং উপরের ছোট স্তরগুলোকে আড়াল করে।

আরো: আরও দৃঢ় কেন্দ্রমুখী বল, যা সব সময় আপনার হাতের নড়াচড়ায় বাধা দেয়।

কম: একটি লিম্পার স্টিক যা শুধুমাত্র বায়ুগতীয় লোডের উপর নির্ভর করে।

এখানে কেন: Artificial feel supplies centering around powered primary controls. The baseline spring is 0.8. Its low-speed blend reaches baseline strength at 90 KIAS.

F-14A/B TomcatF-14A/B underlying flight controls and trim; DCS differences must be excludedUser GuideIndiaFoxtEcho F-14 Tomcat Microsoft Flight Simulator The Grumman F-14 Tomcat Price $53.33 AUDGrumman F-14 POH
Spring deadband4%

কেন্দ্রের চারপাশে একটি ছোট নিরপেক্ষ অঞ্চল যেখানে স্প্রিং নিরব থাকে, তাই অস্থায়ী অবস্থায় ক্ষুদ্র নড়াচড়া শব্দ করে না। প্রশস্ত হলে তা আরও শান্ত হবে কিন্তু আরামদায়ক; সংকীর্ণ হলে তা আরও নির্ভুল হবে কিন্তু কেন্দ্রের চারদিকে ঝাঁপিয়ে পড়তে পারে।

আরো: একটু শান্ত কিন্তু আরো বেশি মুক্ত খেলার সাথে উন্মুক্ত কেন্দ্র।

কম: একটি সংকীর্ণ কেন্দ্র যে বিশ্রাম সময় কথা বলতে পারে.

এখানে কেন: Sets travel around the centre before the baseline spring resists. Smaller values engage it sooner.

Overall aerodynamic load25%

উভয় অক্ষ লোডের উপর একটি মাস্টার স্কেল, তাদের স্বাধীন ভারসাম্য প্রয়োগের পূর্বে প্রয়োগ করা হয়। প্রোফাইল সাধারণত এটিকে একা ছেড়ে দেয় এবং এর পরিবর্তে দুইটি অক্ষ লোড টুইন করে।

আরো: উভয় অক্ষ লোড করা কঠিন।

কম: উভয় অক্ষ একসাথে আলোকিত হয়।

এখানে কেন: The aerodynamic-load gain is 0.25 with an indicated-speed reference of 300 KIAS. The hydraulic-load factor of 0.35 scales that modeled term; it is a selected artificial-feel approximation.

Airspeed blendingTrue

কম গতির স্প্রিং সংযোগ উইন্ডো সক্রিয় করে (উপরে knots শুরু/পূর্ণ)। নিষ্ক্রিয় হলে, স্প্রিং সব ধরনের গতিতেই একই থাকে।

এখানে কেন: Allows baseline spring strength to rise with indicated airspeed where the control law permits it.

Low-speed spring floor55%

স্প্রিং-এর কতটুকু অস্তিত্ব আছে, যখন বায়ুগতি কোন বায়ুগতীয় বা বল তৈরি করতে পারে না। উচ্চ তলায় পার্ক করা স্টিক-কে দৃঢ় রাখা হয়; নিম্ন তলায় পার্ককৃত হালকা বিমানের মত পাতলা, কেবল-সলাকের অনুভূতি পাওয়া যায়।

আরো: পার্কিং এবং ট্যাক্সি চালানোর সময় আরো দৃঢ় স্টিক।

কম: একটি ফ্লপি পার্ক করা স্টিক যা শুধুমাত্র বায়ুগতি দ্বারা জাগ্রত হয়।

এখানে কেন: Sets low-speed spring strength as a fraction of baseline when blending is enabled. One keeps full strength.

Spring engagement start20 kt

বায়ুগতি যেখানে স্প্রিং তার কম গতির ন্যূনতম সীমা থেকে পূর্ণ শক্তির দিকে উঠতে শুরু করে: রোল-এ উড্ডয়নের সময় নিয়ন্ত্রণ "জীবিত হয়ে ওঠে"।

এখানে কেন: Sets the IAS where the low-speed spring blend starts rising. This is a feel threshold, not a flight limit.

Spring engagement full90 kt

বায়ুগতি যেখানে স্প্রিং সম্পূর্ণ শক্তি অর্জন করে। শুরু এবং এই বিন্দুর মধ্যে, কেন্দ্রে ফেরানো নিয়ন্ত্রণের উপর বায়ু প্রবাহ বৃদ্ধির সাথে সাথে ক্রমবর্ধমানভাবে দৃঢ় হয়ে ওঠে।

এখানে কেন: Sets the IAS where the low-speed blend reaches baseline strength; high-speed stiffening also uses it.

বল টিউনিংয়ের গতি300

নির্দেশিত বায়ুগতি যেখানে বায়ুগতীয় লোড তার নকশাকৃত সম্পূর্ণ স্তরে পৌঁছে যায়। এটি সমগ্র লোড বক্ররেখাকে বিমানের প্রকৃত গতি সীমার সাথে সংযুক্ত করে: একটি 172 লোড করা হয় 110 knots দ্বারা, একটি জেট অনেক পরে।

আরো: লোড পরে আসে; স্টিক উচ্চতর গতি পর্যন্ত হালকা থাকে।

কম: লোড দ্রুত পৌঁছায় এবং ক্রুজ ভারী মনে হয়।

এখানে কেন: Sets the IAS reference for aerodynamic loading. It is an estimate, not published cruise TAS or a flight limit.

Centre firmness vs speed0%

কেন্দ্রে ফেরানো নিজেই কি পরিমাণ দ্রুতগতির সাথে সংকুচিত হয়, বিচ্যুতি লোডের উপরে। শূণ্য হলে কেন্দ্রস্থল স্থির মনে হয়; বেশি হলে স্টিক কেন্দ্রস্থল ক্রুজে কঠিন হয়ে যায় এবং নকশায় পাতলা হয়ে যায়।

আরো: একটি কেন্দ্র যেটি দ্রুতগতিতে যাওয়ার সাথে সাথে দৃশ্যমানভাবে কঠিন হয়ে যায়।

কম: প্রতিটি গতিতেই স্থির কেন্দ্র অনুভূতি।

এখানে কেন: The high-speed spring-stiffening gain is 0. No additional speed-driven stiffening is added; this does not disable independent aerodynamic loading.

Centre stiffening cap5

গতি-চালিত কেন্দ্র স্থিরকরণের উপরের সীমা, তাই খুব দ্রুত উড়োজাহাজ সীমা ছাড়া স্প্রিং উড়িয়ে দিতে পারে না।

আরো: উচ্চ গতিতে আরো মোট স্থিরতা অনুমোদিত.

কম: ক্ল্যাম্পগুলো দ্রুত খুলে ফেলো।

এখানে কেন: Limits the squared airspeed ratio used for high-speed spring stiffening; it is not a device-force cap.

Aileron load65%

এইলারন, বিচ্যুতি এবং বায়ুগতি থেকে স্থায়ী রোল লোড, পিচ এর স্বাধীনভাবে ভারসাম্যপূর্ণ। এলিভেটর লোডের সাথে এটি নিয়ন্ত্রণ-সমঞ্জস্য অনুপাত নির্ধারণ করে যা পর্যালোচনাকারীরা আলোচনা করে।

আরো: ভারী রোল বল।

কম: হালকা, দ্রুত অনুভূতি এয়াররোন.

এখানে কেন: Roll and pitch aerodynamic scales are 0.65 and 0.65, respectively. They set the aerodynamic axis balance. No custom spring-travel curve is enabled.

Elevator load65%

এলিভেটরের বিচ্যুতি ও বায়ুগতির কারণে তৈরি অবিরাম পিচ লোড, যা রোল থেকে স্বাধীনভাবে সামঞ্জস্য করা হয়। কোনও বিমানের পিচে ভারী অনুভূতি নিয়ন্ত্রণের এটি প্রধান উপায়। এতে এলারন, স্প্রিং, ট্রিম বা বাফেটিংয়ের বল বদলায় না।

আরো: দ্রুতগতিতে ভারী পিচ বল চালানো।

কম: একটি হালকা এলিভেটর যা ধরে রাখতে কম পেশী দরকার।

এখানে কেন: Scales pitch aerodynamic loading; pitch spring travel and trim responses are separate settings.

Max output force55%

প্রতিটি স্থির পিচ অথবা রোল বল এর উপর ডিভাইসে পৌঁছানোর পূর্বে একটি ক্যাপ, শক্তিশালী ম্যানুয়ালগুলিতে হার্ডওয়্যারকে স্লিপিং বা সাটিউরেট করার থেকে রক্ষা করে।

আরো: ক্লিপ করার পূর্বে শক্তিশালী পিক স্থির বল।

কম: একটি নরম ছাদ; কঠিন ম্যানুয়াল দ্রুত flatten out.

এখানে কেন: Caps directed-force output. Native spring effects and device limits remain separate.

ট্রিম

Trim relief (elevator)30%

এলিভেটর ট্রিম কতটা শক্তিশালীভাবে পিচ বল-কে সরিয়ে দেয় এবং যেখানে স্টিক অবস্থিত সেখানে স্থানান্তর করে। 100%-এ, একটি সঠিক ট্রিম করা বিমানের কোন চাপ-এর প্রয়োজন নেই, বাস্তব উড়োজাহাজের ট্রিম-away-the-load workflow।

আরো: ট্রিম ধরে রাখা পিচ বল-এর অধিকাংশ অপসারণ করে; 100% পূর্ণ হলে ট্রিম এটি শূণ্য করে।

কম: ট্রিম করার পরেও আপনাকে বল ধরে রাখতে হয়।

এখানে কেন: Documented pitch/lateral trim shifts stick neutral; the profile’s powered-trim option represents that mechanism. Pitch authority 0.3 relieves permitted loading; hydraulic centre movement is off. Roll authority is 0.09.

F-14A/B TomcatF-14A/B underlying flight controls and trim; DCS differences must be excludedUser GuideIndiaFoxtEcho F-14 Tomcat Microsoft Flight Simulator The Grumman F-14 Tomcat Price $53.33 AUDGrumman F-14 POH
Trim relief (aileron)9%

রোল ট্রিমের জন্য একইভাবে বল কমানো। বেশিরভাগ GA বিমানে বাস্তব এলারন ট্রিম নেই, তাই এটি শূন্য থাকে; রোল ট্রিম আছে এমন বিমানে উপযুক্ত মান দেওয়া হয়।

আরো: রোল ট্রিম আরো রোল বল সরিয়ে ফেলে।

কম: রোল ট্রিম কম করে।

এখানে কেন: Scales supported roll-trim relief and permitted centre movement. Zero removes roll response.

প্রভাব গেইন · ভূমি

Runway rumble40%

চাকার গতি এবং পৃষ্ঠের ধরন থেকে রোলিং পৃষ্ঠের কম্পন: গিয়ার-এর অধীনে পাথর, ঘাস অথবা গর্ত।

আরো: স্টিক-এর মাধ্যমে উচ্চতর পৃষ্ঠের টেক্সচার।

কম: ট্যাক্সি চালানো সহজ হবে।

এখানে কেন: Sets rolling texture strength, modified by speed, surface and undercarriage configuration.

Gear bumps32%

বিস্তৃত সংযোগস্থল, ছিদ্র এবং মসৃণ পৃষ্ঠ থেকে সংক্ষিপ্ত বিচ্ছিন্ন ঝাঁকুনি, যা অবিরাম কম্পন-কে চিহ্নিত করে।

আরো: জয়েন্ট এবং রুট থেকে আরও জোরালো আঘাত।

কম: নরম মাটির বিবরণ.

এখানে কেন: Sets gear-bump texture during ground motion, separate from touchdown impact.

প্রভাব গেইন · এয়ারফ্রেম

Stall buffet30%

এয়ারফ্রেম স্টল-এর কাছে এসে ঝাঁপিয়ে পড়ে এবং যখন স্টল সতর্কবার্তা সক্রিয় থাকে: এই ডানাটি কতটা জোরে ঘোষণা করে যে এটি অসন্তুষ্ট। তীক্ষ্ণ বিরতিযুক্ত ধরনগুলি বাফেটিং-এ পরিণত হয় এবং হর্নটিকে সতর্কবার্তা বহন করতে দেয়।

আরো: স্টল-এর আগে এক জোরালো ঝাঁকুনি।

কম: একটি শান্ত ডানা; হর্ন সতর্কতা বহন করে।

এখানে কেন: Sets stall-buffet strength. Zero removes the cue without changing simulator stalls or warnings.

Mach buffet0%

ট্রান্সসনিক বাফেটিং Mach সীমার কাছে এসে পৌঁছেছে। এমএমও-এর নিকটবর্তী জেটের জন্য অর্থবহ, পিস্টন এবং টারবাইনপ্রোপের জন্য শূন্য যা কখনোই সেখানে পৌঁছায় না।

আরো: Mach সীমার কাছাকাছি শক্তিশালী ট্রান্সসনিক বাফেটিং।

কম: একটি সুষম উচ্চ-Mach সফর.

এখানে কেন: Sets high-Mach buffet strength; onset and full-strength thresholds are separate.

Flap buffet14%

ফ্ল্যাপ এর সাথে কম-ফ্রিকোয়েন্সি এয়ারফ্রেম কম্পন বায়ুপ্রবাহের মধ্যে প্রসারিত হয়, গতি উইন্ডোতে যেখানে তারা আসলে বায়ুকে কাজ করে।

আরো: ফ্ল্যাপ বাতাসে কাজ করার সাথে একটি কঠিন সার্ভিস।

কম: সুষম প্রক্রিয়া ফ্ল্যাপ।

এখানে কেন: Sets flap buffet at the configured position and speed gates. Flap movement texture is separate.

Gear buffet10%

এয়ারফ্রেম এয়ারস্ট্রিম-এ ঝুলন্ত গিয়ার থেকে ড্রাম বাজানো। শূন্য নির্দিষ্ট-গিয়ার ধরনের জন্য, যেখানে এয়ারফ্রেম কখনোই আকৃতি পরিবর্তন করে না।

আরো: চাকার সাথে আরো ড্রাম বাজানো।

কম: পরিষ্কার গিয়ার-ডাউন ফ্লাইট.

এখানে কেন: Sets gear aerodynamic buffet; movement and ground-contact cues are separate.

Stick shaker90%

বিমানের নিজস্ব স্টল সতর্কতা ব্যবস্থা থেকে চালু হওয়া বিশেষ স্টল স্টিক-শেকারের কম্পন। বাস্তবে শেকার আছে এমন বিমানেই মান দেওয়া হয়; অন্যগুলি বায়ুগত বাফেটিং ও সতর্কতার হর্নের ওপর নির্ভর করে।

আরো: আরো কঠিন স্টিক-Shaker buzz।

কম: একটি সুক্ষ্ম শেকার.

এখানে কেন: Sets triggered shaker strength; inactive while the shaker feature is disabled.

এফেক্ট গেইন · ইঞ্জিন, যান্ত্রিক এবং ড্র্যাগ

Touchdown thump90%

যখন চাকাগুলো রানওয়েতে ধাক্কা দেয়, তখন এক ধাক্কায় উড়োজাহাজটি নিচে নেমে যায়: একটি গরম চুম্বন, একটি দৃঢ় আবির্ভাব।

আরো: টাচডাউনে কঠিন কিক.

কম: নরম আবির্ভাব.

এখানে কেন: Sets landing-impact strength; landing telemetry and response shape determine the pulse.

Reverse rumble50%

রিভার্স থ্রাস্ট অথবা beta-রেঞ্জের প্রপস কাজ করার সময় ভ্রমণের প্রদর্শন। বিপরীতমুখী না হওয়া ধরনের ক্ষেত্রে শূণ্য।

আরো: বিপরীত দিক থেকে আরো কঠিন ভাবে বেরিয়ে আসবে।

কম: শান্ত বিপরীত.

এখানে কেন: Sets reverse-thrust vibration with valid reverser and engine conditions. Zero removes the cue.

Engine rumble6%

RPM-এর পর নিরবচ্ছিন্ন শক্তি উৎপাদনকারী যন্ত্রের কম্পন, অকার্যকর এবং সম্পূর্ণ শক্তির মধ্যে, সবসময় উপস্থিত স্মরণ করিয়ে দেয় যে সামনে কিছু জ্বালানি পুড়ে যাচ্ছে।

আরো: স্টিক এর মাধ্যমে আরো ইঞ্জিন।

কম: একটি নিরব শক্তি উৎপাদন কেন্দ্র.

এখানে কেন: Sets estimated engine vibration using configured telemetry and response, not measured cockpit vibration.

Flap motion12%

শুধুমাত্র সিম যখন ফ্ল্যাপ পৃষ্ঠ প্রকৃতপক্ষে ভ্রমণ করছে তা রিপোর্ট করে তখনই অবিরাম কম্পন। এটি বাস্তব অ্যাক্টর নড়াচড়া এবং ব্যর্থতা অনুসরণ করে, একটি অনুমানিত টাইমার নয়।

আরো: ফ্ল্যাপ পৃষ্ঠের ভ্রমণের সময় আরও বেশি কম্পন।

কম: নিরব ফ্ল্যাপ চলছে।

এখানে কেন: Sets texture from observed flap movement; a command without movement does not establish the cue.

অটোপাইলট অনুসরণ

AP follow authority10%

অটোপাইলট কমান্ড দ্বারা স্টিক কে কত দূর সরানো যাবে। MSFS-এ ছোট করে রাখা হয়েছে, যেখানে একটি সরানো অক্ষ পাইলট ইনপুট হিসেবে পড়তে পারে; শূন্য অনুসরণ করা সম্পূর্ণ নিষ্ক্রিয় করে।

আরো: অটোপাইলট দৃশ্যমানভাবে আপনার স্টিক-কে আরো এগিয়ে নিয়ে যায়।

কম: খুবই অদৃশ্য অনুসরণ.

এখানে কেন: Sets admitted AP-follow gain, not a percentage of travel. Runtime ownership and input limits still apply.

Stick feel

StickFeel · Trim feel enabledTrue

Whether this feature is active in this profile.

এখানে কেন: Retained for compatibility and group membership. Trim relief, rather than this flag, controls centre movement.

StickFeel · Trim relief enabledTrue

Whether this feature is active in this profile.

এখানে কেন: Allows trim relief with supported control law and valid telemetry. Axis authorities set its amount.

StickFeel · Force trim enabledFalse

Whether this feature is active in this profile.

এখানে কেন: Enables local force trim, separate from aircraft-owned trim and add-on integration qualification.

StickFeel · G load enabledTrue

Whether this feature is active in this profile.

এখানে কেন: Allows load-factor changes to modify permitted spring laws. Passive fly-by-wire feel can suppress it.

StickFeel · Rate damping enabledTrue

Whether this feature is active in this profile.

এখানে কেন: Enables rate damping with the configured coefficients and control law.

Autopilot

Autopilot · Follow enabledFalse

Whether this feature is active in this profile.

এখানে কেন: Autopilot following is off; the configured spring and load retain the hardware feel.

Autopilot · Neutral hold enabledFalse

Whether this feature is active in this profile.

এখানে কেন: Permits centering hold during a supported AP state, separate from following a moving target.

Autopilot · Neutral hold strength0.6

এখানে কেন: Sets admitted AP neutral-hold strength; inactive while neutral hold is disabled.

Aero

Aero · EnabledTrue

Whether this feature is active in this profile.

এখানে কেন: Enables aerodynamic cues; each still needs nonzero strength and its simulator conditions.

Aero · Max flap index3

Where this effect reaches full strength (or has fully faded, for washouts).

আরো: a more gradual build to a later peak.

কম: a quicker build.

এখানে কেন: Sets the final flap index for detent normalization. UP plus three detents uses maximum index3.

Aero · Min flap index2

Where this effect begins fading in.

আরো: the effect begins later.

কম: it begins earlier.

এখানে কেন: Sets the first flap detent that admits buffet; this is a handle index, not degrees.

Aero · Shaker enabledTrue

Whether this feature is active in this profile.

এখানে কেন: Permits shaker at supported warning conditions; the switch does not establish aircraft equipment.

Ground

Ground · EnabledTrue

Whether this feature is active in this profile.

এখানে কেন: Enables ground effects; each still needs its own strength and contact or motion telemetry.

Engine

Engine · EnabledTrue

Whether this feature is active in this profile.

এখানে কেন: Enables engine cues with nonzero settings and valid running-engine telemetry.

Mechanical

Mechanical · EnabledTrue

Whether this feature is active in this profile.

এখানে কেন: Enables accessory cues with configured strengths and observed accessory movement.

Mechanical · Gain0.12

The strength of this effect.

আরো: a stronger effect.

কম: a weaker one.

এখানে কেন: Sets texture from observed gear movement, separate from aerodynamic and touchdown effects.

প্রোফাইলের সব সেটিং
আনুমানিক প্রোফাইল সেটিংস
প্যারামিটারমানকী নিয়ন্ত্রণ করে এবং কেন
Spring strength0.8 Artificial feel supplies centering around powered primary controls. The baseline spring is 0.8. Its low-speed blend reaches baseline strength at 90 KIAS.
Spring deadband0.035 Sets travel around the centre before the baseline spring resists. Smaller values engage it sooner.
Force gain0.25 The aerodynamic-load gain is 0.25 with an indicated-speed reference of 300 KIAS. The hydraulic-load factor of 0.35 scales that modeled term; it is a selected artificial-feel approximation.
Master gain0.85 Scales overall profile strength while preserving effect balance, subject to device and output limits.
Dynamic-pressure blendTrue Allows baseline spring strength to rise with indicated airspeed where the control law permits it.
Minimum spring factor0.55 Sets low-speed spring strength as a fraction of baseline when blending is enabled. One keeps full strength.
Spring wake-up speed20 ktSets the IAS where the low-speed spring blend starts rising. This is a feel threshold, not a flight limit.
Spring full-strength speed90 ktSets the IAS where the low-speed blend reaches baseline strength; high-speed stiffening also uses it.
বল টিউনিংয়ের গতি300.0 ktSets the IAS reference for aerodynamic loading. It is an estimate, not published cruise TAS or a flight limit.
Airspeed spring stiffening0 The high-speed spring-stiffening gain is 0. No additional speed-driven stiffening is added; this does not disable independent aerodynamic loading.
Airspeed stiffening cap5 Limits the squared airspeed ratio used for high-speed spring stiffening; it is not a device-force cap.
Aileron force scale0.65 Roll and pitch aerodynamic scales are 0.65 and 0.65, respectively. They set the aerodynamic axis balance. No custom spring-travel curve is enabled.
Elevator force scale0.65 Scales pitch aerodynamic loading; pitch spring travel and trim responses are separate settings.
Maximum output force0.55 Caps directed-force output. Native spring effects and device limits remain separate.
StickFeel · Trim feel enabledTrue Retained for compatibility and group membership. Trim relief, rather than this flag, controls centre movement.
StickFeel · Trim relief enabledTrue Allows trim relief with supported control law and valid telemetry. Axis authorities set its amount.
StickFeel · Elevator authority0.3 Documented pitch/lateral trim shifts stick neutral; the profile’s powered-trim option represents that mechanism. Pitch authority 0.3 relieves permitted loading; hydraulic centre movement is off. Roll authority is 0.09.
StickFeel · Aileron authority0.09 Scales supported roll-trim relief and permitted centre movement. Zero removes roll response.
StickFeel · Force trim enabledFalse Enables local force trim, separate from aircraft-owned trim and add-on integration qualification.
StickFeel · G load enabledTrue Allows load-factor changes to modify permitted spring laws. Passive fly-by-wire feel can suppress it.
StickFeel · Rate damping enabledTrue Enables rate damping with the configured coefficients and control law.
Autopilot · Follow enabledFalse Autopilot following is off; the configured spring and load retain the hardware feel.
Autopilot · Follow authority0.1 Sets admitted AP-follow gain, not a percentage of travel. Runtime ownership and input limits still apply.
Autopilot · Neutral hold enabledFalse Permits centering hold during a supported AP state, separate from following a moving target.
Autopilot · Neutral hold strength0.6 Sets admitted AP neutral-hold strength; inactive while neutral hold is disabled.
Aero · EnabledTrue Enables aerodynamic cues; each still needs nonzero strength and its simulator conditions.
Aero · Gain0.3 Sets stall-buffet strength. Zero removes the cue without changing simulator stalls or warnings.
Aero · Gain0 Sets high-Mach buffet strength; onset and full-strength thresholds are separate.
Aero · Gain0.14 Sets flap buffet at the configured position and speed gates. Flap movement texture is separate.
Aero · Max flap index3 Sets the final flap index for detent normalization. UP plus three detents uses maximum index3.
Aero · Min flap index2 Sets the first flap detent that admits buffet; this is a handle index, not degrees.
Aero · Gain0.1 Sets gear aerodynamic buffet; movement and ground-contact cues are separate.
Aero · Shaker enabledTrue Permits shaker at supported warning conditions; the switch does not establish aircraft equipment.
Aero · Amplitude0.9 Sets triggered shaker strength; inactive while the shaker feature is disabled.
Ground · EnabledTrue Enables ground effects; each still needs its own strength and contact or motion telemetry.
Ground · Gain0.4 Sets rolling texture strength, modified by speed, surface and undercarriage configuration.
Ground · Gain0.32 Sets gear-bump texture during ground motion, separate from touchdown impact.
Ground · Gain0.9 Sets landing-impact strength; landing telemetry and response shape determine the pulse.
Ground · Gain0.5 Sets reverse-thrust vibration with valid reverser and engine conditions. Zero removes the cue.
Engine · EnabledTrue Enables engine cues with nonzero settings and valid running-engine telemetry.
Engine · Gain0.06 Sets estimated engine vibration using configured telemetry and response, not measured cockpit vibration.
Mechanical · EnabledTrue Enables accessory cues with configured strengths and observed accessory movement.
Mechanical · Gain0.12 Sets texture from observed flap movement; a command without movement does not establish the cue.
Mechanical · Gain0.12 Sets texture from observed gear movement, separate from aerodynamic and touchdown effects.
প্রকাশ্য সূত্র 14
  1. Grumman F-14 TomcatResearch background · Wikipedia revision 1374360313 · retrieved 2026-09-12
  2. F-14A/B TomcatIncluded models and custom systems; Exact product features and simulator requirementsProduct listing captured 2026-09-24; edition scope from the reviewed catalogue
  3. F-14A/B underlying flight controls and trim; DCS differences must be excludedTrim section; Heatblur underlying F14A/B flight controls and trim; separate simulator implementation
  4. User GuidePDF pages 2-6,8-10,15,17-21,23
  5. IndiaFoxtEcho F-14 Tomcat Microsoft Flight Simulator The Grumman F-14 Tomcat Price $53.33 AUDNamed product and Supported Simulators
  6. Grumman F-14 POHGrumman F-14 Tomcat
  7. X-Plane 12 Desktop Manual
  8. X-Plane aircraft and avionics manuals
  9. An interview with Tomcat pilot Richard Erie27 November 2022
  10. Flying and fighting in the F-14: Mostafa Roustaie27 February 2020
  11. Interview with F-14 pilot Fereydoun Mazandarani7 April 2020
  12. F-14D TomcatMuseum airframe history · retrieved September 2026
  13. ICAO Doc 8643 — aircraft type designatorsPublic search data retrieved 2026-09-14; authority update 2026-09-03
  14. F-14 TomcatProduct listing captured 2026-09-24; edition scope from the reviewed catalogue

সম্প্রদায় এবং সংশোধন

আপনার সময় যদি বলে যে এই পৃষ্ঠায় কিছু ভুল হয়েছে, তাহলে এখানে সংশোধন করুন।

পাইলট সংশোধন

এই উড়োজাহাজ উড়ান? এই পৃষ্ঠাটি সংশোধন করুন।

এই পৃষ্ঠাটি উদ্ধৃত রেফারেন্স থেকে তৈরি করা হয়েছে, এবং টাইপের রিয়েল টাইম একটি উদ্ধৃতি বীট করে। ভুল পড়া দাবিটি উদ্ধৃত করুন এবং প্রকৃত বিমানটি কী করে তা আমাদের বলুন। সংশোধন পর্যালোচনার জন্য রক্ষণাবেক্ষণকারীর কাছে যান এবং এই গবেষণার পরবর্তী সংশোধনটি খাওয়ান।

হ্যাঙ্গার কথা

কমিউনিটি ফোরামে Grumman F-14 Tomcat উড়তে এবং টিউন করার বিষয়ে খোলা কথোপকথন। উপরের সংশোধনগুলি ব্যক্তিগতভাবে রক্ষণাবেক্ষণকারীর কাছে যায়; হ্যাঙ্গার আলোচনা সর্বজনীন।

Grumman F-14 Tomcat-এর জন্য এখনও কোনও হ্যাঙ্গার টক নেই। প্রথম হও।

সম্প্রদায়

এই বিমানের জন্য কমিউনিটি প্রোফাইল

এই বিমানের জন্য এখনও কোন সম্প্রদায় প্রোফাইল নেই। এটা আপনার উপায় টিউন? একটি প্রোফাইল শেয়ার করুন এবং এটি এখানে প্রদর্শিত হবে।