Development milestones
Designer: Ted R. Smith
First flight: 1967
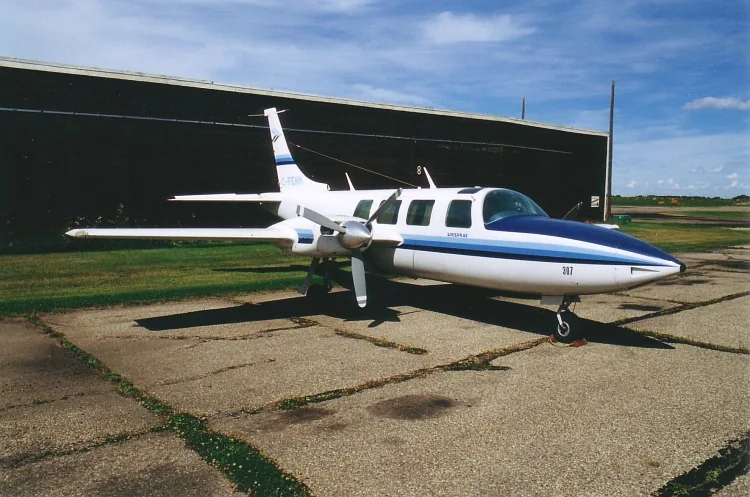 No machine-readable author provided. CommonsHelper2 Bot assumed (based on copyright claims). · Public domain · Piper Aerostar — real-aircraft reference photograph.
The Aerostar began as a Ted Smith design for executive travel and light transport. Piper acquired the design in 1978 and continued production as the PA-60. That change of ownership explains the different manufacturer names found in references. The simulator entry represents the Aerostar 600; the specification tables identify the family models they describe.
Piper Aerostar · Specifications (700P) · real aircraft; source units retained
Подробнее об этом воздушном судне на AirframeDB
Designer: Ted R. Smith
First flight: 1967
The A2A manual describes primary controls operated through push-pull tubes and bellcranks. Electric motors move the elevator and rudder trim tabs, with their positions shown in the cockpit. Its Fowler flaps use hydraulic actuators. This description is scoped to the 600 represented in the manual.
Gentile chose a normally aspirated Aerostar when buying his own aircraft, preferring its combination of solidity and responsiveness to the balance he perceived in the turbocharged version. He operated it for several years, and that direct experience later helped motivate A2A's choice to develop a simulated 600. His introduction is both an owner's recollection and a developer's explanation of a product in which he has a commercial interest.
One experience was especially memorable. A landing-gear failure during a test flight forced him and his son Jake to make a controlled gear-up landing. Gentile describes the aircraft settling onto its belly and both occupants getting out without incident. He presents the event as something that encouraged further curiosity and learning, alongside his continuing appreciation of the design.
Durden flew Stan Musick's modified 1977 Aerostar 601P with its owner in the right seat. The departure required him to think ahead as acceleration quickly carried the aircraft into a climb through low cloud. As speed increased, the initially unfamiliar control feel developed into a responsive, stable aeroplane. Once trimmed, it held its condition while he attended to radio calls and the climb toward 23,000 feet.
He later enjoyed steep turns, appreciated the extra overhead windows and found the cabin more spacious than its external appearance suggested. Musick had removed one middle-row seat to suit family travel. Durden also evaluated how a new Garmin display worked with the older autopilot, then returned to hand-flying for the enjoyment of it. The landing completed an enthusiastic report that still recognised the need to understand the aircraft's systems and maintain proficiency. This was a pressurised, turbocharged 601P with modifications, distinct from the normally aspirated 600 represented by A2A.
Cox traces his affection for the Aerostar to a 1975 flight with Jim Miller in Texas. The view past the nearby spinner, the long nose and the rapidly passing landscape became a distinctive part of the experience for him. Over the following decades, ferrying roughly a dozen 700-series aircraft around the world gave him repeated opportunities to appreciate their speed and control response. He still hoped eventually to own one himself.
His recollections include working with Jim Christy on a television flying segment and delivering the specially prepared Spirit of Kai Tak to Britain before its London-to-Sydney race. Those experiences concerned higher-powered, modified Aerostars rather than the original 600. Cox's enthusiasm also acknowledges the fuel consumed when using their full cruising capability. He enjoyed the way the aircraft looked, responded and carried him over long distances, even while his own aeroplane remained a Mooney.
The Aerostar began as a Ted Smith design for executive travel and light transport. Piper acquired the design in 1978 and continued production as the PA-60. That change of ownership explains the different manufacturer names found in references. This entry includes the Aerostar 600 simulation, while family specifications identify their particular model.
This starting point selects Aerostar 600. Its aircraft-level settings do not select a particular developer’s custom systems.
Spring resistance builds with the selected airspeed response. A separate aerodynamic term adds speed-dependent control load.
Valid trim provides the configured pressure relief. Autopilot following is enabled for supported control references.
A2A's Aerostar manual describes push-pull tubes and bellcranks operating the primary surfaces without control cables. Electric elevator and rudder trim tabs serve separate axes. Its custom Century IV autopilot can retain reduced-authority pitch-servo operation with autotrim disabled. The detailed hydraulic landing-gear description takes precedence over introductory shorthand; gear hydraulics do not establish powered primary controls.
The gains are normalized profile settings. They describe the chosen effect balance; hand force depends on the device and its output limits. IAS references are tuning values rather than operating limits. Physical acceptance of this revision remains pending.
Итоговый общий масштаб вывода, применяемый ко всему, что выдает модель, до ограничения устройства.
Больше: все (пружина, нагрузки, эффекты) одновременно усиливается.
Меньше: все одновременно становится мягче.
Почему так: Scales overall profile strength while preserving effect balance, subject to device and output limits.
Базовое центрирующее усилие, которое возвращает джойстик в центр. Все остальные усилия накладываются на него. Слишком низкое — и джойстик кажется вялым в обычном полете; слишком высокое — и он сопротивляется руке и заглушает более слабые эффекты, наложенные поверх.
Больше: более жесткое центрирование, постоянно сопротивляющееся руке.
Меньше: более вялый джойстик, опирающийся только на аэродинамическую нагрузку.
Почему так: Push-pull primary controls motivate aerodynamic yoke loading; the linkage construction does not supply an absolute hand-force calibration. The baseline spring is 0.74. Its low-speed blend reaches baseline strength at 90 KIAS.
Accu-Sim Aerostar 600 ManualAccu-Sim Aerostar 600Небольшая нейтральная зона вокруг центра, в которой пружина не действует, чтобы мелкие движения в покое не вызывали дребезга. Шире — спокойнее, но свободнее; уже — точнее, но джойстик может подергиваться около центра.
Больше: более спокойный, но более свободный центр с большим люфтом.
Меньше: более плотный центр, который может дребезжать в покое.
Почему так: Sets travel around the centre before the baseline spring resists. Smaller values engage it sooner.
Общий множитель для обеих постоянных нагрузок по осям, применяемый до их независимой балансировки. Обычно профили его не трогают и вместо этого настраивают нагрузки двух осей.
Больше: обе оси нагружаются сильнее.
Меньше: обе оси одновременно становятся легче.
Почему так: The aerodynamic-load gain is 0.8 with an indicated-speed reference of 185 KIAS. This supplies speed-dependent loading alongside the spring.
Включает окно нарастания пружины на малой скорости (начальная и полная скорость в узлах, см. выше). Если выключено, пружина постоянна на всех скоростях.
Почему так: Allows baseline spring strength to rise with indicated airspeed where the control law permits it.
Какая доля пружины сохраняется на стоянке, пока скорость еще не создала никакого аэродинамического усилия. Высокий минимум оставляет джойстик на стоянке упругим; низкий дает свободные ощущения провисших тросов, как у легкого самолета на стоянке.
Больше: более упругий джойстик на стоянке и при рулении.
Меньше: более свободно болтающийся джойстик на стоянке, который оживает только с ростом скорости.
Почему так: Sets low-speed spring strength as a fraction of baseline when blending is enabled. One keeps full strength.
Скорость, на которой пружина начинает расти от минимума на малой скорости к полной силе: органы управления «оживают» на разбеге.
Почему так: Sets the IAS where the low-speed spring blend starts rising. This is a feel threshold, not a flight limit.
Скорость, на которой пружина достигает полной силы. Между начальной скоростью и этой точкой центрирование постепенно становится жестче по мере усиления обтекания рулей.
Почему так: Sets the IAS where the low-speed blend reaches baseline strength; high-speed stiffening also uses it.
Приборная скорость, на которой аэродинамическая нагрузка достигает расчетного полного уровня. Она привязывает всю кривую нагрузки к реальному диапазону скоростей воздушного судна: у 172 нагрузка набирается к 110 узлам, у реактивного самолета — намного позже.
Больше: нагрузки приходят позже; джойстик остается легким до более высокой скорости.
Меньше: нагрузки приходят раньше, и в крейсерском полете управление тяжелее.
Почему так: Sets the IAS reference for aerodynamic loading. It is an estimate, not published cruise TAS or a flight limit.
Насколько само центрирование становится жестче со скоростью, в дополнение к нагрузкам от отклонения. Ноль сохраняет ощущения в центре постоянными; большее значение делает центр джойстика жестче в крейсерском полете и мягче при полете по кругу.
Больше: центр заметно становится жестче с ростом скорости.
Меньше: постоянные ощущения в центре на любой скорости.
Почему так: The high-speed spring-stiffening gain is 0.15. It strengthens the permitted spring response above 90 KIAS, with the squared-speed ratio capped at 5.
Верхний предел скоростного ужесточения центра, чтобы очень быстрый полет не мог затягивать пружину без ограничений.
Больше: на большой скорости допускается большее общее ужесточение.
Меньше: ужесточение ограничивается раньше.
Почему так: Limits the squared airspeed ratio used for high-speed spring stiffening; it is not a device-force cap.
Постоянная нагрузка по крену от отклонения элеронов и скорости, балансируемая независимо от тангажа. Вместе с нагрузкой руля высоты она задает соотношение усилий по осям (гармонию управления), о котором пишут обозреватели.
Больше: более тяжелые усилия по крену.
Меньше: более легкие элероны, которые кажутся более быстрыми.
Почему так: Roll and pitch aerodynamic scales are 0.72 and 1, respectively. They set the aerodynamic axis balance. No custom spring-travel curve is enabled.
Постоянная нагрузка по тангажу от отклонения руля высоты и скорости, балансируемая независимо от крена. Это главный регулятор тяжести тангажа у данного типа. Он не затрагивает усилия элеронов, пружины, триммера и бафтинга.
Больше: более тяжелые постоянные усилия по тангажу на скорости.
Меньше: более легкий руль высоты, который требует меньше сил для удержания.
Почему так: Scales pitch aerodynamic loading; pitch spring travel and trim responses are separate settings.
Ограничение каждого постоянного усилия по тангажу или крену до того, как оно дойдет до устройства; защищает оборудование от ударов и насыщения при энергичных маневрах.
Больше: более сильные пиковые постоянные усилия до срезания.
Меньше: более мягкий предел; при резких маневрах усилие раньше перестает расти.
Почему так: Caps directed-force output. Native spring effects and device limits remain separate.
Насколько сильно триммер руля высоты снимает удерживаемое усилие по тангажу и смещает положение, в котором устанавливается джойстик. При 100% правильно оттриммированное воздушное судно не требует удерживающего давления — как в реальном полете, где нагрузку снимают триммером.
Больше: триммер снимает большую часть удерживаемого усилия по тангажу; при 100% полное триммирование сводит его к нулю.
Меньше: даже после триммирования приходится удерживать усилие.
Почему так: Electric elevator trim supports pitch-load relief. The rudder trim tab is a yaw control and does not supply aileron relief. Pitch authority 0.3 provides load relief and permitted centre movement; roll authority is 0.
Accu-Sim Aerostar 600 ManualAccu-Sim Aerostar 600Такая же разгрузка для триммера крена. У большинства типов авиации общего назначения нет настоящего триммера элеронов, поэтому здесь остается ноль; типы с триммером крена получают соответствующее значение.
Больше: триммер крена снимает больше удерживаемого усилия по крену.
Меньше: триммер крена действует слабее.
Почему так: Scales supported roll-trim relief and permitted centre movement. Zero removes roll response.
Вибрация при качении по поверхности в зависимости от скорости колес и типа покрытия: асфальт, трава или гравий под шасси.
Больше: более выраженная фактура покрытия в джойстике.
Меньше: более плавное руление.
Почему так: Sets rolling texture strength, modified by speed, surface and undercarriage configuration.
Короткие отдельные толчки от деформационных швов, колеи и неровного покрытия, прерывающие непрерывную тряску.
Больше: более резкие удары от стыков и колеи.
Меньше: более мягкие детали покрытия.
Почему так: Sets gear-bump texture during ground motion, separate from touchdown impact.
Тряска планера при приближении к сваливанию и пока активна сигнализация сваливания: насколько громко это крыло сообщает, что ему плохо. Типы с четким сваливанием получают умеренный бафтинг и оставляют предупреждение звуковой сирене.
Больше: более сильная тряска перед сваливанием.
Меньше: более спокойное крыло; предупреждает звуковая сирена.
Почему так: Sets stall-buffet strength. Zero removes the cue without changing simulator stalls or warnings.
Трансзвуковой бафтинг при приближении к ограничению по числу М. Имеет смысл для реактивных самолетов вблизи MMO; ноль для поршневых и турбовинтовых, которые туда никогда не добираются.
Больше: более сильный трансзвуковой бафтинг вблизи ограничения по числу М.
Меньше: более плавный полет на больших числах М.
Почему так: Sets high-Mach buffet strength; onset and full-strength thresholds are separate.
Низкочастотная вибрация планера при выпущенных в поток закрылках, в том диапазоне скоростей, где они действительно работают в потоке.
Больше: более тряский полет, когда закрылки работают в потоке.
Меньше: более плавный заход с выпущенными закрылками.
Почему так: Sets flap buffet at the configured position and speed gates. Flap movement texture is separate.
Дробная вибрация планера от выпущенного в поток убираемого шасси. Ноль для типов с неубираемым шасси, у которых форма планера никогда не меняется.
Больше: сильнее дробная вибрация с выпущенными колесами.
Меньше: более чистый полет с выпущенным шасси.
Почему так: Sets gear aerodynamic buffet; movement and ground-contact cues are separate.
Отдельное дрожание вибратора штурвала при сваливании, запускаемое собственной системой предупреждения о сваливании воздушного судна. Значение получают только типы с настоящим вибратором штурвала; все остальные полагаются на аэродинамический бафтинг и звуковую сирену.
Больше: более сильное дрожание вибратора штурвала.
Меньше: более слабый вибратор штурвала.
Почему так: Sets triggered shaker strength; inactive while the shaker feature is disabled.
Разовый толчок при касании колесами ВПП, зависящий от вертикальной скорости снижения: мягкая посадка едва ощутима, жесткая отдается ударом.
Больше: более сильный толчок при касании.
Меньше: более мягкие посадки.
Почему так: Sets landing-impact strength; landing telemetry and response shape determine the pulse.
Вибрация на пробеге при работе реверса тяги или винтов в бета-режиме. Ноль для типов без реверса.
Больше: более тряский пробег на реверсе.
Меньше: более тихий реверс.
Почему так: Sets reverse-thrust vibration with valid reverser and engine conditions. Zero removes the cue.
Непрерывная вибрация силовой установки, следующая за оборотами от малого газа до полной мощности, — постоянное напоминание о том, что впереди что-то сжигает топливо.
Больше: двигатель сильнее ощущается в джойстике.
Меньше: более тихая силовая установка.
Почему так: Sets estimated engine vibration using configured telemetry and response, not measured cockpit vibration.
Непрерывная вибрация, только пока симулятор сообщает, что закрылки действительно движутся. Она следует за реальным движением приводов и отказами, а не за расчетным таймером.
Больше: сильнее вибрация, пока закрылки движутся.
Меньше: более тихое движение закрылков.
Почему так: Sets texture from observed flap movement; a command without movement does not establish the cue.
Насколько далеко команды автопилота могут физически перемещать джойстик. В MSFS значение минимально, потому что смещенная ось может считываться обратно как ввод пилота; ноль полностью отключает следование.
Больше: автопилот заметно дальше отклоняет ваш джойстик.
Меньше: едва ощутимое следование.
Почему так: Sets admitted AP-follow gain, not a percentage of travel. Runtime ownership and input limits still apply.
Whether this feature is active in this profile.
Почему так: Retained for compatibility and group membership. Trim relief, rather than this flag, controls centre movement.
Whether this feature is active in this profile.
Почему так: Allows trim relief with supported control law and valid telemetry. Axis authorities set its amount.
Whether this feature is active in this profile.
Почему так: Enables local force trim, separate from aircraft-owned trim and add-on integration qualification.
Whether this feature is active in this profile.
Почему так: Allows load-factor changes to modify permitted spring laws. Passive fly-by-wire feel can suppress it.
Whether this feature is active in this profile.
Почему так: Enables rate damping with the configured coefficients and control law.
Whether this feature is active in this profile.
Почему так: Following is on at 0.1 authority when a supported, valid autopilot control reference is available.
Whether this feature is active in this profile.
Почему так: Permits centering hold during a supported AP state, separate from following a moving target.
Почему так: Sets admitted AP neutral-hold strength; inactive while neutral hold is disabled.
Whether this feature is active in this profile.
Почему так: Enables aerodynamic cues; each still needs nonzero strength and its simulator conditions.
Where this effect reaches full strength (or has fully faded, for washouts).
Больше: a more gradual build to a later peak.
Меньше: a quicker build.
Почему так: Sets the final flap index for detent normalization. UP plus three detents uses maximum index3.
Where this effect begins fading in.
Больше: the effect begins later.
Меньше: it begins earlier.
Почему так: Sets the first flap detent that admits buffet; this is a handle index, not degrees.
Whether this feature is active in this profile.
Почему так: Permits shaker at supported warning conditions; the switch does not establish aircraft equipment.
Whether this feature is active in this profile.
Почему так: Enables ground effects; each still needs its own strength and contact or motion telemetry.
Whether this feature is active in this profile.
Почему так: Enables engine cues with nonzero settings and valid running-engine telemetry.
Whether this feature is active in this profile.
Почему так: Enables accessory cues with configured strengths and observed accessory movement.
The strength of this effect.
Больше: a stronger effect.
Меньше: a weaker one.
Почему так: Sets texture from observed gear movement, separate from aerodynamic and touchdown effects.
| Параметр | Значение | Что регулирует и почему |
|---|---|---|
| Spring strength | 0.74 | Push-pull primary controls motivate aerodynamic yoke loading; the linkage construction does not supply an absolute hand-force calibration. The baseline spring is 0.74. Its low-speed blend reaches baseline strength at 90 KIAS. |
| Spring deadband | 0.045 | Sets travel around the centre before the baseline spring resists. Smaller values engage it sooner. |
| Force gain | 0.8 | The aerodynamic-load gain is 0.8 with an indicated-speed reference of 185 KIAS. This supplies speed-dependent loading alongside the spring. |
| Master gain | 0.85 | Scales overall profile strength while preserving effect balance, subject to device and output limits. |
| Dynamic-pressure blend | True | Allows baseline spring strength to rise with indicated airspeed where the control law permits it. |
| Minimum spring factor | 0.5 | Sets low-speed spring strength as a fraction of baseline when blending is enabled. One keeps full strength. |
| Spring wake-up speed | 20 kt | Sets the IAS where the low-speed spring blend starts rising. This is a feel threshold, not a flight limit. |
| Spring full-strength speed | 90 kt | Sets the IAS where the low-speed blend reaches baseline strength; high-speed stiffening also uses it. |
| Скорость настройки усилия | 185.0 kt | Sets the IAS reference for aerodynamic loading. It is an estimate, not published cruise TAS or a flight limit. |
| Airspeed spring stiffening | 0.15 | The high-speed spring-stiffening gain is 0.15. It strengthens the permitted spring response above 90 KIAS, with the squared-speed ratio capped at 5. |
| Airspeed stiffening cap | 5 | Limits the squared airspeed ratio used for high-speed spring stiffening; it is not a device-force cap. |
| Aileron force scale | 0.72 | Roll and pitch aerodynamic scales are 0.72 and 1, respectively. They set the aerodynamic axis balance. No custom spring-travel curve is enabled. |
| Elevator force scale | 1.0 | Scales pitch aerodynamic loading; pitch spring travel and trim responses are separate settings. |
| Maximum output force | 0.55 | Caps directed-force output. Native spring effects and device limits remain separate. |
| StickFeel · Trim feel enabled | True | Retained for compatibility and group membership. Trim relief, rather than this flag, controls centre movement. |
| StickFeel · Trim relief enabled | True | Allows trim relief with supported control law and valid telemetry. Axis authorities set its amount. |
| StickFeel · Elevator authority | 0.3 | Electric elevator trim supports pitch-load relief. The rudder trim tab is a yaw control and does not supply aileron relief. Pitch authority 0.3 provides load relief and permitted centre movement; roll authority is 0. |
| StickFeel · Aileron authority | 0 | Scales supported roll-trim relief and permitted centre movement. Zero removes roll response. |
| StickFeel · Force trim enabled | False | Enables local force trim, separate from aircraft-owned trim and add-on integration qualification. |
| StickFeel · G load enabled | True | Allows load-factor changes to modify permitted spring laws. Passive fly-by-wire feel can suppress it. |
| StickFeel · Rate damping enabled | True | Enables rate damping with the configured coefficients and control law. |
| Autopilot · Follow enabled | True | Following is on at 0.1 authority when a supported, valid autopilot control reference is available. |
| Autopilot · Follow authority | 0.1 | Sets admitted AP-follow gain, not a percentage of travel. Runtime ownership and input limits still apply. |
| Autopilot · Neutral hold enabled | False | Permits centering hold during a supported AP state, separate from following a moving target. |
| Autopilot · Neutral hold strength | 0.6 | Sets admitted AP neutral-hold strength; inactive while neutral hold is disabled. |
| Aero · Enabled | True | Enables aerodynamic cues; each still needs nonzero strength and its simulator conditions. |
| Aero · Gain | 0.35 | Sets stall-buffet strength. Zero removes the cue without changing simulator stalls or warnings. |
| Aero · Gain | 0 | Sets high-Mach buffet strength; onset and full-strength thresholds are separate. |
| Aero · Gain | 0.14 | Sets flap buffet at the configured position and speed gates. Flap movement texture is separate. |
| Aero · Max flap index | 3 | Sets the final flap index for detent normalization. UP plus three detents uses maximum index3. |
| Aero · Min flap index | 2 | Sets the first flap detent that admits buffet; this is a handle index, not degrees. |
| Aero · Gain | 0.1 | Sets gear aerodynamic buffet; movement and ground-contact cues are separate. |
| Aero · Shaker enabled | False | Permits shaker at supported warning conditions; the switch does not establish aircraft equipment. |
| Aero · Amplitude | 0.5 | Sets triggered shaker strength; inactive while the shaker feature is disabled. |
| Ground · Enabled | True | Enables ground effects; each still needs its own strength and contact or motion telemetry. |
| Ground · Gain | 0.4 | Sets rolling texture strength, modified by speed, surface and undercarriage configuration. |
| Ground · Gain | 0.25 | Sets gear-bump texture during ground motion, separate from touchdown impact. |
| Ground · Gain | 0.65 | Sets landing-impact strength; landing telemetry and response shape determine the pulse. |
| Ground · Gain | 0 | Sets reverse-thrust vibration with valid reverser and engine conditions. Zero removes the cue. |
| Engine · Enabled | True | Enables engine cues with nonzero settings and valid running-engine telemetry. |
| Engine · Gain | 0.12 | Sets estimated engine vibration using configured telemetry and response, not measured cockpit vibration. |
| Mechanical · Enabled | True | Enables accessory cues with configured strengths and observed accessory movement. |
| Mechanical · Gain | 0.12 | Sets texture from observed flap movement; a command without movement does not establish the cue. |
| Mechanical · Gain | 0.12 | Sets texture from observed gear movement, separate from aerodynamic and touchdown effects. |
Если ваш опыт полетов на этом типе говорит о том, что на странице что-то не так, исправьте это здесь.
Эта страница составлена по цитируемым источникам, но реальный опыт полетов на этом типе важнее любой цитаты. Процитируйте утверждение, которое кажется вам ошибочным, и расскажите, как ведет себя настоящее воздушное судно. Исправления направляются сопровождающему проекта на проверку и учитываются в следующей редакции этого исследования.
Открытое обсуждение полетов и настройки Aerostar 600 на форуме сообщества. Исправления выше конфиденциально отправляются сопровождающему проекта, а разговоры в ангаре публичны.